
The performance of modern industrial robots and precision machinery is fundamentally tied to the capabilities of their core transmission components. Among these, the rotary vector reducer stands as a critical element, renowned for its high reduction ratio, compact structure, excellent torsional rigidity, and high positioning accuracy. This two-stage reducer combines a first-stage planetary gear train with a second-stage cycloidal-pin wheel mechanism, achieving remarkable torque density. However, the very nature of this geared transmission, involving multiple meshing interfaces and bearing supports, introduces nonlinearities and complex load distributions that directly impact the overall kinematic accuracy. This investigation focuses on one of the most influential yet often simplified components within the rotary vector reducer system: the main output bearing. This non-standard angular contact ball bearing supports the output flange or planet carrier and directly transmits the final output torque and radial loads to the housing. Its stiffness characteristics are not linear but vary dynamically with load and position, significantly influencing the system’s overall compliance, vibration, and transmission error. Therefore, a precise understanding and modeling of the main bearing’s nonlinear contact stiffness is paramount for predicting and enhancing the performance of the rotary vector reducer.
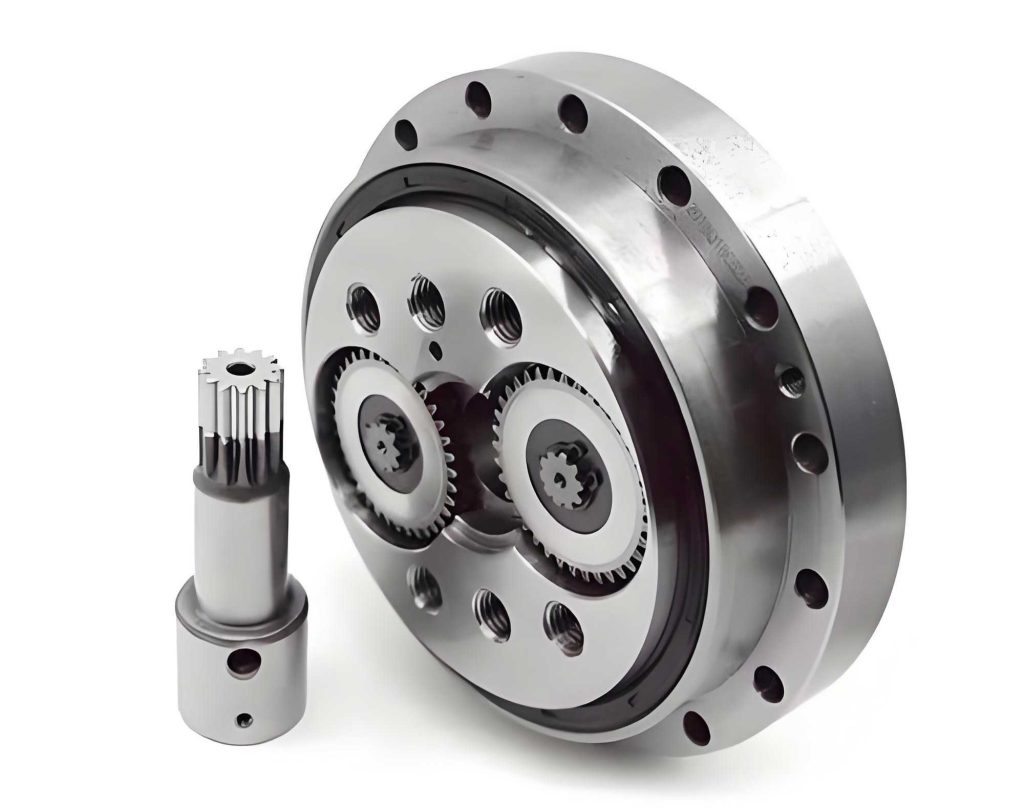
The main bearing in a rotary vector reducer operates under a complex, multi-directional load spectrum. The output stage, driven by the cycloidal disc, subjects the bearing’s inner ring to radial forces originating from the meshing of the cycloidal disc with the pinwheels. These forces are not constant but vary cyclically with the rotation of the crankshaft, which is part of the second-stage reduction. Additionally, the bearing may experience axial preloads and moments. This loading condition represents a statically indeterminate problem, meaning the distribution of load among the rolling elements cannot be solved by equilibrium equations alone; deformation compatibility must be considered. To address this, a methodology combining statically indeterminate force analysis with Hertzian contact theory is employed. This approach allows for the calculation of the load on each ball, the resulting elastic deformation at the contact ellipses, and ultimately, the derivation of the instantaneous contact stiffness for the entire main bearing assembly.
The primary parameters for a typical main bearing and its associated rotary vector reducer used in this analysis are summarized in the following tables.
| Parameter Name | Symbol | Value | Unit |
|---|---|---|---|
| Number of Balls | Z | 40 | – |
| Ball Diameter | Dw | 10 | mm |
| Pitch Circle Diameter | dm | 132 | mm |
| Initial Contact Angle | α | 10 | ° |
| Parameter Name | Symbol | Value | Unit |
|---|---|---|---|
| Total Transmission Ratio | i | 153 | – |
| Input Shaft Speed | n_input | 1050 | rpm |
| Input Power | P | 0.65 | kW |
| Sun Gear Teeth (Input) | Z1 | 15 | – |
| Planet Gear Teeth | Z2 | 57 | – |
| Cycloidal Disc Teeth | Zc | 39 | – |
| Number of Pins | Zp | 40 | – |
Static Force Analysis of the Main Bearing
The radial force acting on the main bearing’s inner ring originates from the force transmitted through the crankshaft from the cycloidal-pin gear meshing. Considering the layout of the rotary vector reducer with two crankshafts, each supported by its own main bearing, a force balance on the crankshaft system is necessary. Let \(F_A\) and \(F_B\) represent the forces from the cycloidal disc onto the crankshaft, \(F_r\) represent the radial force from the first-stage planetary gear, and \(F_{r1}\) and \(F_{r2}\) represent the reaction forces from the two main bearings onto the crankshaft (and thus, by action-reaction, the radial loads on the bearing inner races). The distances between force application points are defined as A, B, C, and D. The equilibrium equations for moments can be established as follows:
$$F_{r1} \times (A+B+C) + F_A \times (B+C) – F_B \times C – F_r \times D = 0$$
$$F_{r2} \times (A+B+C) + F_A \times A – F_B \times (A+B) + F_r \times (A+B+C+D) = 0$$
By solving this system, the radial loads \(F_{r1}\) and \(F_{r2}\) on each main bearing can be determined. For a given radial load \(F_r\) on a single main bearing and assuming a load distribution where the radial component is carried by balls in compression, the approximate normal contact force \(Q\) on the most heavily loaded ball can be estimated for initial analysis as:
$$Q \approx \frac{F_r}{Z \cos \alpha}$$
However, this simplified formula ignores the statically indeterminate nature and the variation of contact angle under load. A more accurate model requires considering the relative displacement between the inner and outer rings and enforcing compatibility of deformations for all balls, leading to a nonlinear system of equations solved iteratively. The resulting load distribution is periodic with the rotation of the crankshaft, and consequently, with the rotation of the cycloidal disc. As the crankshaft completes one revolution, the cycloidal disc rotates by one tooth pitch (e.g., ~9° for a 39-tooth disc). The normal contact force \(Q\) on the critical ball varies cyclically with this motion.
Theoretical Derivation of Contact Stiffness Based on Hertz Theory
The contact stiffness between a ball and a raceway is inherently nonlinear, as the contact area and pressure distribution depend on the load. Hertzian contact theory provides the foundational framework for modeling this behavior under the assumptions of homogeneous, isotropic, linear-elastic materials, smooth surfaces, and absence of tangential traction. For a ball bearing, the contact between a ball and a groove is a point contact that deforms into an elliptical area under load.
The geometry is defined by the principal curvatures of the two contacting bodies. For the ball (Body I) and the outer or inner raceway (Body II), the principal curvatures are:
$$\rho_{1}^{I} = \rho_{1}^{II} = \frac{2}{D_w}$$
$$\rho_{2}^{I} = -\frac{2}{f D_w}, \quad \rho_{2}^{II} = \frac{2}{D_i} \quad \text{(for inner ring contact)}$$
$$\rho_{2}^{I} = -\frac{2}{f D_w}, \quad \rho_{2}^{II} = -\frac{2}{D_o} \quad \text{(for outer ring contact)}$$
where \(f\) is the curvature radius coefficient (ratio of groove radius to ball diameter), and \(D_i\) and \(D_o\) are related to the inner and outer raceway diameters. The negative sign indicates a concave surface. The sum and difference of the principal curvatures are critical parameters:
$$\sum \rho = \rho_{1}^{I} + \rho_{1}^{II} + \rho_{2}^{I} + \rho_{2}^{II}$$
$$F(\rho) = \frac{(\rho_{1}^{II} – \rho_{1}^{I}) + (\rho_{2}^{II} – \rho_{2}^{I})}{\sum \rho}$$
The function \(F(\rho)\) relates to the ellipticity of the contact area. According to Hertz theory, the normal approach \(\delta\) (mutual elastic deformation of the two bodies at the contact point) for steel-on-steel contact is given by:
$$\delta = \epsilon_{\delta} (\sum \rho)^{-1/3} Q^{2/3}$$
Here, \(\epsilon_{\delta}\) is a dimensionless deflection coefficient that depends on the complete elliptic integrals, which are functions of \(F(\rho)\). The contact stiffness for a single ball-raceway contact pair, \(K_{contact}\), is defined as the derivative of the load with respect to the deformation:
$$K_{contact} = \frac{dQ}{d\delta}$$
Since \(Q \propto \delta^{3/2}\) from the Hertz relation, the contact stiffness becomes:
$$K_{contact} \propto Q^{1/3} \propto \delta^{1/2}$$
This clearly demonstrates the nonlinear nature: stiffness increases with the applied load. For the entire main bearing in the rotary vector reducer, the overall axial/radial stiffness is a complex assembly of the series and parallel combinations of the contact stiffnesses at each loaded ball, further modulated by the bearing geometry and the varying load distribution. The total deflection \(\Delta\) under a radial load \(F_r\) is found by solving the force equilibrium and displacement compatibility equations iteratively, from which the bearing’s overall radial stiffness \(K_{bearing}\) is computed as \(K_{bearing} = F_r / \Delta\).
This stiffness is not constant but varies periodically as the bearing rotates and the load distribution shifts from ball to ball. A key geometric parameter influencing this stiffness is the curvature radius coefficient \(f\). It affects the conformity between the ball and the raceway, thereby altering the contact ellipse dimensions, the contact stress, and ultimately the load-deformation relationship. An optimal value of \(f\) exists that maximizes load capacity and stiffness while minimizing contact stress. Analysis shows that for the main bearing in a typical rotary vector reducer, a value around \(f = 0.55\) yields the highest contact stiffness across the operational load cycle.
| Curvature Radius Coefficient (f) | Approximate Maximum Single Contact Stiffness | Relative Trend |
|---|---|---|
| 0.525 | 3.29 x 10³ N/mm | Lower |
| 0.550 | 3.31 x 10³ N/mm | Highest |
| 0.575 | 3.16 x 10³ N/mm | Lower |
Finite Element Analysis for Validation
To validate the theoretical stiffness model derived from statically indeterminate analysis and Hertz theory, a detailed Finite Element Analysis (FEA) is conducted. FEA directly solves the boundary value problem of continuum mechanics, governed by the equations of equilibrium, constitutive relations (Hooke’s law for linear elasticity), and strain-displacement (geometric) relations. The strong form for a static linear elastic problem in index notation is:
Equilibrium: $$\sigma_{ij,j} + b_i = 0$$
Constitutive Law: $$\sigma_{ij} = D_{ijkl} \epsilon_{kl}$$
Strain-Displacement: $$\epsilon_{ij} = \frac{1}{2}(u_{i,j} + u_{j,i})$$
with boundary conditions \(u_i = \bar{u}_i\) on \(S_u\) (displacement boundary) and \(\sigma_{ij} n_j = \bar{t}_i\) on \(S_t\) (traction boundary). The weak form, often solved via the Galerkin method using shape functions \(N_i\), transforms this into a system of linear equations \([K]\{u\} = \{F\}\), where \([K]\) is the global stiffness matrix—the numerical analog of the physical stiffness we seek to characterize.
For efficiency and clarity, a sub-model of the main bearing assembly is created, focusing on a sector containing one ball in contact with both the inner and outer rings. Symmetry boundary conditions are applied to represent the effect of the full bearing. The model is meshed with high-quality hex-dominant elements, with refined mesh in the anticipated contact regions. Contact pairs between the ball and the raceways are defined using a surface-to-surface algorithm with Lagrange multiplier or augmented Lagrangian formulation to handle the nonlinear, constrained nature of the contact. The material is defined as bearing steel (e.g., GCr15) with Young’s modulus \(E = 210\) GPa and Poisson’s ratio \(\nu = 0.3\).
| Component | Element Type | Mesh Size (Global/Contact) | Number of Nodes/Elements (Sector Model) |
|---|---|---|---|
| Inner Ring | C3D10 (Tet) / C3D8R (Hex) | 2 mm / 0.5 mm | ~110,000 nodes |
| Ball | C3D10 (Tet) / C3D8R (Hex) | 1 mm / 0.3 mm | ~106,000 elements |
| Outer Ring | C3D10 (Tet) / C3D8R (Hex) | 2 mm / 0.5 mm | – |
A static analysis is performed first. The radial load \(F_r\), corresponding to a specific crankshaft angle, is applied to the inner ring’s reference point coupled to its inner surface, while the outer ring is fixed. The analysis solves for the deformation and stress fields. The normal elastic strain in the ball along the load line is extracted, which corresponds to the theoretical elastic deformation \(\delta\). The results from the FEA simulation show excellent agreement with the theoretical predictions from the Hertz-based model. The deformation pattern clearly shows the elliptical contact area, and the magnitude of deformation follows the same periodic trend as the theoretical curve when plotted against crankshaft rotation angle.
A transient dynamic analysis is also conducted to observe the behavior over a short time period as the load varies. The load is applied as a time-varying function simulating one-half revolution of the crankshaft. The results show a smooth, periodic variation in strain, converging to a stable periodic response, confirming the dynamic stability of the contact. A path plot through the center of the ball, from one contact point to the other, reveals the strain distribution: maximum compressive strain at the contact regions and near-zero strain at the ball’s core, which aligns perfectly with the expectations from Hertzian contact theory for a sphere under diametral compression.
| Metric | Theoretical Value (Hertz Model) | FEA Static Analysis Value | Agreement |
|---|---|---|---|
| Maximum Deformation \(\delta_{max}\) | 0.0130 mm | 0.0130 mm | Excellent |
| Minimum Deformation \(\delta_{min}\) | 1.42e-4 mm | ~1.49e-4 mm | Very Good |
| Path: Max Strain at Contact | – | ~3.8e-4 | Consistent with theory |
| Path: Min Strain at Core | – | ~1.1e-4 | Consistent with theory |
Conclusion
This investigation provides a comprehensive methodology for analyzing the nonlinear contact stiffness of the main bearing in a rotary vector reducer, a critical factor for the system’s transmission accuracy. By integrating a statically indeterminate force analysis specific to the reducer’s kinematics with the classical Hertzian contact theory, a theoretical model for the time-varying bearing stiffness was developed. The model successfully captures the periodic fluctuation of stiffness resulting from the cyclically varying load distribution imposed by the cycloidal-pin gear meshing. The analysis identifies the curvature radius coefficient of the raceway as a significant design parameter, with an optimal value near \(f = 0.55\) for maximizing the main bearing’s contact stiffness in this specific rotary vector reducer application.
The theoretical findings were robustly validated through detailed nonlinear Finite Element Analysis. The FEA results, including both static and transient simulations, showed remarkable agreement with the theoretical predictions for elastic deformation under load. The observed strain distribution within the ball element, characterized by maxima at the contact points and minima at the core, perfectly aligns with the physical expectations from Hertzian theory. This consistency between the analytical Hertz-based model and the numerical FEA solution confirms the validity and accuracy of the proposed approach for characterizing the complex, nonlinear stiffness behavior of the main bearing. Consequently, this work establishes a reliable framework for modeling, simulating, and optimizing the elastic properties of this essential component, ultimately contributing to the design of higher-precision and more reliable rotary vector reducers for advanced robotic and precision mechanical systems.