
The evolution of robotics, driven by the demands of modern industry and security, necessitates the development of intelligent systems capable of operating in hazardous or complex environments. The core of this evolution lies in bionic robot design, which draws inspiration from biological systems to enhance functionality, adaptability, and efficiency. This paper details the comprehensive design, simulation, and fabrication of a multifunctional bionic robot system, initially conceptualized for hazardous material handling but with principles applicable to a wide range of tasks. The primary objective is to replace human operators in dangerous scenarios, such as explosive ordnance disposal (EOD), thereby significantly increasing safety margins. The system integrates a mobile platform, a multi-degree-of-freedom manipulator, an end-effector, and a sophisticated virtual reality (VR) control interface, embodying the essence of a bionic robot through its articulated structure and intelligent control.
The mechanical architecture of the bionic robot is engineered for stability and dexterity. The mobile platform employs a tracked drive system, providing superior traction, obstacle negotiation, and stability on uneven terrain compared to conventional wheeled designs. The manipulator, inspired by the human arm, features a waist joint, upper arm (shoulder), forearm (elbow), and a wrist-mounted end-effector, granting it the necessary dexterity for precise operations. Actuation is achieved through a combination of DC servo motors and precision gear trains, ensuring reliable torque transmission and positional accuracy. The design of each joint involves critical calculations for motor selection, gear design, and strength verification to ensure robust performance under load.
Mechanical Arm Joint Design and Actuation
The manipulator is the core functional element of the bionic robot. Its design requires careful consideration of load capacity, range of motion, and precision. Each joint’s motion and power parameters are foundational for component selection. The primary joints (Joints I, II for the arm) were analyzed as follows:
| Joint Axis | Rotational Speed n (rpm) | Power P (kW) | Torque T (N·m) | Gear Ratio i | Efficiency η |
|---|---|---|---|---|---|
| I0 (Motor Output) | 128 | 0.03 | 2.238 | 2 | – |
| I (After 1st Reduction) | 64 | 0.0282 | 4.3868 | – | 0.94 |
| II (After 2nd Reduction) | 12.8 | 0.0285 | 20.8504 | 5 | 0.98 |
For the revolute joints of the bionic robot arm, spur gear trains were selected for their reliability and efficiency in transmitting motion and torque between parallel shafts. The design process for a representative gear pair (e.g., Joint I drive) involves material selection, kinematic design, and verification against failure modes like contact fatigue and bending fatigue.
Gear Design Parameters and Calculations: For a gear pair with a desired ratio \(u = 3.2\), starting with a pinion tooth count \(z_1 = 24\), the gear tooth count is \(z_2 = u \cdot z_1 = 76.8 \approx 77\), giving an actual ratio \(u’ = 77/24 \approx 3.208\). The error is negligible: \(\frac{u’ – u}{u} \times 100\% = 0.25\%\).
The design follows the surface contact fatigue strength criterion, checked against bending fatigue. The design formula for the pinion’s pitch diameter is:
$$ d_{1t} \geq \sqrt[3]{\frac{2K_t T_1}{\phi_d} \cdot \frac{u \pm 1}{u} \left( \frac{Z_H Z_E}{[\sigma_H]} \right)^2 } $$
Where \(K_t\) is the trial load factor (1.8), \(T_1\) is the pinion torque (\(4.3 \times 10^3\) N·mm), \(\phi_d\) is the face width coefficient (1.0 for soft gears), \(Z_H\) is the zone factor (2.5), \(Z_E\) is the elasticity factor (189.8 \(\sqrt{MPa}\)), and \([\sigma_H]\) is the allowable contact stress. Material properties for 45 steel (pinion: tempered, 230 HB; gear: normalized, 190 HB) yield endurance limits \(\sigma_{Hlim1}=590\) MPa and \(\sigma_{Hlim2}=470\) MPa. After calculating life factors \(K_{HN1}=0.95\), \(K_{HN2}=0.85\) and using a safety factor \(S_H=1\), the allowable stresses are \([\sigma_{H1}] = 560.5\) MPa and \([\sigma_{H2}] = 399.5\) MPa. Using the smaller value \([\sigma_{H2}]\) in the formula yields a trial diameter \(d_{1t} = 30.588\) mm.
Subsequent calculations for speed \(v\), module \(m_t\), and face width \(b\) lead to a refined load factor \(K = K_A K_v K_{H\alpha} K_{H\beta} = 1 \times 1 \times 1 \times 1.417 = 1.417\). The corrected diameter is:
$$ d_1 = d_{1t} \sqrt[3]{\frac{K}{K_t}} = 30.588 \times \sqrt[3]{\frac{1.417}{1.8}} \approx 26.12 \text{ mm} $$
The standard module is chosen as \(m = 1\) mm. Therefore, the final dimensions are: \(d_1 = m z_1 = 24\) mm, \(d_2 = m z_2 = 77\) mm, center distance \(a = (d_1+d_2)/2 = 50.5\) mm, and face width \(b = \phi_d d_1 = 24\) mm (with \(b_2\) taken as 30 mm for the gear).
Bending Fatigue Check: The verification formula is \(\sigma_F = \frac{2K T_1 Y_{Fa} Y_{Sa}}{b d_1 m}\). For the pinion (\(Y_{Fa1}=2.65, Y_{Sa1}=1.58\)) and gear (\(Y_{Fa2}=2.22, Y_{Sa2}=1.77\)), with bending endurance limits \(\sigma_{Flim1}=215\) MPa, \(\sigma_{Flim2}=190\) MPa, life factors \(K_{FN1}=0.89, K_{FN2}=0.92\), stress correction factor \(Y_{ST}=2\), and safety factor \(S_F=1.3\), the allowable bending stresses are \([\sigma_{F1}] = 294.6\) MPa and \([\sigma_{F2}] = 268.9\) MPa. The calculated stresses \(\sigma_{F1} = 26.8\) MPa and \(\sigma_{F2} = 25.1\) MPa are well below the allowable limits, confirming the design’s safety. Similar calculations were performed for the other arm joints, resulting in compact, reliable gear transmissions essential for the bionic robot‘s articulated movement.
End-Effector Design for Dexterous Manipulation
The end-effector of a bionic robot, akin to a human hand, must provide adequate grip force, precise motion, and adaptability. For this application, a two-fingered parallel gripper was designed. The fingers open and close via a symmetric gear mechanism where two identical gears mesh, ensuring parallel motion. The gripper fingers are designed with a lightweight yet rigid material and are fitted with rubber pads to prevent slippage and absorb shocks, a critical feature for handling sensitive objects. The gear pair for the gripper, with \(z = 16\) teeth each, module \(m = 2\) mm, and pitch diameter \(d = 32\) mm, was also verified for bending fatigue strength, ensuring reliable operation under clamping loads.
Simulation and Control Architecture
The integration of Virtual Reality (VR) technology marks a significant advancement in bionic robot teleoperation, providing an immersive and intuitive control interface. This system allows operators to rehearse complex maneuvers in a safe virtual environment before executing them in reality, drastically reducing risk. The simulation framework was built using a multi-platform approach: V-REP (now CoppeliaSim) for modeling and inverse kinematics computation, Unity3D for developing the interactive simulation platform, and HTC Vive for delivering the immersive VR experience. This setup enables real-time, interactive simulation of the bionic robot‘s kinematics, visualizing its motion paths and joint states in a 3D virtual space.
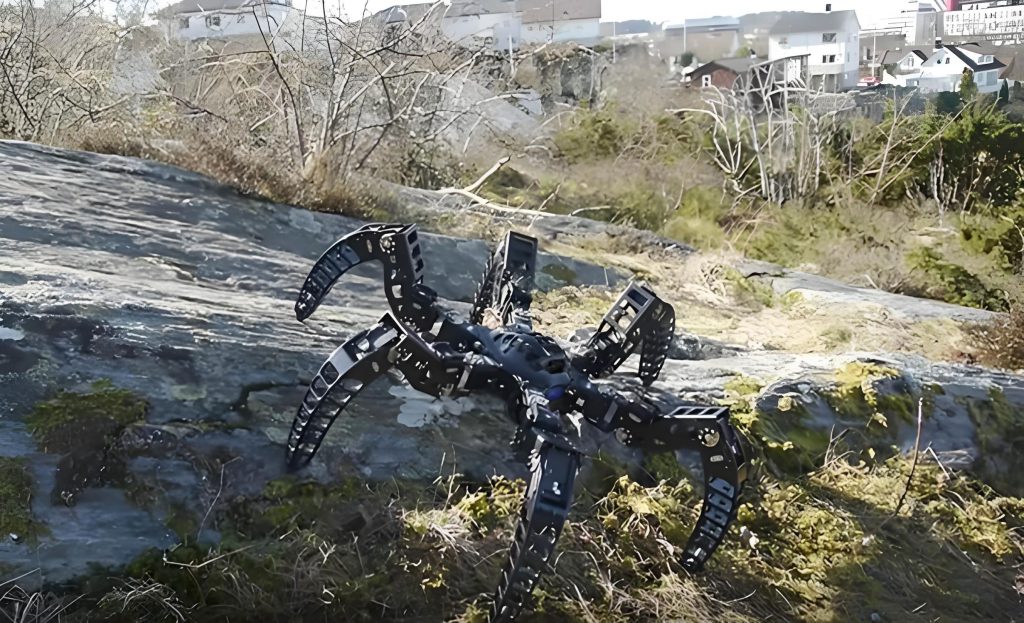
The control system of the physical bionic robot is based on a microcontroller unit (MCU) architecture. It comprises a minimum system board, power regulation modules, motor drivers (for DC servos and track motors), and various functional modules (sensors, wireless communication). The MCU interprets commands from the remote operator (via the VR interface or a traditional controller) and generates precise PWM signals to control the joint motors and drive systems, enabling coordinated movement of the entire bionic robot.
Kinematic and Dynamic Simulation
Prior to physical fabrication, the bionic robot model undergoes extensive simulation. The 3D CAD model, created in software like SolidWorks, is used for interference checking and mass property analysis. Key components like the manipulator arm, gripper, and tracked chassis are simulated to validate their range of motion and structural integrity.
The forward kinematics of the bionic robot arm can be described using the Denavit-Hartenberg (D-H) convention. For a 4-DOF arm (waist, shoulder, elbow, and a simple gripper roll/pitch), the transformation from base frame to end-effector frame is:
$$ T^{0}_{4} = A^{0}_{1} A^{1}_{2} A^{2}_{3} A^{3}_{4} $$
Where each homogeneous transformation matrix \(A^{i-1}_{i}\) is a function of its joint angle \(\theta_i\), link length \(a_{i-1}\), link offset \(d_i\), and twist angle \(\alpha_{i-1}\). The end-effector position \((p_x, p_y, p_z)\) and orientation are derived from \(T^{0}_{4}\). Dynamic simulation further involves solving the equations of motion using the Lagrangian formulation:
$$ \tau_i = \frac{d}{dt} \left( \frac{\partial L}{\partial \dot{q}_i} \right) – \frac{\partial L}{\partial q_i} $$
where \(L = K – P\) is the Lagrangian (Kinetic energy minus Potential energy), \(q_i\) are the generalized coordinates (joint angles), and \(\tau_i\) are the generalized forces (joint torques). These simulations help in selecting motors with sufficient torque and in tuning the control algorithms.
A summary of key designed parameters and component selections for the bionic robot is presented below:
| Subsystem | Component | Key Parameter/Model | Value/Specification |
|---|---|---|---|
| Manipulator | Shoulder Joint Gear | Pinion/Gear Teeth (z1/z2), Module | 24 / 77, m=1 mm |
| Elbow Joint Gear | Pinion/Gear Teeth (z1/z2), Module | 16 / 48, m=1 mm | |
| Joint Actuator | DC Servo Motor (Typical) | Rated Torque > 25 N·cm | |
| End-Effector | Gripper Gear | Teeth per gear, Module | 16, m=2 mm |
| Gripper Actuator | Micro Servo | High torque for clamping | |
| Drive System | Track Drive Motor | DC Geared Motor | High RPM, sufficient stall torque |
| Waist Joint | Bevel Gears, Actuator | 1:1 ratio, High-torque Servo | |
| Control | Main Controller | Microcontroller Unit (MCU) | ARM Cortex-M based |
| Power | Battery Pack | Lithium Polymer (LiPo) | 12V, High Capacity (e.g., 5000mAh+) |
Fabrication and Integration
The transition from simulation to physical embodiment is a critical phase in bionic robot development. Based on the finalized design and simulation results, the robot is fabricated. The tracked chassis provides a stable base, with motors driving sprockets that engage the reinforced rubber tracks. The manipulator segments are assembled with precision-aligned bearings and gearboxes. Four dedicated servo motors are integrated into the arm and waist, providing the required 360-degree rotation and articulated motion. The gripper, actuated by a servo through a worm-gear or linkage mechanism, achieves parallel jaw motion. All electronic components—the MCU, motor drivers, voltage regulators, and wireless transceivers—are housed within the robot’s body, connected via a robust harness. The final integrated system represents a functional bionic robot capable of remote teleoperation.
Performance Analysis and Material Considerations
The performance of the bionic robot hinges on the careful selection of materials and stress analysis. Key structural members, like the manipulator links, must be lightweight to reduce inertia but stiff to minimize deflection under load. Common materials include aluminum alloys (e.g., 6061-T6) for strength-to-weight ratio and polymers like ABS or polycarbonate for non-load-bearing covers. Stress analysis for a cantilevered arm link under a combined bending moment \(M\) and gripper load \(F\) at the end involves calculating the bending stress \(\sigma_b\):
$$ \sigma_b = \frac{M y}{I} + \frac{F L}{A} $$
where \(y\) is the distance from the neutral axis, \(I\) is the area moment of inertia, \(L\) is the length, and \(A\) is the cross-sectional area. This stress must be less than the material’s yield strength \(\sigma_y\) with an appropriate safety factor \(n\): \(\sigma_b < \sigma_y / n\). The tracked system’s traction force \(F_{traction}\) is limited by the coefficient of friction \(\mu\) and the robot’s weight \(W\): \(F_{traction} \leq \mu W\). The motor must provide enough torque to overcome this force at the sprocket radius \(r\): \(\tau_{motor} \geq F_{traction} \cdot r / (i \cdot \eta_{drive})\), where \(i\) is the gear reduction and \(\eta_{drive}\) is the drive efficiency.
A comparative analysis of potential materials for critical components is useful:
| Component | Material Option 1 | Material Option 2 | Key Property Consideration |
|---|---|---|---|
| Arm Links | Aluminum 6061-T6 | Carbon Fiber Composite | Specific Stiffness (E/ρ), Cost |
| Gear Wheels | Steel 45 (Case-Hardened) | Acetal (POM) | Wear Resistance, Noise, Load Capacity |
| Chassis Frame | Aluminum Sheet | ABS (3D Printed) | Impact Strength, Fabrication Complexity |
| Gripper Jaws | Aluminum with Rubber Pad | Polycarbonate | Grip Coefficient, Weight |
Conclusion and Future Perspectives
This work has presented a holistic approach to the design, simulation, and development of a sophisticated bionic robot system. From the detailed mechanical design of its articulated arm and gripper, through rigorous simulation of its kinematics and dynamics, to the integration of an immersive VR control interface, each step contributes to creating a machine capable of performing delicate tasks in hazardous environments. The use of tracked mobility enhances its terrain adaptability, a key feature for a practical bionic robot. While the initial application focus is on EOD, the underlying principles of robust mechanical design, precise actuation, and intelligent teleoperation are universally applicable in fields such as search and rescue, industrial inspection, and remote maintenance. The presented bionic robot serves as a testbed prototype. Future iterations would benefit from advanced sensor fusion (LIDAR, force/torque sensing), more autonomous behaviors using machine learning, and enhanced materials to improve the strength-to-weight ratio further. The continuous refinement of such bionic robot platforms is essential for pushing the boundaries of what machines can do to assist and protect human operators in challenging scenarios.