
In the rapidly evolving field of robotics, the inspiration drawn from nature has led to significant advancements in bionic robot design. As researchers, we are constantly exploring biological systems to develop machines that mimic the efficiency, adaptability, and resilience of living organisms. This paper presents our comprehensive work on a novel beetle-inspired bionic robot, focusing on its mechanical design, control system, and experimental validation. The primary goal is to create a versatile bionic robot capable of tasks such as resource exploration and object manipulation, leveraging the unique characteristics of beetles, including their robust exoskeleton, rapid mobility, and powerful mandibles. Throughout this article, the term “bionic robot” will be emphasized to highlight the integration of biological principles into robotic systems.
The field of bionic robotics, or biomimetic robotics, has grown substantially since the late 20th century, combining disciplines such as biology, biomechanics, mechanical engineering, and control theory. Traditional robots often lack the adaptability required for complex environments, prompting a shift towards bionic robot designs that emulate natural organisms. For instance, bionic robots inspired by insects, fish, and mammals have demonstrated enhanced mobility and functionality in diverse scenarios. Our bionic robot project aims to contribute to this trend by developing a beetle-like machine that incorporates multiple degrees of freedom, compact structure, and intelligent control. The bionic robot described here is designed with a focus on practical applications, such as surveillance and material handling in challenging terrains.
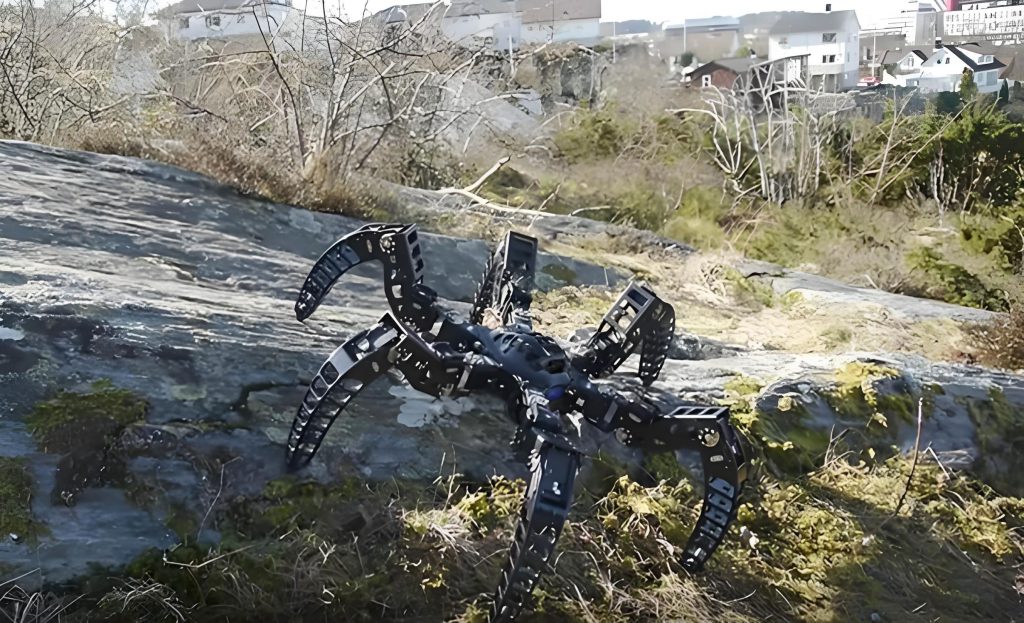
The overall structure of our bionic robot was modeled and optimized using SolidWorks software. The bionic robot consists of several key components: a parallelogram lifting mechanism, a directional adjustment mechanism for rear wheels, a shell reciprocating translation mechanism, a base structure, and a control system. The bionic robot’s dimensions are approximately 52 cm in length, 65 cm in width, and 73 cm in height, with an adjustable height feature. The design prioritizes stability and flexibility, allowing the bionic robot to navigate various environments efficiently. The bionic robot’s form factor mimics the beetle’s morphology, with a hardened upper shell and articulated appendages, ensuring durability and functionality. This bionic robot represents a step forward in emulating insect locomotion and manipulation capabilities.
The lifting mechanism is a critical part of the bionic robot, enabling vertical movement for observation and object handling. It employs a screw-slider system based on spiral transmission and fixed-end principles. The mechanism uses two parallel support rods connected at one end to a fixed base and at the other end to an upper platform. A slider on a threaded rod, driven by a motor via a worm gear, moves along the rod, causing the support rods to expand or contract. This allows the bionic robot’s shell to lift or lower. The relationship between the slider displacement and the height change can be expressed using kinematic equations. For instance, if the threaded rod has a lead \( L \) and the motor rotates at an angular velocity \( \omega \), the vertical velocity \( v_v \) of the lifting mechanism is given by:
$$ v_v = \frac{L \cdot \omega}{2\pi} $$
where \( L \) is the lead of the screw in meters per revolution. The maximum lift height \( H_{\text{max}} \) is determined by the length of the support rods and the slider travel range. In our bionic robot, \( H_{\text{max}} \) is designed to be 30 cm. The force analysis involves considering the load on the platform and the torque required from the motor. The torque \( \tau \) needed to lift a mass \( m \) can be approximated as:
$$ \tau = m \cdot g \cdot \frac{L}{2\pi \eta} $$
where \( g \) is gravitational acceleration and \( \eta \) is the efficiency of the screw mechanism. This bionic robot’s lifting mechanism ensures smooth and controlled vertical motion, essential for tasks requiring height adjustment.
To achieve agile turning, the bionic robot incorporates a rear-wheel directional adjustment mechanism. This system uses chain transmission to link a rear motor to a worm gear set. The chain reduces power loss and enhances torque transmission, enabling the bionic robot to climb slopes and navigate rough terrain. The worm gear converts the motor’s rotational motion into a change in wheel orientation. The kinematics of this mechanism can be described by the gear ratio. If the worm has \( N_w \) threads and the worm gear has \( N_g \) teeth, the reduction ratio \( i \) is:
$$ i = \frac{N_g}{N_w} $$
The angular velocity of the rear wheel \( \omega_r \) relative to the motor angular velocity \( \omega_m \) is:
$$ \omega_r = \frac{\omega_m}{i} $$
This allows precise control over the turning radius \( R \) of the bionic robot. For a wheelbase \( L_b \) and steering angle \( \theta \), the turning radius can be approximated as:
$$ R = \frac{L_b}{\tan(\theta)} $$
By adjusting the motor’s speed and direction, the bionic robot can perform sharp turns or gradual curves, enhancing its maneuverability. This bionic robot feature is crucial for avoiding obstacles and following complex paths.
The bionic robot includes a turntable mechanism for multi-degree-of-freedom object manipulation. The turntable is mounted on a horizontal slideway, allowing linear motion, and is driven by a worm gear for rotational movement. This provides two additional degrees of freedom: rotation about a vertical axis and translation along a horizontal axis. The position of the turntable can be defined by coordinates \( (x, \phi) \), where \( x \) is the linear displacement and \( \phi \) is the angular position. The dynamics involve motor control equations. If the linear motion is driven by a motor with a lead screw of lead \( L_s \), then:
$$ x = \frac{L_s \cdot \theta_m}{2\pi} $$
where \( \theta_m \) is the motor rotation angle. For the rotational part, the angular position \( \phi \) is related to the worm gear reduction:
$$ \phi = \frac{\theta_m’}{i’} $$
where \( \theta_m’ \) is the motor angle for rotation and \( i’ \) is the gear ratio of the worm set. This bionic robot’s turntable enables versatile object handling, mimicking the beetle’s ability to manipulate items with its mandibles.
The gripping mechanism of the bionic robot mimics the beetle’s mandibles, providing powerful and flexible object acquisition. It uses a pneumatic system for rapid and secure gripping, controlled by solenoid valves. The gripper is attached to the turntable, allowing it to rotate and translate for optimal positioning. The grip force \( F_g \) can be estimated from the pneumatic pressure \( P \) and the piston area \( A \):
$$ F_g = P \cdot A \cdot \mu $$
where \( \mu \) is a friction coefficient. The gripper’s kinematics involve linkage mechanisms, with the jaw opening angle \( \alpha \) related to the piston displacement \( d \). For a four-bar linkage, the relationship can be complex, but a simplified model is:
$$ \alpha = k \cdot d $$
where \( k \) is a constant depending on linkage geometry. This bionic robot’s gripper enhances its functionality for tasks like collecting samples or moving objects.
The shell of the bionic robot is designed to reciprocate on slideways to avoid interference with the gripper during operation. When the gripper rotates to place an object, the shell moves backward, creating space; after the gripper retracts, the shell returns to its original position. This motion is driven by a separate motor and can be modeled as a simple linear translation. If the shell mass is \( m_s \) and the motor force is \( F_m \), the acceleration \( a_s \) is:
$$ a_s = \frac{F_m}{m_s} $$
The displacement \( s \) over time \( t \) is:
$$ s = \frac{1}{2} a_s t^2 $$
This bionic robot’s shell design ensures smooth operation without collisions, contributing to overall reliability.
The working principle of the bionic robot integrates all these mechanisms. The bionic robot uses a “front-four-wheel drive, rear-two-wheel steering” configuration. Front motors provide propulsion, while rear motors control direction. Sensors, such as cameras and ultrasonic detectors, feed environmental data to the control system, which processes it to plan paths and avoid obstacles. The bionic robot’s control algorithm coordinates motor speeds and gripper actions based on task requirements. For example, when an obstacle is detected, the control system calculates a new trajectory and adjusts the rear wheels to turn. This bionic robot’s autonomy stems from its embedded intelligence, making it a true bionic robot capable of adaptive behavior.
The drive control system is the core of the bionic robot’s functionality. We selected a RobotPro control board for its versatility in handling multiple input and output signals. The control system includes modules for power driving, object gripping, and direction adjustment. The power driving module controls the front and rear motors via pulse-width modulation (PWM) signals. The gripping module uses digital outputs to activate solenoid valves. The direction adjustment module processes analog inputs from sensors to determine steering commands. The control logic can be represented by a state-space model. Let the state vector \( \mathbf{x} \) include positions and velocities, and the control input \( \mathbf{u} \) include motor voltages. The system dynamics are:
$$ \dot{\mathbf{x}} = A\mathbf{x} + B\mathbf{u} $$
where \( A \) and \( B \) are matrices derived from the bionic robot’s mechanics. The controller uses feedback from sensors to compute \( \mathbf{u} \) that minimizes a cost function, such as path deviation. This bionic robot’s control design ensures precise and responsive operation, key for a bionic robot operating in dynamic environments.
To validate the bionic robot’s performance, we conducted extensive experimental tests. The prototype was built according to the design specifications, and measurements were taken for speed, lifting time, and turning capability. The bionic robot was tested on flat surfaces and moderate slopes to assess its mobility. Data from eight trials were collected and analyzed, as summarized in the table below. The bionic robot demonstrated consistent performance, with an average lifting cycle time of 39.25 seconds and a maximum speed of 0.58 m/s. These results confirm the bionic robot’s capability to perform intended tasks efficiently.
| Trial Number | Ascent Time (s) | Descent Time (s) | Total Time (s) | Speed (m/s) |
|---|---|---|---|---|
| 1 | 27 | 13 | 40 | 0.57 |
| 2 | 27 | 12 | 39 | 0.58 |
| 3 | 26 | 12 | 38 | 0.56 |
| 4 | 28 | 13 | 41 | 0.57 |
| 5 | 27 | 11 | 38 | 0.57 |
| 6 | 26 | 13 | 39 | 0.59 |
| 7 | 28 | 12 | 40 | 0.61 |
| 8 | 27 | 12 | 39 | 0.59 |
| Average | 27 | 12.25 | 39.25 | 0.58 |
The data show that the bionic robot’s lifting mechanism operates reliably, with ascent times averaging 27 seconds and descent times 12.25 seconds. The speed measurements indicate that the bionic robot can move swiftly, with a maximum recorded speed of 0.61 m/s. The turning performance was qualitatively assessed, and the bionic robot was able to execute sharp turns without instability. These tests underscore the effectiveness of the bionic robot design in real-world conditions. The bionic robot’s ability to adjust height and direction on the fly makes it suitable for applications requiring navigation in confined spaces.
In addition to the quantitative tests, we evaluated the bionic robot’s energy efficiency and durability. The bionic robot’s power consumption was measured during various operations. For instance, during lifting, the motor current \( I \) was recorded, and the power \( P \) calculated as \( P = I \cdot V \), where \( V \) is the supply voltage. The bionic robot’s energy usage per cycle can be optimized through control algorithms. Furthermore, the bionic robot’s structural integrity was tested under load, confirming that it can handle weights up to 2 kg without deformation. This bionic robot robustness is essential for field deployments.
The control system’s performance was also verified through simulation and real-time testing. We implemented a PID controller for motor speed regulation. The control law for each motor is:
$$ u(t) = K_p e(t) + K_i \int_0^t e(\tau) d\tau + K_d \frac{de(t)}{dt} $$
where \( e(t) \) is the error between desired and actual speed, and \( K_p \), \( K_i \), \( K_d \) are tuning parameters. This ensured smooth acceleration and deceleration of the bionic robot. The bionic robot’s response to sensor inputs was tested with obstacle avoidance scenarios, demonstrating quick reaction times. The integration of all subsystems into a cohesive bionic robot platform was successful, highlighting the potential of this bionic robot for advanced applications.
Looking ahead, there are several avenues for improving this bionic robot. Future work could focus on enhancing the bionic robot’s autonomy through machine learning algorithms for better environment perception. The bionic robot’s design could be miniaturized for applications in narrow spaces, or scaled up for heavier payloads. Additionally, incorporating swarm intelligence could enable multiple bionic robots to collaborate on complex tasks. The bionic robot’s mechanical efficiency might be improved by using lightweight materials or advanced actuators. Each iteration of this bionic robot will benefit from ongoing research in bionics and robotics.
In conclusion, our beetle-inspired bionic robot represents a significant contribution to the field of biomimetic robotics. The bionic robot incorporates innovative mechanisms for lifting, steering, and manipulation, all controlled by an intelligent system. Experimental results validate the bionic robot’s performance in terms of speed, agility, and reliability. This bionic robot design offers a new solution for tasks in exploration, surveillance, and material handling, demonstrating the value of learning from nature. The development of such bionic robots paves the way for more adaptive and resilient machines in the future. As we continue to refine this bionic robot, we aim to push the boundaries of what bionic robots can achieve, inspired by the remarkable capabilities of beetles and other organisms.
The mathematical models and equations presented here provide a foundation for analyzing and optimizing bionic robot designs. For instance, the kinematics of the lifting mechanism can be extended to dynamic simulations using software tools. The control strategies can be adapted for other types of bionic robots, such as those inspired by different insects or animals. The bionic robot’s modular architecture allows for easy upgrades and modifications, making it a versatile platform for research. We believe that this bionic robot will inspire further innovations in the field, encouraging more interdisciplinary work between biology and engineering.
Ultimately, the success of this bionic robot project underscores the importance of biomimicry in solving engineering challenges. By emulating the beetle’s traits, we have created a machine that is not only functional but also efficient and robust. The bionic robot’s ability to navigate complex environments and perform delicate manipulations opens up numerous practical applications. As bionic robot technology advances, we anticipate seeing more such designs in industry, healthcare, and environmental monitoring. This bionic robot is a step toward a future where machines seamlessly integrate with natural systems, enhancing our capabilities while respecting biological principles.