
In the field of high-precision robotics, the rotary vector reducer has emerged as a critical component due to its compact design, high transmission ratio, and excellent load-bearing capacity. As a two-stage enclosed planetary gear mechanism, the rotary vector reducer combines a high-speed involute planetary gear set with a low-speed cycloidal pin gear transmission, offering advantages such as minimal backlash, high efficiency, and smooth operation. However, torsional stiffness remains a pivotal performance metric, as insufficient stiffness can lead to chatter, reduced load capacity, and positional inaccuracies in robotic end-effectors. This study focuses on analyzing the torsional stiffness and hysteresis of a rotary vector reducer through finite element methods, aiming to provide a reliable simulation framework for design optimization.
We begin by establishing a parametric finite element model of a specific rotary vector reducer using APDL (ANSYS Parametric Design Language). The model incorporates detailed gear geometries, including the cycloidal and planetary gears, to capture meshing stiffness accurately. Additionally, it accounts for the elasticity of all components and the stiffness of bearings, particularly the crank bearings, which significantly influence overall torsional behavior. The finite element model is built with hexahedral elements to enhance accuracy, as opposed to tetrahedral meshes that may reduce precision. The assembly comprises 158 solid parts, with 1,227,915 nodes and 1,006,668 elements, ensuring a comprehensive representation of the rotary vector reducer’s mechanical system.
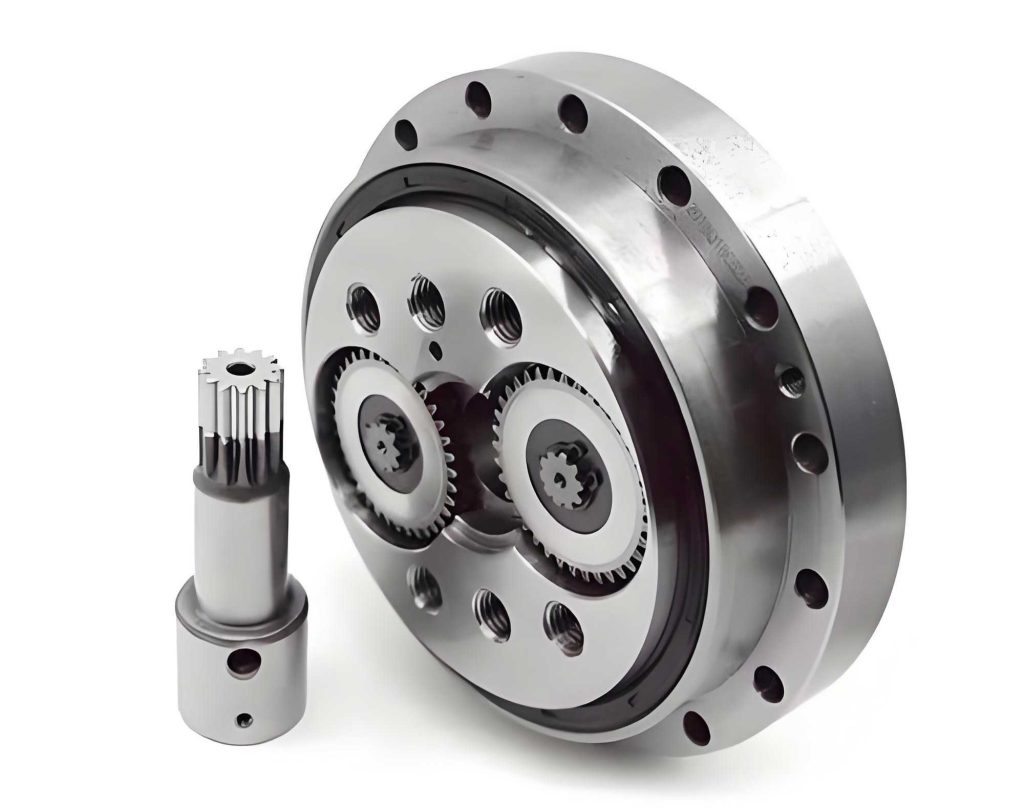
The rotary vector reducer operates through a dual-stage process: the first stage involves an input sun gear driving three planetary gears at 120-degree intervals for initial speed reduction, while the second stage uses cycloidal gears meshing with pin gears to achieve further reduction and output via a planetary frame. In our analysis, we assume the sun gear rotates counterclockwise, driving the planetary gears clockwise, which in turn actuate the cycloidal gears through crank shafts. The cycloidal gears undergo eccentric motion, leading to reverse rotation transmitted to the output. To improve performance, we apply comprehensive modifications to the cycloidal gears, including isometric and shift corrections, which enhance load distribution and reduce backlash. These modifications are derived from design handbooks and algorithms that ensure strength, precision, and backlash below 1 arcminute.
Key parameters of the rotary vector reducer are summarized in Table 1. This includes input power, output torque, gear specifications, and modification values. The materials used, such as GCr15 for most components and 20CrMnTi for gears, are detailed in Table 2, with their density and elastic modulus provided. These parameters form the basis for our finite element analysis, ensuring that the model reflects real-world conditions accurately.
| Parameter | Value |
|---|---|
| Input Power (kW) | 1.64 |
| Output Torque (N·m) | 784 |
| Output Speed (r/min) | 15 |
| Pin Gear Center Circle Diameter (mm) | 154 |
| Pin Gear Diameter (mm) | 7 |
| Pin Gear Hole Diameter (mm) | 7.008 |
| Eccentricity (mm) | 1.5 |
| Number of Cycloidal Gear Teeth | 39 |
| Isometric Modification (mm) | -0.042 |
| Shift Modification (mm) | -0.047 |
| Material | Density (kg/m³) | Elastic Modulus (MPa) |
|---|---|---|
| GCr15 | 7,830 | 2.19 × 10⁵ |
| 20CrMnTi | 7,860 | 2.12 × 10⁵ |
| QT450 | 7,060 | 1.69 × 10⁵ |
In the finite element model, we apply boundary conditions and loads to simulate operational scenarios. The sun gear is fixed to represent a stationary input, while the planetary gears and crank shafts are constrained axially, with other degrees of freedom managed through contacts. Bearings, including the crank bearings, are constrained axially and circumferentially using local cylindrical coordinate systems to mimic real constraints. The cycloidal gears are only axially constrained, allowing meshing interactions to dictate motion. The planetary frame is represented by a MASS21 point element fixed in place. A torque load of -784 N·m is applied to the pin gear housing, converted into circumferential forces distributed across nodes to simulate output resistance at 15 r/min.
Contact pairs are defined using surface-to-surface “flexible-flexible” contact, with TARGE170 and CONTA174 elements. Seven contact pairs are established: cycloidal gear teeth with pin gears (two pairs), cycloidal gear bearing holes with crank bearings (two pairs), crank shaft eccentric surfaces with bearings (two pairs), and planetary gears with the sun gear (one pair). The contact stiffness FKN is set to 2, and the maximum penetration FTOLN is 0.01, ensuring realistic interaction without excessive penetration. This setup allows the rotary vector reducer model to accurately capture deformation under load, which is crucial for torsional stiffness analysis.
Torsional stiffness of the rotary vector reducer is calculated as the ratio of applied torque to the angular deflection of the output component. Since gaps such as gear backlash and bearing clearance affect measurements, we exclude these by using incremental steps. The formula for torsional stiffness is modified as follows:
$$ \text{Torsional Stiffness} = \frac{T_{\text{rated}} – T_{\text{previous}}}{\theta_{\text{rated}} – \theta_{\text{previous}}} $$
where \( T_{\text{rated}} \) is the rated torque (784 N·m), \( T_{\text{previous}} \) is the torque from the previous load step, \( \theta_{\text{rated}} \) is the angular deflection under rated torque, and \( \theta_{\text{previous}} \) is the deflection from the previous step. Due to the time-varying nature of meshing stiffness and bearing compliance in the rotary vector reducer, torsional stiffness fluctuates with the engagement position of the cycloidal gears. We divide the cycloidal gear into 13 engagement zones (as shown in Figure 3 of the original text) and compute stiffness for each, with results summarized in Table 3.
| Engagement Position | Maximum Deflection (arcmin) | Torsional Stiffness (N·m/arcmin) |
|---|---|---|
| 1 | 3.463 | 256.2 |
| 2 | 3.573 | 247.1 |
| 3 | 3.554 | 248.6 |
| 4 | 3.349 | 265.8 |
| 5 | 3.212 | 278.8 |
| 6 | 3.289 | 271.4 |
| 7 | 3.350 | 265.8 |
| 8 | 3.564 | 247.8 |
| 9 | 3.563 | 247.9 |
| 10 | 3.487 | 254.0 |
| 11 | 3.229 | 277.1 |
| 12 | 3.367 | 265.2 |
| 13 | 3.384 | 262.7 |
The torsional stiffness varies sinusoidally with engagement position, as illustrated in Figure 4 of the original text. The maximum stiffness of 278.8 N·m/arcmin occurs at position 5, while the minimum of 247.1 N·m/arcmin occurs at position 2, yielding an average stiffness of 260.65 N·m/arcmin. This variation highlights the dynamic behavior of the rotary vector reducer under load, emphasizing the importance of considering multiple engagement points in design.
Backlash, or hysteresis, in the rotary vector reducer refers to the lag in output motion when the input direction is reversed. It arises from geometric tolerances, thermal effects, and elastic deformation. According to Nabtesco Corporation, backlash is defined as the torsional deformation under ±0.03T loading. For symmetric engagement positions, such as position 1, forward and reverse deformations are equal. For asymmetric positions, backlash is calculated using the formula:
$$ \phi_i = \frac{0.03T}{k_i} + \frac{0.03T}{k_{15-i}} $$
where \( \phi_i \) is the backlash at engagement position \( i \), \( T \) is the rated torque, and \( k_i \) is the torsional stiffness at position \( i \). The computed backlash values are listed in Table 4, resulting in a range of 0.173 to 0.185 arcminutes for the rotary vector reducer.
| Engagement Position | Backlash (arcmin) | Engagement Position | Backlash (arcmin) |
|---|---|---|---|
| 1 | 0.214 | 2, 13 | 0.215 |
| 3, 12 | 0.213 | 4, 11 | 0.213 |
| 5, 10 | 0.217 | 6, 9 | 0.211 |
| 7, 8 | 0.213 |
To validate our finite element analysis, we conducted experimental tests on a rotary vector reducer of the same model. The experimental setup involved fixing the input shaft and applying torque to the output via a loading device, with angular deflection measured using a grating ruler. The hysteresis curve from the experiment is shown in Figure 6 of the original text, and data points are summarized in Table 5. By excluding points affected by gaps, we derived an average experimental torsional stiffness of 232.37 N·m/arcmin, with a maximum of 274.4 N·m/arcmin and a minimum of 196 N·m/arcmin. The experimental backlash was measured as 0.233 arcminutes.
| Load (kg) | Torque (N·m) | Deflection (arcsec) | Load (kg) | Torque (N·m) | Deflection (arcsec) |
|---|---|---|---|---|---|
| 0 | 0 | 0 | 3.6 | 24.7 | 14 |
| 5 | 34.3 | 30 | 15 | 102.9 | 68 |
| 35 | 240.1 | 120 | 55 | 377.3 | 167 |
| 75 | 514.5 | 210 | 95 | 651.7 | 250 |
| 115 | 788.9 | 291 | 95 | 651.7 | 261 |
| 75 | 514.5 | 228 | 55 | 377.3 | 187 |
| 35 | 240.1 | 144 | 15 | 102.9 | 95 |
| 5 | 34.3 | 63 | 3.5 | 24.7 | 46 |
| 0 | 0 | 37 | -3.6 | -24.7 | 27 |
| -5 | -34.3 | -4 | -15 | -102.9 | -47 |
| -35 | -240.1 | -92 | -55 | -377.3 | -132 |
| -75 | -514.5 | -164 | -95 | -651.7 | -200 |
| -115 | -788.9 | -242 | -95 | -651.7 | -211 |
| -75 | -514.5 | -180 | -55 | -377.3 | -146 |
| -35 | -240.1 | -110 | -15 | -102.9 | -67 |
| -5 | -34.3 | -42 | -3.5 | -24.7 | -26 |
| 0 | 0 | -18 |
A comparison between finite element results and experimental data is presented in Table 6. The finite element analysis overestimates average torsional stiffness by 10.85% (260.65 vs. 232.37 N·m/arcmin) and underestimates backlash by 8.9% (0.214 vs. 0.233 arcmin). This discrepancy is attributed to simplifications in our model, such as omitting the planetary frame and tapered roller bearings that connect it to the crank shafts. Despite these differences, the trends and patterns align closely, demonstrating that finite element methods are a viable tool for simulating torsional behavior in rotary vector reducers.
| Metric | Finite Element Method | Experimental Method | Deviation |
|---|---|---|---|
| Torsional Stiffness (N·m/arcmin) | 260.65 | 232.37 | 10.85% |
| Backlash (arcmin) | 0.214 | 0.233 | 8.9% |
Our analysis reveals that the rotary vector reducer exhibits time-varying torsional stiffness due to cyclical changes in gear meshing and bearing compliance. The stiffness fluctuates between 247.1 and 278.8 N·m/arcmin, with an average of 260.65 N·m/arcmin, while backlash ranges from 0.173 to 0.185 arcminutes. These findings underscore the importance of considering dynamic effects in the design of rotary vector reducers for robotics applications. The finite element model, despite slight overestimations, provides a robust framework for predicting performance, and future work could incorporate additional components like the planetary frame to improve accuracy.
In conclusion, the rotary vector reducer is a complex system where torsional stiffness and hysteresis are critical for precision. Through detailed finite element modeling and experimental validation, we have shown that simulation techniques can effectively capture these properties, offering valuable insights for optimizing the rotary vector reducer in high-demand environments. As robotics technology advances, continued refinement of such models will enhance the reliability and efficiency of rotary vector reducers, supporting their widespread adoption in industrial automation.