
In my work as a vocational technical educator, I have watched the mechanical trades change from mostly manual and conventional machine-based tasks into hybrid roles that combine mechanical knowledge with automation, data, and industrial robot operation. I no longer treat the industrial robot as a separate specialization that only a few advanced students should study. Instead, I design mechanical courses so that every learner meets the industrial robot as a natural extension of mechanisms, transmissions, fixtures, sensors, control, and production systems. The purpose of this article is to present my design for integrating an industrial robot fundamentals module into mechanical courses in a vocational technical college. I explain why this integration is necessary, how I structure goals and principles, how I rebuild curriculum content, how I use project-driven and layered teaching, how I organize practical training, how I assess learning, and how I improve the design over time.
The central argument is simple: mechanical competence alone is no longer enough for modern manufacturing. An industrial robot is not a replacement for mechanical understanding; it is a demanding application of that understanding. When students learn mechanical drawing, tolerance analysis, mechanism design, fixture clamping, pneumatic actuation, and machine maintenance alongside industrial robot programming and commissioning, they become more adaptable, more employable, and more capable of improving production systems. I use formulas, tables, and structured design rules to make this integration explicit rather than accidental.
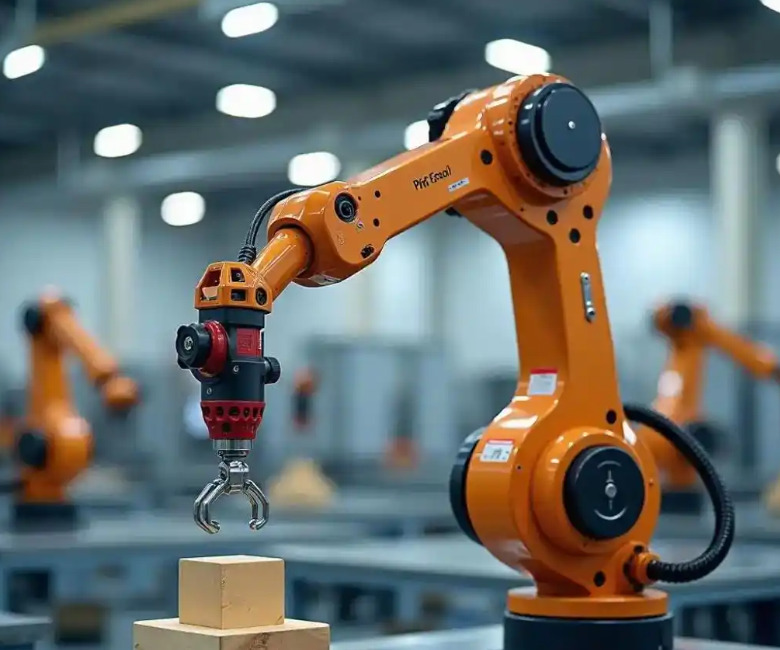
1. Why I Integrate Industrial Robot Fundamentals into Mechanical Courses
My first reason is industry demand. Manufacturing companies in automotive parts, electronics assembly, food processing, logistics, and general machining increasingly use an industrial robot for picking, placing, machine tending, welding, painting, palletizing, and inspection. These companies still need mechanical technicians who understand bearings, gears, belts, cams, linkages, hydraulic and pneumatic circuits, alignment, and preventive maintenance. However, they also need technicians who can safely jog an industrial robot, verify a tool center point, adjust a program, diagnose a gripper fault, and coordinate an industrial robot with a machine tool or conveyor.
I describe this shift with a simple productivity relationship. If a process produces \(Q\) good units in time \(T\), then productivity \(P\) is:
$$P = \frac{Q}{T}$$
An industrial robot can increase \(Q\) by reducing cycle time, improving repeatability, and allowing longer operating hours. It can also improve quality by reducing variation. Overall equipment effectiveness is often summarized as:
$$OEE = A \times P \times Q$$
where \(A\) is availability, \(P\) is performance, and \(Q\) is quality. In my teaching, I use this formula to show that an industrial robot affects all three factors. If the industrial robot is poorly maintained, availability falls. If the industrial robot program has unnecessary waiting points, performance falls. If the industrial robot gripper damages parts, quality falls. Mechanical students must therefore learn the industrial robot not as a black box but as an integrated machine within a production system.
| Industry role | Mechanical knowledge required | Industrial robot knowledge required | Typical task |
|---|---|---|---|
| Machine tending technician | Fixture design, chuck and vise operation, tool wear, coolant flow | Industrial robot teaching, safe door interlock, tool center point verification | Load and unload a CNC machine with an industrial robot |
| Automation line maintainer | Conveyor alignment, bearing replacement, pneumatic circuit repair | Industrial robot fault codes, I/O mapping, program backup | Restore a stopped line after an industrial robot gripper failure |
| Industrial robot cell operator | Part presentation, fixture clamping, tolerance inspection | Industrial robot jogging, program selection, emergency stop recovery | Run a welding or palletizing cell safely |
| Integration assistant | Workcell layout, guarding, fastener selection, cable routing | Industrial robot offline programming, calibration, fieldbus setup | Assist in commissioning a new industrial robot workstation |
| Quality technician | Measurement, geometric tolerance, statistical process control | Industrial robot repeatability testing, vision inspection handshake | Verify part quality after an industrial robot operation |
The second reason is student competitiveness. In my experience, students who understand only conventional mechanical operations can still find jobs, but their career paths are narrower. Students who can combine mechanical skills with industrial robot fundamentals can apply for machine tending, automated assembly, industrial robot maintenance, workcell operation, and production support roles. They also have a stronger foundation for further study in industrial robot programming, vision systems, and smart manufacturing. The industrial robot becomes a bridge between mechanical trades and advanced automation.
I represent the desired competence profile as a weighted vector:
$$C_{total} = w_m C_m + w_r C_r + w_i C_i + w_s C_s$$
where \(C_m\) is mechanical competence, \(C_r\) is industrial robot competence, \(C_i\) is integration competence, \(C_s\) is safety and communication competence, and the weights satisfy:
$$\sum_{j} w_j = 1,\quad w_j \ge 0$$
In my current design, I use \(w_m = 0.35\), \(w_r = 0.30\), \(w_i = 0.20\), and \(w_s = 0.15\). These weights can be adjusted by local industry needs, but they force me to avoid treating the industrial robot module as an optional appendix. It becomes a measurable part of the mechanical program.
2. Design Goals and Principles
I set goals before I write any lesson plan. The first goal is job alignment. The integrated course must reflect real tasks performed by mechanical technicians who work near or with an industrial robot. The second goal is knowledge coherence. Mechanical theory and industrial robot fundamentals must connect through shared concepts such as motion, force, tolerance, control, and safety. The third goal is skill progression. Students should move from recognition to guided operation, then to independent programming and troubleshooting. The fourth goal is safety. Every industrial robot activity must begin with risk awareness and end with safe shutdown. The fifth goal is adaptability. The design must be modular enough to accept new industrial robot models, controllers, and software.
| Design goal | Implementation principle | Indicator I use |
|---|---|---|
| Job alignment | Map every module to at least one industrial robot-related task | Percentage of learning outcomes verified by industry partners |
| Knowledge coherence | Teach mechanical and industrial robot concepts in pairs | Number of shared concept links in the curriculum map |
| Skill progression | Use a spiral sequence from observation to independent operation | Student performance level on a four-stage rubric |
| Safety | Integrate risk assessment into every practical task | Zero unsafe acts and complete safety logs |
| Adaptability | Separate core concepts from vendor-specific procedures | Time required to update a module for a new industrial robot |
| Reflection | Require students to document errors and corrections | Quality of maintenance and debugging journals |
I use three curriculum equations to guide sequencing. The first is a prerequisite relation:
$$M_1 \prec M_2 \prec M_3 \prec \cdots \prec M_n$$
This means module \(M_1\) must be completed before \(M_2\), and so on. For example, mechanical safety and measurement come before industrial robot jogging. Industrial robot jogging comes before industrial robot programming. Industrial robot programming comes before industrial robot and machine tool integration. The second equation is a time allocation balance:
$$T_{total} = T_{theory} + T_{practice} + T_{project} + T_{assessment}$$
In my design, \(T_{practice}\) and \(T_{project}\) together should be at least sixty percent of the total time. The third equation is a competence growth target:
$$\Delta C = C_{post} – C_{pre} \ge C_{target}$$
I measure \(C_{pre}\) at the beginning of the module and \(C_{post}\) at the end. I want the gain \(\Delta C\) to be positive for every student, while the absolute target \(C_{target}\) may differ by layer.
3. Rebuilding the Curriculum Architecture
I do not simply add a new industrial robot course beside the existing mechanical courses. That approach creates timetable pressure and leaves students unable to connect the two subjects. Instead, I reconstruct the mechanical curriculum by identifying natural intersection points. Mechanical drawing becomes workcell layout and industrial robot reach envelope drawing. Tolerance analysis becomes industrial robot repeatability and path accuracy. Mechanism study becomes joint transmission and end effector design. CNC operation becomes industrial robot machine tending. Pneumatics becomes gripper control. Electrical control becomes industrial robot I/O and safety interlock. Maintenance becomes industrial robot preventive maintenance and troubleshooting.
| Mechanical course topic | Industrial robot integration point | Shared concept | Practical task |
|---|---|---|---|
| Mechanical drawing | Workcell layout, industrial robot reach envelope, tool drawing | Coordinate systems, dimensions, projection | Draw a top view of an industrial robot workstation |
| Tolerance and measurement | Industrial robot repeatability, path accuracy, calibration | Variation, datum, uncertainty | Measure industrial robot positioning error at ten points |
| Mechanisms and transmissions | Industrial robot joints, harmonic drive, cycloidal drive, belts | Ratio, torque, speed, backlash | Compare a gearbox and an industrial robot joint reducer |
| CNC machining | Industrial robot machine tending, automatic door, chuck signal | Cycle time, interlock, sequencing | Program an industrial robot to load and unload a CNC machine |
| Pneumatics and hydraulics | Industrial robot end effector, vacuum gripper, pneumatic clamp | Pressure, force, flow, response time | Build and test a pneumatic gripper circuit for an industrial robot |
| Electrical control | Industrial robot controller I/O, safety relay, fieldbus | Signal, logic, grounding, noise | Wire an industrial robot start and stop signal to a PLC |
| Machine maintenance | Industrial robot preventive maintenance, battery, grease, belt tension | Wear, lubrication, alignment | Create an industrial robot maintenance checklist |
| Production organization | Industrial robot cell cycle balancing, takt time, buffer size | Flow, capacity, bottleneck | Balance a two-machine industrial robot cell |
I organize the integrated curriculum into a sixteen-week semester framework. The first four weeks establish mechanical and safety foundations. The next four weeks introduce industrial robot structure, coordinates, and manual operation. The following four weeks focus on programming, end effectors, and simple integration. The final four weeks use a project to combine mechanical fixtures, industrial robot programs, sensors, and production requirements.
| Week | Mechanical focus | Industrial robot focus | Assessment evidence |
|---|---|---|---|
| 1 | Safety, measurement, hand tools | Industrial robot safety zones, emergency stop, safe approach | Safety quiz and safe shutdown demonstration |
| 2 | Mechanical drawing and coordinate systems | Industrial robot coordinate frames, world, base, tool, user | Coordinate frame worksheet |
| 3 | Fixtures, clamping, locating principles | Industrial robot gripper types and part presentation | Fixture sketch and gripper selection report |
| 4 | Transmission, bearings, backlash | Industrial robot joints and reducers | Joint transmission comparison table |
| 5 | Pneumatics and actuators | Industrial robot end effector control | Pneumatic circuit simulation |
| 6 | Electrical signals and sensors | Industrial robot digital I/O and sensor handshake | I/O mapping diagram |
| 7 | CNC workholding and cycle time | Industrial robot machine tending sequence | Sequence flowchart |
| 8 | Midterm mechanical task | Midterm industrial robot jogging and teaching task | Practical midterm rubric |
| 9 | Path planning and motion | Industrial robot linear, joint, and circular motion | Motion type comparison log |
| 10 | Tolerance and variation | Industrial robot repeatability and accuracy test | Measurement data and control chart |
| 11 | Mechanism synthesis | Industrial robot tool center point calibration | Calibration record |
| 12 | Maintenance planning | Industrial robot preventive maintenance | Maintenance checklist and spare parts list |
| 13 | Project planning | Industrial robot cell task definition | Project proposal |
| 14 | Fixture fabrication and assembly | Industrial robot program drafting | Fixture and program review |
| 15 | Integration and debugging | Industrial robot and machine coordination | Commissioning log |
| 16 | Presentation and reflection | Industrial robot cell demonstration | Final project defense |
4. Specific Content Integration Strategies
I use a content mapping matrix to ensure that every industrial robot fundamental has a mechanical anchor. The matrix prevents the industrial robot module from becoming a list of controller button exercises. It also prevents mechanical content from ignoring automation. I write the matrix with three columns: mechanical concept, industrial robot concept, and integrated task. Then I add an equation or quantitative check to each row.
| Integrated topic | Mechanical concept | Industrial robot concept | Quantitative check |
|---|---|---|---|
| Workcell layout | Machine footprint, operator clearance, service access | Reach envelope, payload, mounting orientation | $$D = \sqrt{(x_2-x_1)^2+(y_2-y_1)^2+(z_2-z_1)^2}$$ |
| End effector design | Clamping force, friction, center of gravity | Tool center point, payload limit, inertia | $$F_f = \mu N \ge m g$$ |
| Joint transmission | Gear ratio, backlash, bearing load | Servo motor torque, reducer efficiency | $$\tau_{out} = \eta i \tau_{in}$$ |
| Path accuracy | Guideway error, thermal expansion | Repeatability, absolute accuracy, calibration | $$\sigma = \sqrt{\frac{1}{N}\sum_{i=1}^{N}(x_i-\bar{x})^2}$$ |
| Cycle time | Clamping time, machining time, unloading time | Industrial robot motion time, wait time, handshake time | $$T_{cycle} = \sum_{i=1}^{n}(t_{pick,i}+t_{move,i}+t_{place,i})$$ |
| Safety interlock | Guard door, light curtain, lockout | Industrial robot protective stop, emergency stop, reduced mode | $$RPN = S \times O \times D$$ |
| Preventive maintenance | Lubrication interval, belt tension, bolt torque | Industrial robot battery, grease, encoder, fan filter | $$MTBF = \frac{T_{operating}}{N_{failures}}$$ |
| Production quality | Datum, fixture repeatability, surface finish | Industrial robot path consistency, vision inspection | $$C_{pk} = \min\left(\frac{USL-\mu}{3\sigma},\frac{\mu-LSL}{3\sigma}\right)$$ |
When I teach mechanical transmission, I introduce the industrial robot joint as a compact, high-ratio, low-backlash transmission problem. I compare a conventional gearbox with a harmonic reducer and a cycloidal reducer. Students calculate output torque and speed using:
$$\omega_{out} = \frac{\omega_{in}}{i}$$
$$\tau_{out} = \eta i \tau_{in}$$
Then they inspect a real industrial robot axis, observe backlash by moving the tool, and discuss why backlash matters for path accuracy. I ask them to relate the industrial robot repeatability specification to the mechanical quality of the joint and the control system.
When I teach fixtures and clamping, I connect the mechanical clamp to the industrial robot gripper. Students calculate the required friction force to hold a part:
$$F_f = \mu N$$
For a part of mass \(m\), the vertical holding condition is:
$$F_f \ge m g$$
Then they consider acceleration and safety factor:
$$F_f \ge S_f m (g + a)$$
where \(S_f\) is a safety factor. This calculation makes the industrial robot payload and gripper selection concrete. It also shows why center of gravity and moment load matter. Students learn that an industrial robot can fail a task not because the controller is wrong but because the end effector cannot hold the part rigidly.
When I teach CNC machine tending, I use a sequence model. The industrial robot must wait for the machine door to open, the chuck to release, the part to be clear, and the safety signal to be valid. I represent the sequence as a state set:
$$S = \{S_0, S_1, S_2, \ldots, S_n\}$$
and a transition relation:
$$S_i \xrightarrow{c_i} S_{i+1}$$
where \(c_i\) is the condition for transition. Students draw the sequence, program the industrial robot, and test the handshake with a PLC or machine simulator. This directly combines mechanical workholding knowledge with industrial robot programming.
5. Project-Driven Teaching and Learning
I rely on project-driven teaching because it forces students to use mechanical and industrial robot knowledge together. A traditional lecture followed by a separate laboratory exercise often leaves students unable to transfer knowledge. A project gives them a reason to calculate, draw, build, program, test, and improve. I choose projects that are small enough to finish but rich enough to require integration.
| Project | Mechanical task | Industrial robot task | Integrated deliverable |
|---|---|---|---|
| Part picking and placing | Design a simple nest and stop | Teach pick and place points, set tool center point | Working cell with cycle time log |
| CNC machine tending | Design a drawer or tray for raw and finished parts | Program door, chuck, and industrial robot handshake | Sequence diagram and safe demonstration |
| Pneumatic sorting | Select cylinder, gripper, and mounting bracket | Program industrial robot pick, sensor check, and place | Sorting station with count and reject logic |
| Palletizing | Design a pallet pattern and layer support | Program industrial robot paths for multiple layers | Stable pallet and optimized path |
| Welding positioner | Design a fixture for repeatable joint location | Program industrial robot welding path and safe approach | Welding cell plan and quality check |
| Vision inspection | Design part presentation and lighting bracket | Interface industrial robot with camera and reject output | Inspection report with pass and fail counts |
| Maintenance and troubleshooting | Create a mechanical fault list and spare parts map | Create industrial robot alarm and recovery guide | Combined troubleshooting manual |
I use a project scoring formula that balances product, process, safety, and reflection:
$$S_{project} = 0.25 S_{design} + 0.30 S_{program} + 0.25 S_{debug} + 0.10 S_{safety} + 0.10 S_{documentation}$$
Each term is scored from zero to one hundred. I require students to record cycle time, success rate, and defect count. The success rate is:
$$R_{robot} = \frac{N_{success}}{N_{total}} \times 100\%$$
They also calculate an improvement ratio before and after debugging:
$$\eta_{improve} = \frac{T_{before} – T_{after}}{T_{before}} \times 100\%$$
This makes the project quantitative. Students cannot simply say that their industrial robot program works; they must show how well it works and how they improved it.
I also use a layered teaching model. Vocational technical students enter with different backgrounds. Some have strong mechanical skills but little exposure to an industrial robot. Some have seen an industrial robot at a competition or family workplace but lack mechanical theory. Some are ready for advanced integration. I therefore define three layers and allow movement between them based on evidence.
| Layer | Student profile | Mechanical content | Industrial robot content | Assessment target |
|---|---|---|---|---|
| Foundation | Needs support in measurement, tools, and safety | Basic drawing, hand tools, fasteners, clamping | Industrial robot safety, power up, jog, simple point teaching | Safe operation and accurate point recording |
| Development | Can complete guided mechanical tasks | Fixture design, pneumatic circuits, tolerance checks | Industrial robot programming, tool center point, I/O handshake | Independent cell task with troubleshooting log |
| Extension | Ready for open-ended problems | Workcell layout, cycle balancing, maintenance plan | Industrial robot offline programming, multi-device coordination, optimization | Improved cell design with measured performance |
I do not label students permanently. The layer is a design variable, not a rank. A student can begin in Foundation and move to Development after demonstrating safe operation and basic programming. This is consistent with my view that the industrial robot module should widen opportunity, not create a new barrier.
6. Practical Teaching Environment and Safety
The practical environment determines whether integration succeeds. I need more than a computer lab and a few videos. I need an industrial robot workstation that can be configured for picking, machine tending, and simple assembly. I also need mechanical benches, fixture plates, sensors, pneumatic components, and safe guarding. The workstation should be modular so that students can change grippers, part nests, and sensor positions.
| Equipment or resource | Purpose | Safety requirement | Integration with mechanical course |
|---|---|---|---|
| Industrial robot arm with controller | Teaching, programming, operation | Emergency stop, protective stop, limit space | Joint structure, transmission, coordinate frames |
| Modular fixture plate | Part location and clamping | Deburred edges, secure mounting | Locating principles, tolerance, fastener torque |
| Pneumatic gripper set | Part handling | Pressure limit, hose protection, pinch points | Force calculation, circuit design, actuator selection |
| Safety guard and interlock | Human protection | ISO 10218 and ISO/TS 15066 principles | Machine guarding, lockout, risk assessment |
| PLC or industrial controller | Handshake and sequencing | Grounding, fuse protection, signal isolation | Electrical control, logic, I/O mapping |
| Vision sensor or camera | Inspection and guidance | Light safety, calibration checks | Measurement, datum, quality control |
| CNC or machine simulator | Machine tending practice | Door interlock, chuck guard, safe clearances | Workholding, cycle time, tool change |
| Digital twin software | Offline layout and path planning | Simulation validation before real motion | Workcell drawing, reach study, collision check |
I use risk assessment before every new project. The risk priority number is:
$$RPN = S \times O \times D$$
where \(S\) is severity, \(O\) is occurrence, and \(D\) is detection. Students rank each hazard and propose controls. For an industrial robot cell, common hazards include crushing between the industrial robot and fixture, impact from a released part, pneumatic pressure injection, electrical shock, and tripping over cables. I require students to reduce \(RPN\) by engineering controls first, then administrative controls, and only then personal protective equipment. This order matters because an industrial robot moves quickly and can cause serious injury.
I also teach a safe start-up and shutdown procedure. A typical checklist is:
| Step | Action | Verification |
|---|---|---|
| 1 | Inspect the industrial robot cell for people and loose objects | Visual scan and callout |
| 2 | Check guard doors, light curtains, and emergency stops | Function test |
| 3 | Verify air pressure and electrical supply | Gauge and indicator check |
| 4 | Power the controller and wait for self-test | No alarm on teach pendant |
| 5 | Jog the industrial robot at low speed in a clear area | Confirm coordinate frame and tool |
| 6 | Run the program in step mode | Observe each motion and handshake |
| 7 | Switch to automatic mode only after validation | Supervisor approval |
| 8 | Shut down, unload tools, and record the session | Maintenance and safety log |
I connect safety to mechanical design. For example, if a student designs a fixture that requires the operator to reach into the industrial robot workspace, the design is unacceptable. The student must redesign the fixture or add a load station outside the guarded area. This teaches that mechanical design and industrial robot safety are not separate topics. A good mechanical layout reduces risk before software limits are considered.
7. Assessment and Evaluation
I assess integrated learning with multiple instruments. A written test can check knowledge of coordinate frames, transmission ratios, and safety rules, but it cannot confirm that a student can safely jog an industrial robot or diagnose a gripper fault. Therefore, I combine theory, practical performance, project work, and reflective documentation. I use the following weighting:
$$S_{student} = 0.20 S_{theory} + 0.30 S_{project} + 0.35 S_{practice} + 0.15 S_{reflection}$$
Each component is scored from zero to one hundred. The practical component includes a checklist for safety, tool center point setup, program editing, and recovery from a fault. The project component includes fixture quality, industrial robot path efficiency, cycle time, and documentation. The reflection component includes a maintenance journal, error analysis, and improvement proposal.
| Learning outcome | Assessment method | Evidence | Weight |
|---|---|---|---|
| Explain mechanical and industrial robot motion concepts | Written test and oral defense | Calculations and diagrams | 20% |
| Safely operate an industrial robot | Practical checklist | Observed safe start, jog, stop, and recovery | 15% |
| Design a fixture or end effector | Design review | Drawing, force calculation, bill of materials | 15% |
| Program an industrial robot task | Project demonstration | Working program and cycle time log | 20% |
| Integrate industrial robot with machine or sensor | Commissioning test | I/O map, handshake sequence, fault recovery | 15% |
| Reflect and improve | Portfolio and journal | Error log, revised program, maintenance plan | 15% |
I use a competence matrix to track progress. Each row is a skill, and each column is a performance level. The levels are: awareness, guided performance, independent performance, and improvement. I convert the levels to numbers for analysis:
$$L = \{0, 1, 2, 3\}$$
Then I calculate an average competence index for the class:
$$\bar{L} = \frac{1}{N}\sum_{i=1}^{N} L_i$$
I also calculate the standard deviation to see whether the integration design is helping all students or only a few:
$$\sigma_L = \sqrt{\frac{1}{N}\sum_{i=1}^{N}(L_i-\bar{L})^2}$$
If \(\sigma_L\) is high, I adjust the layered teaching tasks. If \(\bar{L}\) is low, I review the difficulty and the amount of guided practice. If both are acceptable, I continue to the next project. This use of data keeps the integration design honest.
8. Implementation Challenges and Responses
I face several challenges when I integrate an industrial robot fundamentals module into mechanical courses. The first is teacher capability. Some mechanical teachers have deep experience with conventional machines but limited experience with an industrial robot. The second is equipment cost. An industrial robot workstation is expensive, and a school may not be able to buy many units. The third is safety. Moving machinery creates real risk, and administrators may hesitate. The fourth is timetable pressure. Mechanical courses are already full. The fifth is assessment. Traditional exams do not capture integration skills well.
| Challenge | Effect | Response I use | Measure of success |
|---|---|---|---|
| Teacher capability gap | Less confident teaching of industrial robot concepts | Pair mechanical and automation teachers; industry shadowing; micro-teaching | Number of co-taught modules and teacher confidence survey |
| High equipment cost | Limited student access to an industrial robot | Use simulation, digital twin, and rotation stations; share with other programs | Student hands-on hours per semester |
| Safety concerns | Reluctance to allow independent operation | Risk assessment, guarded cells, step-mode operation, supervisor check | Incident rate and near-miss reports |
| Timetable pressure | Integration seen as an extra subject | Embed industrial robot tasks into existing mechanical units | Number of mechanical outcomes taught with industrial robot context |
| Assessment mismatch | Project skills not reflected in grades | Rubrics, checklists, portfolios, practical defense | Correlation between rubric scores and industry feedback |
| Rapid technology change | Course content becomes outdated | Separate core concepts from vendor procedures; annual review | Time to update a module |
I also calculate a simple return on investment for the industrial robot workstation. The annual benefit includes improved student enrollment, reduced training time for employers, and potential service work. The annual cost includes maintenance, software, consumables, and teacher training. The return on investment is:
$$ROI = \frac{AnnualBenefit – AnnualCost}{InitialInvestment} \times 100\%$$
This formula helps me communicate with administrators. The industrial robot is not only a teaching tool; it is an investment in employability, industry partnership, and program reputation. When local employers hire my students and return for further training, the benefit becomes visible.
9. Continuous Improvement of the Integration Design
I use a plan-do-check-act cycle to improve the integrated course. In the plan stage, I review industry feedback, student performance, and equipment status. In the do stage, I teach the modules and collect evidence. In the check stage, I compare results with targets. In the act stage, I revise the curriculum map, project list, or assessment rubric. The cycle is:
$$PDCA = Plan \rightarrow Do \rightarrow Check \rightarrow Act \rightarrow Plan$$
I define key performance indicators for the integration design. These indicators include the percentage of students who safely operate an industrial robot, the percentage who complete an integrated project, the average cycle time improvement, the placement rate in automation-related roles, and the satisfaction of industry partners. I summarize them with a composite index:
$$KPI_{integration} = \frac{1}{m}\sum_{j=1}^{m} \frac{Actual_j}{Target_j}$$
If \(KPI_{integration} \ge 1\), the design is meeting its overall targets. If it is below one, I investigate the weakest indicator. This prevents me from relying on a single success story or a single excellent student project.
| KPI | Definition | Target | Data source |
|---|---|---|---|
| Safe operation rate | Students who pass the industrial robot safety checklist on the first attempt | 100% | Practical checklist |
| Project completion rate | Students who complete an integrated industrial robot project | 95% | Project records |
| Cycle time improvement | Average improvement from first run to final run | 20% | Program logs |
| Fault diagnosis score | Average score on industrial robot and mechanical fault tasks | 80 | Rubric |
| Industry satisfaction | Employer rating of student preparation | 4 out of 5 | Survey |
| Placement relevance | Graduates in roles that use mechanical and industrial robot skills | 70% | Follow-up data |
I also maintain an equipment and software review schedule. Every year I check whether the industrial robot controller, teach pendant, simulation software, and safety devices still match common industry practice. I do not change the entire course when a new model appears. Instead, I update the vendor-specific laboratory guide while keeping the core mechanical and industrial robot concepts stable. This is how I protect the curriculum from becoming obsolete without constant disruption.
10. Example Integrated Lesson Sequence
To make the design concrete, I describe a four-lesson sequence that I use for machine tending. The sequence assumes that students already know basic measurement, fixture principles, and safe industrial robot jogging.
| Lesson | Mechanical focus | Industrial robot focus | Student activity | Formula or check |
|---|---|---|---|---|
| 1 | Analyze the part, datum, and chuck jaws | Identify the industrial robot work envelope and safe approach | Sketch the cell and mark reach limits | $$D = \sqrt{(x_2-x_1)^2+(y_2-y_1)^2}$$ |
| 2 | Design a tray or nest for raw and finished parts | Teach pick and place points; set tool center point | Build a cardboard or modular nest and test access | $$F_f \ge S_f m(g+a)$$ |
| 3 | Define the machine door, chuck, and safety signals | Create the industrial robot and machine handshake program | Wire a simulator or PLC and test step mode | $$S_i \xrightarrow{c_i} S_{i+1}$$ |
| 4 | Measure cycle time and inspect part quality | Optimize motion and remove waiting points | Run ten cycles, record time, and improve the path | $$\eta_{improve} = \frac{T_{before}-T_{after}}{T_{before}} \times 100\%$$ |
After this sequence, students can explain why the mechanical nest must present the part within the industrial robot reach and at a repeatable position. They can also explain why the industrial robot program must wait for the machine safety signal. The integration is no longer theoretical. It is a set of calculations, decisions, and verified actions.
11. My Design Rules for Sustainable Integration
I summarize my design rules as follows. First, I anchor every industrial robot task in a mechanical concept. Second, I teach safety before motion. Third, I use simulation before real operation. Fourth, I require a fixture or end effector design for every handling project. Fifth, I assess process and reflection, not only the final product. Sixth, I use layered tasks so that all students can succeed. Seventh, I keep core concepts stable while updating vendor-specific procedures. Eighth, I collect quantitative evidence such as cycle time, success rate, and repeatability. Ninth, I invite industry feedback into the rubric. Tenth, I revise the design every year using the PDCA cycle.
| Design rule | Why it matters | Evidence I collect |
|---|---|---|
| Anchor industrial robot tasks in mechanical concepts | Prevents isolated button-pressing lessons | Curriculum map with paired concepts |
| Teach safety before motion | Reduces risk and builds professional habits | Safety checklist and risk assessment |
| Use simulation before real operation | Prevents collisions and saves equipment time | Digital twin files and collision reports |
| Require fixture or end effector design | Connects mechanical design to industrial robot handling | Drawings and force calculations |
| Assess process and reflection | Develops troubleshooting and improvement skills | Journals and revised programs |
| Use layered tasks | Supports diverse student backgrounds | Competence matrix and standard deviation |
| Keep core concepts stable | Reduces curriculum obsolescence | Annual review record |
| Collect quantitative evidence | Makes improvement measurable | Cycle time, success rate, repeatability data |
| Invite industry feedback | Keeps the course relevant | Employer survey and advisory notes |
| Revise with PDCA | Creates continuous improvement | KPI trend charts |
12. Conclusion
In my design, the industrial robot is not an extra topic added to an already crowded mechanical curriculum. It is a integrating technology that makes mechanical concepts more visible and more valuable. When students calculate gripper force, they understand clamping. When they set a tool center point, they understand coordinate systems. When they program a machine tending sequence, they understand workholding and interlock. When they measure industrial robot repeatability, they understand tolerance and variation. When they maintain an industrial robot, they understand bearings, reducers, batteries, and belts. The industrial robot becomes a powerful context for mechanical learning.
I have proposed goals, principles, a rebuilt curriculum architecture, content integration strategies, project-driven teaching, layered instruction, practical environment requirements, safety procedures, assessment methods, implementation responses, and continuous improvement metrics. The approach is intentionally quantitative. Formulas such as \(OEE = A \times P \times Q\), \(RPN = S \times O \times D\), and \(S_{student} = 0.20 S_{theory} + 0.30 S_{project} + 0.35 S_{practice} + 0.15 S_{reflection}\) help me judge whether the integration is working. Tables help me map every mechanical topic to an industrial robot application and every learning outcome to evidence.
The most important conclusion is that integration must be designed, not assumed. If I simply place an industrial robot in a laboratory and ask students to watch, the mechanical curriculum remains unchanged. If I redesign the curriculum so that mechanical knowledge and industrial robot fundamentals reinforce each other, students leave with a broader and deeper competence. They can operate, program, maintain, and improve automated cells. They can communicate with mechanical specialists, automation engineers, and production managers. They are better prepared for the industrial robot era of manufacturing.
I will continue to refine this design with student data, industry feedback, and equipment updates. My goal is not to turn every mechanical student into an industrial robot specialist. My goal is to ensure that every mechanical student can work safely and effectively with an industrial robot as part of a modern production system. That is the standard I set for my teaching, and it is the standard that industry increasingly expects.