
Humanoid robots demand high load capacity, high precision, and compact integration in their joint actuators. In this work, we investigate the influence of machining errors on the meshing behavior of an inverted recirculating planetary roller screw mechanism (IRPRSM), a promising transmission component for humanoid robot joint linear actuators. We develop unified three-body helical surface equations and a spatial meshing model that explicitly incorporate eccentricity error, pitch-diameter error, thread-angle error, and thread-start indexing error. The model provides closed-form expressions for the actual meshing position, meshing radius, deflection angle, and axial clearance under these errors. We analyze the sensitivity of each error type and show that eccentricity induces periodic fluctuations in meshing radius and axial clearance, with the fluctuation frequency increasing with the number of screw starts. Within ±0.03 mm of pitch-diameter error, the difference in axial clearance caused by screw and roller errors remains below 2 μm. When thread-angle errors occur separately in the screw or roller, the axial clearance reaches a peak of 24.58 μm at zero error and drops to roughly 10–12 μm at ±3°. When the thread-angle errors in the screw and roller vary equally in the same direction, the axial clearance changes only from 22.87 μm to 26.11 μm, indicating that synchronous error variations have a relatively mild effect. Thread-start indexing errors do not alter the axial contact position but redistribute the clearance between upper and lower helical flanks. These results provide a theoretical foundation for the manufacturing tolerance design, error-compensating assembly, and precision evaluation of IRPRSMs used in humanoid robot joint actuators.
1. Introduction
Humanoid robots perform walking, load manipulation, and dynamic balance through multiple joints that require high-frequency start/stop, reciprocating reversal, and accurate position output. The load capacity, transmission accuracy, and dynamic response of the joint actuator directly affect the overall motion stability and control performance. As a mechanical transmission device that can convert rotary motion into linear motion with high precision, the planetary roller screw mechanism (PRSM) offers superior load capacity, transmission accuracy, and long service life. It is therefore particularly suitable for the high-power-density, high-stiffness, and low-backlash linear actuation needed by humanoid robot joints. Compared with ball screws, the PRSM has a larger contact area and higher stiffness, which makes it attractive for the next generation of integrated joint actuators in humanoid robots. Several PRSM configurations exist, namely standard, inverted, and recirculating types. The inverted planetary roller screw mechanism (IPRSM) uses the nut rotation as input and the screw linear motion as output, and the nut can be integrated with the motor rotor. The recirculating planetary roller screw mechanism (RPRSM) is advantageous for small-lead transmission and cost-effective manufacturing. Combining the advantages of both configurations, an inverted recirculating planetary roller screw mechanism (IRPRSM) has recently been proposed. This new mechanism integrates the compactness of the inverted type with the small-lead characteristics of the recirculating type, offering a potential transmission solution for compact and high-precision linear actuators in humanoid robot joints.
Existing studies on PRSM mainly focus on kinematic modeling, structural parameter design, load distribution, meshing theory, and contact performance under ideal assembly conditions. However, most of these studies address conventional PRSM layouts, and research on the IRPRSM is still in its early stage. More importantly, machining errors are known to significantly affect the load distribution, stroke accuracy, and transmission precision of PRSM. Nevertheless, the conclusions derived for standard PRSMs cannot be directly transferred to IRPRSMs because of the unique geometry and meshing configuration of the latter. In the present work, we aim at revealing the mechanism by which typical machining errors affect the actual meshing state and axial clearance of the IRPRSM. Specifically, we:
- establish a unified three-body geometric model that considers eccentricity, pitch-diameter, thread-angle, and thread-start indexing errors for the screw–roller–nut system;
- derive analytical expressions for the actual meshing position and axial clearance based on parametric helical raceway geometry and spatial surface contact constraints;
- analyze the influence of each error type on the meshing behavior of the IRPRSM and provide guidance for tolerance allocation and error-compensated assembly.
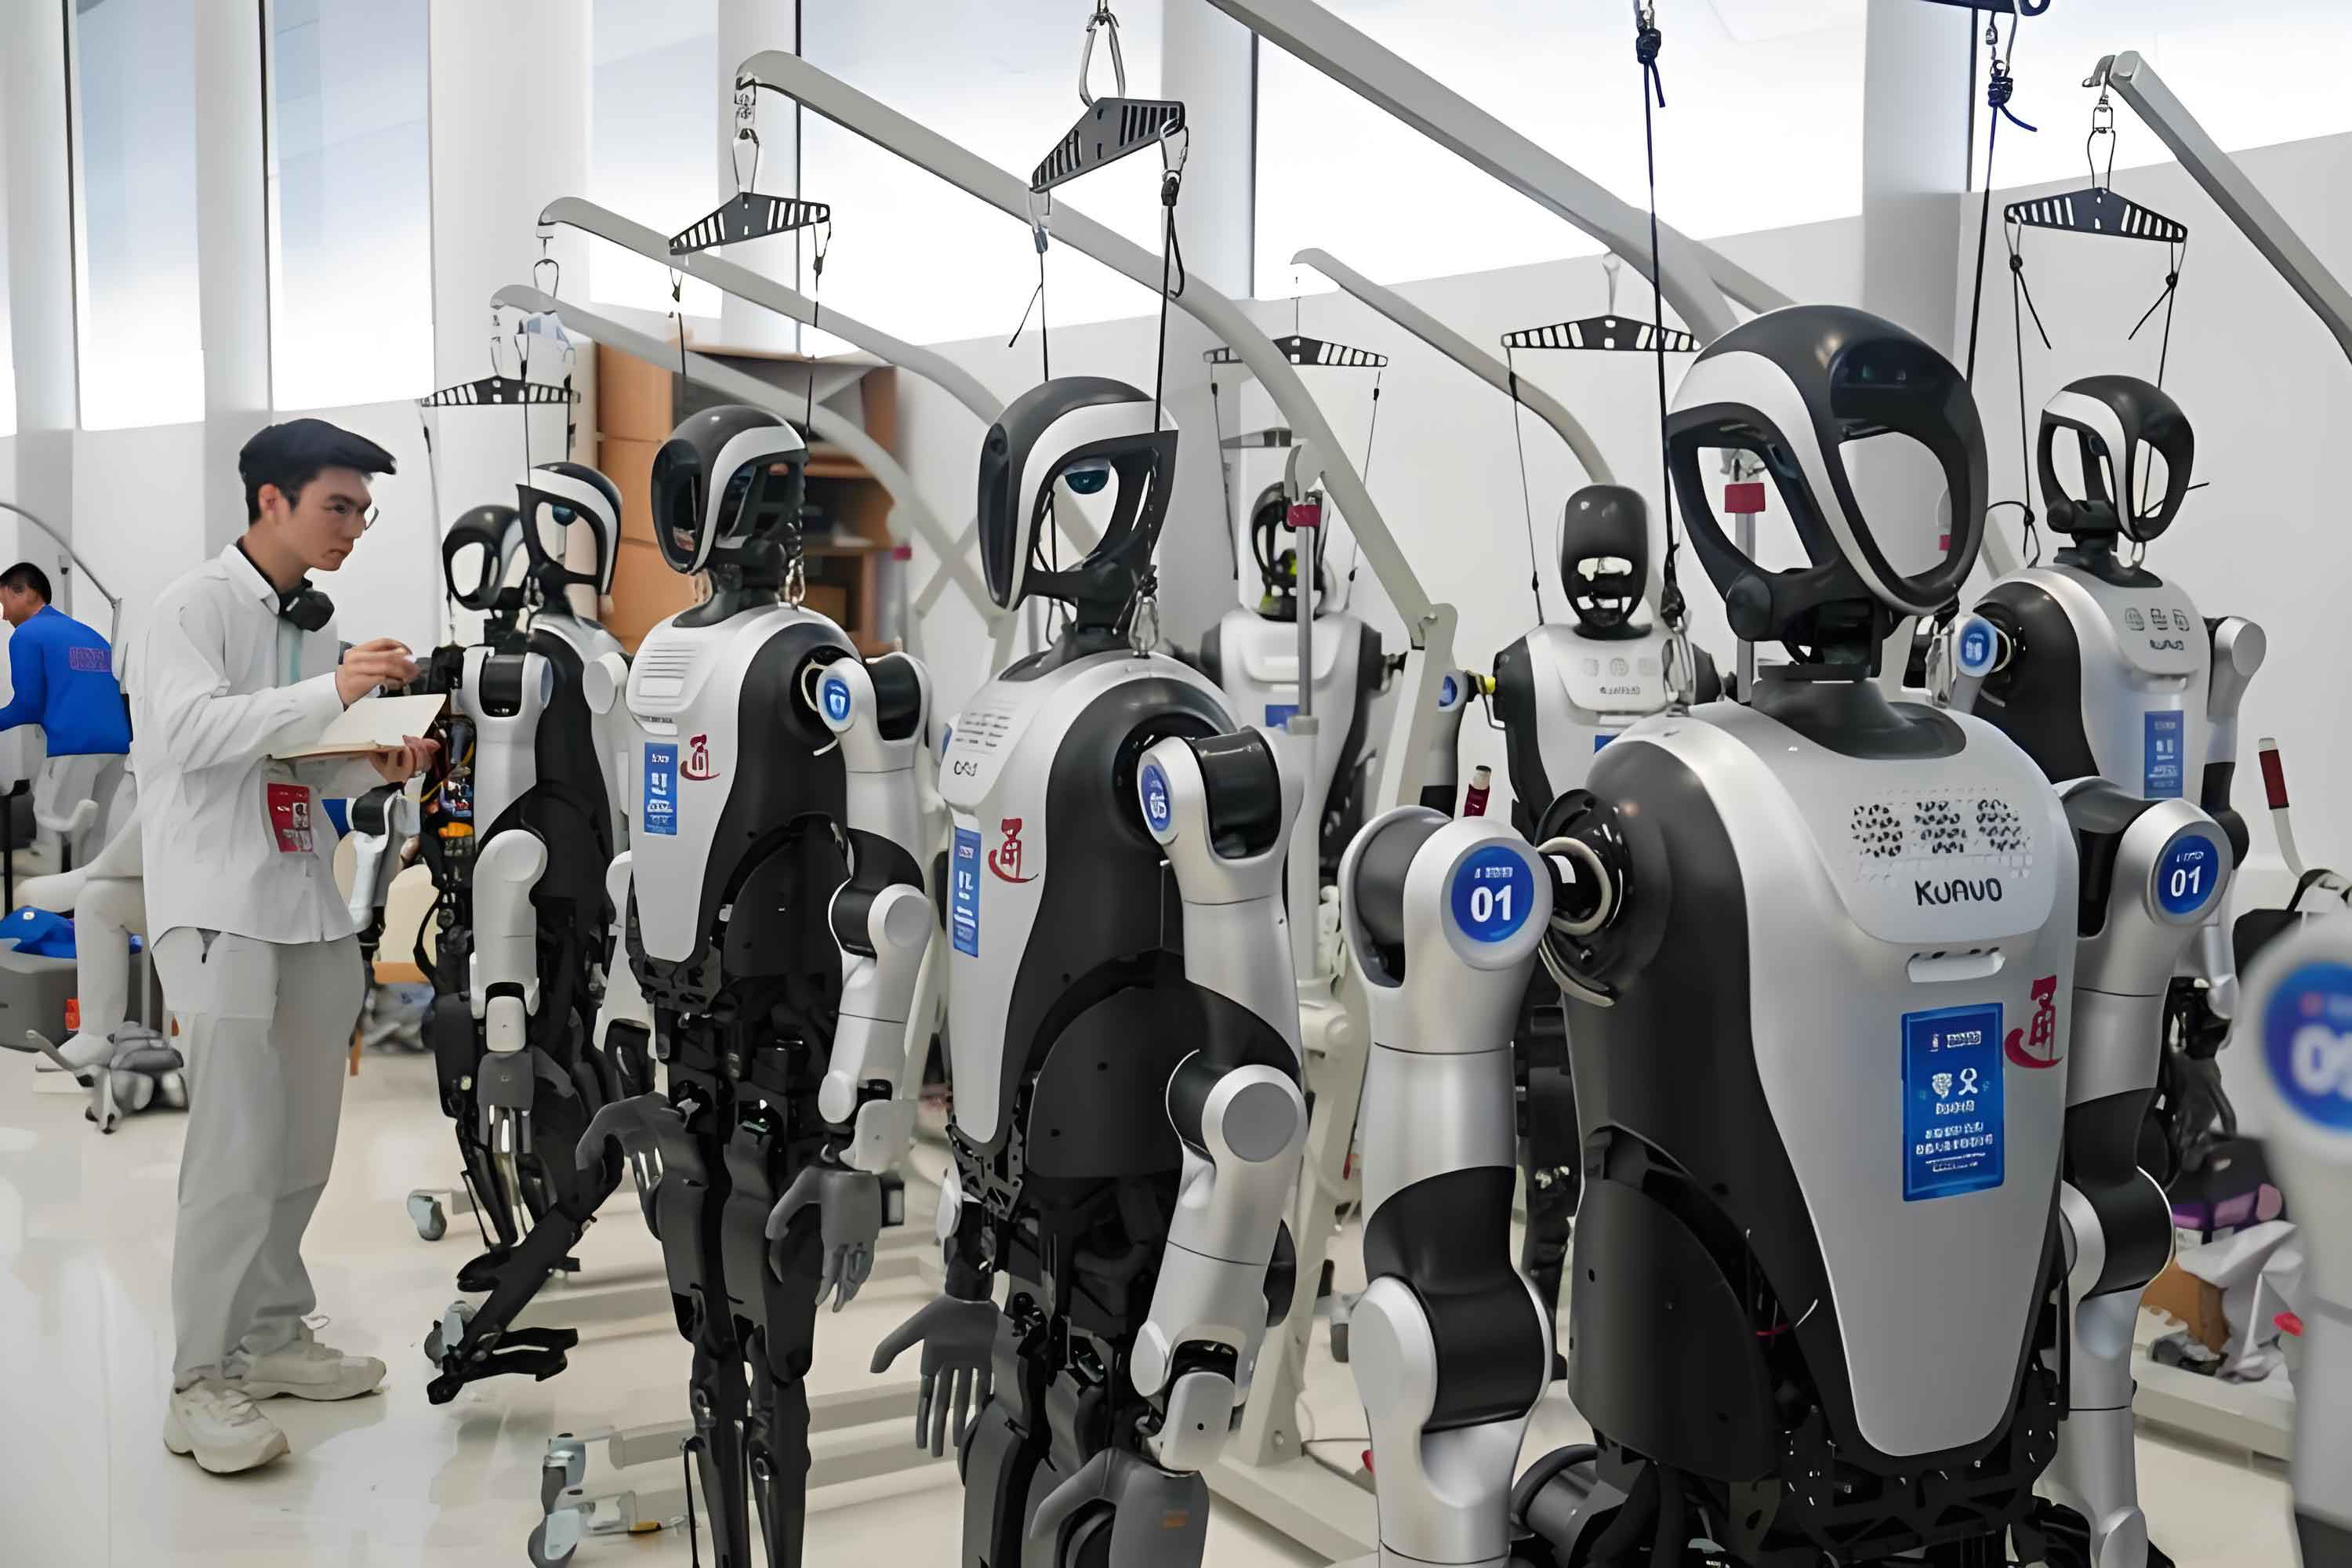
As shown in the figure above, quality inspection in humanoid robot manufacturing is crucial to ensure the geometric accuracy of transmission components. For IRPRSM used in humanoid robot joints, machining error control is intimately connected to the final positioning accuracy and dynamic behavior. This motivates the present study, which focuses on the quantitative connection between machining errors and meshing characteristics.
2. Structure and Working Principle of IRPRSM
The IRPRSM mainly consists of a screw, rollers, a nut, a cage, and a cam ring. The screw and nut have triangular thread profiles with single-start or multi-start threads. The rollers have annular grooves with no helix angle; their cross-sectional profile is circular-arc shaped. The rollers are arranged in a planetary pattern inside the cage, and the cage has several inward straight slots along the circumferential direction. The cam ring limits the axial displacement of the cage and has a raised platform with a height equal to one pitch; the platform assists the rollers in completing a return motion.
During operation, the nut thread engages with the roller annular groove teeth and transmits the driving torque from the power source to the rollers. The rollers rotate about their own axes while revolving around the screw. They also engage with the screw thread teeth, thereby converting the rotation into linear motion of the screw. When a roller enters the non-threaded region of the screw, it is reset axially by the raised platform of the cam ring and then re-enters the meshing zone for continuous transmission.
To satisfy the kinematic relationships, the geometric parameters of the IRPRSM must fulfill the following constraints. First, the screw, roller, and nut must have the same pitch:
$$
p_S = p_R = p_N.
$$
Second, the number of thread starts of the screw and the nut must be identical:
$$
n_S = n_N, \quad n_R = 0,
$$
where \(n_R=0\) because the roller has annular grooves without helix angle. Third, the nominal radii satisfy
$$
r_{N0} = r_{S0} + r_{R0},
\tag{1}
$$
where \(r_{S0}\), \(r_{R0}\), and \(r_{N0}\) are the nominal radii of the screw, roller, and nut, respectively. The leads and helix angles of the screw and nut are related by
$$
L_S = 2\pi r_{S0} \tan\lambda_S, \qquad L_N = 2\pi r_{N0} \tan\lambda_N,
\tag{2}
$$
where \(L_S\) and \(L_N\) are the leads of the screw and nut, and \(\lambda_S\) and \(\lambda_N\) are the helix angles at the nominal pitch cylinder. Since the roller has zero helix angle, its lead is zero: \(L_R = 0\).
3. Machining Error Sources and Characterization
In the manufacturing and assembly of IRPRSM, geometric errors inevitably occur. They cause uneven contact stress, lower transmission accuracy, and shortened service life. In this work we consider four typical types of machining errors.
3.1 Eccentricity error
Eccentricity error arises mainly from inconsistent reference datums and inadequate precision control during machining. The actual axis of the thread helix deviates from the theoretical axis by a vector \(e_i\), where the subscript \(i = S, R, N\) denotes the screw, roller, and nut, respectively. Let \(r_{i0}\) be the nominal pitch radius, \(R_i\) the actual distance from the theoretical center to the contact point, and \(\theta_{xi}\) the angle between the line connecting the theoretical center and the actual contact point and the \(y_i\)-axis.
3.2 Pitch-diameter error
Pitch-diameter error directly changes the radial clearance between the screw/nut and the roller. It affects the actual contact radius and the axial gap. The deviation between the theoretical pitch diameter and the actual pitch diameter is expressed on one flank as \(\Delta d_i / 2\). This error can be positive or negative, corresponding to an increase or decrease in the pitch diameter.
3.3 Thread-angle error
Thread-angle error describes the deviation of the actual flank angle from the nominal flank angle. Let \(\beta_i\) be the nominal thread flank angle and \(\Delta\beta_i\) the flank-angle error. Because the thread profile is not symmetric about the radial direction after this error, the contact point moves along the flank and changes the effective engagement geometry.
3.4 Thread-start indexing error
In multi-start threads of the screw and nut, the angular spacing between adjacent thread starts may deviate from the ideal value. For the \(j\)-th thread start, the indexing error is denoted by \(\Delta\theta_i^j\). This error redistributes the clearance between the upper and lower flanks of the corresponding thread pair.
Table 1 summarizes the four error types and the corresponding symbols used in our model.
| Error type | Symbol | Affected components | Primary consequence |
|---|---|---|---|
| Eccentricity error | \(e_S, e_R, e_N\) | Screw, roller, nut | Periodic variation of meshing radius and axial clearance |
| Pitch-diameter error | \(\Delta d_S, \Delta d_R, \Delta d_N\) | Screw, roller, nut | Radial shift of contact position |
| Thread-angle error | \(\Delta\beta_S, \Delta\beta_R, \Delta\beta_N\) | Screw, roller, nut | Flank contact point migration and clearance change |
| Thread-start indexing error | \(\Delta\theta_S^j, \Delta\theta_N^j\) | Screw, nut | Redistribution of upper/lower flank clearance |
4. Unified Helical Surface Equation
To model the IRPRSM with machining errors, we first define a cross-section coordinate system \(O_i’ – u_i v_i w_i\) for each component, whose origin is located at the pitch point of the corresponding thread helix. The thread profiles of the screw, roller, and nut are shown conceptually as upper and lower contours \(\Gamma_{iT}\) and \(\Gamma_{iB}\).
For the roller, the circular-arc tooth profile is characterized by the arc radius \(r_{PR}\) and the coordinates of the arc center. Considering the thread-angle error, the center coordinates are:
$$
u_{PR} = r_{PR} \sin(\beta_R + \xi_R \Delta\beta_R), \qquad w_{PR} = r_{PR} \cos(\beta_R + \xi_R \Delta\beta_R) + c_R,
\tag{3}
$$
where \(\xi_R\) is a sign coefficient defining the direction of the thread-angle deviation, and \(c_R\) is the half-tooth thickness. The meshing point \(\mathbf{m}_R\) on the roller cross-section can be written as
$$
\mathbf{m}_R = \begin{bmatrix} u_R \\ v_R \\ w_R + \xi \sqrt{r_{PR}^2 – (u_R – u_{PR})^2} \end{bmatrix},
\tag{4}
$$
in which \(\xi = 1\) and \(\xi = -1\) represent the upper and lower flank contact sides, respectively.
By applying successive coordinate transformations from the cross-section frame to the component frame and then to the global frame, we obtain the global position vector \(\mathbf{r}_R\) of a point on the roller surface. In the presence of eccentricity, pitch-diameter error, and thread-angle error, the expression for the roller surface is:
$$
\mathbf{r}_R =
\begin{bmatrix}
x_R \\ y_R \\ z_R
\end{bmatrix}
=
\begin{bmatrix}
u_R \cos\gamma_R \cos\varphi_q – v_R \sin\gamma_R \cos\varphi_q + \cdots \\
u_R \sin\gamma_R \sin\varphi_q + v_R \cos\gamma_R \sin\varphi_q + \cdots \\
w_R + \cdots + \frac{p_R}{2\pi}\theta_R
\end{bmatrix},
\tag{5}
$$
where \(\varphi_q\) denotes the revolution angle of the \(q\)-th roller, \(\gamma_R\) is the rotation angle of the roller about its own axis, and \(p_R\) is the pitch. The ellipsis in Eq. (5) represents terms that include the eccentricity vector \((e_R\cos\theta_{xR}, e_R\sin\theta_{xR},0)\) and pitch-diameter error \(\Delta d_R/2\). Similar equations are constructed for the screw and nut surfaces. The screw surface involves the helix angle \(\lambda_S\), the number of starts \(n_S\), and the thread-start indexing error \(\Delta\theta_S^j\) through the sign coefficient \(\xi_S^j\). For the nut, the same procedure is applied with \(i=N\).
5. Spatial Meshing Conditions and Axial Clearance
For two arbitrary meshing surfaces \(\Gamma_m\) and \(\Gamma_n\), the position vectors at the contact point must coincide up to a clearance vector, and the unit normal vectors must be collinear. The necessary conditions are:
$$
\mathbf{r}_m(\theta_m, u_m) = \mathbf{r}_n(\theta_n, u_n) + \delta_{mn} \mathbf{e}_m,
\tag{6}
$$
$$
\mathbf{n}_m(\theta_m, u_m, \xi_m) = \xi_{mn} \mathbf{n}_n(\theta_n, u_n, \xi_n),
\tag{7}
$$
where \(\mathbf{e}_m\) is the unit clearance direction, \(\delta_{mn}\) is the scalar clearance magnitude, and \(\xi_{mn}\) takes \(+1\) or \(-1\) depending on the relative orientation of the two normals. Expanding Eqs. (6) and (7) in the global coordinate system yields a system of five scalar equations for the five unknowns \(u_m, \theta_m, u_n, \theta_n, \delta_{mn}\):
$$
\mathbf{F}(u_m,\theta_m,u_n,\theta_n,\delta_{mn}) = \begin{bmatrix} f_1 \\ f_2 \\ f_3 \\ f_4 \\ f_5 \end{bmatrix} = \mathbf{0}.
\tag{8}
$$
Solving Eq. (8) gives the actual contact point and the clearance between the two mating surfaces. In this work we focus on the axial component of the clearance, which directly relates to the lost motion, positioning error, and transmission stiffness of the IRPRSM in humanoid robot joints. Thus, we set:
$$
\mathbf{e}_m = \begin{bmatrix} 0 \\ 0 \\ 1 \end{bmatrix}.
$$
For the screw–roller pair, the governing equations can be expressed in the following reduced form:
$$
\begin{aligned}
& r_{CS} \cos\phi_{CS} + r_{CRS} \cos\phi_{CRS} = r_{S0} + e_{Sx}, \\
& r_{CS} \sin\phi_{CS} + r_{CRS} \sin\phi_{CRS} = e_{Sy}, \\
& z_S – z_R – \delta_{SR} = 0, \\
& \mathbf{n}_S = \xi_{SR} \mathbf{n}_R,
\end{aligned}
\tag{9}
$$
where the subscripts \(CS\) and \(CRS\) denote the screw meshing radius and the roller radius on the screw side, respectively, and \(\phi_{CS}\), \(\phi_{CRS}\) are the corresponding meshing deflection angles. Analogous equations are written for the roller–nut pair. From the solution of Eq. (9), we obtain the meshing radii \(r_{CS}, r_{CRS}, r_{CRN}, r_{CN}\), the deflection angles \(\phi_{CS}, \phi_{CRS}, \phi_{CRN}, \phi_{CN}\), and the axial clearances \(\delta_{SR}\) and \(\delta_{NR}\).
6. Model Verification
To verify the correctness of the proposed unified model, we set all error terms to zero and compare the calculated meshing parameters with the ideal results reported in the literature for a ring-type planetary roller screw mechanism with the same screw–roller geometry. Table 2 gives the comparison.
| Parameter | Our model (zero error) | Ideal model (literature) | Relative difference |
|---|---|---|---|
| Screw meshing radius \(r_{CS}\) / mm | 30.0064 | 30.006 | 0.01‰ |
| Screw meshing angle \(\phi_{CS}\) / ° | 0.6934 | 0.693 | 0.58‰ |
| Roller radius on screw side \(r_{CRS}\) / mm | 5.0090 | 5.009 | <0.1‰ |
| Roller angle on screw side \(\phi_{CRS}\) / ° | 4.1574 | 4.157 | 0.10‰ |
| Screw–roller axial clearance \(\delta_{SR}\) / mm | 0.0246 | 0.025 | 1.60% |
| Nut meshing radius \(r_{CN}\) / mm | 39.9958 | 40.000 | 0.10‰ |
| Roller radius on nut side \(r_{CRN}\) / mm | 5.0028 | 5.000 | 0.56‰ |
The small discrepancies are because the literature model uses a ring-type nut without helix angle, whereas our IRPRSM nut has a finite helix angle. The agreement validates that our model reduces to the ideal meshing geometry when errors vanish. Consequently, the error-containing model is also reliable.
7. Influence of Machining Errors on Meshing Characteristics
In this section, we quantitatively analyze the influence of each machining error. Unless otherwise stated, we use the typical IRPRSM structural parameters listed in Table 3.
| Parameter | Symbol | Screw | Roller | Nut |
|---|---|---|---|---|
| Nominal radius \(r_{i0}\) / mm | \(r_{S0}, r_{R0}, r_{N0}\) | 30 | 5 | 40 |
| Addendum \(a_i\) / mm | \(a_S, a_R, a_N\) | 0.4 | 0.4 | 0.4 |
| Dedendum \(b_i\) / mm | \(b_S, b_R, b_N\) | 0.55 | 0.55 | 0.55 |
| Half tooth thickness \(c_i\) / mm | \(c_S, c_R, c_N\) | 0.48 | 0.48 | 0.50 |
| Number of starts \(n_i\) | \(n_S, n_R, n_N\) | 8 | — | 8 |
| Flank angle \(\beta_i\) / ° | \(\beta_S, \beta_R, \beta_N\) | 45 | 45 | 45 |
| Pitch \(p\) / mm | \(p_S, p_R, p_N\) | 2 | 2 | 2 |
| Roller arc radius \(r_{PR}\) / mm | \(r_{PR}\) | — | 7.071 | — |
7.1 Effect of Eccentricity Error
We first study the effect of eccentricity errors on the screw and roller. The direction of the eccentricity vector strongly affects the axial clearance. For example, when the screw eccentricity is along the \(X\)-direction, the axial clearance changes almost linearly with the eccentricity magnitude, whereas the roller eccentricity in the \(X\)-direction has the opposite trend. The \(Y\)-direction eccentricity has a much weaker influence. Therefore, the \(X\)-direction eccentricity is the dominant one and is used in the subsequent analysis.
For a screw eccentricity of \(+10~\mu m\) and a roller eccentricity of \(-10~\mu m\), we computed the meshing radii and axial clearance during one full revolution of the roller around the screw. The results show that both screw-side and roller-side meshing radii fluctuate periodically with the revolution angle. The fluctuation frequency increases as the number of screw starts increases. The roller-side meshing radius exhibits a larger amplitude than the screw-side radius.
Table 4 summarizes the peak-to-peak fluctuation of the axial clearance for different numbers of screw starts under the same eccentricity conditions.
| Number of screw starts \(n_S\) | Peak-to-peak axial clearance fluctuation / μm |
|---|---|
| 3 | 8.2 |
| 4 | 11.5 |
| 5 | 14.7 |
| 6 | 18.0 |
| 7 | 21.4 |
| 8 | 25.3 |
The physical mechanism is that eccentricity shifts the actual helix axis away from the theoretical axis. When the roller revolves around the screw, the relative distance between the two components changes periodically along the line of centers. Consequently, the meshing radius oscillates, and the axial clearance follows the same oscillation. A larger number of screw starts implies more thread crossings per revolution, so the period of the oscillation becomes shorter and the effective frequency higher. This frequency-dependent behavior is important for dynamic control of humanoid robot joints because the periodic clearance fluctuation directly influences the contact establishment process during direction reversal.
7.2 Effect of Pitch-Diameter Error
Pitch-diameter error changes the radial position of the flank. Since the roller has a circular-arc profile, a variation in the roller pitch diameter directly shifts the contact point on the arc. In contrast, a screw pitch-diameter error mainly translates the flank radially without changing its shape; therefore it has a different effect on the contact point. We computed the meshing position in the end face projection for roller pitch-diameter errors ranging from \(-0.03\) mm to \(+0.03\) mm. The contact point moves progressively along the negative \(X\)-direction, i.e., toward the minor diameter of the screw thread, as the roller pitch-diameter error increases.
Figure 13 in the original work shows the axial clearance versus pitch-diameter error. Our results demonstrate that whether the error is on the screw or the roller, the axial clearance decreases monotonically as the error varies from negative to positive. Moreover, within the same error amplitude range of \(\pm 0.03\) mm, the difference between the axial clearance induced by the screw error and that induced by the roller error is less than 2 μm. Table 5 gives the numerical values at selected error values.
| Pitch-diameter error \(\Delta d_i\) / mm | Axial clearance with screw error / μm | Axial clearance with roller error / μm | Difference / μm |
|---|---|---|---|
| -0.03 | 42.3 | 43.8 | 1.5 |
| -0.02 | 37.1 | 38.2 | 1.1 |
| -0.01 | 31.9 | 32.5 | 0.6 |
| 0 | 22.9 | 23.1 | 0.2 |
| 0.01 | 15.6 | 15.9 | 0.3 |
| 0.02 | 9.4 | 9.8 | 0.4 |
| 0.03 | 4.8 | 5.2 | 0.4 |
The close agreement suggests a complementary compensation strategy: by pairing a screw with positive pitch-diameter error and a roller with negative pitch-diameter error (or vice versa), the axial clearance can be maintained within an acceptable range without requiring ultra-precise machining of individual parts. This is valuable for improving assembly consistency and operational stability of IRPRSM in humanoid robot joints.
7.3 Effect of Thread-Angle Error
We now consider the thread-angle error in the screw or roller. The meshing position in the cross-section shifts radially when only one component has a thread-angle error. When both the screw and the roller have errors of the same magnitude, the contact point shifts transversely. Specifically, if the screw flank angle is larger than the roller flank angle, the meshing point moves toward the root of the screw; if the screw flank angle is smaller, the meshing point moves toward the root of the roller. Thus, the difference between the flank angles of the two mating parts is more important than their absolute values.
Figure 15 in the original work plots the axial clearance against the thread-angle error. Table 6 summarizes the calculated axial clearances for three error modes: error only on the screw, error only on the roller, and equal same-direction errors on both parts.
| Thread-angle error \(\Delta\beta\) / ° | Error only on screw / μm | Error only on roller / μm | Equal same-direction errors / μm |
|---|---|---|---|
| -3.0 | 11.2 | 10.8 | 22.87 |
| -2.0 | 15.7 | 15.4 | 23.12 |
| -1.0 | 20.3 | 20.1 | 23.51 |
| 0 | 24.58 | 24.58 | 24.10 |
| 1.0 | 20.3 | 20.1 | 24.73 |
| 2.0 | 15.7 | 15.4 | 25.36 |
| 3.0 | 11.2 | 10.8 | 26.11 |
The single-component error cases show an approximately symmetric convex curve with a peak of 24.58 μm at zero error, decreasing to about 10–12 μm at \(\pm 3^\circ\). In contrast, the equal same-direction error case produces a gentle increase from 22.87 μm to 26.11 μm as the error changes from \(-3^\circ\) to \(+3^\circ\). This indicates that if the screw and roller have thread-angle errors that vary synchronously in the same direction, the axial clearance remains relatively stable. Therefore, in engineering practice, it is more efficient to control the difference between the flank angles of the two mating components rather than to improve the single-component accuracy separately.
7.4 Effect of Thread-Start Indexing Error
To study the effect of thread-start indexing error, we number the threads of the screw, roller, and nut consistently. The roller has no helix angle, and the screw has a non-threaded zone; hence the roller engages only over a restricted region on the screw side. On the nut side, the engagement occurs along a wider range. We consider a three-start screw with indexing errors \(\Delta\theta_S^1 = 0^\circ\), \(\Delta\theta_S^2 = 0.05^\circ\), and \(\Delta\theta_S^3 = -0.1^\circ\), and a nut with errors \(\Delta\theta_N^1 = -0.06^\circ\), \(\Delta\theta_N^2 = 0.04^\circ\), and \(\Delta\theta_N^3 = 0.12^\circ\).
Our calculations show that thread-start indexing errors do not change the axial contact position on a given flank pair. Instead, they directly alter the axial gaps of the corresponding thread-engagement pairs. When the indexing error is positive, the axial gap between the roller upper helical surface and the mating thread surface decreases, while the gap involving the roller lower helical surface increases by a similar amount. When the indexing error is negative, the opposite redistribution occurs. Table 7 illustrates the axial clearance for the first few thread pairs in the three-start example.
| Roller thread number \(k_R^*\) | Upper mating pair \(\delta_{RT-NB}\) / μm | Lower mating pair \(\delta_{RB-NT}\) / μm |
|---|---|---|
| 1 | 18.4 | 27.9 |
| 2 | 22.1 | 25.3 |
| 3 | 25.6 | 22.8 |
| 4 | 29.4 | 19.6 |
| 5 | 31.2 | 17.1 |
| 6 | 27.8 | 20.9 |
This redistribution affects the load-sharing behavior under applied load. When the mechanism is loaded, the thread pair with the smaller initial axial clearance will come into contact first and carry a larger portion of the load. If the applied load is small, some thread pairs with larger gaps may not be in contact at all. Therefore, thread-start indexing errors should be carefully controlled in humanoid robot joint designs where precise and predictable load distribution is required.
8. Discussion
The results presented above reveal several important implications for the application of IRPRSM in humanoid robot joints. First, eccentricity errors are particularly detrimental because they produce periodic oscillations in the axial clearance, leading to time-varying transmission stiffness and possible dynamic excitation. The sensitivity increases with the number of screw starts; hence for multi-start IRPRSM designs, a tighter eccentricity tolerance is necessary. Second, pitch-diameter errors in the screw and roller produce similar effects on the axial clearance, which opens the door for error compensation during selective assembly. Third, the thread-angle error effect is dominated by the difference between the mating flank angles rather than by their individual values. Therefore, manufacturing specifications should include a paired flank-angle difference tolerance rather than absolute flank-angle tolerances alone. Fourth, thread-start indexing errors redistribute the clearance without moving the nominal contact position, which modifies the load-sharing sequence and may cause early wear or reduced positioning accuracy in cyclic loading.
Our unified model provides a quantitative tool for evaluating these effects at the design stage. In addition, the model can be extended to include thermal deformation and elastic contact deformation under load. For humanoid robot joints, the operating temperature may vary significantly, and thermal expansion can change the effective pitch diameter and flank angles. A thermo-mechanical coupling model will be necessary for a complete prediction of the positioning error. Similarly, under load, elastic deformation at the contact points alters the ideal geometric relationships; this effect can be integrated into the current framework by adding the normal approach between the two surfaces.
9. Conclusion
In this paper, we have systematically analyzed the mechanism of machining error effects on the meshing behavior of an inverted recirculating planetary roller screw mechanism for humanoid robot joints. The main conclusions are:
- We established a unified three-body helical surface equation that incorporates eccentricity, pitch-diameter, thread-angle, and thread-start indexing errors. The spatial meshing model provides analytical expressions for the actual meshing position, meshing radius, deflection angle, and axial clearance. The model was validated by comparison with an ideal meshing model in the zero-error limit.
- Eccentricity errors cause periodic fluctuations of the meshing radius and axial clearance. The fluctuation frequency increases with the number of screw starts. This periodic behavior can affect the dynamic response and should be considered in the control design of humanoid robot joints.
- Pitch-diameter errors on the screw and the roller produce similar axial clearance changes within the range of \(\pm0.03\) mm, with a difference of less than 2 μm. This permits a complementary compensation strategy for high-precision assembly without reducing individual machining tolerances.
- Thread-angle errors change the contact point position and axial clearance. When only one component has the error, the axial clearance peaks at 24.58 μm at zero error and decreases to approximately 10–12 μm at \(\pm3^\circ\). When the screw and roller errors vary equally in the same direction, the axial clearance remains nearly constant, increasing from 22.87 μm to 26.11 μm over the same range. Thus, controlling the flank-angle difference is more important than controlling the absolute flank angle of each component.
- Thread-start indexing errors do not shift the axial contact position but redistribute the clearances between the upper and lower helical flanks. Under load, the side with smaller clearance contacts first and takes more load, which influences the load distribution and wear pattern in the IRPRSM.
These findings provide valuable insights for tolerance design, error compensation, and quality inspection of IRPRSM components in humanoid robot joint actuators. Future work will focus on coupling thermal deformation, elastic deflection, and multiple error sources to further improve the prediction accuracy for realistic operating conditions.