
In the field of industrial robotics and precision manufacturing equipment, the RV reducer has emerged as a critical component due to its high torque capacity, compact design, and excellent positioning accuracy. As an engineer specializing in mechanical design and finite element analysis, I have extensively studied the dynamic behavior of RV reducers to enhance their performance and reliability. This article presents a comprehensive modal analysis of key components within an RV reducer, specifically the crankshaft and planetary frame, using finite element methods. The goal is to investigate their inherent vibrational characteristics, assess potential resonance risks, and identify structural weaknesses that could impact the overall system’s integrity. Through this work, I aim to provide insights that can guide the optimization of RV reducer designs for demanding applications such as industrial robots, where high loads and precise motion control are paramount.
The importance of the RV reducer in modern automation cannot be overstated. It is widely employed in robotic arms and joints, where it must withstand harsh operating conditions while maintaining minimal vibration and high precision. Any excessive vibration can lead to resonance, causing premature wear, reduced accuracy, or even catastrophic failure. Therefore, understanding the modal properties—such as natural frequencies and mode shapes—is essential for predicting and mitigating vibrational issues. In this study, I leverage finite element analysis (FEA) to simulate the free and constrained boundary conditions of the crankshaft and planetary frame, two critical elements in the RV reducer assembly. By comparing their natural frequencies with gear meshing frequencies and overall system frequencies, I evaluate the likelihood of resonance and pinpoint areas requiring structural reinforcement. The analysis is conducted using ANSYS Workbench software, with models created parametrically in Pro/ENGINEER to ensure flexibility and accuracy.
To begin, let me outline the theoretical foundation of modal analysis. Modal analysis is a linear dynamic technique that determines the natural frequencies and mode shapes of a structure, assuming constant mass and stiffness matrices without time-varying loads. For an undamped system, the equation of motion can be expressed as:
$$[M]\{\ddot{u}\} + [K]\{u\} = \{0\}$$
where $[M]$ is the mass matrix, $[K]$ is the stiffness matrix, $\{\ddot{u}\}$ is the acceleration vector, and $\{u\}$ is the displacement vector. For free vibration, the solution takes the form:
$$\{u\} = \{\phi_i\} \cos(\omega_i t)$$
Here, $\{\phi_i\}$ represents the eigenvector or mode shape for the $i$-th mode, $\omega_i$ is the corresponding natural frequency in radians per second, and $t$ is time. Substituting this into the equation of motion yields the eigenvalue problem:
$$(-\omega_i^2 [M] + [K]) \{\phi_i\} = \{0\}$$
The characteristic equation is then:
$$|-\omega_i^2 [M] + [K]| = 0$$
Solving this equation provides the natural frequencies $\omega_i$ and eigenvectors $\{\phi_i\}$. These eigenvectors are often normalized with respect to the mass matrix, such that:
$$\{\phi_i\}^T [M] \{\phi_i\} = 1$$
In practical terms, modal analysis helps identify how a structure will vibrate under dynamic loads, with lower-order modes typically having the most significant impact on vibrational response. For the RV reducer, this analysis is crucial because internal excitations from gear meshing can induce forced vibrations. If any natural frequency aligns closely with these excitation frequencies, resonance may occur, leading to amplified vibrations and potential damage. Thus, by computing the modal parameters, I can assess the structural dynamics and inform design improvements.
The methodology for this modal analysis involves several steps, starting with parametric modeling. I used Pro/ENGINEER to create geometric models of the crankshaft and planetary frame, focusing on an RV-200C reducer as a case study. Parametric design allows for quick modifications by defining relationships between geometric parameters and design variables. For instance, the gear components, such as the planetary gears, were modeled with specified parameters: 45 teeth, a module of 2 mm, a pressure angle of 20°, a face width of 12 mm, an addendum factor of 0.9, and a dedendum factor of 0.25. This approach ensures that the models are accurate and adaptable for future variations. The crankshaft and planetary frame were assembled considering their actual connections—the crankshaft is solidly coupled with the planetary gear via splines, while the output disk serves as the planetary frame in the first-stage transmission, fixed with screws. These assemblies were then exported in .igs format and imported into ANSYS Workbench for further analysis.
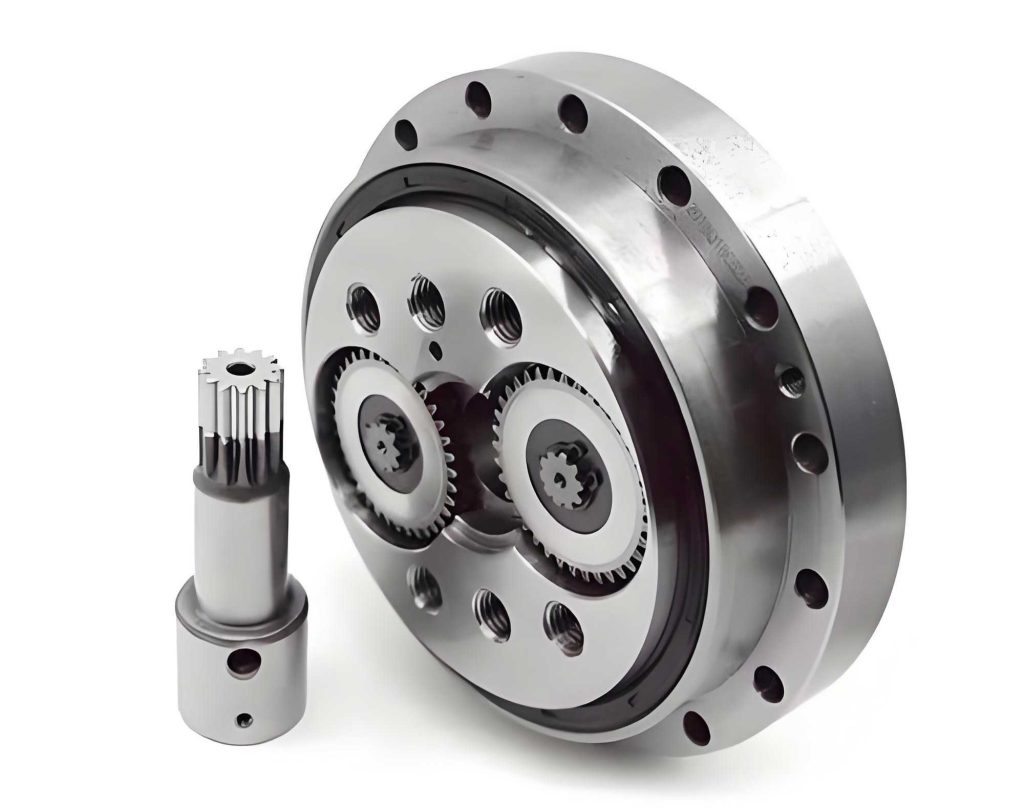
After importing the models, I defined the material properties based on actual components used in RV reducers. Accurate material data are vital for reliable FEA results. The table below summarizes the material parameters assigned to the crankshaft and planetary frame:
| Component | Material | Elastic Modulus (GPa) | Density (kg/m³) | Poisson’s Ratio |
|---|---|---|---|---|
| Planetary Gear | 40Cr | 212 | 7870 | 0.279 |
| Crankshaft | GCr15 | 219 | 7850 | 0.310 |
| Planetary Frame | 45 Steel | 209 | 7890 | 0.269 |
These values were input into the Engineering Data module of ANSYS Workbench. For the finite element discretization, I selected Solid186 elements, which are 3D 20-node hexagonal elements suitable for complex geometries. Each node has three translational degrees of freedom (X, Y, Z), allowing for accurate simulation of irregular meshes. The mesh generation was performed using free meshing with a global element size of 2 mm, resulting in a fine mesh that captures detailed features of the crankshaft and planetary frame. This mesh density balances computational efficiency with precision, as shown in the grid划分 results where elements are evenly distributed across the surfaces and volumes.
Boundary conditions play a critical role in modal analysis. In theory, free-boundary modal analysis provides fundamental insights into a structure’s inherent vibrational behavior without external constraints, which can be mathematically transformed to other boundary conditions. However, constrained-boundary analysis more closely mimics real-world operating conditions, where components are supported by bearings or housings. To gain a comprehensive understanding, I conducted both free and constrained modal analyses for the crankshaft and planetary frame. For the crankshaft, free boundaries imply no restrictions on degrees of freedom, while constrained boundaries involve radial supports at the cylindrical contact surfaces where bearings connect to the planetary frame—simulating only half the contact area to reflect actual load distribution. For the planetary frame, constraints include radial and axial fixes at the bearing holes and outer cylindrical surfaces where it interfaces with the pin housing. These setups enable a comparison of how boundary conditions affect modal properties, enhancing the reliability of my findings.
The modal analysis was solved for the first fifteen modes under free boundaries and the first ten modes under constrained boundaries, as lower-order modes dominate vibrational response. The results are presented in tables and discussed in detail below. First, let’s consider the crankshaft. Under free boundaries, the natural frequencies were computed, with the first three modes near zero (rigid body modes) ignored. The significant modes, such as the seventh and thirteenth, show distinct mode shapes. For instance, in free state, the planetary gear attached to the crankshaft exhibits axial swinging, while the crankshaft itself undergoes radial twisting and bending. Maximum displacements occur at the gear tooth profiles and shaft ends, indicating potential weak points. The table below lists the natural frequencies for the crankshaft under free boundaries:
| Mode Number | Natural Frequency (Hz) |
|---|---|
| 1 | 0 |
| 2 | 1.8156 × 10⁻³ |
| 3 | 4.1534 × 10⁻³ |
| 4 | 2.2371 |
| 5 | 4.1622 |
| 6 | 7.8053 |
| 7 | 2759.5 |
| 8 | 2763.3 |
| 9 | 4187.1 |
| 10 | 6379.8 |
| 11 | 6746.9 |
| 12 | 6748.1 |
| 13 | 9417.6 |
| 14 | 9460.0 |
| 15 | 14239 |
To assess resonance risk, I compared these frequencies with the gear meshing frequency. For the RV reducer, the meshing frequency $f_n$ can be calculated using:
$$f_n = \frac{n z}{60}$$
where $z$ is the number of teeth on the central gear and $n$ is the rotational speed in RPM. For the central gear with 22 teeth and an assumed speed of 3500 RPM (typical for robotic applications), the meshing frequency is:
$$f_n = \frac{3500 \times 22}{60} \approx 1283.3 \text{ Hz}$$
Comparing this with the crankshaft’s natural frequencies, there is no close match, suggesting low resonance probability under free boundaries. However, under constrained boundaries, the crankshaft’s modal behavior changes. The constrained model includes radial supports at the shaft ends, and the natural frequencies are tabulated below:
| Mode Number | Natural Frequency (Hz) |
|---|---|
| 1 | 1.6276 × 10⁻³ |
| 2 | 1910.9 |
| 3 | 1953.3 |
| 4 | 4244.6 |
| 5 | 4876.4 |
| 6 | 5266.7 |
| 7 | 5223.2 |
| 8 | 6849.2 |
| 9 | 6849.3 |
| 10 | 14446 |
In this case, the second and third modes (1910.9 Hz and 1953.3 Hz) are closer to the meshing frequency (1283.3 Hz), though still not overlapping. The mode shapes reveal that vibration primarily occurs at the planetary gear, with axial and radial twisting, and maximum displacement at the gear tooth edges. This highlights the gear as a potential weak link, warranting attention to stiffness in future RV reducer designs.
Moving to the planetary frame, similar analyses were performed. Under free boundaries, the natural frequencies are as follows:
| Mode Number | Natural Frequency (Hz) |
|---|---|
| 1 | 0 |
| 2 | 0 |
| 3 | 1.0105 × 10⁻³ |
| 4 | 2.7975 × 10⁻³ |
| 5 | 6.1757 × 10⁻³ |
| 6 | 9.1267 × 10⁻³ |
| 7 | 2635.8 |
| 8 | 2635.9 |
| 9 | 2808.7 |
| 10 | 3703.3 |
| 11 | 3704.0 |
| 12 | 4131.3 |
| 13 | 4131.4 |
| 14 | 4374.5 |
| 15 | 4576.8 |
Ignoring the rigid body modes (first six near zero), the natural frequencies are significantly higher than the meshing frequency and reported overall system frequencies from prior studies. For reference, literature cites the first nine natural frequencies of an entire RV reducer as approximately 75.14 Hz, 135.07 Hz, 135.77 Hz, 178.48 Hz, 426.3 Hz, 451.63 Hz, 844.47 Hz, 847.065 Hz, and 1163.1 Hz. The planetary frame’s free-boundary frequencies show no close alignment, indicating minimal resonance risk. The mode shapes, such as the eighth and fourteenth modes, depict axial twisting with maximum displacement at the outer edges of the left planetary frame, suggesting these areas are structurally vulnerable.
Under constrained boundaries, the planetary frame was analyzed with radial and axial supports at bearing connections and outer surfaces. The natural frequencies are:
| Mode Number | Natural Frequency (Hz) |
|---|---|
| 1 | 2068.8 |
| 2 | 2668.2 |
| 3 | 2980.8 |
| 4 | 4215.3 |
| 5 | 4524.9 |
| 6 | 4829.0 |
| 7 | 5460.8 |
| 8 | 5923.9 |
| 9 | 6433.3 |
| 10 | 6570.6 |
Again, these frequencies do not closely match the system frequencies or meshing frequency, reinforcing that the planetary frame is unlikely to resonate in the RV reducer assembly. The mode shapes show radial and axial twisting, with maximum displacement persisting at the outer edges, confirming that stiffness enhancements should focus on these regions.
Throughout this analysis, the parametric modeling approach proved highly efficient, allowing rapid generation and modification of RV reducer components. By adjusting design parameters, I can easily explore different geometries for optimization. The finite element modal analysis, conducted in ANSYS Workbench, provided detailed insights into the dynamic characteristics of the crankshaft and planetary frame. Comparing free and constrained boundaries enhanced the robustness of my conclusions, as constrained conditions better reflect real-world operation. The results indicate that neither component is prone to resonance with the gear meshing frequency or overall system frequencies, validating the current RV reducer design’s structural adequacy. However, the mode shapes reveal specific weak points: for the crankshaft, the gear tooth profiles and shaft ends experience high displacements, while for the planetary frame, the outer edges are critical. These findings suggest that future optimizations should target these areas, perhaps through material selection, geometric reinforcements, or damping treatments, to further improve the RV reducer’s performance and longevity.
In conclusion, modal analysis is a powerful tool for understanding the vibrational behavior of RV reducer components. By employing finite element methods, I have demonstrated that the crankshaft and planetary frame exhibit natural frequencies that avoid resonance with common excitations, but their mode shapes highlight potential structural weaknesses. This study underscores the importance of integrating modal analysis into the design process of RV reducers, ensuring they meet the stringent demands of industrial robotics. As automation continues to advance, such analyses will play a crucial role in developing more reliable and efficient RV reducer systems. Future work could extend to nonlinear analyses, experimental validation, or optimization algorithms to refine these components further, ultimately contributing to the evolution of high-performance RV reducers in the manufacturing landscape.