
As a researcher focused on precision transmission systems, I have always been intrigued by the thermal challenges in RV reducers, which are critical components in robotic joints. The RV reducer, a type of two-stage speed reducer, combines a planetary gear stage with a cycloidal pin gear stage to achieve high reduction ratios and compact design. However, the high input speeds and substantial torque transmission in RV reducers often lead to significant thermal effects, such as heat generation from friction during gear meshing. This can result in thermal deformation, reduced transmission accuracy, and even failure due to thermal胶合. In this article, I explore how tooth profile modification of the cycloidal gear in RV reducers influences temperature distribution, aiming to provide insights for improving thermal performance and reliability. The study is based on theoretical calculations and finite element analysis, emphasizing the impact of different modification methods on contact stress, friction heat, and steady-state temperature.
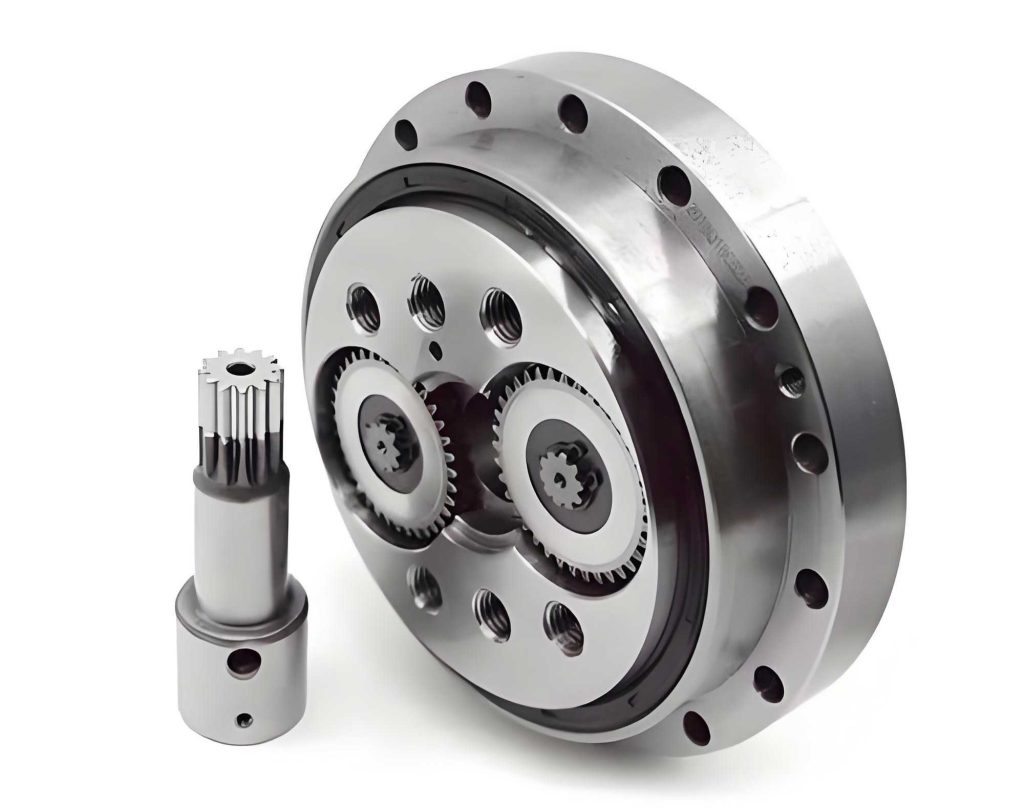
In RV reducers, the cycloidal gear meshes with multiple pin teeth to transmit motion and torque. The standard tooth profile of the cycloidal gear is derived from a theoretical curve, but in practice, modifications are essential to compensate for manufacturing errors, facilitate assembly, and enhance lubrication. Common modification methods include isometric modification and shift modification, often combined to achieve optimal performance. These modifications alter the initial meshing clearance, which in turn affects the load distribution, contact patterns, and frictional heat generation. Understanding these effects is crucial for designing RV reducers that operate efficiently under varying thermal conditions. My analysis focuses on three combination modification methods: positive isometric with negative shift, negative isometric with positive shift, and positive isometric with positive shift, all with a consistent radial clearance of 0.006 mm. This approach allows for a comparative study of how different profiles influence the thermal behavior of the RV reducer.
The generation of friction heat during meshing is a primary source of temperature rise in RV reducers. When the cycloidal gear engages with the pin teeth, relative sliding occurs, leading to energy dissipation as heat. The instantaneous friction heat generated at the contact interface can be expressed by the following formula:
$$Q = \sigma_H v_r f \gamma$$
Here, $Q$ represents the instantaneous friction heat per unit area, $\sigma_H$ is the contact stress on the tooth surface, $v_r$ is the relative sliding velocity between the gear and pin tooth, $f$ is the friction coefficient, and $\gamma$ is the energy conversion coefficient, typically ranging from 0.9 to 0.95. This heat is partially absorbed by the cycloidal gear and pin teeth, causing temperature increases, while the remainder dissipates through convection with lubricant. Over time, the system reaches a steady-state temperature distribution, which I analyze using finite element methods to evaluate the thermal performance of modified profiles.
To compute the friction heat, accurate models for contact stress, sliding velocity, and friction coefficient are necessary. The contact between the cycloidal gear and pin teeth resembles Hertzian contact between two cylinders, allowing for simplified stress calculations. The average contact stress, $\sigma_H$, is derived from the maximum Hertzian stress, adjusted by a factor of $\pi/4$. The formula is:
$$\sigma_H = \frac{\pi}{4} \times 0.418 \sqrt{\frac{F_i E}{b \rho_{ei}}}$$
In this equation, $F_i$ denotes the normal contact force at the $i$-th meshing point, $E$ is the elastic modulus (approximately $2.06 \times 10^5$ MPa for GCr15 steel, commonly used in RV reducers), $b$ is the tooth width, and $\rho_{ei}$ is the equivalent curvature radius at the contact point. The equivalent curvature radius depends on the gear geometry and modification parameters, calculated as:
$$\frac{1}{\rho_{ei}} = \frac{1}{r_{rp}} – \frac{1}{\rho_i}$$
where $r_{rp}$ is the pin tooth radius, and $\rho_i$ is the curvature radius of the cycloidal gear tooth profile, given by:
$$\rho_i = \frac{(1 + K^2 – 2K \cos \phi_i)^{3/2} r_p}{K(1 + z_p) \cos \phi_i – z_p K^2 – 1} + r_{rp}$$
Here, $\phi_i$ is the meshing phase angle, $K$ is the shorten amplitude coefficient defined as $K = a z_p / r_p$, with $a$ as the eccentricity, $z_p$ as the number of pin teeth, and $r_p$ as the radius of the pin tooth center circle. These geometric parameters are fundamental to the design of RV reducers and influence how modifications alter the meshing characteristics.
The normal contact force, $F_i$, varies between standard and modified tooth profiles. For a standard profile, assuming half the teeth are in contact, the force distribution is derived from torque equilibrium. The force at each meshing point is:
$$F_i = \frac{4 T_c \sin \phi_i}{K z_c r_p s^{1/2}}$$
where $T_c$ is the output torque per cycloidal gear disc (approximately $0.55T$ for a two-disc configuration in RV reducers), $z_c$ is the number of cycloidal gear teeth, and $s = 1 + K^2 – 2K \cos \phi_i$. For modified profiles, the initial meshing clearance changes, leading to a different load distribution. Only teeth where the total deformation exceeds the initial clearance participate in meshing. The force on the $i$-th tooth for modified profiles is expressed as:
$$F_i = \frac{\delta_i – \Delta \phi_i}{\delta_{\text{max}}} F_{\text{max}}$$
where $\delta_i$ is the total deformation at the meshing point, $\Delta \phi_i$ is the initial meshing clearance due to modification, $\delta_{\text{max}}$ is the maximum deformation, and $F_{\text{max}}$ is the maximum contact force. The initial clearance $\Delta \phi_i$ for combined modifications is calculated as:
$$\Delta \phi_i = \Delta r_{rp} \left(1 – \frac{\sin \phi_i}{\sqrt{s}}\right) + \Delta r_p \left(1 – K \cos \phi_i – \frac{\sqrt{1 – K^2} \sin \phi_i}{\sqrt{s}}\right)$$
where $\Delta r_{rp}$ is the isometric modification amount and $\Delta r_p$ is the shift modification amount. The maximum force $F_{\text{max}}$ is determined iteratively, considering the deformation and clearance, to ensure equilibrium in the RV reducer system.
To illustrate the parameters used in my analysis, I summarize the key specifications of the RV reducer studied in Table 1. This table provides a reference for understanding the geometric and operational context of the temperature analysis.
| Parameter | Value |
|---|---|
| Cycloidal gear tooth width, $b$ (mm) | 16 |
| Number of cycloidal gear teeth, $z_c$ | 39 |
| Number of pin teeth, $z_p$ | 40 |
| Eccentricity, $a$ (mm) | 1.5 |
| Pin tooth radius, $r_{rp}$ (mm) | 3 |
| Pin tooth center circle radius, $r_p$ (mm) | 76.5 |
| Output speed, $n$ (rpm) | 15 |
| Output torque, $T$ (N·m) | 784 |
The three combination modification methods are applied with a radial clearance of 0.006 mm, and the optimal modification amounts are determined through engineering practices. Table 2 lists these amounts for each method, highlighting the differences in isometric and shift modifications that influence the thermal behavior of the RV reducer.
| Modification Method | Isometric Modification Amount (mm) | Shift Modification Amount (mm) |
|---|---|---|
| Positive Isometric + Negative Shift | 0.0158 | -0.0098 |
| Negative Isometric + Positive Shift | -0.0098 | 0.0158 |
| Positive Isometric + Positive Shift | 0.0158 | 0.0098 |
The relative sliding velocity, $v_r$, between the cycloidal gear and pin teeth is another critical factor in heat generation. Assuming the pin teeth are fixed and without sleeves, the sliding velocity can be derived from the kinematics of the RV reducer. It is given by:
$$v_r = (r_p s^{1/2} – r_{rp}) \omega_H / z_c$$
where $\omega_H$ is the angular velocity of the input shaft, calculated as $\omega_H = 2\pi n_H / 60$, with $n_H$ as the input speed. This velocity varies with the meshing phase angle, affecting the frictional energy dissipation across the tooth profile.
The friction coefficient, $f$, is not constant but depends on operating conditions such as load, speed, and surface roughness. I use an empirical formula to estimate $f$ at different meshing positions:
$$f = 0.002 \left( \frac{F_{ti}}{0.001b} \right)^{0.2} \left( \frac{0.001 \rho_{ei} v_n \cos \phi_i}{\eta} \right)^{0.2} \eta^{-0.05x}$$
Here, $F_{ti}$ is the tangential load at the meshing point, $v_n$ is the tangential velocity, $\eta$ is the dynamic viscosity of the lubricant, and $x$ is a roughness factor defined as $x = 21.4 ((s_1 + s_2)/(2d))^{0.25}$, where $s_1$ and $s_2$ are the surface roughness values of the gear and pin teeth, and $d$ is the pitch diameter of the cycloidal gear. This detailed model allows for a more accurate prediction of friction heat in the RV reducer.
Once the instantaneous friction heat is computed, it must be averaged over the meshing cycle to analyze the steady-state temperature field. The periodic heat flux, $q_i$, applied to the cycloidal gear tooth surface is given by:
$$q_i = \frac{2 a_H / v_r}{T} q_c$$
where $q_c = \beta Q$ is the portion of heat absorbed by the cycloidal gear (with $\beta$ as the heat partition factor), $T$ is the meshing period calculated as $T = 2\pi (z_p – 1)/(z_p \omega_H)$, and $a_H$ is the half-width of the contact area from Hertzian theory:
$$a_H = \sqrt{\frac{8 F_i \rho_{ei} (1 – \mu^2)}{\pi b E}}$$
with $\mu$ as Poisson’s ratio (0.3 for steel). This periodic heat input is used in finite element simulations to determine the temperature distribution in the RV reducer components.
For heat dissipation, convection plays a key role. The convective heat transfer coefficients on the gear tooth surface and end faces are estimated using formulas based on boundary layer theory. For the tooth surface:
$$h_c = 0.664 \lambda \left( \frac{\rho c v}{\lambda} \right)^{1/3} \left( \frac{\omega}{\nu} \right)^{1/2}$$
and for the end faces:
$$h_d = 0.616 \lambda \left( \frac{\rho c v}{\lambda} \right)^{1/2} \left( \frac{\omega}{\nu} \right)^{1/2}$$
where $\lambda$ is the thermal conductivity, $\omega$ is the angular velocity of the cycloidal gear, $\nu$ is the kinematic viscosity, $\rho$ is the density, and $c$ is the specific heat capacity. These coefficients define the boundary conditions for the thermal analysis of the RV reducer.
In my finite element analysis, I model the cycloidal gear using material properties of GCr15 steel, with a thermal conductivity of 44 W/(m·°C). The environment temperature is set to 22°C, and steady-state temperature fields are solved for both standard and modified tooth profiles. The results reveal significant insights into how modifications affect thermal performance in RV reducers. For instance, the standard profile exhibits a maximum steady-state temperature of 41.7°C, with heat distributed symmetrically along the tooth width and higher gradients in the meshing region.
To compare the effects of different modifications, I analyze the contact stress and friction heat distributions. Figure 1 (not shown numerically, but referenced in context) illustrates the initial meshing clearances for the three modification methods. The positive isometric with positive shift modification results in the largest initial clearance, providing more space for lubrication and potentially better thermal management. This aligns with the findings from the temperature analysis, where this modification method shows the most effective cooling.
The contact stress distributions for standard and modified profiles are summarized in Table 3. As the meshing range decreases due to modifications, the stress on individual teeth increases, and the peak stress location shifts forward. This concentration of stress influences the friction heat generation and subsequent temperature rise in the RV reducer.
| Profile Type | Maximum Contact Stress (MPa) | Meshing Range (Phase Angle) | Peak Friction Heat Location |
|---|---|---|---|
| Standard | Moderate | Wide | Centered |
| Positive Isometric + Negative Shift | High | Reduced | Shifted Forward |
| Negative Isometric + Positive Shift | High | Reduced | Shifted Forward |
| Positive Isometric + Positive Shift | High | Reduced | Shifted Forward |
The instantaneous friction heat, $Q$, shows that the maximum value remains similar across profiles, but the peak location shifts with the meshing range. In contrast, the periodic heat flux, $q_i$, increases as the meshing range decreases, with peaks occurring at the same meshing phase angle but with higher magnitudes due to increased pressure. This is captured in the formula for periodic heat:
$$q_i = \frac{2 a_H / v_r}{T} \beta \sigma_H v_r f \gamma$$
Simplifying, this highlights the dependence on contact stress and sliding velocity, both affected by modification in the RV reducer.
The steady-state temperature fields from finite element analysis are presented in Table 4. The positive isometric with positive shift modification achieves the lowest maximum temperature, indicating its superiority in thermal performance for RV reducers. The temperature gradients on single teeth become more concentrated with reduced meshing ranges, emphasizing the need for careful design to avoid hot spots.
| Tooth Profile | Maximum Temperature (°C) | Temperature Gradient Concentration | Cooling Effectiveness |
|---|---|---|---|
| Standard | 41.7 | Moderate | Baseline |
| Positive Isometric + Negative Shift | 38.2 | High | Good |
| Negative Isometric + Positive Shift | 37.5 | High | Better |
| Positive Isometric + Positive Shift | 36.8 | High | Best |
My discussion centers on the implications of these findings for RV reducer design. The reduction in steady-state temperature with tooth profile modification is primarily due to altered load distribution and improved lubrication gaps. The positive isometric with positive shift modification offers the largest initial clearance, which enhances lubricant flow and heat dissipation, thereby lowering temperatures. This is crucial for RV reducers operating in high-speed robotic applications where thermal management is critical for longevity and precision.
Furthermore, the concentration of temperature gradients on single teeth under modified profiles suggests that while overall temperatures decrease, local hot spots may form if the meshing range is too narrow. Engineers must balance modification amounts to optimize both thermal and mechanical performance in RV reducers. The iterative process for calculating $F_{\text{max}}$ underscores the complexity of predicting behavior in modified gears, but finite element analysis provides a robust tool for simulation.
In conclusion, my investigation demonstrates that tooth profile modification of cycloidal gears significantly influences temperature distribution in RV reducers. Among the combined methods, positive isometric with positive shift modification yields the best cooling effect, reducing the steady-state temperature by approximately 5°C compared to the standard profile. The instantaneous friction heat peaks shift with meshing range, while periodic heat increases under higher loads. These insights can guide the design of RV reducers for improved thermal performance, enhancing reliability in demanding applications like industrial robotics. Future work could explore dynamic thermal analysis or the effects of different lubricants on temperature in RV reducers.
To summarize key formulas used in this analysis for quick reference, I list them below:
- Instantaneous friction heat: $$Q = \sigma_H v_r f \gamma$$
- Average contact stress: $$\sigma_H = \frac{\pi}{4} \times 0.418 \sqrt{\frac{F_i E}{b \rho_{ei}}}$$
- Equivalent curvature radius: $$\frac{1}{\rho_{ei}} = \frac{1}{r_{rp}} – \frac{1}{\rho_i}$$
- Normal force for standard profile: $$F_i = \frac{4 T_c \sin \phi_i}{K z_c r_p s^{1/2}}$$
- Normal force for modified profile: $$F_i = \frac{\delta_i – \Delta \phi_i}{\delta_{\text{max}}} F_{\text{max}}$$
- Relative sliding velocity: $$v_r = (r_p s^{1/2} – r_{rp}) \omega_H / z_c$$
- Periodic heat flux: $$q_i = \frac{2 a_H / v_r}{T} q_c$$
This comprehensive analysis underscores the importance of tooth profile modification in managing thermal effects in RV reducers, contributing to advancements in precision transmission technology.