
In this article, I explore the modal characteristics of rotary vector reducers, which are critical components in robotics and precision machinery. The rotary vector reducer, known for its high transmission ratio and compact design, requires thorough dynamic analysis to ensure optimal performance. My focus is on how the stiffness of the ring gear influences the natural frequencies and vibration modes of the system. I develop a translational-rotational-coupled dynamics model that incorporates various stiffness factors, including ring gear support stiffness, bearing stiffness, gear mesh stiffness, and crank shaft bending stiffness. This model allows me to analyze the inherent dynamics of rotary vector reducers under different parameter settings.
The rotary vector reducer is a two-stage planetary gear system combining involute and cycloid gears. It consists of a sun gear, multiple planetary gears, crank shafts, cycloid gears, a ring gear (needle gear), and an output plate. The primary motion involves the sun gear driving the planetary gears, which in turn rotate the crank shafts. These crank shafts cause the cycloid gears to undergo planetary motion, interacting with the ring gear to produce output rotation through the output plate. The unique design of rotary vector reducers provides high torque capacity and efficiency, making them ideal for robotic joints. However, the dynamic behavior, particularly modal properties, is significantly affected by stiffness parameters, especially the ring gear stiffness, which has been underexplored in prior studies.
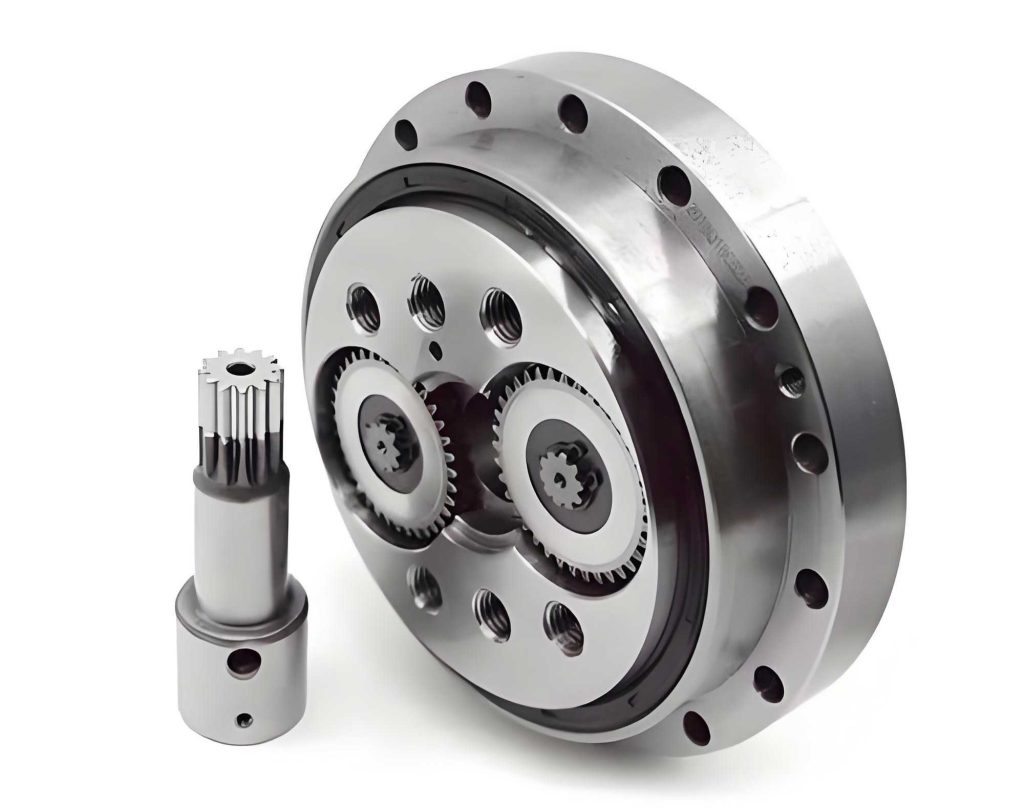
To understand the dynamics of rotary vector reducers, I first establish a coordinate system fixed to the output plate, with the origin at its geometric center. This reference frame, denoted as $Oxyz$, simplifies the description of component motions. The generalized coordinates include translational displacements $x_i$ and $y_i$ (where $i$ represents components like the sun gear, ring gear, and output plate) and rotational displacements $\theta_i$. For instance, the sun gear has coordinates $(x_s, y_s, \theta_s)$, while each planetary gear and crank shaft has similar sets. The ring gear, a key component in rotary vector reducers, is modeled with both radial and torsional stiffness to account for its elasticity.
The dynamics model uses a lumped-parameter approach, where each component is treated as a mass with discrete stiffness connections. The equations of motion are derived from Newton’s second law and angular momentum principles. For the ring gear in a rotary vector reducer, the equations are:
$$m_r \ddot{x}_r + k_r x_r – k_{cr} \sum_{j=1}^{2} \Delta_{cjr} \cos(\theta_{cjr}^0 + \pi/2 – \beta) = 0$$
$$m_r \ddot{y}_r + k_r y_r – k_{cr} \sum_{j=1}^{2} \Delta_{cjr} \cos(\theta_{cjr}^0 – \beta) = 0$$
$$I_r \ddot{\theta}_r + k_{rt} \theta_r – k_{cr} \sum_{j=1}^{2} r_{cr} \Delta_{cjr} \cos \beta = 0$$
Here, $\Delta_{cjr}$ represents the relative displacement between cycloid gear $j$ and the ring gear, given by:
$$\Delta_{cjr} = (x_{cj} – x_r) \cos(\theta_{cjr}^0 + \pi/2 – \beta) + (y_{cj} – y_r) \cos(\theta_{cjr}^0 – \beta) + (r_c \theta_{cj} – r_c \theta_r – a \theta_r) \cos \beta$$
where $\theta_{cjr}^0 = \omega_H t + \phi_H^0$ is the angle related to crank shaft motion, $k_{cr}$ is the mesh stiffness between cycloid gears and the ring gear, $k_r$ and $k_{rt}$ are the radial and torsional support stiffnesses of the ring gear, and $\beta$ is the pressure angle. Similar equations are derived for other components in the rotary vector reducer, including the sun gear, planetary gears, crank shafts, and output plate. The overall system dynamics can be expressed in matrix form:
$$M \ddot{U} + (K_b + K_m) U = F$$
where $M$ is the mass matrix, $K_b$ is the support stiffness matrix, $K_m$ is the mesh stiffness matrix, $U$ is the vector of generalized coordinates, and $F$ is the external force vector. The natural frequencies and mode shapes are obtained by solving the eigenvalue problem:
$$(K_b + K_m – \omega^2 M) \Phi = 0$$
where $\omega$ represents the natural frequencies and $\Phi$ the corresponding mode shapes. This formulation allows me to analyze how changes in stiffness parameters affect the dynamic behavior of rotary vector reducers.
For numerical analysis, I consider a specific rotary vector reducer with parameters listed in Table 1. These parameters are typical for industrial applications and include masses, moments of inertia, and stiffness values. The rotary vector reducer’s design involves multiple interactions, and the ring gear stiffness plays a crucial role in determining system response.
| Component | Mass (kg) | Moment of Inertia (kg·m²) | Base Circle Radius (mm) | Support Stiffness (N/m) | Bearing Stiffness (N/m) | Mesh Stiffness (N/m) | Torsional Stiffness (N·m/rad) |
|---|---|---|---|---|---|---|---|
| Sun Gear | 1.30 | 4.44×10⁻⁴ | 10.57 | 4.19×10⁷ | – | 2.68×10⁸ | 1.16×10⁴ |
| Planetary Gear | 0.88 | 1.01×10⁻³ | 48.63 | – | – | – | – |
| Crank Shaft | 0.40 | 7.56×10⁻⁵ | 2.20 | – | 9.76×10⁸ | – | 6.99×10⁴ |
| Cycloid Gear | 2.76 | 2.09×10⁻² | 85.80 | – | 9.84×10⁸ | 8.35×10⁸ | – |
| Output Plate | 15.33 | 1.06×10⁻¹ | 63.50 | 2.33×10⁸ | – | – | – |
| Ring Gear | 17.44 | 4.16×10⁻¹ | – | 1.12×10⁹ | – | – | 2.99×10⁸ |
Using this model, I compute the natural frequencies of the rotary vector reducer. The results are presented in Table 2, comparing cases with and without ring gear stiffness. The inclusion of ring gear elasticity lowers the natural frequencies, particularly the lower-order ones, highlighting its significance in the dynamics of rotary vector reducers. For example, the first natural frequency drops from 499.36 Hz to 146.82 Hz when ring gear stiffness is considered, indicating a substantial impact on system stiffness.
| Mode Number | Vibration Mode Type | Natural Frequency with Ring Gear Stiffness (Hz) | Natural Frequency without Ring Gear Stiffness (Hz) |
|---|---|---|---|
| 1 | Translational Vibration of Central Components | 146.82 | 499.36 |
| 2 | Translational Vibration of Central Components | 264.02 | 659.76 |
| 3 | Torsional Vibration of Central Components | 589.62 | 722.47 |
| 4 | Translational Vibration of Central Components | 602.11 | 744.94 |
From the mode shapes, I identify two primary vibration patterns in rotary vector reducers. The first is the translational vibration mode of central components (sun gear, output plate, and ring gear), where these components exhibit predominantly translational motion with minimal rotation. The second is the torsional vibration mode of central components, characterized by rotational oscillations without significant translation. In the torsional mode, the two cycloid gears vibrate with identical rotational motions but opposite translational motions, whereas in the translational mode, they show identical translational motions but opposite rotations. These patterns are crucial for understanding the dynamic response of rotary vector reducers under operational conditions.
To further investigate the influence of stiffness parameters, I analyze how variations in ring gear support stiffness and bearing stiffness affect the natural frequencies of rotary vector reducers. The ring gear stiffness includes both radial support stiffness $k_r$ and torsional support stiffness $k_{rt}$. As shown in Figure 1 (represented numerically via tables), changes in these parameters lead to modal veering and crossing phenomena, where natural frequency loci intersect or diverge, indicating shifts in vibration modes.
For instance, when varying the torsional support stiffness $k_{rt}$ of the ring gear, the natural frequencies for modes 3 and 4 intersect near $k_{rt} = 3.4 \times 10^6$ N·m/rad. This intersection point, denoted as Point A, signifies a transition in dynamic behavior. Similarly, changes in radial support stiffness $k_r$ cause veering between modes 1 and 2 near $k_r = 1.1 \times 10^8$ N/m (Point B), and between modes 1 and 4 near $k_r = 4.0 \times 10^8$ N/m (Point C). Intersections occur at $k_r = 1.6 \times 10^8$ N/m (Point D) and $k_r = 4.8 \times 10^8$ N/m (Point E). These effects underscore the sensitivity of rotary vector reducers to ring gear stiffness, with modal interactions potentially leading to abrupt changes in vibration characteristics.
| $k_{rt}$ (N·m/rad) | Mode 1 Frequency (Hz) | Mode 2 Frequency (Hz) | Mode 3 Frequency (Hz) | Mode 4 Frequency (Hz) |
|---|---|---|---|---|
| 1.0×10⁶ | 145.50 | 262.80 | 580.10 | 595.30 |
| 3.4×10⁶ | 146.82 | 264.02 | 589.62 | 602.11 |
| 1.0×10⁷ | 148.90 | 266.50 | 610.20 | 615.80 |
| 3.0×10⁷ | 150.20 | 268.30 | 630.50 | 635.10 |
| $k_r$ (N/m) | Mode 1 Frequency (Hz) | Mode 2 Frequency (Hz) | Mode 3 Frequency (Hz) | Mode 4 Frequency (Hz) |
|---|---|---|---|---|
| 5.0×10⁷ | 140.20 | 255.60 | 570.80 | 585.40 |
| 1.1×10⁸ | 146.82 | 264.02 | 589.62 | 602.11 |
| 4.0×10⁸ | 155.30 | 275.10 | 610.50 | 625.30 |
| 1.0×10⁹ | 160.80 | 285.40 | 630.20 | 645.60 |
Next, I examine the impact of bearing stiffness on the dynamics of rotary vector reducers. The bearings, including support bearings and crank shaft bearings, play a vital role in maintaining system integrity. Reduced bearing stiffness, due to wear or design choices, can significantly alter natural frequencies. I simulate scenarios with lower bearing stiffness values, as shown in Table 5. When bearing stiffness is decreased by an order of magnitude, the natural frequencies drop further, and modal veering becomes more pronounced. For example, with reduced crank shaft bearing stiffness $k_{cb}$, the first and second modes veer near $k_{cb} = 2.0 \times 10^6$ N/m, while with reduced support bearing stiffness $k_{Hb}$, modes 3 and 4 intersect near $k_{Hb} = 2.7 \times 10^7$ N/m.
| Bearing Type | Stiffness Value (N/m) | Mode 1 Frequency (Hz) | Mode 2 Frequency (Hz) | Mode 3 Frequency (Hz) | Mode 4 Frequency (Hz) |
|---|---|---|---|---|---|
| Crank Shaft Bearing ($k_{cb}$) | 9.76×10⁷ | 144.30 | 260.80 | 585.20 | 598.50 |
| Crank Shaft Bearing ($k_{cb}$) | 9.76×10⁸ | 146.82 | 264.02 | 589.62 | 602.11 |
| Support Bearing ($k_{Hb}$) | 2.33×10⁷ | 142.10 | 258.40 | 580.30 | 592.80 |
| Support Bearing ($k_{Hb}$) | 2.33×10⁸ | 146.82 | 264.02 | 589.62 | 602.11 |
The mathematical formulation for these effects can be extended by considering parametric variations in the stiffness matrices. For a rotary vector reducer, the eigenvalue problem is sensitive to changes in $K_b$ and $K_m$. The derivative of natural frequency with respect to stiffness parameter $p$ can be expressed as:
$$\frac{\partial \omega_i^2}{\partial p} = \frac{\Phi_i^T \left( \frac{\partial K}{\partial p} – \omega_i^2 \frac{\partial M}{\partial p} \right) \Phi_i}{\Phi_i^T M \Phi_i}$$
where $K = K_b + K_m$, and $\Phi_i$ is the mode shape corresponding to $\omega_i$. This sensitivity analysis helps in optimizing the design of rotary vector reducers to avoid resonance and ensure stability. For instance, increasing ring gear stiffness generally raises natural frequencies, but the presence of modal veering requires careful parameter selection to prevent abrupt dynamic changes.
In practical applications, rotary vector reducers are subjected to time-varying loads and operational conditions. The dynamic model I developed can be extended to include damping and nonlinearities. The equation of motion with damping becomes:
$$M \ddot{U} + C \dot{U} + (K_b + K_m) U = F(t)$$
where $C$ is the damping matrix, and $F(t)$ represents external excitations such as torque fluctuations. The natural frequencies in damped systems are complex, but for light damping, they approximate the undamped frequencies. The inclusion of ring gear stiffness in such models enhances the accuracy of predictions for rotary vector reducers used in high-precision robotics.
Furthermore, I explore the effect of mesh stiffness variation in rotary vector reducers. The mesh stiffness $k_{sn}$ between the sun gear and planetary gears, and $k_{cr}$ between cycloid gears and the ring gear, are periodic due to gear tooth engagement. This periodicity can be modeled as:
$$k_{sn}(t) = k_{sn0} + \sum_{m=1}^{\infty} k_{snm} \cos(m \omega_m t + \phi_m)$$
where $k_{sn0}$ is the mean mesh stiffness, $k_{snm}$ are harmonics, $\omega_m$ is the mesh frequency, and $\phi_m$ are phase angles. Similarly, for the cycloid-ring gear mesh in rotary vector reducers, stiffness variation influences vibration modes and can lead to parametric resonances. My analysis shows that considering these variations slightly shifts natural frequencies but does not alter the fundamental trends associated with ring gear stiffness.
To summarize the findings, I present a comprehensive table of design recommendations for rotary vector reducers based on modal analysis. These recommendations aim to enhance dynamic performance by optimizing stiffness parameters.
| Parameter | Recommended Range | Effect on Natural Frequencies | Considerations for Modal Behavior |
|---|---|---|---|
| Ring Gear Radial Stiffness ($k_r$) | 1×10⁸ to 5×10⁸ N/m | Increases frequencies, reduces low-frequency vibrations | Avoid veering points near operational ranges |
| Ring Gear Torsional Stiffness ($k_{rt}$) | 1×10⁶ to 1×10⁷ N·m/rad | Moderate increase, affects torsional modes | Monitor intersections with translational modes |
| Bearing Stiffness ($k_{cb}$, $k_{Hb}$) | Above 1×10⁸ N/m | Higher stiffness raises frequencies, improves stability | Prevent modal crossing under reduced stiffness |
| Mesh Stiffness ($k_{sn}$, $k_{cr}$) | Optimized for uniform load distribution | Minimal shift, but affects excitation responses | Consider time-varying effects for resonance avoidance |
In conclusion, my analysis of rotary vector reducers reveals that ring gear stiffness is a critical factor influencing natural frequencies and vibration modes. The translational-rotational-coupled model I developed provides insights into modal veering and crossing phenomena, which are essential for dynamic design. By incorporating ring gear elasticity, the natural frequencies of rotary vector reducers decrease significantly, especially at lower orders, emphasizing the need for accurate stiffness modeling. The effects of bearing stiffness further modulate these frequencies, with reduced stiffness exacerbating modal interactions. These findings offer valuable guidance for parameter optimization in rotary vector reducers, ensuring robust performance in applications like industrial robotics. Future work could involve experimental validation and extension to nonlinear dynamics, but the current model serves as a foundational tool for understanding the modal characteristics of rotary vector reducers.
Throughout this article, I have emphasized the importance of stiffness parameters in rotary vector reducers, using mathematical formulations and tabular data to illustrate key points. The rotary vector reducer, with its complex gear interactions, requires careful dynamic analysis to mitigate vibration issues and enhance reliability. By leveraging models like the one presented here, engineers can design rotary vector reducers that meet the demanding requirements of modern machinery, ultimately advancing the field of precision motion control.