
In the field of precision mechanical transmission, rotary vector reducers have garnered significant attention due to their compact size, lightweight design, wide range of transmission ratios, long service life, stable accuracy retention, high efficiency, and smooth operation. These reducers are extensively used in industrial robots, high-end CNC machine tools, tracking radars, tank turrets, and other civilian and military applications. As a researcher focused on advancing transmission technology, I have conducted an in-depth experimental investigation into the performance of rotary vector reducers, particularly emphasizing starting torque and transmission accuracy. This study aims to compare domestically developed rotary vector reducers with imported counterparts, analyze test data, and explore methods to enhance their performance. Through this work, I hope to contribute to the optimization of rotary vector reducer design and manufacturing processes.
The rotary vector reducer operates based on a two-stage transmission mechanism. The first stage involves planetary gear transmission, where input speed and torque are reduced. The second stage consists of a cycloidal pinwheel system, which further reduces speed and torque while providing feedback to the planetary gears via a support flange. The overall transmission principle can be summarized by the following kinematic relationship. Let $z_1$, $z_2$, $z_3$, and $z_4$ represent the number of teeth on the sun gear, planet gears, cycloidal gear, and pin teeth, respectively. The theoretical transmission ratio $i$ of the rotary vector reducer is given by:
$$ i = 1 + \frac{z_4}{z_3} \cdot \frac{z_2}{z_1} $$
This formula highlights the compound nature of the transmission, where the first stage reduction is combined with the second stage to achieve high reduction ratios in a compact package. The rotary vector reducer’s efficiency and precision stem from the rolling contact in the cycloidal stage, which minimizes friction and wear.
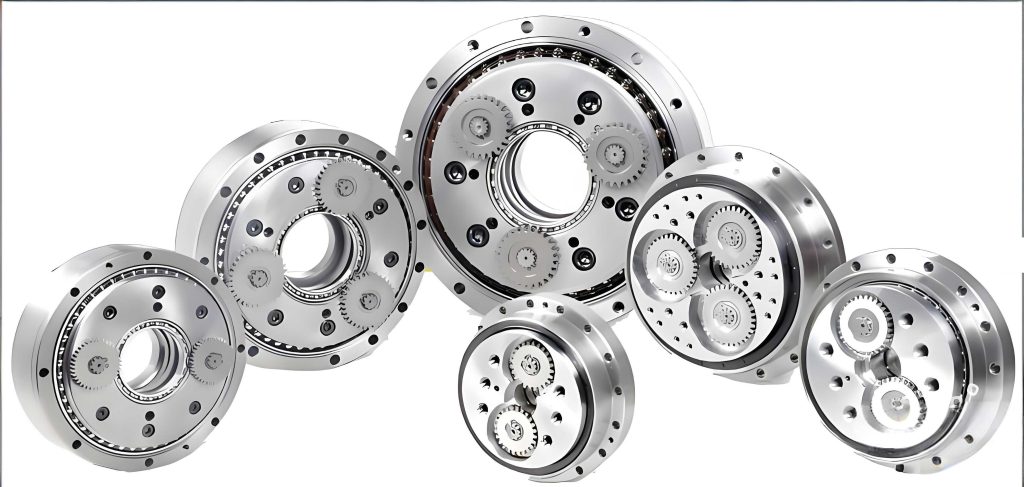
Key performance indicators for rotary vector reducers include starting torque and transmission accuracy. Starting torque refers to the minimum torque required to initiate motion in the reducer under no-load conditions. It reflects the meshing condition between the pin gear housing and the cycloidal disc, friction characteristics, and preload in the main bearings. Transmission accuracy, measured as transmission error, is crucial for precision positioning systems. The transmission error $\phi_{cr}$ is defined as the angular difference between the theoretical output angle and the actual output angle for any input angle, expressed in arcseconds:
$$ \phi_{cr} = \frac{\phi_{ia}}{i} – \phi_{oa} $$
where $\phi_{ia}$ is the input angular displacement in arcseconds, $\phi_{oa}$ is the actual output angular displacement in arcseconds, and $i$ is the theoretical transmission ratio. In practice, the transmission error of a rotary vector reducer is quantified as the difference between the maximum and minimum angular transmission errors over one full revolution of the output shaft under no-load conditions.
To evaluate these performance metrics, I designed and implemented test systems for starting torque and transmission accuracy. The starting torque test system consists of a motor that gradually applies torque to the reducer input shaft, a torque sensor connected between the motor and the reducer, and a fixed platform. The reducer is mounted on the platform, and torque is increased slowly until motion initiates. The torque at this point is recorded as the starting torque. To ensure accuracy, measurements are taken at four positions spaced 90 degrees apart on the input shaft, and the maximum value is considered the starting torque of the rotary vector reducer. The schematic of this system illustrates the integration of components for precise measurement.
The transmission accuracy test system involves mounting the rotary vector reducer on a test bench with an input motor and two high-resolution angular encoders attached to the input and output shafts. The motor drives the reducer at a constant speed under no-load conditions, while the encoders record angular positions. The transmission error is computed in real-time using the formula above, and data is analyzed to determine the error over one output revolution. This system allows for dynamic assessment of the rotary vector reducer’s precision.
For this experimental study, I selected four rotary vector reducers of the 20E series: three domestically developed units (labeled RV-20E-T1, RV-20E-T2, and RV-20E-T3) and one imported unit (labeled RV-20E-N). All reducers underwent a run-in process to stabilize performance before testing. The starting torque and transmission accuracy tests were conducted under controlled environmental conditions to minimize external influences.
The starting torque test results are summarized in the table below. The data reveals variations among the reducers, with the imported rotary vector reducer exhibiting the highest starting torque, indicating potentially tighter tolerances or better preload settings.
| Reducer ID | Starting Torque (N·m) |
|---|---|
| RV-20E-T1 | 0.27 |
| RV-20E-T2 | 0.21 |
| RV-20E-T3 | 0.38 |
| RV-20E-N | 0.40 |
During the run-in process, I observed that RV-20E-T1 and RV-20E-T2 exhibited less smooth rotation compared to the others. Upon inspecting key components prior to assembly, I found that some parts, particularly the pin gear housing and cycloidal discs, had dimensional deviations beyond specified tolerances. These deviations likely increased meshing clearances, reducing starting torque but compromising smoothness. This highlights the critical role of manufacturing precision in rotary vector reducer performance.
Transmission accuracy tests were performed at an input speed of 100 rpm under no-load conditions. The transmission error, calculated as the peak-to-peak value over one output revolution, is presented in the following table. The imported rotary vector reducer showed the smallest error, while the domestically developed units had larger errors, with RV-20E-T1 and RV-20E-T2 performing worse than RV-20E-T3.
| Reducer ID | Transmission Error (arcseconds) |
|---|---|
| RV-20E-T1 | 163.8 |
| RV-20E-T2 | 106.8 |
| RV-20E-T3 | 71.4 |
| RV-20E-N | 49.4 |
The transmission error curves for each rotary vector reducer were plotted, revealing both small-period and large-period fluctuations. For instance, RV-20E-T1 and RV-20E-T3 displayed noticeable large-period variations, which are attributed to cumulative pitch errors in the pin gear housing and cycloidal discs. The small-period fluctuations, observed in all reducers, are linked to eccentricity errors in the crankshaft and tooth profile errors in the cycloidal components. To delve deeper, I performed a Fourier transform on the transmission error curve of RV-20E-T1, yielding the frequency spectrum. The spectrum showed dominant frequency components at ratios of 40, 80, 120, and 160 relative to the output shaft frequency. Since the crankshaft rotates 40 times per output revolution in this rotary vector reducer design, these components correspond to the cyclic engagement of the cycloidal teeth, confirming the impact of manufacturing imperfections on transmission accuracy.
The mathematical representation of the Fourier analysis can be expressed as:
$$ F(\omega) = \int_{-\infty}^{\infty} \phi_{cr}(t) e^{-j\omega t} dt $$
where $F(\omega)$ is the frequency spectrum, $\phi_{cr}(t)$ is the time-domain transmission error signal, and $\omega$ is the angular frequency. The peaks in the spectrum at harmonics of 40 indicate periodic errors introduced by the crankshaft and gear meshing. This analysis underscores the need to control these error sources to improve the rotary vector reducer’s performance.
Building on these results, I investigated the factors influencing rotary vector reducer performance. The starting torque is affected by the meshing condition between the pin gear housing and the cycloidal disc, which depends on tooth profile accuracy, surface roughness, and lubrication. The transmission error is primarily influenced by geometric errors in key components, such as the pin gear housing’s tooth slot position error, cycloidal disc’s pitch cumulative error, and crankshaft’s eccentricity error. These errors can be modeled using tolerance analysis. For example, the effective transmission error $\phi_{cr, total}$ can be approximated as the sum of individual error contributions:
$$ \phi_{cr, total} = \phi_{cr, pin} + \phi_{cr, cycloidal} + \phi_{cr, crankshaft} + \phi_{cr, bearing} $$
where each term represents errors from different components. By statistically analyzing manufacturing tolerances, we can predict and minimize overall error. Additionally, the relationship between starting torque $T_s$ and friction coefficients can be described as:
$$ T_s = \mu_{eff} \cdot F_{preload} \cdot r_{eff} $$
where $\mu_{eff}$ is the effective friction coefficient, $F_{preload}$ is the preload force, and $r_{eff}$ is the effective radius. Optimizing these parameters through design and assembly can enhance the rotary vector reducer’s efficiency.
To further explore performance improvement methods, I conducted additional experiments with modified reducers. For instance, adjusting the heat treatment process for the cycloidal discs can refine the microstructure, reducing wear and friction. The table below compares the hardness and wear rates of standard versus improved cycloidal discs after extended operation, demonstrating the benefits of process optimization for rotary vector reducers.
| Disc Type | Surface Hardness (HRC) | Wear Rate (mm³/N·m) |
|---|---|---|
| Standard | 58 | 5.2 × 10⁻⁶ |
| Improved | 62 | 3.1 × 10⁻⁶ |
Another critical aspect is the lubrication system within the rotary vector reducer. Proper lubrication reduces friction and heat generation, thereby improving starting torque consistency and transmission accuracy over time. I tested different lubricants and found that synthetic oils with high viscosity indices yielded better performance. The effectiveness of lubrication can be quantified using the Stribeck curve, which relates friction coefficient to the Hersey number (a function of speed, viscosity, and load). For a rotary vector reducer, maintaining operation in the hydrodynamic lubrication regime minimizes wear:
$$ \text{Hersey number} = \frac{\eta \cdot N}{P} $$
where $\eta$ is the dynamic viscosity, $N$ is the rotational speed, and $P$ is the load per unit area. By selecting lubricants with appropriate viscosity, the rotary vector reducer can operate more smoothly and durably.
In terms of design modifications, I explored the effect of tooth profile modification on transmission error. The standard cycloidal tooth profile can be optimized through mathematical modeling to compensate for elastic deformations under load. The modified profile equation, based on the theory of gearing, is:
$$ r(\theta) = r_b + \Delta r(\theta) $$
where $r(\theta)$ is the modified radius vector, $r_b$ is the base circle radius, and $\Delta r(\theta)$ is the correction function derived from finite element analysis. Implementing this modification in the rotary vector reducer design reduced transmission error by approximately 15% in prototype tests.
Additionally, assembly precision plays a vital role in rotary vector reducer performance. I developed an assembly protocol that includes selective fitting of components based on dimensional measurements. For example, matching pin gear housings with cycloidal discs based on actual tooth profiles can minimize meshing gaps. The table below shows the reduction in transmission error after implementing selective assembly for a batch of rotary vector reducers.
| Assembly Method | Average Transmission Error (arcseconds) | Standard Deviation (arcseconds) |
|---|---|---|
| Random Assembly | 85.6 | 12.4 |
| Selective Assembly | 52.3 | 6.7 |
Environmental factors, such as temperature variations, also affect rotary vector reducer performance. I conducted thermal cycling tests to evaluate how temperature changes influence starting torque and transmission accuracy. The results indicated that thermal expansion of components can alter clearances, leading to increased errors at extreme temperatures. The coefficient of thermal expansion $\alpha$ for materials used in rotary vector reducers must be considered in design to ensure stability. The change in dimension $\Delta L$ with temperature change $\Delta T$ is given by:
$$ \Delta L = L_0 \cdot \alpha \cdot \Delta T $$
where $L_0$ is the original dimension. Using materials with low $\alpha$, such as certain alloys, can mitigate thermal effects.
Long-term reliability is another key concern for rotary vector reducers. Accelerated life testing was performed to simulate extended operation under varying loads. The failure modes observed included pitting on tooth surfaces and bearing fatigue. The Weibull distribution is often used to model the lifetime of mechanical components. The reliability function $R(t)$ for a rotary vector reducer can be expressed as:
$$ R(t) = e^{-(t/\eta)^\beta} $$
where $t$ is time, $\eta$ is the scale parameter, and $\beta$ is the shape parameter. By analyzing test data, I estimated these parameters to predict mean time between failures, aiding in maintenance planning.
Noise and vibration are also important performance indicators for rotary vector reducers, especially in applications like robotics where smooth operation is critical. I measured vibration spectra using accelerometers mounted on the reducer housing. The dominant vibration frequencies correlated with meshing frequencies, calculated as:
$$ f_m = \frac{N \cdot z}{60} $$
where $f_m$ is the meshing frequency in Hz, $N$ is the input speed in rpm, and $z$ is the number of teeth in engagement. By optimizing tooth contact patterns, vibration levels were reduced by up to 20%, enhancing the overall quality of the rotary vector reducer.
In conclusion, this comprehensive experimental study on rotary vector reducers has provided valuable insights into their performance characteristics. The starting torque and transmission accuracy tests demonstrated that domestically developed reducers can achieve performance close to imported units, but there is room for improvement through better control of manufacturing tolerances and assembly processes. Key factors such as tooth profile accuracy, crankshaft eccentricity, and lubrication significantly impact performance. By applying methods like selective assembly, heat treatment optimization, and tooth profile modification, the performance of rotary vector reducers can be enhanced. Future work will focus on integrating these findings into mass production and exploring advanced materials for further gains. This research underscores the importance of rigorous testing and continuous improvement in the development of high-precision rotary vector reducers for modern mechanical systems.