
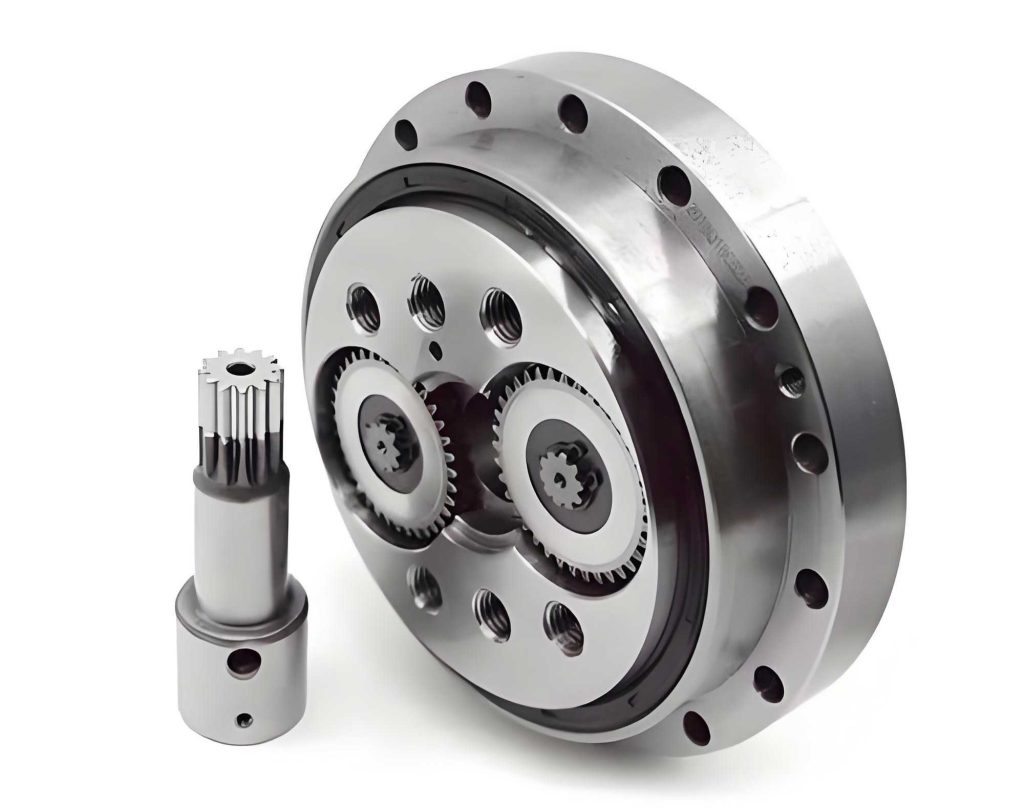
The rotary vector reducer is a critical precision transmission component widely employed in industrial robots, directly determining motion accuracy, operational stability, and long-term reliability. Its running stability is paramount, as it directly impacts the overall action efficiency and performance of the robotic system. With the rapid advancement of information processing technology, the automation level of electromechanical control equipment has significantly improved. This progress demands correspondingly higher standards for the operational monitoring and fault diagnosis of industrial robots. To meet these stringent requirements and achieve more accurate identification of fault signals in equipment utilizing rotary vector reducers, the introduction of sophisticated deep learning algorithms has become essential. Among various architectures, the Deep Belief Network (DBN) is particularly noteworthy for its capability to learn hierarchical representations from raw data. DBNs exhibit excellent time-varying characteristic modeling abilities, which can lead to a significant enhancement in fault diagnosis accuracy. This potential has attracted considerable research interest, yielding numerous promising results aimed at improving diagnostic precision and robustness under varying operational conditions.
The core challenge in fault diagnosis for complex mechanical systems like the rotary vector reducer lies in the non-stationary, noisy nature of vibration signals and the difficulty in obtaining large amounts of labeled fault data under all possible operating conditions. Traditional signal processing and shallow machine learning methods often struggle with these complexities. Deep learning models, particularly DBNs, offer a powerful solution by automatically extracting discriminative features from raw or minimally processed sensor data. For instance, improved DBN architectures integrated with attention mechanisms have been proposed to enhance diagnostic accuracy for gearboxes under variable working conditions by focusing on the most relevant signal components. Other approaches utilize transfer learning with DBNs, where a network pre-trained on abundant source domain data (e.g., from one type of reducer or operating condition) is fine-tuned with a small number of labeled samples from the target domain (a specific rotary vector reducer), thereby improving fault recognition accuracy and reducing the need for extensive target-specific data collection. Furthermore, optimizing the DBN training process with advanced optimizers like Adam has been shown to accelerate model convergence and improve classification performance. While these methods advance the field, diagnosis based on a single sensor measurement point remains susceptible to noise, sensor failure, or incomplete fault information from a single location on the machine.
To overcome the limitations of single-point analysis and create a more robust and reliable diagnostic system, this article elaborates on a comprehensive fault diagnosis methodology that synergistically combines multi-point vibration signal acquisition with a fusion framework based on the Dempster-Shafer (DS) evidence theory and Deep Belief Networks (DBN). The proposed DS-DBN multi-point fusion approach aims to leverage information from multiple physical locations on the rotary vector reducer to achieve near-perfect diagnostic accuracy. The general diagnostic process is illustrated in the following flowchart, showcasing the integration of multiple DBN models and DS fusion.
Methodology: The DS-DBN Multi-Point Fusion Framework
The proposed methodology is built upon a systematic architecture designed to handle the intricacies of multi-source information fusion for fault diagnosis. The process can be decomposed into several key stages: system architecture definition based on fault types, credibility assessment for each measurement point, initial basic probability assignment, and finally, evidence fusion for a consolidated diagnosis.
1. System Architecture and Confusion Matrix Formulation
The first step involves a thorough analysis of the rotary vector reducer to identify all potential fault types (e.g., bearing defects, gear wear, rotor imbalance, stator issues) and the normal operating state. For a problem with \( k \) distinct fault classes (including the “normal” state), a diagnostic system is established. To evaluate the performance of a classifier (like a DBN) on a given measurement point, the confusion matrix is a fundamental tool. Let \( r_{ij} \) represent the number of samples whose actual fault type is \( i \) but are predicted as class \( j \). The normalized confusion matrix element \( c_{ij} \) is calculated as the ratio of samples from actual class \( i \) predicted as class \( j \) to the total number of samples from class \( i \):
$$ c_{ij} = \frac{r_{ij}}{\sum_{j=1}^{k} r_{ij}} $$
Based on this, a \( k \)-dimensional confusion matrix \( \mathbf{Q} \) is constructed for each diagnostic model (tied to a specific sensor location). Each row vector \( \mathbf{c}_i \) represents the probability distribution of predictions across all fault classes when the true fault is \( i \). Conversely, each column vector \( \mathbf{c}^j \) indicates the proportion of samples from each true class that were predicted as fault \( j \).
$$ \mathbf{Q} = \begin{bmatrix}
c_{11} & c_{12} & \dots & c_{1k} \\
c_{21} & c_{22} & \dots & c_{2k} \\
\vdots & \vdots & \ddots & \vdots \\
c_{k1} & c_{k2} & \dots & c_{kk}
\end{bmatrix} $$
This matrix quantitatively captures the diagnostic strengths and weaknesses (e.g., misclassification patterns) of the model at a specific measurement point.
2. Credibility Evaluation Function for Measurement Points
Not all sensor locations provide equally reliable diagnostic information. Some points may be more sensitive to certain faults than others. Therefore, a credibility weight \( \gamma_\delta \) is assigned to each measurement point \( \delta \). This weight is derived from the point’s overall diagnostic accuracy \( Z_\delta \), which is calculated from its confusion matrix. Let \( T_i \) be the total number of test samples for fault type \( i \). The accuracy for point \( \delta \) is:
$$ Z_\delta = \frac{\sum_{i=1}^{k} (c_{ii}^{(\delta)} T_i)}{\sum_{j=1}^{k} T_j} $$
where \( c_{ii}^{(\delta)} \) is the diagonal element (true positive rate for class \( i \)) from the confusion matrix of point \( \delta \). The credibility weight \( \gamma_\delta \) is then computed by normalizing a scaled version of these accuracies across all \( \tau \) measurement points:
$$ \gamma_\delta = \frac{\sigma z_\delta}{\sum_{i=1}^{\tau} z_i} $$
Here, \( \sigma \) is a random value within the interval (0, 1), introduced to add a degree of stochasticity and prevent over-reliance on a rigid weighting scheme, potentially improving the fusion’s robustness. The term \( z_\delta \) is a standardized or processed version of \( Z_\delta \).
3. Initial Basic Probability Assignment (BPA)
The Dempster-Shafer theory requires a Basic Probability Assignment (BPA) function for each evidence source (each measurement point). For a point \( \delta \), the BPA for each fault hypothesis (e.g., “the fault is of type \( i \)”) is initialized based on the model’s output probability \( p_{\delta i} \) and an adjustment factor \( \omega_{\delta i} \). This factor can be derived from the confusion matrix, reflecting the historical reliability of the model at point \( \delta \) for diagnosing fault \( i \). The initial BPA mass \( p’_{\delta i} \) is calculated as:
$$ p’_{\delta i} = \frac{\omega_{\delta i} p_{\delta i}}{\sum_{i=1}^{k} \omega_{\delta i} p_{\delta i}} $$
This ensures the BPA for the set of all fault hypotheses sums to 1.
4. Evidence Fusion and Final Diagnosis
This is the core of the DS-DBN fusion stage. Each measurement point provides a body of evidence in the form of its BPA. However, evidence from different sensors may conflict (e.g., one point suggests a bearing fault, another suggests a gear fault). The DS combination rule is specifically designed to handle such conflicts by converging on the consensus while proportionally discounting conflicting evidence. The BPA for point \( \delta \), including its credibility weight \( \gamma_\delta \), is formulated as:
$$ m_\delta(\{f_1\}, \{f_2\}, \dots, \{f_k\}, \phi) = (\gamma_\delta p’_{\delta 1}, \gamma_\delta p’_{\delta 2}, \dots, \gamma_\delta p’_{\delta k}, 1-\gamma_\delta, 0) $$
Here, \( m_\delta(\{f_i\}) = \gamma_\delta p’_{\delta i} \) represents the belief mass assigned to the specific fault hypothesis \( f_i \) by point \( \delta \). The mass \( 1-\gamma_\delta \) is assigned to the universal set \( \phi \) (representing ignorance or uncertainty), and 0 mass is assigned to the empty set (conflict).
The Dempster’s rule is then applied iteratively to combine the BPAs from all \( \tau \) measurement points. For two independent sources of evidence with BPAs \( m_1 \) and \( m_2 \), the combined mass for a hypothesis \( A \) is given by:
$$ (m_1 \oplus m_2)(A) = \frac{1}{1-K} \sum_{B \cap C = A} m_1(B) m_2(C) $$
where \( K = \sum_{B \cap C = \emptyset} m_1(B) m_2(C) \) quantifies the total conflict between the two bodies of evidence. The factor \( 1/(1-K) \) serves as a normalization constant. This rule is associative, allowing for the sequential combination of all sensor evidences. The final output after fusing all \( m_\delta \) is a consolidated BPA that assigns belief masses to each fault hypothesis and the universal set. The fault hypothesis with the highest final belief mass is selected as the ultimate diagnosis for the rotary vector reducer. This multi-point, evidence-fusion approach significantly enhances diagnostic reliability compared to any single-point model.
Experimental Design and Data Acquisition
To validate the efficacy of the proposed DS-DBN multi-point fusion method, a rigorous experimental study was conducted. The test platform centered on an industrial robot rotary vector reducer (model analogous to Y160M2-8). The key to multi-point analysis is strategic sensor placement. Four vibration sensors were deployed at distinct, mechanically significant locations on the reducer assembly to capture diverse dynamic responses: one at the input coupling section (Connection Point), one on the reducer housing near the input side (Head Position), one on the housing near the output side (Tail Position), and one on the mounting base (Base). This configuration ensures a comprehensive capture of vibration propagation paths through the rotary vector reducer structure.
Vibration signals were acquired under various pre-defined health states of the reducer, including normal operation, rotor-related faults, stator-related faults, and several bearing defect scenarios (e.g., inner/outer race defects, rolling element defects). A high sampling frequency of 10 kHz was used with a sampling interval of 0.0001 seconds to adequately capture high-frequency transient components associated with incipient faults. The raw time-domain signals for different states exhibit clear visual differences in amplitude and pattern. More importantly, their frequency-domain representations, obtained via Fast Fourier Transform (FFT), show distinct peaks and active frequency bands corresponding to different fault types, providing a rich feature set for the DBN models to learn from. The following table summarizes the experimental parameters.
| Parameter | Specification |
|---|---|
| Reducer Type | Industrial Robot Rotary Vector Reducer |
| Number of Measurement Points | 4 |
| Sensor Locations | Connection Point, Head, Tail, Base |
| Fault States | Normal, Rotor Fault, Stator Fault, Bearing Faults |
| Sampling Frequency | 10 kHz |
| Sampling Interval | 0.0001 s |
| Signal Type | Vibration Acceleration |
Performance Evaluation of the Rotary Vector Reducer Fault Diagnosis
The performance evaluation focuses on two primary aspects: the optimization and convergence behavior of the individual DBN models at each measurement point within the DS-DBN framework, and the ultimate diagnostic accuracy achieved through DS evidence fusion.
1. Model Training and Parameter Optimization
Separate DBN models were constructed and trained for each of the four measurement points. The training process involved learning hierarchical features from the preprocessed vibration data (e.g., normalized frequency spectra or time-frequency representations). The optimization trajectory, measured by the classification error on a validation set, was monitored. As shown conceptually in the convergence plot, the classification error for all four DS-DBN models decreased significantly during the initial training phases. The error reduction rate gradually slowed in the later stages until convergence was achieved. Remarkably, all four models reached a stable convergence state within 30 training epochs. The final classification errors for the models at Point 1, Point 2, Point 3, and Point 4 were 2.07%, 3.78%, 3.96%, and 3.41%, respectively. All errors were below the 5% threshold, demonstrating that the DBNs, guided by the overall DS-DBN framework’s objective, were able to rapidly identify near-global optimal parameters for feature extraction and classification specific to their sensor location on the rotary vector reducer.
2. Diagnostic Accuracy: Single-Point vs. Multi-Point Fusion
The primary metric for evaluating diagnostic performance is the classification accuracy \( A \). It is calculated considering the correct identification of both normal and various fault states:
$$ \text{Accuracy} = \frac{n_{11}T_1 + \sum_{i=2}^{k} (f_{ii} T_i)}{\sum_{i=1}^{k} T_i} $$
where:
- \( n_{11} \) is the proportion of correctly identified normal state samples,
- \( f_{ii} \) is the proportion of correctly identified samples for fault state \( i \),
- \( T_1 \) is the total number of normal state samples,
- \( T_i \) is the total number of samples for fault state \( i \).
The diagnostic results for each individual measurement point and for the final DS-fused output are summarized in the table below. The results clearly illustrate the power of information fusion. While each single measurement point already performs commendably, with accuracies for various states ranging from approximately 96.6% to 99.4%, they are not flawless. However, after applying the DS evidence theory to synergistically combine the diagnostic outputs from all four points, the fused system achieves a remarkable leap in performance. The diagnosis accuracy for normal state, rotor faults, and stator faults is elevated to nearly 100%. The accuracy for the more challenging bearing-related faults is also boosted to over 99.5%. This demonstrates that the multi-point DS-DBN fusion approach effectively resolves uncertainties and conflicts present in single-source evidence, leading to an extremely reliable and accurate fault diagnosis system for the industrial robot rotary vector reducer.
| Diagnosis Method | Normal State | Stator Fault | Rotor Fault | Bearing Fault | Rolling Element Fault |
|---|---|---|---|---|---|
| Measurement Point 1 | 0.994 | 0.982 | 0.988 | 0.989 | 0.982 |
| Measurement Point 2 | 0.993 | 0.975 | 0.976 | 0.966 | 0.983 |
| Measurement Point 3 | 0.985 | 0.984 | 0.979 | 0.971 | 0.986 |
| Measurement Point 4 | 0.989 | 0.981 | 0.985 | 0.975 | 0.983 |
| DS Evidence Fusion | 0.999 | 0.999 | 1.000 | 0.999 | 0.995 |
Discussion and Comparative Analysis
The outstanding results obtained validate the DS-DBN multi-point fusion approach as a superior paradigm for rotary vector reducer fault diagnosis. To contextualize this advancement, it is useful to compare it against other common diagnostic strategies. Traditional methods relying on handcrafted features (e.g., statistical moments, spectral kurtosis) combined with classifiers like Support Vector Machines (SVM) often require extensive domain expertise for feature selection and may not generalize well under varying loads or speeds. Standard deep learning approaches using a single, complex network fed with data from multiple concatenated sensors can suffer from the curse of dimensionality, require more training data, and be less interpretable regarding the contribution of individual measurement points.
The proposed framework offers distinct advantages. First, by employing separate DBNs per measurement point, it allows for the learning of location-specific fault signatures, making the system inherently modular and easier to train. Second, the DS evidence theory provides a mathematically rigorous framework to handle the inherent uncertainty, imprecision, and conflict in real-world multi-sensor data. The credibility weighting mechanism ensures that more reliable sensors contribute more strongly to the final decision. Third, the system’s robustness is enhanced; the failure or degradation of one sensor does not catastrophically fail the entire system, as evidence from the remaining points can still yield a reasonable diagnosis.
| Approach | Key Principle | Advantages | Limitations |
|---|---|---|---|
| Traditional Signal Processing + Shallow ML | Manual feature extraction + SVM/ANN | Interpretable features, lower computational cost for inference. | Feature engineering is labor-intensive, performance limited by chosen features, poor adaptability to new conditions. |
| Single-Point Deep Learning (e.g., DBN, CNN) | Automatic feature learning from one sensor’s data. | Reduces need for manual feature engineering, good performance for specific point. | Vulnerable to sensor-specific noise/failure, may miss faults manifesting elsewhere. |
| Data-Level Multi-Sensor Fusion (Early Fusion) | Concatenating raw/processed data from all sensors into one input vector for a single model. | Potentially uses all available information directly. | High input dimensionality, difficult to train, model may not learn spatial/topological relationships well. |
| Proposed DS-DBN Multi-Point Fusion (Decision-Level Fusion) | Separate DBNs per point + DS theory fusion of their decisions. | Robust to sensor failure, models location-specific patterns, handles evidence conflict formally, achieves near-perfect accuracy. | Higher initial training complexity (multiple models), requires a validation set to establish credibility weights. |
Conclusion and Future Perspectives
This article has presented a detailed exposition of a sophisticated fault diagnosis methodology for industrial robot rotary vector reducers, based on the fusion of Deep Belief Networks and Dempster-Shafer evidence theory across multiple measurement points. The DS-DBN framework systematically addresses the challenges of accurate and reliable diagnosis by leveraging complementary information from spatially distributed sensors. The experimental validation confirms two major outcomes: Firstly, the individual DBN models for each measurement point converge rapidly and effectively, achieving low classification errors (all below 5%) within 30 training epochs, indicating efficient learning of optimal diagnostic parameters. Secondly, and most significantly, the DS evidence fusion layer dramatically enhances the overall system performance. Compared to relying on any single measurement point, the fused diagnosis boosts the accuracy for key fault states—normal, rotor, and stator faults—to nearly 100%, while pushing bearing fault diagnosis accuracy above 99.5%. This represents a substantial advancement towards fail-safe condition monitoring.
The implementation of such a high-performance diagnostic system for the rotary vector reducer carries profound practical implications. It enables the early and precise detection of incipient faults, facilitating predictive maintenance strategies. This directly contributes to minimizing unplanned downtime, extending the service life of expensive robotic components, preventing catastrophic failures, and ultimately reducing the total economic cost of ownership for industrial automation systems. Future research directions may focus on further optimizing the DBN architectures (e.g., using convolutional or recurrent layers for better temporal feature extraction), automating the credibility weight adaptation online as sensor conditions change, and extending the fusion framework to incorporate other data modalities such as temperature or acoustic emissions for an even more comprehensive health assessment of the rotary vector reducer.
| Aspect | Result / Contribution | Impact |
|---|---|---|
| Model Convergence | All 4 point-specific DBNs converged within 30 epochs with error < 5%. | Demonstrates efficient and stable training of the network components. |
| Single-Point Accuracy | High individual accuracy (96.6% – 99.4% across states/points). | Confirms DBN’s strong capability for automatic fault feature learning from vibration data. |
| Fusion Accuracy Gain | DS fusion increased accuracy to ~100% for major faults and >99.5% for bearing faults. | Highlights the critical value of multi-sensor information fusion, resolving conflicts and uncertainties. |
| Methodological Robustness | Decision-level fusion with credibility weighting. | Enhances system reliability against single-sensor noise or failure. |
| Practical Outcome | Enables precise, early fault detection in rotary vector reducers. | Supports predictive maintenance, reduces downtime and costs, extends equipment life. |