
In the field of industrial robotics, precision reducers play a critical role in ensuring accurate and efficient motion control. Among these, the RV reducer stands out due to its compact design, high torque capacity, and excellent positioning accuracy. As a mechanical engineer specializing in gear systems, I have often encountered the RV reducer in applications such as robotic joints, where its performance is paramount. In this article, I will delve into the kinematics of the RV reducer, analyzing its motion principles, deriving transmission ratios for various configurations, and summarizing the kinematic relationships of its components. This exploration aims to provide a comprehensive understanding that can aid in design, analysis, and optimization efforts. The RV reducer’s unique structure, which combines a differential gear train with a cycloidal pinwheel mechanism, makes its kinematics both fascinating and complex. By breaking down these elements, I hope to clarify how motion is transferred and controlled within the RV reducer, emphasizing key formulas and tables for practical reference.
The RV reducer, short for Rotary Vector reducer, is widely used in articulated industrial robots, accounting for approximately 60% of the global market for joint reducers. Its advantages include small size, light weight, long service life, high precision, substantial stiffness, a broad transmission ratio range, and high transmission efficiency. To understand its kinematics, we must first examine its composition and motion transfer process. The RV reducer consists of two main planetary transmission parts that form a closed differential gear train, rather than being simply connected in series or parallel. This configuration is key to its performance. In essence, the RV reducer integrates a differential gear train section—comprising an input gear, planet gears, and a planet carrier—with a closed cycloidal pinwheel planetary transmission section—consisting of crankshafts, cycloidal gears, pinwheels, and a pin housing. These sections are interconnected through fixed couplings and an equiangular velocity transmission mechanism, resulting in a system with one degree of freedom. The motion transfer begins when the input gear rotates, engaging the planet gears to spin. Since the planet gears are fixed to the crankshafts, their rotation drives the crankshafts, causing the cycloidal gears to revolve. As the cycloidal gears revolve, they mesh with the pinwheels, leading to rotation. This rotation is then transmitted back to the planet carrier via the crankshafts, establishing a determinate motion with specific angular velocity relationships. Throughout this process, components like the planet gears, crankshafts, and cycloidal gears exhibit both rotation and revolution, adding layers of complexity to the kinematic analysis.
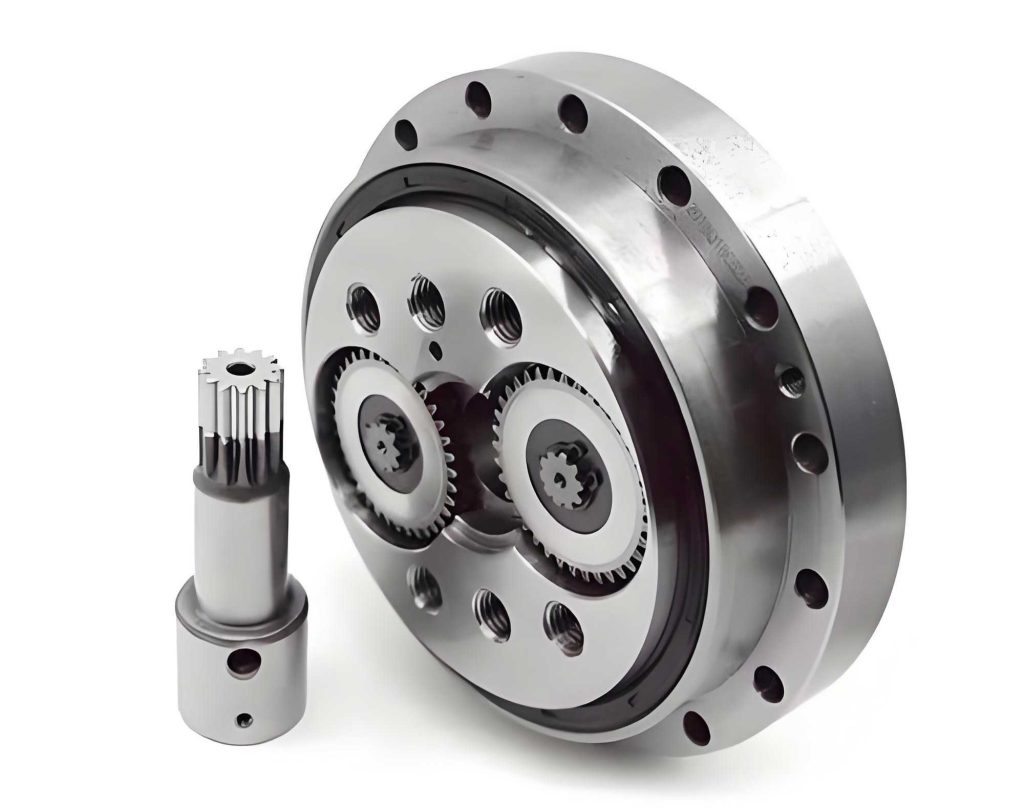
To visualize the RV reducer’s structure, consider a schematic representation that highlights its key parts: the input gear (serving as the input shaft), planet gears, crankshafts, cycloidal gears, pinwheels, a pin housing (often fixed as the frame), and a planet carrier (serving as the output shaft). In a typical setup, the pin housing is stationary, the input gear receives motion, and the planet carrier delivers output. However, alternative installations are possible, affecting the transmission ratio and direction. The planet carrier is positioned on both sides of the cycloidal gears, with holes in the cycloidal gears allowing the carrier to pass through. This design ensures stability and compactness. From a kinematic perspective, we can establish a fixed coordinate system with its origin at the center of the pin housing. In this frame, the planet carrier acts as the connecting rod for the planet gears, meaning their revolution speed matches the carrier’s angular velocity. Similarly, the crankshafts serve as the connecting rods for the cycloidal gears, as their rotation speed corresponds to the revolution of the cycloidal gear centers. The equiangular velocity transmission mechanism—formed by the planet carrier, crankshafts, and cycloidal gears—ensures that the planet carrier’s angular velocity equals the cycloidal gear’s rotation speed. This mechanism relies on parallel linkages, such as parallelogram arrangements, to maintain synchronized motion. Understanding these roles is crucial for deriving the RV reducer’s kinematic equations.
Now, let’s analyze the motion principles in detail. The differential gear train section functions as a planetary gear mechanism. Here, the planet carrier is the connecting rod, denoted as \( H’ \), the input gear as gear 1, and the planet gears as gear 2. With external meshing between gear 1 and gear 2, the transmission ratio of the converted mechanism is given by:
$$ i^{H’}_{12} = \frac{\omega_1 – \omega_{H’}}{\omega_2 – \omega_{H’}} = -\frac{z_2}{z_1} $$
where \( \omega_1 \) is the angular velocity of the input gear, \( \omega_2 \) is the angular velocity of the planet gears (i.e., their absolute rotation speed), \( \omega_{H’} \) is the angular velocity of the planet carrier, \( z_1 \) is the number of teeth on the input gear, and \( z_2 \) is the number of teeth on the planet gears. The negative sign indicates opposite rotation directions in the converted frame. Next, the closed section is a cycloidal pinwheel planetary transmission. In this part, the crankshafts act as the connecting rod, denoted as \( H” \), the cycloidal gears as gear 3, and the pinwheels (along with the pin housing) as gear 4. With internal meshing between gear 3 and gear 4, the transmission ratio of the converted mechanism is:
$$ i^{H”}_{34} = \frac{\omega_3 – \omega_{H”}}{\omega_4 – \omega_{H”}} = \frac{z_4}{z_3} $$
where \( \omega_3 \) is the angular velocity of the cycloidal gears, \( \omega_4 \) is the angular velocity of the pin housing, \( \omega_{H”} \) is the angular velocity of the crankshafts, \( z_3 \) is the number of teeth on the cycloidal gears, and \( z_4 \) is the number of teeth on the pinwheels. In RV reducers, the relationship \( z_4 = z_3 + 1 \) typically holds, enhancing reduction capabilities. The two sections are linked through two critical connections: first, the planet gears are fixed to the crankshafts, so \( \omega_2 = \omega_{H”} \); second, the equiangular velocity transmission mechanism ensures \( \omega_{H’} = \omega_3 \). By combining these equations, we can derive the overall transmission ratios for different installation methods of the RV reducer.
The transmission ratio of the RV reducer depends on which component is fixed, which serves as input, and which as output. Using the formulas above, we can solve for various configurations. For instance, when the pin housing is fixed (\( \omega_4 = 0 \)), the input gear is driven (\( \omega_1 \)), and the planet carrier outputs (\( \omega_{H’} \)), the transmission ratio is:
$$ i_{1H’} = \frac{\omega_1}{\omega_{H’}} = 1 + \frac{z_2}{z_1} \cdot z_4 $$
This positive ratio indicates that the input gear and planet carrier rotate in the same direction. If the planet carrier is fixed (\( \omega_{H’} = 0 \)), the input gear is driven (\( \omega_1 \)), and the pin housing outputs (\( \omega_4 \)), the transmission ratio becomes:
$$ i_{14} = \frac{\omega_1}{\omega_4} = -\frac{z_2}{z_1} \cdot z_4 $$
Here, the negative sign shows opposite rotation directions between input and output. Alternatively, with the input gear fixed (\( \omega_1 = 0 \)), the pin housing is driven (\( \omega_4 \)), and the planet carrier outputs (\( \omega_{H’} \)), the transmission ratio is:
$$ i_{4H’} = \frac{\omega_4}{\omega_{H’}} = 1 + \frac{z_1}{z_2} \cdot \frac{1}{z_4} $$
which is positive, indicating concurrent rotation. To illustrate, consider an example RV reducer model, RV-320E-201, with \( z_1 = 14 \), \( z_2 = 70 \), and \( z_4 = 40 \). Plugging these values into the formulas yields \( i_{1H’} = 201 \), \( i_{14} = -200 \), and \( i_{4H’} \approx 1.005 \). These ratios highlight the RV reducer’s ability to achieve high reduction factors, making it ideal for robotic applications requiring precise motion control. The derivations emphasize the importance of gear tooth counts in determining performance, and engineers can use these equations to tailor RV reducer designs for specific needs.
Beyond transmission ratios, the kinematic relationships among moving parts are vital for understanding the RV reducer’s behavior, especially in force analysis. For the common setup with fixed pin housing, input gear drive, and planet carrier output, we can express the angular velocities of all components in terms of the input speed \( \omega_1 \). Using the derived equations, we obtain the following relationships summarized in Table 1. This table shows both rotation and revolution speeds, where rotation refers to absolute angular velocity about a component’s own axis, and revolution refers to the angular velocity of its center about the fixed frame origin. These distinctions are crucial when analyzing forces and moments within the RV reducer.
| Component | Rotation Angular Velocity | Revolution Angular Velocity |
|---|---|---|
| Planet Gears and Crankshafts | \( \omega_2 = -\left( \frac{\omega_1}{i_{1H’}} \right) \cdot z_3 \) | \( \omega_{H’} = \frac{\omega_1}{i_{1H’}} \) |
| Cycloidal Gears | \( \omega_3 = \frac{\omega_1}{i_{1H’}} \) | \( \omega_{H”} = -\left( \frac{\omega_1}{i_{1H’}} \right) \cdot z_3 \) |
| Planet Carrier | \( \omega_{H’} = \frac{\omega_1}{i_{1H’}} \) | N/A (output axis) |
| Pin Housing | \( \omega_4 = 0 \) | N/A (fixed) |
In this table, \( i_{1H’} = 1 + \frac{z_2}{z_1} \cdot z_4 \) and \( z_3 = z_4 – 1 \). For the RV-320E-201 example, with \( \omega_1 = 201 \) rad/s (or any unit), the rotation speed of planet gears is \( -39 \) rad/s, and their revolution speed is \( 1 \) rad/s. This means the planet gears rotate clockwise while revolving counterclockwise, assuming input gear rotation is counterclockwise. Similarly, the cycloidal gears rotate counterclockwise at \( 1 \) rad/s while revolving clockwise at \( 39 \) rad/s. The planet carrier rotates counterclockwise at \( 1 \) rad/s. These relationships reveal that the cycloidal gear’s rotation equals the planet carrier’s speed, and its revolution equals the planet gear’s rotation. This constraint, imposed by the closed differential system, ensures synchronized motion. Additionally, relative speeds between components are important for bearing selection and lubrication analysis. For instance, the relative speed between the crankshafts and cycloidal gears (via needle bearings) is \( \omega_2 – \omega_3 = -\left( \frac{\omega_1}{i_{1H’}} \right) \cdot z_4 \), and between crankshafts and planet carrier (via roller bearings) is \( \omega_2 – \omega_{H’} = -\left( \frac{\omega_1}{i_{1H’}} \right) \cdot z_4 \). In the example, both are \( -40 \) rad/s, indicating significant internal motion that affects wear and efficiency.
The kinematics of the RV reducer also involves the motion of the meshing point between cycloidal gears and pinwheels, denoted as point P. This point lies on the line connecting the pin housing center O and the cycloidal gear center \( O_c \), with distances satisfying \( \overline{OP} / \overline{O_cP} = z_3 \). In force analysis, point P is critical because it represents the contact where forces are transmitted. Its motion relative to the fixed frame is characterized by the revolution speed of the cycloidal gear center, i.e., \( \omega_{H”} = -\left( \frac{\omega_1}{i_{1H’}} \right) \cdot z_3 \). As point P moves, the angular positions of components change accordingly. For a given rotation angle \( \theta \) of point P about O, we can derive the corresponding angles for other parts, as shown in Table 2. This table helps in understanding phase relationships and timing in gear meshing, which is essential for durability studies and noise reduction in the RV reducer.
| Component | Rotation Angle | Revolution Angle |
|---|---|---|
| Planet Gears and Crankshafts | \( \theta \) | \( -\theta / z_3 \) |
| Cycloidal Gears | \( -\theta / z_3 \) | \( \theta \) |
| Point P (relative to O) | N/A | \( \theta \) |
From this, when point P revolves by \( \theta \), the planet carrier rotates by \( -\theta / z_3 \), and the crankshafts rotate relative to the cycloidal gears by \( \theta – (-\theta / z_3) = (\theta / z_3) \cdot z_4 \). For the RV-320E-201 reducer, with \( z_3 = 39 \) and \( z_4 = 40 \), if point P revolves by 9°, the cycloidal gear revolves by 9°, the crankshafts rotate by 9°, and the cycloidal gear rotates by approximately -0.23°. This means that every 9° revolution of point P, a new pinwheel and cycloidal gear tooth pair come into symmetric meshing position, ensuring smooth force transmission. Over a full 360° revolution of point P, the crankshafts complete about 369.23° relative to the cycloidal gears, highlighting the high reduction effect. Such detailed kinematic insights are invaluable for optimizing tooth profiles and load distribution in RV reducer design.
In addition to the basic relationships, we can explore the kinematics of the RV reducer through velocity and acceleration analysis. For instance, the linear velocities of key points, such as the centers of planet gears or cycloidal gears, can be derived from angular velocities. If we denote the distance from the fixed center O to the planet gear center as \( r_H \) (the radius of the planet carrier), then the linear velocity of the planet gear center is \( v = \omega_{H’} \cdot r_H \). Similarly, for the cycloidal gear center, the velocity is \( v_c = \omega_{H”} \cdot r_c \), where \( r_c \) is the offset distance. These velocities influence inertial forces and dynamic balancing in the RV reducer. Acceleration components, including centripetal and tangential accelerations, can be calculated using standard rotational dynamics formulas. For example, the centripetal acceleration of a planet gear center is \( a_c = \omega_{H’}^2 \cdot r_H \), and its tangential acceleration is \( a_t = \alpha_{H’} \cdot r_H \), where \( \alpha_{H’} \) is the angular acceleration of the planet carrier. In high-speed applications, these accelerations must be considered to prevent excessive vibrations and ensure longevity of the RV reducer. By incorporating such analyses, engineers can better predict performance under varying operational conditions.
Another kinematic aspect worth noting is the efficiency of the RV reducer, which relates to motion losses due to friction and meshing. While efficiency is not purely kinematic, it depends on speed ratios and relative motions. The overall efficiency \( \eta \) can be estimated using formulas that account for gear meshing efficiencies \( \eta_1 \) and \( \eta_2 \) for the differential and cycloidal sections, respectively. For the fixed pin housing configuration, the efficiency might be approximated as \( \eta = \eta_1 \cdot \eta_2 \), though detailed models consider power flow and losses in bearings. Kinematically, the relative speeds from Table 1 affect friction losses; for instance, higher relative speeds in bearings lead to greater heat generation. Thus, understanding kinematics aids in thermal analysis and lubrication design for the RV reducer. Moreover, the RV reducer’s compactness often requires careful management of internal clearances and tolerances, which kinematic simulations can help optimize by predicting motion paths and potential interferences.
The versatility of the RV reducer allows for various installation modes, each with distinct kinematic implications. Table 3 summarizes the transmission ratios and directionalities for common configurations, derived from the fundamental equations. This table serves as a quick reference for designers selecting an RV reducer for specific robotic or mechanical systems. It underscores how the same physical RV reducer can yield different reduction factors and output directions simply by changing fixed and driven components, enhancing its adaptability in diverse applications.
| Fixed Component | Input Component | Output Component | Transmission Ratio Formula | Direction Relationship |
|---|---|---|---|---|
| Pin Housing | Input Gear | Planet Carrier | \( i_{1H’} = 1 + \frac{z_2}{z_1} \cdot z_4 \) | Same direction |
| Planet Carrier | Input Gear | Pin Housing | \( i_{14} = -\frac{z_2}{z_1} \cdot z_4 \) | Opposite direction |
| Input Gear | Pin Housing | Planet Carrier | \( i_{4H’} = 1 + \frac{z_1}{z_2} \cdot \frac{1}{z_4} \) | Same direction |
In practice, the choice of installation depends on space constraints, torque requirements, and desired motion output. For example, in robotic arms, the fixed pin housing setup is common because it provides high reduction and stable mounting. The kinematic analysis presented here enables engineers to calculate speeds and torques accurately, ensuring the RV reducer meets performance targets. Furthermore, with the rise of digital twins and simulation software, these kinematic models can be integrated into virtual prototypes to test dynamic behavior before physical manufacturing, reducing development time and cost for RV reducer-based systems.
To deepen the kinematic analysis, we can also examine the RV reducer’s motion through vector methods. By representing positions and velocities as vectors in the fixed coordinate system, we can derive comprehensive equations for all moving points. For instance, the position vector of a planet gear center can be expressed as \( \mathbf{r}_H = r_H (\cos(\omega_{H’} t), \sin(\omega_{H’} t)) \), and its velocity vector as \( \mathbf{v}_H = \omega_{H’} r_H (-\sin(\omega_{H’} t), \cos(\omega_{H’} t)) \). Similarly, for a point on the cycloidal gear profile, parametric equations based on cycloidal curves can describe its path relative to the pinwheels. These vector formulations are useful for advanced simulations and tolerance analysis, particularly in ensuring that the RV reducer maintains precision over millions of cycles. They also facilitate the study of load distribution across multiple teeth, which is key to achieving the high stiffness that the RV reducer is known for.
In conclusion, the kinematics of the RV reducer is a rich topic that combines principles from gear theory, planetary systems, and cycloidal mechanisms. Through this article, I have analyzed its motion principles, emphasizing the closed differential structure that integrates a planetary gear train with a cycloidal pinwheel transmission. Deriving transmission ratios for various installations provides practical formulas for engineers, while summarizing kinematic relationships in tables offers clear insights into component motions. The motion of the meshing point and relative speeds are particularly relevant for force analysis and durability assessments. As the RV reducer continues to be a cornerstone in robotics and precision machinery, a thorough understanding of its kinematics will aid in innovation and optimization. Future work may explore dynamic effects, thermal behavior, or advanced materials, but the foundational kinematic relationships discussed here will remain essential. By leveraging these insights, designers can harness the full potential of the RV reducer, ensuring reliable and efficient performance in demanding applications.
Ultimately, the RV reducer exemplifies how clever mechanical design can achieve high performance in a compact package. Its kinematics not only define its function but also inspire further advancements in reduction technology. Whether used in industrial robots, aerospace mechanisms, or medical devices, the RV reducer’s motion characteristics must be well-understood to maximize its benefits. I hope this detailed exploration serves as a valuable resource for engineers and researchers working with this remarkable device, fostering continued improvement and application of the RV reducer across industries.