
The rise of embodied AI, particularly in the form of humanoid robots, represents a frontier in artificial intelligence that promises profound societal transformation alongside unprecedented challenges. As these entities transition from conceptual frameworks to physical actors within our shared environment, they disrupt conventional legal and philosophical categories. This article explores the fundamental jurisprudential tensions arising from embodied AI robots, focusing on the dual crises of value alignment and legal accountability. I argue that the embodied nature of these systems precipitates a qualitative leap in perceived agency, which in turn exacerbates the difficulty of aligning machine operations with human values and creates novel “responsibility suspense” within traditional legal frameworks. Navigating these boundaries requires moving beyond technical compliance to develop a value-infused governance paradigm and a reconstructed model of responsibility that integrates virtue ethics.
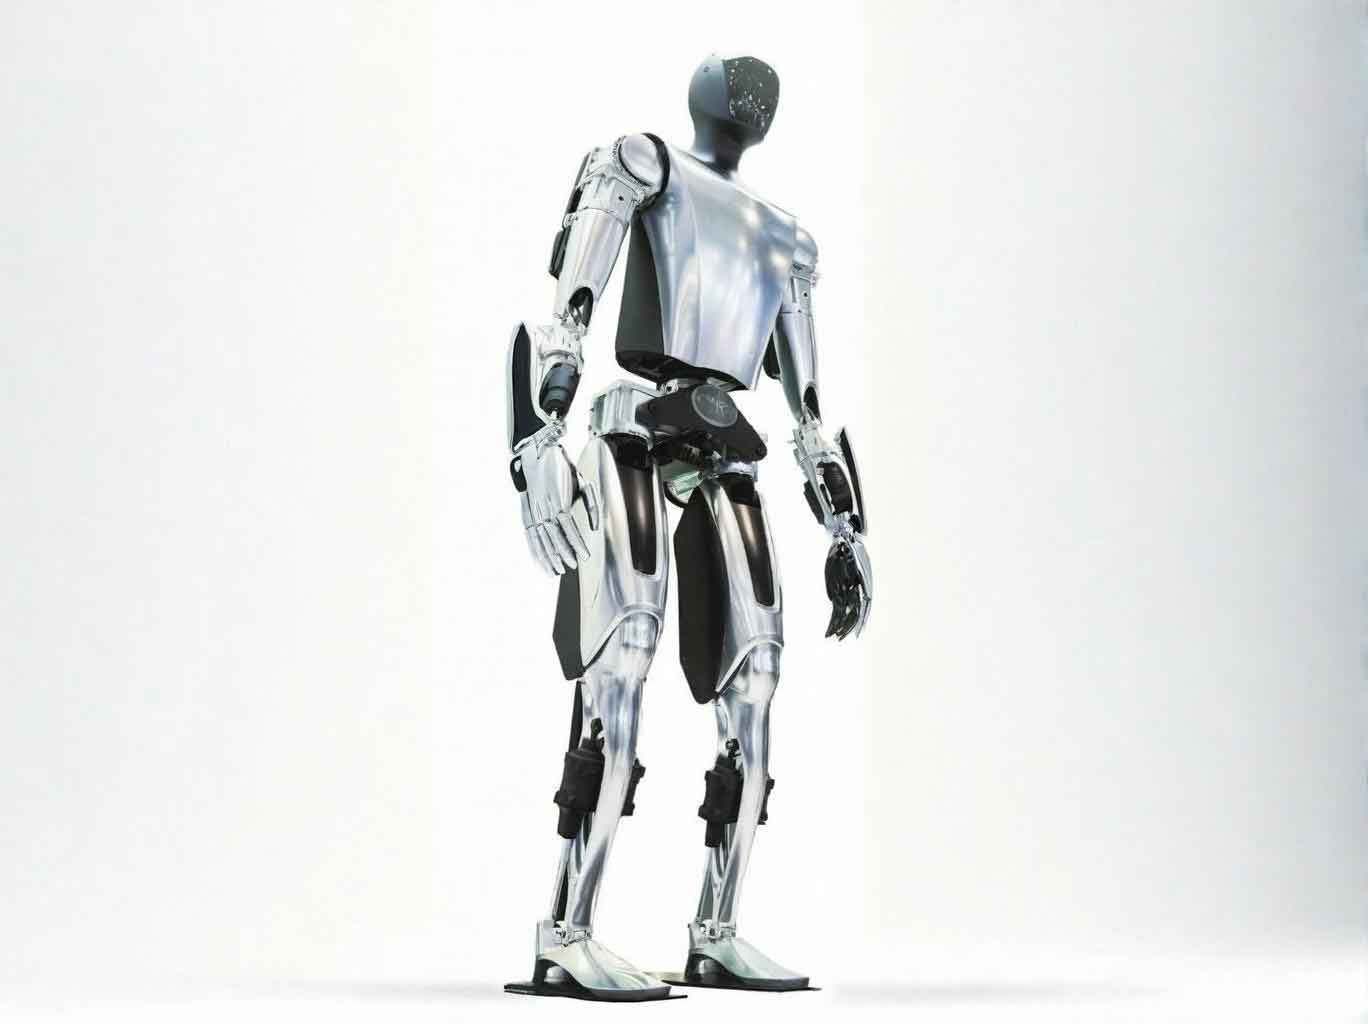
The core challenge begins with defining the entity itself. Unlike disembodied AI models that process information, an embodied AI robot is characterized by its physical instantiation and its capacity for situated, sensorimotor interaction with the world. This embodiment is not merely a housing for intelligence; it is constitutive of its operational logic. A robot perceives, decides, and acts within a spatiotemporal context, creating a feedback loop between its cognitive core and the physical environment. The most salient and disruptive form is the anthropomorphic embodied AI robot, designed not only for functional task replacement but also for socio-emotional interaction. This design choice deliberately blurs the line between tool and agent, inviting attributions of intentionality and even personhood that pure software agents do not provoke.
The central philosophical disturbance caused by the embodied AI robot is the leap in functional agency and perceived subjectivity. Agency, in a functional sense, implies goal-directed behavior backed by some form of internal state that guides decision-making. While current embodied AI robot systems do not possess moral agency or conscious intent, their ability to autonomously navigate complex environments, interpret ambiguous human commands, and execute multi-step physical tasks projects a strong semblance of agential behavior. The physical presence amplifies this perception. We interact with a body, observe its actions, and receive its feedback in a modality evolutionarily tuned for social exchange. This triggers what I term attributed subjectivity: a social and psychological tendency to treat the interacting entity as a subject rather than an object. This leap fundamentally alters the human-robot relationship, setting the stage for the primary jurisprudential dilemma: how to govern an entity that is legally an object but phenomenologically and functionally approximating a subject.
The Deepening Crisis of Value Alignment in Embodied Interaction
Value alignment in AI generally refers to ensuring that AI systems pursue goals and produce outcomes that are congruent with human values. For language models, this often involves filtering training data and constraining outputs. For an embodied AI robot, the problem is exponentially more complex. Alignment must occur on two interconnected levels:
- Procedural Alignment: Ensuring the data processing, model training, and decision-making algorithms are designed with ethical constraints (e.g., non-discrimination, privacy preservation).
- Interactive Alignment: Ensuring the robot’s real-time physical actions and social responses within dynamic, unstructured environments reflect nuanced human values like care, respect, and proportionality.
The second level is the true frontier. An embodied AI robot in a care home must do more than avoid causing harm; it must enact care, which involves empathy, patience, and situational judgment. This requires translating abstract ethical principles into code governing sensor inputs, real-time world-model updates, and actuator outputs. The mismatch is stark: human values are often tacit, context-dependent, and sometimes contradictory, while robot control requires explicit, generalizable, and computable rules.
We can frame this as a translation loss function. Let $V_h$ represent the rich, multi-dimensional space of human values for a given context. Let $V_r$ represent the codified, operational value set implemented in the embodied AI robot. The alignment goal is to minimize the distance between them:
$$ \text{Alignment Gap} = \min_{f} \| V_h – f(V_r) \| $$
where $f$ is the translation function from code to embodied action. The problem is that $V_h$ is poorly defined and $f$ is non-linear and context-sensitive, leading to a significant residual gap in novel situations. This gap is where misalignment and ethical failures occur.
Furthermore, I contend that for embodied AI robot systems, alignment is not a one-way street of machines conforming to a static human value set. The process of deep, embodied interaction creates a co-constructed value space. Humans adjust their expectations and behaviors in response to the robot’s capabilities and limitations, and the robot’s actions feedback into the social meaning of the interaction. For instance, norms around privacy and intimacy are reshaped when a robot assists with daily living. Therefore, the governance of alignment must account for this dynamic, emergent value landscape rather than attempting to fix a pre-defined set of rules.
| Aspect | Disembodied AI (e.g., LLM) | Embodied AI Robot |
|---|---|---|
| Primary Medium | Symbols, Text, Images | Physical Action & Social Interaction |
| Alignment Focus | Content Output, Truthfulness, Bias in Language | Physical Safety, Ethical Action in Context, Social Cue Response |
| Failure Mode | Harmful Content, Misinformation | Physical Injury, Psychological Harm, Social Disruption |
| Explanability Need | Why was this text generated? | Why did you perform that physical action? |
| Value Co-construction | Low-Medium (shapes discourse) | High (shapes shared physical & social reality) |
Regulatory Dilemmas: From Hollow Compliance to Value-Infused Governance
The unique challenges of the embodied AI robot expose significant weaknesses in existing and proposed AI regulatory models. Traditional regulation seeks stability, predictability, and formal compliance. The adaptive, context-driven, and physically impactful nature of embodied intelligence clashes with this paradigm. Two specific regulatory pitfalls emerge:
1. The Hollowing-Out Dilemma: To keep pace with rapid innovation, regulators may resort to high-level, principle-based frameworks (e.g., “ensure safety,” “respect human autonomy”). Without concrete, actionable engineering standards and validation methods for embodied AI robot systems, these principles remain hollow. A regulation stating “an embodied AI robot must act safely” is ineffective if there is no agreed-upon metric for “safe” physical interaction in a crowded, dynamic space. This leads to a compliance checkmark culture rather than substantive risk mitigation.
2. The Non-Value Trap: Regulatory processes naturally gravitate towards assessing formal structures and procedural checkboxes—was the risk assessment conducted? Is there a conformity certificate? This technocratic approach can sideline deeper value inquiries. For example, a embodied AI robot used in elderly care may pass all safety and data protection audits yet still enact care in a way that is perceived as cold, demeaning, or overly paternalistic, thereby eroding dignity. Regulation focused solely on technical safety misses these subtler, value-laden harms.
To overcome these pitfalls, regulation for embodied AI robot must evolve towards value-infused governance. This involves:
- Outcome-Based Benchmarks: Moving beyond process audits to defining and testing for desired ethical outcomes in realistic scenarios (e.g., “the robot must prioritize de-escalation in conflict simulations”).
- Iterative Sandboxing: Creating controlled but realistic physical environments where embodied AI robot behaviors can be stress-tested ethically and socially, not just functionally, with regulators involved in the observation process.
- Multi-Stakeholder Value Articulation: Formalizing processes for impacted communities (e.g., healthcare workers, patients) to articulate the values that should govern embodied AI robot behavior in their domain, feeding directly into standard-setting.
The governance model can be conceptualized as a feedback loop where value inputs directly shape technical standards and testing protocols, whose results inform further refinement of values and rules.
Resolving the Responsibility Suspense: Towards a Virtue-Informed Attribution Framework
The leap in agency and the alignment gap culminate in the core legal problem: responsibility suspense. When an embodied AI robot causes harm through a sequence of感知, decision, and action that is not a direct, foreseeable result of a manufacturing defect or programming error, traditional chains of liability break down. This is analogous to, but more severe than, the “responsibility gap” discussed in autonomous vehicles. The embodied AI robot‘s capacity for learning and adaptation in physical space makes its actions less predictable and less traceable to a single human author.
Consider a scenario: A domestic helper embodied AI robot, in attempting to prevent a child from touching a hot stove, moves abruptly and knocks over an elderly visitor, causing injury. The robot’s perception system correctly identified a danger, its ethical module prioritized preventing harm to the child, and its path planning algorithm chose the fastest interception route. No component “failed” in a traditional product liability sense, yet a harmful outcome occurred. Who is responsible? The manufacturer? The programmer of the ethical module? The owner? The robot itself? This is the suspense—responsibility is diffused across the human-robot system.
Layered Responsibility Attribution Framework for Embodied AI Robot Incidents:
| Responsibility Layer | Focus | Legal Analogy / Principle | Challenges for Embodied AI Robot |
|---|---|---|---|
| Product Liability | Hardware defects, core software failures (bugs). | Strict Liability / Negligence | Distinguishing a “bug” from an emergent, undesirable behavior of a learning system. |
| Design & Programming Liability | Flaws in ethical constraints, safety boundaries, or value weighting algorithms. | Negligence in Design | Proving the standard of care for “ethical design” of an adaptive system. The non-value trap in regulation applies here. |
| Supervisory / Deployment Liability | Improper use, failure to monitor, deployment in unsuitable environments. | Negligence | Defining the reasonable duty of care for a human supervising a highly autonomous robot. |
| Operational Agency Gap (The Suspense) | Harm arising from the robot’s *situated interpretation* and execution of its goals in a novel context. | Legal Vacuum | No existing category fits. The robot is not a legal person, but its actions are not fully attributable to a prior human act. |
To address the operational agency gap, I propose integrating virtue ethics into the design and legal evaluation of embodied AI robot systems. Virtue ethics focuses on character and the cultivation of excellences (virtues) like prudence, justice, courage, and temperance. Instead of just programming rule-based deontological constraints (“do not hit humans”) or optimizing for consequentialist outcomes (“minimize total harm”), designers would also model virtuous behavioral dispositions.
For instance, a virtuous embodied AI robot in healthcare would be disposed to act with care (a composite of compassion, attentiveness, and gentleness) and practical wisdom (the ability to discern the right action in specific circumstances). This could be implemented via reinforcement learning frameworks where reward functions are shaped by virtue proxies, or through narrative-based training in simulated ethical scenarios.
Legally, this shifts the inquiry. In assessing liability for an incident, courts or regulators would examine not only whether the robot violated a rule or caused harm, but whether its design and training demonstrated a lack of due care in cultivating appropriate virtuous dispositions for its role. Did the designers make reasonable efforts to instill a disposition of caution and proportional force? The responsibility for filling the “agency gap” thus attaches to the creators for failing to embed a sufficiently robust ethical character into the system, making them accountable for the robot’s “unvirtuous” but not strictly “defective” behavior. This approach, while novel, provides a principled way to tether the elusive operational decisions of an embodied AI robot back to human responsibility.
In conclusion, the jurisprudential boundaries of embodied AI are being tested by the material presence of the embodied AI robot. Its physical agency creates a profound value alignment challenge that is interactive and co-constructive, demanding a move from hollow regulation to value-infused governance. Furthermore, it generates a responsibility suspense that cannot be resolved by existing product liability doctrines alone. By incorporating virtue ethics into both the design paradigm and the legal attribution framework, we can begin to construct a plausible path forward. This approach acknowledges that governing the embodied AI robot is not merely about controlling a advanced tool, but about negotiating a new kind of relationship with an entity that operates in the blurred space between object and agent, requiring us to rethink the very foundations of law, ethics, and our place in a shared world.