
The development of robotics represents a pinnacle of modern technological advancement. Among various robotic architectures, the bionic robot, particularly those inspired by arthropods, has garnered significant attention for operations in unstructured and hazardous environments. Tasks such as search and rescue post-disaster, planetary exploration, military reconnaissance, and environmental monitoring demand platforms with exceptional terrain adaptability, stability, and autonomous decision-making capabilities. The hexapod bionic robot, mimicking the locomotion of insects, meets these demands through its inherent static stability, flexible gait patterns, and superior obstacle-crossing ability. This article delves into the comprehensive structural analysis and evaluation of a hexapod bionic robot, focusing on its mechanical integrity via detailed finite element analysis (FEA) to validate and inform its design.
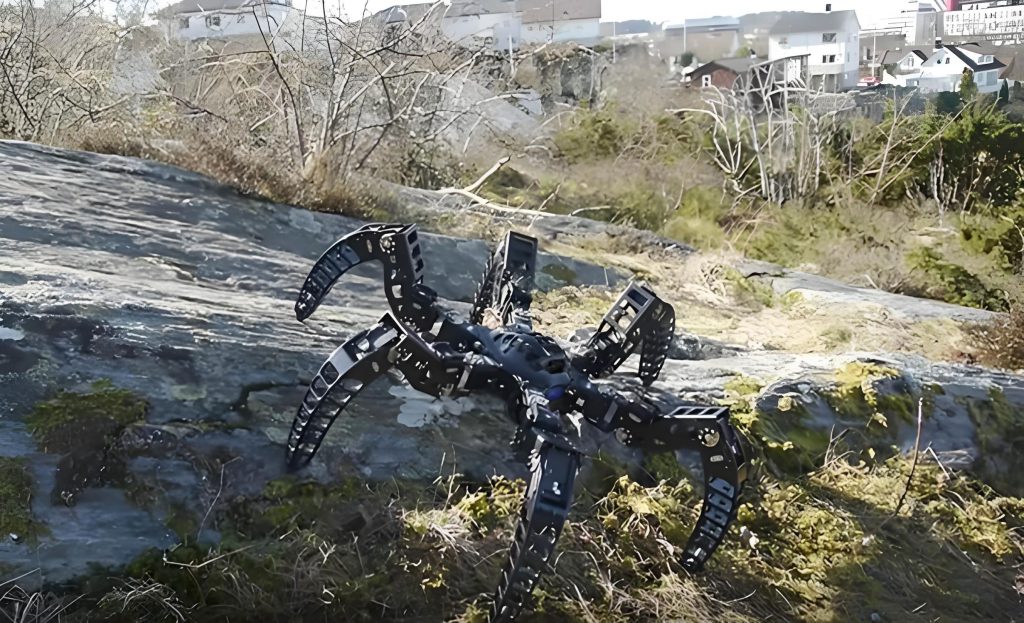
The core mechanical design of the discussed hexapod bionic robot comprises three main subsystems: a locomotion system with six independent legs, a payload and control housing, and optional front-mounted manipulators for interaction. The locomotion system is paramount, employing 18 high-torque servo motors—three per leg—to actuate the three primary joints: the coxa (root), femur (hip), and tibia (knee). Each leg segment (coxa, femur, tibia) rotates around its respective joint, providing the necessary degrees of freedom for complex leg trajectories. The robot utilizes a tripod gait for efficient and stable locomotion, where three legs (front-right, middle-left, rear-right) form one supporting triangle while the other three swing forward, alternating in a coordinated cycle. This biologically inspired gait grants the bionic robot remarkable stability even on rough terrain.
The key performance specifications for the initial design of this hexapod bionic robot are summarized in the table below. These parameters set the baseline for load-bearing requirements and operational scope, which directly influence the structural analysis.
| Parameter | Value | Unit |
|---|---|---|
| Total Mass | 15 | kg |
| Dimensions (L×W×H) | 700 × 700 × 350 | mm |
| Rated Payload Capacity | 10 | kg |
| Total Power | 120 | W |
| Speed Range | 0.1 – 5 | m/s |
Kinematic and Static Model Foundation
Prior to structural analysis, a fundamental understanding of the forces and kinematics is essential. The static analysis of a bionic robot often simplifies the dynamic conditions into worst-case loading scenarios. For a hexapod in a stationary, load-bearing pose (e.g., standing with full payload), the force equilibrium for the entire body can be expressed as:
$$
\sum_{i=1}^{6} \vec{F}_{ground,i} + \vec{W}_{robot} + \vec{W}_{payload} = 0
$$
$$
\sum_{i=1}^{6} (\vec{r}_i \times \vec{F}_{ground,i}) + \vec{M}_{ext} = 0
$$
where $\vec{F}_{ground,i}$ is the ground reaction force on the $i$-th foot, $\vec{W}_{robot}$ and $\vec{W}_{payload}$ are the weight vectors of the robot and its payload, $\vec{r}_i$ is the position vector from the center of mass to the $i$-th foot contact point, and $\vec{M}_{ext}$ represents external moments.
For an idealized tripod stance with symmetric load distribution on a flat surface, the vertical force on each supporting leg ($F_z$) can be approximated by:
$$
F_z \approx \frac{(m_{robot} + m_{payload}) \cdot g}{n_{support}}
$$
where $g$ is gravitational acceleration (9.81 m/s²) and $n_{support}$ is the number of legs in the supporting phase (3 for a tripod gait). With the given masses, this results in a significant load per leg, which is then transmitted through the joint actuators and links, creating internal moments and stresses. The torque $\tau_j$ required at a given joint $j$ to hold a static position is a function of the link geometry and the load:
$$
\tau_j = \vec{r}_{j, \: com} \times \vec{F}_{link} + \sum \vec{r}_{j, \: load} \times \vec{F}_{external}
$$
These transmitted forces and torques form the boundary conditions for the finite element analysis of individual components.
Finite Element Analysis of Critical Components
The structural integrity of the bionic robot hinges on key load-bearing components. Using a detailed 3D model created in CATIA, critical parts were isolated, meshed, and analyzed in ANSYS Mechanical under appropriate constraints and loads. The primary material assumed for structural parts is Aluminum Alloy 6061-T6, with properties as listed:
| Material Property | Aluminum 6061-T6 | Unit |
|---|---|---|
| Density ($\rho$) | 2700 | kg/m³ |
| Young’s Modulus (E) | 68.9 | GPa |
| Poisson’s Ratio ($\nu$) | 0.33 | – |
| Yield Strength ($\sigma_y$) | 275 | MPa |
| Ultimate Tensile Strength | 310 | MPa |
The von Mises stress criterion is used to evaluate the yield failure for ductile materials, calculated as:
$$
\sigma_{vm} = \sqrt{ \frac{(\sigma_{11}-\sigma_{22})^2 + (\sigma_{22}-\sigma_{33})^2 + (\sigma_{33}-\sigma_{11})^2 + 6(\sigma_{12}^2+\sigma_{23}^2+\sigma_{31}^2) }{2} }
$$
A safety factor ($n$) is then determined by:
$$
n = \frac{\sigma_y}{\sigma_{vm, \: max}}
$$
1. Analysis of the Upper Load-Bearing Plate
This plate forms the main chassis, connecting the body to the leg shoulder joints and supporting the internal payload. The boundary conditions simulate the reaction forces from all six coxa joints while the plate is subjected to the combined weight of the internal components and the external payload, approximated as a uniformly distributed pressure. The fixed support points are applied at the six coxa joint mounting holes.
The results indicate a maximum deformation of approximately 0.0138 mm at the plate’s center. The maximum von Mises stress is around 1.43 MPa. Given the high yield strength of Aluminum 6061, the safety factor is exceedingly high, confirming this component is over-designed under these static conditions and could potentially be lightweighted for this bionic robot.
2. Analysis of the Femur (Hip) Link (Critical Component)
The femur link acts as a cantilever beam, transmitting forces from the tibia and the ground reaction force up to the coxa and body. It is one of the most highly stressed components in a walking bionic robot. For analysis, the proximal end (connected to the coxa joint) is fixed, while a concentrated force of 240 N (simulating a high dynamic load during motion) is applied at the distal end (knee joint connection) at a worst-case angle.
The FEA results reveal significant deflection and stress concentration. The maximum deformation reaches 0.0724 mm at the free end. More critically, the maximum von Mises stress is found to be 16.5 MPa. While this value is still below the yield strength, the relatively high stress and observed deflection indicate low stiffness and a potential fatigue risk point. The safety factor is reduced compared to the main plate. This identifies the femur as a prime candidate for structural optimization in the hexapod bionic robot design.
3. Analysis of the Servo Mount and Lower Axle
This component houses the servo motor and connects the leg segments. The base of the mount is fixed, and a force representing the transmission load from the leg (10 N) is applied. The analysis shows minimal deformation, on the order of 3.32e-4 mm, and a very low maximum von Mises stress of approximately 0.017 MPa. This component, under the modeled loads, is well within the safe operating limits and does not require immediate redesign for this iteration of the bionic robot.
The comparison of the three analyzed components is summarized below:
| Component | Max Deformation (mm) | Max von Mises Stress (MPa) | Safety Factor (n) | Assessment |
|---|---|---|---|---|
| Upper Load-Bearing Plate | 0.0138 | 1.43 | ~192 | Over-designed, can be optimized for weight. |
| Femur (Hip) Link | 0.0724 | 16.50 | ~16.7 | Moderate stress, low stiffness. Key optimization target. |
| Servo Mount & Axle | 3.32e-4 | 0.017 | ~16,176 | Very robust under analysis loads. |
Proposed Structural Optimization Strategies
Based on the FEA results, targeted optimization can enhance the performance-to-weight ratio of the bionic robot. Optimization in engineering design often involves formulating an objective function subject to constraints. A common formulation for lightweight design is:
$$
\text{Minimize: } m(\vec{x}) = \rho \cdot V(\vec{x})
$$
$$
\text{Subject to: } \sigma_{vm}(\vec{x}) \leq \frac{\sigma_y}{n_{required}}, \quad \delta_{max}(\vec{x}) \leq \delta_{allowable}, \quad \vec{x}_{L} \leq \vec{x} \leq \vec{x}_{U}
$$
where $\vec{x}$ is the vector of design variables (e.g., thicknesses, diameters), $V$ is volume, and $\vec{x}_{L}, \vec{x}_{U}$ are lower and upper bounds.
For the Upper Plate: Topology or size optimization can be performed. The goal is to reduce material while maintaining connection points and global stiffness. Introducing ribs, strategic cutouts, or employing a sandwich composite structure could significantly reduce mass without compromising the bionic robot’s core functionality.
For the Femur Link: This is the critical component. Several approaches can be taken:
1. Shape Optimization: Modifying the cross-section from a simple rectangular bar to an I-beam or C-channel increases the area moment of inertia ($I$), which directly improves bending stiffness ($\delta \propto 1/EI$) without a linear increase in mass.
2. Material Change: Replacing aluminum with carbon fiber reinforced polymer (CFRP) offers a higher specific stiffness (E/ρ). However, cost and connection design complexity increase.
3. Local Reinforcement: Adding gussets or double-wall support (as hinted in the original analysis) at the connection points, especially where stress concentrates, effectively reduces peak stress and local deformation. This is often a practical and cost-effective solution for a prototype bionic robot.
4. Size Optimization: Parameterizing the link’s thickness and width and running a design of experiments (DOE) within the FEA environment to find the Pareto-optimal set between mass and stiffness.
A comparative table of potential materials for the femur link illustrates the trade-offs:
| Material | Density (kg/m³) | Young’s Modulus (GPa) | Specific Stiffness (E/ρ) [MN·m/kg] | Cost & Manufacturability |
|---|---|---|---|---|
| Aluminum 6061-T6 | 2700 | 68.9 | 25.5 | Low, Excellent |
| Titanium Ti-6Al-4V | 4430 | 113.8 | 25.7 | Very High, Difficult |
| Steel AISI 1040 | 7850 | 200 | 25.5 | Low, Excellent |
| CFRP (Unidirectional) | 1550 | 120-150* | 77.4-96.8* | High, Specialized |
*Directional properties; value is longitudinal.
Integration with Control System Dynamics
The structural analysis provides a static snapshot, but a functioning hexapod bionic robot operates under dynamic conditions. The interaction between structural flexibility (compliance) and the control system is crucial. A flexible link can be modeled as a Euler-Bernoulli beam for control purposes. The simplified equation of motion for a cantilevered link undergoing small vibrations is:
$$
EI \frac{\partial^4 w(x,t)}{\partial x^4} + \rho A \frac{\partial^2 w(x,t)}{\partial t^2} = f(x,t)
$$
where $w(x,t)$ is the transverse deflection, $A$ is the cross-sectional area, and $f(x,t)$ is the applied force distribution.
Structural modes can interfere with high-bandwidth position control of the joints. If the first natural frequency of a leg link ($\omega_n$) is not sufficiently higher than the servo controller’s bandwidth ($\omega_{BW}$), it can lead to instability or resonant vibrations. A rule of thumb is $\omega_n > 3-5 \times \omega_{BW}$. The natural frequency for a cantilever beam with an end mass (the distal part of the leg) is approximated by:
$$
f_n = \frac{1}{2\pi} \sqrt{\frac{3EI}{L^3 (m_{link} + 0.24 m_{end})}}
$$
where $L$ is the link length, $m_{link}$ is its mass, and $m_{end}$ is the mass at the free end. Optimizing the femur for stiffness directly increases $EI$, thereby raising $f_n$ and improving the dynamic response of the entire bionic robot.
Conclusion and Future Work
The systematic finite element analysis of the hexapod bionic robot’s key structural components has successfully validated the overall design integrity under static loads while identifying critical areas for improvement. The upper chassis plate demonstrates significant potential for weight reduction, which is vital for enhancing the bionic robot’s energy efficiency and payload-to-weight ratio. The femur link, identified as the most critical component, requires targeted stiffening through shape optimization, local reinforcement, or advanced material selection to ensure long-term durability and precise dynamic control.
Future work will involve implementing these optimization proposals and re-running the FEA for validation. Furthermore, transient dynamic analysis simulating the full gait cycle, including impact forces, should be conducted to capture more realistic stress histories for fatigue life prediction. Multi-body dynamic simulation (MBD) coupled with control system modeling will provide a holistic view of the bionic robot’s performance, bridging the gap between structural mechanics and robotic locomotion intelligence. This iterative process of design, analysis, and optimization is fundamental to advancing the capabilities and reliability of next-generation hexapod bionic robots for demanding real-world applications.