
In this paper, I present a first-person account of our systematic investigation into integrating humanoid robot technology into the course “Digital Electronics Technology” for teaching reform. The work focuses on strategies, practical implementation, and evaluation of a curriculum that bridges cutting-edge robotics with fundamental digital logic design. I begin by discussing the significance of this fusion and its implications for cultivating interdisciplinary talents. Then, I analyze the intrinsic relationship between humanoid robot architecture and digital electronic principles, followed by a diagnosis of existing pedagogical problems. After establishing clear objectives and guiding principles, I detail a comprehensive set of reform measures covering content optimization, methodological innovation, and assessment redesign. A comparative case study is presented to demonstrate the effectiveness of these reforms, using quantitative data and qualitative observations. Finally, I reflect on the remaining challenges and propose future directions. Throughout the article, I emphasize the repeated keyword humanoid robot to underline how this emerging technology can transform a traditionally abstract course into an engaging, hands-on learning experience.
1. Introduction and Background
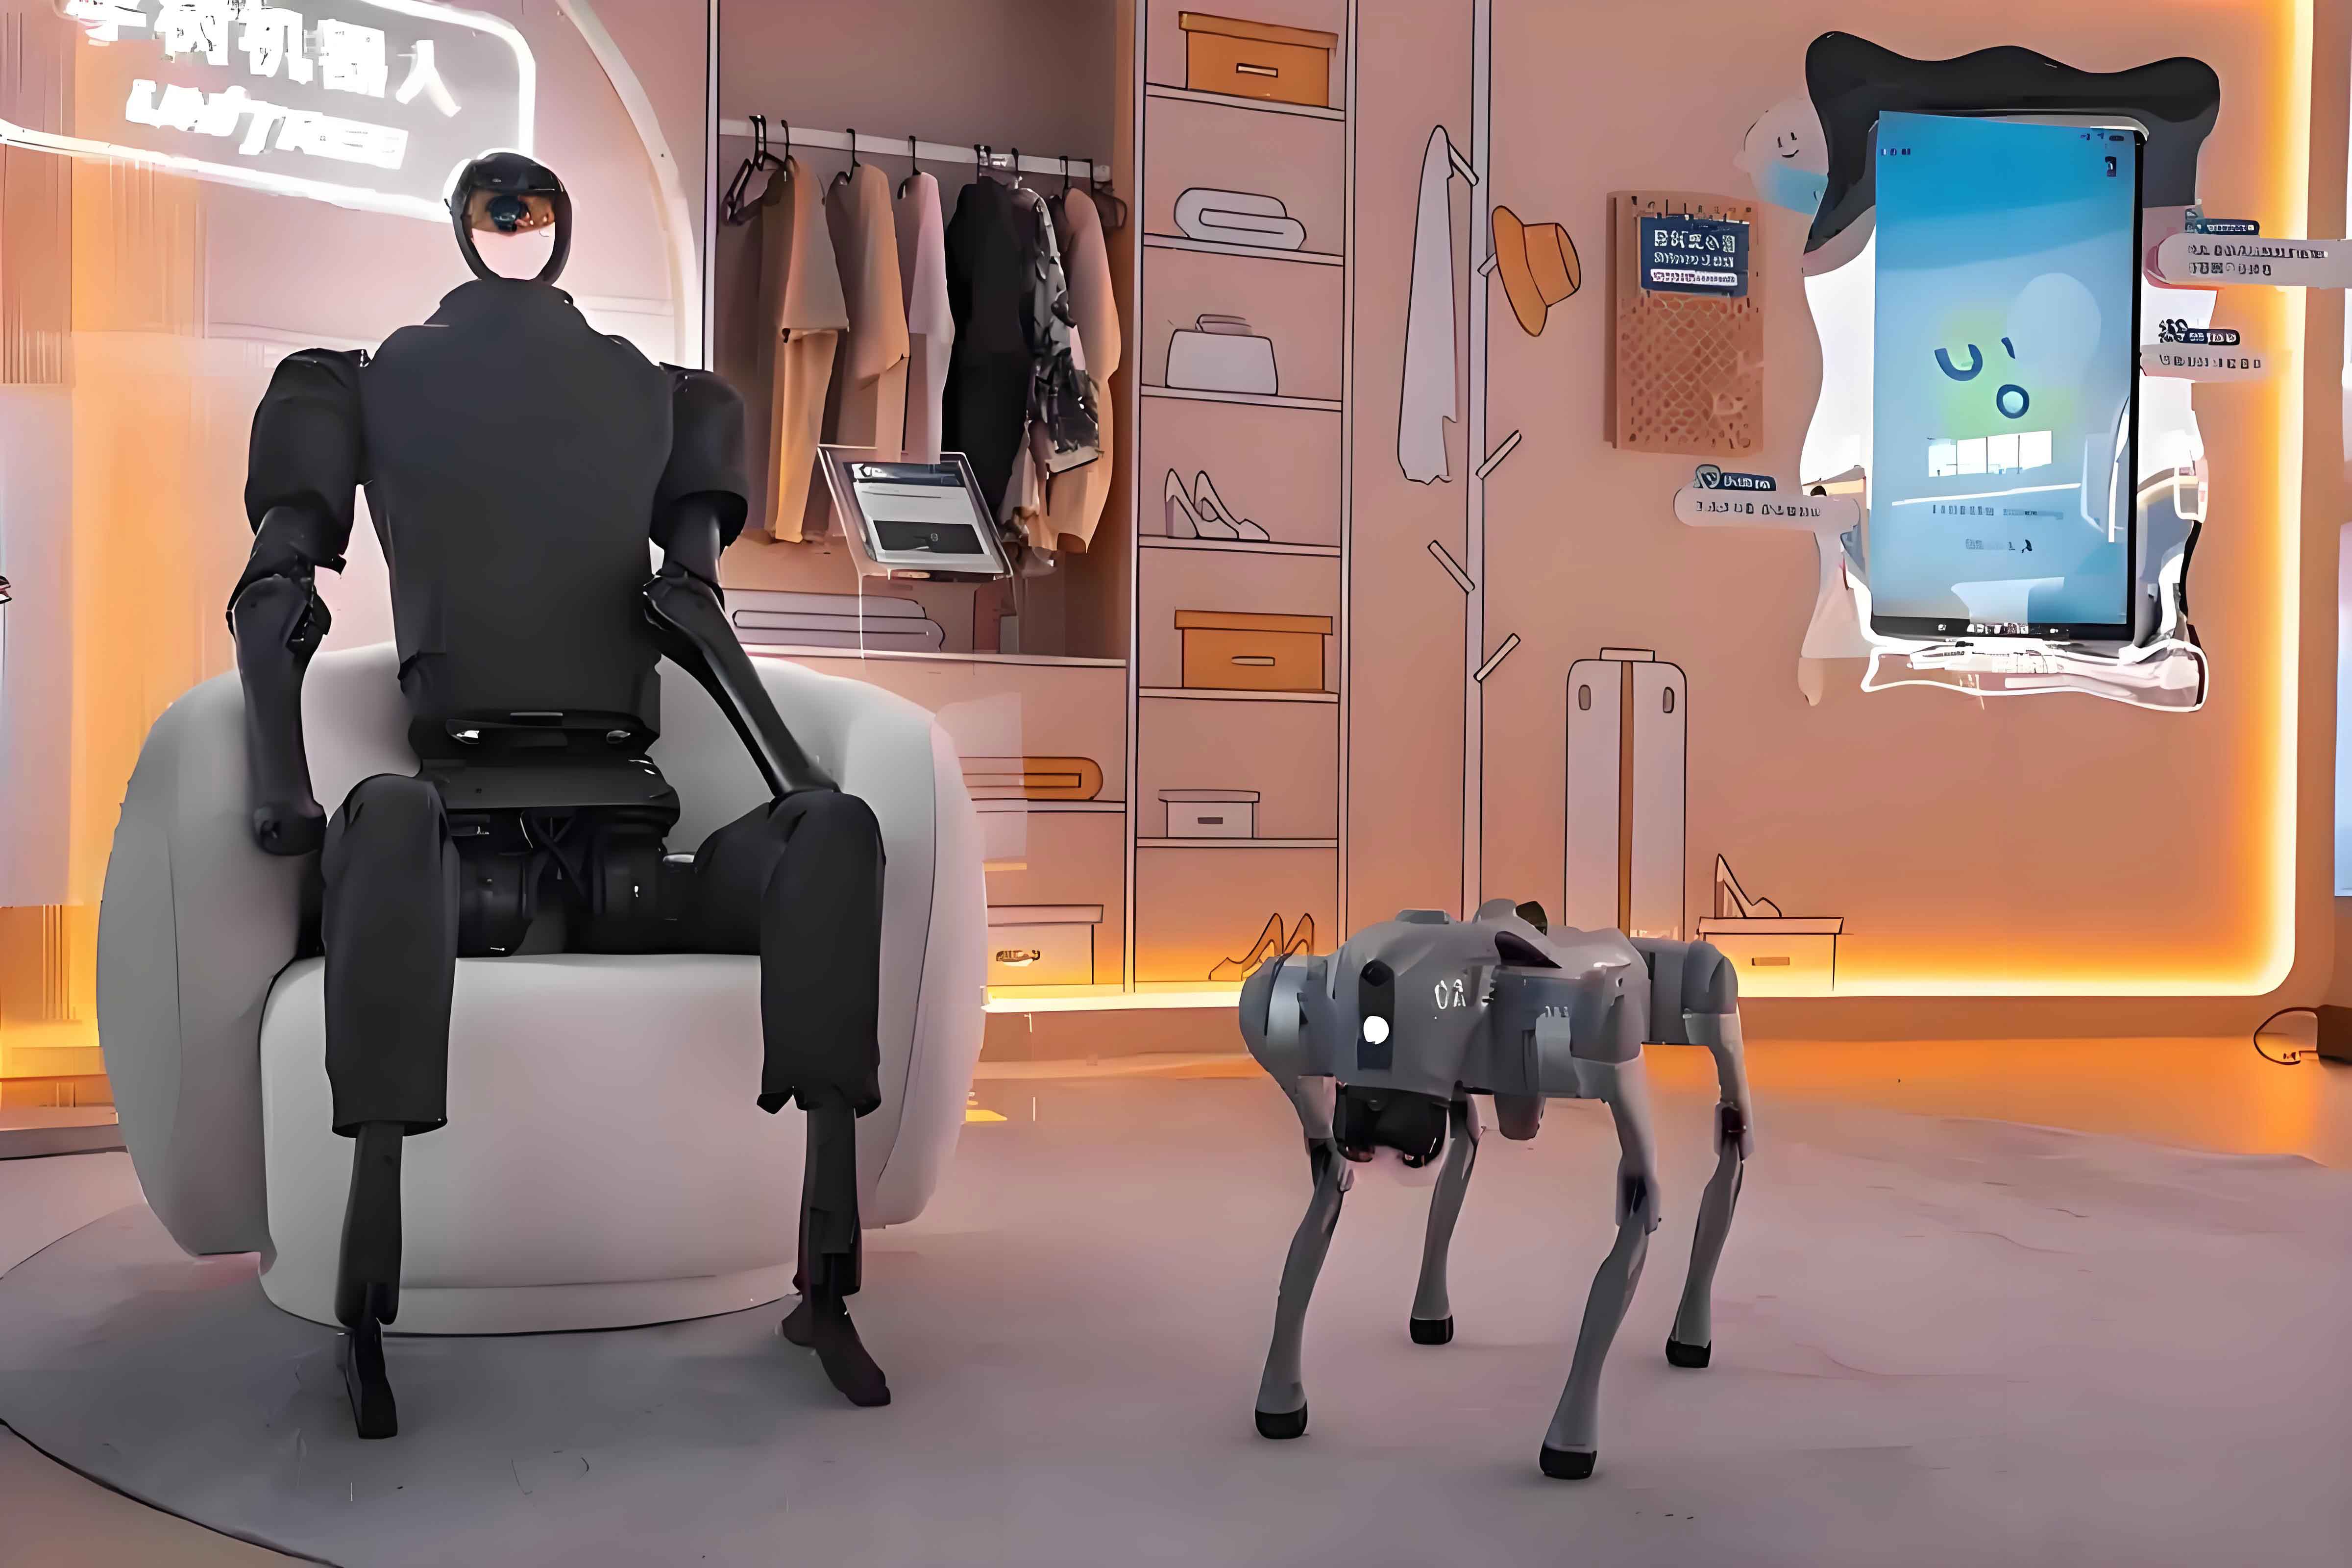
The rapid evolution of humanoid robots has become one of the most striking technological phenomena of our era. These sophisticated machines integrate mechanical engineering, electronic information technology, computer science, artificial intelligence, and many other disciplines. As a result, they are not only icons of innovation but also powerful platforms for education. The humanoid robot embodies a perfect blend of hardware and software, requiring precise control, real-time signal processing, and robust decision-making — all of which are deeply rooted in digital electronics.
“Digital Electronics Technology” is a fundamental core course for students majoring in electronic information and related fields. It provides the logical foundation for modern computing, embedded systems, and automated control. However, in its traditional form, the course often focuses heavily on theoretical derivations and isolated circuit experiments, leaving students unable to connect abstract concepts such as flip-flops, counters, and combinational logic to real-world applications. The emergence of humanoid robots offers a unique opportunity to inject vitality into this course. By embedding humanoid robot design scenarios into the curriculum, we can transform passive learning into active problem-solving, and simultaneously prepare students for careers in the rapidly growing robotics industry.
Our motivation for this reform is threefold. First, from an educational perspective, integrating humanoid robot technology makes digital electronics tangible and exciting. When students see a humanoid robot dance, walk, or manipulate objects, they are naturally curious about the underlying electronic circuits that enable such behaviors. This curiosity can be harnessed to deepen their understanding of digital logic. Second, from an industrial perspective, there is a pressing demand for engineers who can bridge the gap between digital circuit design and robotic systems. A graduate who can design a motor driver circuit for a humanoid robot joint is far more valuable than one who only knows textbook logic gates. Third, from an institutional perspective, our college emphasizes applied undergraduate education; therefore, aligning course content with frontier technologies such as humanoid robots is both an opportunity and a responsibility.
Internationally, many universities have pioneered project-based and interdisciplinary learning approaches. Some have introduced humanoid robot kits into their electronics laboratories, allowing students to build and program small robots. However, these efforts often remain extracurricular or limited to senior design projects. The systematic integration of humanoid robot technology into the daily teaching of a foundational electronics course is still underexplored. Domestically, there has been a growing interest in blending robotics with STEM education, yet many reform attempts focus on competition training rather than curriculum embedding. Our work seeks to fill this gap by designing a coherent framework that aligns digital electronics topics with the functional modules of a humanoid robot, thereby ensuring that every lesson has a clear practical context.
2. Interconnection Between Humanoid Robot Technology and Digital Electronics
2.1 Technical Architecture of a Humanoid Robot
A humanoid robot can be viewed as a complex cyber-physical system. Its hardware layer consists of a mechanical skeleton, precision actuators (such as DC motors, servo motors, and stepper motors), and a diverse array of sensors (e.g., cameras, microphones, tactile sensors, inertial measurement units, and encoders). Its software layer includes the robot operating system, motion control algorithms, path planning modules, and intelligent decision-making programs. Both layers rely heavily on digital electronic circuits for signal conditioning, data conversion, logic sequencing, and motor driving.
To illustrate this interconnection, consider the visual perception subsystem. A camera captures raw analog light intensities, which are converted into digital pixel values by an image sensor. This conversion is governed by the Nyquist sampling theorem:
$$ f_s \geq 2 f_{\max} $$
where \(f_s\) is the sampling frequency and \(f_{\max}\) is the highest frequency component of the analog signal. The resulting digital data stream is then processed by digital logic circuits for tasks such as edge detection, object recognition, and depth estimation. Similarly, the motor control subsystem relies on pulse-width modulation (PWM) signals generated by microcontrollers. The duty cycle \(D\) of a PWM signal determines the average voltage applied to a motor:
$$ V_{\text{avg}} = D \cdot V_{\text{high}}, \quad D = \frac{t_{\text{on}}}{T} $$
where \(t_{\text{on}}\) is the on-time and \(T\) is the period. Digital counters and timers within the microcontroller generate these precise signals. Thus, from data acquisition to actuator actuation, the humanoid robot is essentially a manifestation of digital electronic principles in action.
2.2 Specific Applications of Digital Electronics in Humanoid Robots
In our reform, we explicitly map each major topic of digital electronics to a concrete function in a humanoid robot (see Table 1). This mapping helps students understand why they need to learn each concept and how it contributes to building a complete robot.
| Digital Electronics Topic | Application in Humanoid Robot | Example |
|---|---|---|
| Combinational logic circuits | Arm and hand motion decoding | Using logic gates to translate action commands into motor on/off signals |
| Sequential logic circuits | Gait pattern generation | Counters and shift registers to produce periodic step sequences |
| Flip-flops and registers | State memory and sensor data storage | Storing the last known orientation of the robot |
| ADC/DAC | Sensor signal interfacing | Converting analog sound from microphone to digital for speech recognition |
| PWM and timer circuits | Motor velocity and position control | Generating PWM signals for shoulder and knee joints |
| Digital signal processing | Image and LIDAR data filtering | Noise reduction in obstacle detection |
| Memory and bus systems | Data exchange between sensors and CPU | SPI/I2C communication with inertial sensors |
This table is not merely an explanatory aid; it serves as a blueprint for the entire course structure. When teaching combinational logic, I bring in the example of a humanoid robot hand that must execute a sequence of finger movements. Students are tasked with designing a logic circuit that converts a 3-bit binary input into control signals for five fingers. They quickly realize that to map 8 possible input combinations to 5 outputs, they need Karnaugh maps and Boolean algebra simplifications. The mathematical representation of a simple finger control function can be expressed as:
$$ F_{\text{thumb}} = \overline{X_2}X_1\overline{X_0} + X_2\overline{X_1}X_0 $$
where \(X_2X_1X_0\) are the command bits. This hands-on design activity does far more than a hundred textbook exercises to cement the concept of truth tables and logic minimization.
3. Problems in the Current Digital Electronics Course
Before implementing our reforms, we conducted a thorough analysis of the existing course. Several critical problems emerged, which are common in many similar programs.
3.1 Severe Disconnect Between Course Content and Practical Applications
The traditional curriculum emphasizes theoretical knowledge, which is of course necessary, but the experimental component is often limited to simple verification tasks such as connecting a 74LS00 NAND gate or measuring the output of a 555 timer. Students never get to see how these components operate in a complex system like a humanoid robot. They learn about flip-flops but have no idea that a humanoid robot is covered with flip-flops to store joint states and event triggers. This disconnect causes students to question the relevance of the course and reduces their motivation.
3.2 Monotonous Teaching Methods
The conventional lecture-based approach, even when aided by PowerPoint slides and online videos, places students in a passive role. They listen, take notes, and reproduce circuit diagrams in exams, but they never engage in open-ended exploration. For a subject as dynamic as digital electronics, this is particularly damaging. A humanoid robot is full of interesting challenges — balancing, walking, gripping, sensing, and interacting — all of which could inspire curiosity if presented properly. Yet the traditional classroom rarely incorporates such exciting contexts.
3.3 Inadequate Assessment System
The assessment of student performance in most digital electronics courses relies heavily on a final written examination. Component weights are typically 70% final exam, 20% homework, and 10% lab reports. Examination questions are dominated by derivations, circuit analysis, and small combinational design problems. There is almost no room for evaluating a student’s ability to construct a working subsystem for a humanoid robot. As a result, students resort to rote memorization. They cannot apply the knowledge to novel engineering scenarios. When they graduate, they are ill-prepared for industrial demands.
4. Reform Objectives and Guiding Principles
4.1 Objectives
The primary goal of our reform is to reconstruct the digital electronics course so that it naturally incorporates humanoid robot technology as a central thread. We aim to achieve the following:
- Enable students to acquire solid digital electronic theory and simultaneously develop the ability to design circuits used in humanoid robot systems.
- Enhance hands-on problem-solving skills through project-based learning where each project is a functional module of a humanoid robot.
- Foster innovation, teamwork, and communication skills by simulating an engineering development environment.
- Align course outcomes with the applied talent cultivation mission of our college and the broader demand of the robotics industry.
These objectives can be quantified by improving average exam scores, project completion rates, and student interest levels, as discussed later in the results section.
4.2 Guiding Principles
Our reform follows two key principles. The first is the principle of theory–practice integration. Every theoretical lesson is accompanied by a corresponding humanoid robot lab session. For example, after teaching multiplexers, students design the input selection circuitry for a robot’s multiple sensors. The second principle is student-centered learning. Instead of listening to a lecture for an entire class period, students work in groups, negotiate ideas, and learn by making mistakes. The instructor acts as a facilitator and technical consultant.
5. Reform Strategies Based on Humanoid Robot Technology
5.1 Optimization of Teaching Content
5.1.1 Incorporating Humanoid Robot Case Studies
At the beginning of the course, I show compelling videos of humanoid robots in action: dancing on stage, performing rescue simulations, and playing table tennis. These demonstrations immediately capture student attention. Then I pose guiding questions: “How does the robot know when to lift its arm? How does it convert a wireless command into precise motor motion?” These questions set the stage for the entire course.
When teaching combinational logic, I introduce a case study of a humanoid robot hand. The hand has five fingers, each controlled by a separate servo. The robot must respond to a 3-bit command code to execute a set of gestures. Students must design a decoder circuit that meets the required truth table. When teaching sequential logic, I use the robot’s gait as a case. A bipedal walking sequence involves repeating states (left foot forward, right foot forward, standing). Students design a finite state machine using D flip-flops and combinational logic. Through these case studies, abstract concepts become concrete and memorable.
5.1.2 Integration of Course Knowledge Points
We broke the traditional chapter-by-chapter sequence and reorganized the course around the flow of a humanoid robot’s information processing pipeline: sensing → processing → decision → actuation. This structure mirrors real engineering workflows. Table 2 shows how the original textbook chapters were regrouped into four major modules.
| Module | Humanoid Robot Function | Digital Electronics Topics Included | Contact Hours |
|---|---|---|---|
| Sensor interface and signal conditioning | Converting physical signals into digital data | Analog vs digital, ADC, logic gates, multiplexers, comparators | 12 |
| Data storage and state logic | Remembering joint positions and states | Flip-flops, registers, counters, state machines | 12 |
| Actuator control | Generating PWM and timing signals | 555 timer, PWM circuits, shift registers, voltage regulation | 10 |
| Embedded system integration | Interfacing MCU with sensors and motors | Bus systems, memory interface, programmable logic basics | 10 |
This reorganization allows students to build a mental model of a complete humanoid robot system. For instance, when learning registers, we show how a single chip can store the angular position of all 12 joints of a humanoid robot in real time. The register is not merely a collection of flip-flops; it is a critical component for robot state tracking.
5.2 Innovation in Teaching Methods
5.2.1 Project-Driven Learning
The core method we adopted is project-driven learning (PDL). Students are divided into groups of four to six, and each group is assigned a real development project. Some example projects are listed in Table 3.
| Project Title | Targeted Robot Subsystem | Key Digital Electronics Skills Required |
|---|---|---|
| Facial Expression Control System | LED array and servo-driven mouth | Combinational logic, PWM control, counters |
| Obstacle-Avoidance Platform | Ultrasonic sensor and motor controller | ADC, comparators, logic decision circuits |
| Music Playing Robot | Beeping speaker and LED rhythm lights | Sequential state machines, timers, shift registers |
| Gesture Recognition Glove | Hand motion sensor interface | Multiplexers, encoders, bus interfacing |
Each project is broken into phases: requirement analysis, schematic design, breadboard or simulation implementation, testing, and final presentation. Students are encouraged to explore multiple solutions. For instance, a group designing a voice-activated command decoder might initially use a 74LS138 decoder and later realize that a small CPLD would be more flexible. This type of exploration is exactly what engineers do.
5.2.2 Virtual Simulation in Teaching
To overcome the constraints of limited hardware resources and reduce the risk of circuit damage, we extensively use simulation software such as Proteus, Multisim, and MATLAB Simulink. These tools allow students to design and test humanoid robot subsystems in a risk-free virtual environment. For example, they can simulate the entire control circuit for a robotic leg, adjust PWM parameters, and observe the resulting joint motion without burning out a motor driver. The virtual environment also enables remote learning, which proved essential in hybrid teaching contexts.
Simulation also helps students understand mathematical relationships. Consider the resonant frequency of a 555-timer astable multivibrator used in a humanoid robot’s tone generator:
$$ f = \frac{1}{0.693 (R_1 + 2R_2) C} $$
By changing resistor values in simulation, students can directly hear the change in pitch, thereby connecting the formula to an audible outcome.
5.2.3 Collaborative Group Learning
Group work is mandatory but carefully managed. Every group has a hardware designer, a software programmer (if the project includes a microcontroller), a document writer, a test engineer, and a team leader. These roles rotate during the semester. During weekly progress meetings, each member reports their contribution using a standard template that includes completed tasks, encountered problems, and planned steps. This practice not only improves communication but also ensures accountability. In the humanoid robot music player project, the hardware designer focuses on connecting the speaker driver circuit, while the programmer writes the melody sequence in a lookup table. Collaborative troubleshooting helps students learn from each other.
5.3 Comprehensive Assessment Reform
5.3.1 Diversified Assessment Indicators
We replaced the exam-centric grading with a multi-dimensional rubric that weighs theoretical knowledge, practical ability, project results, and teamwork (see Table 4). This rubric ensures that the assessment is aligned with engineering competencies.
| Assessment Category | Weight | Assessment Method |
|---|---|---|
| Theoretical knowledge | 30% – 40% | Written exam including humanoid robot contextual problems |
| Practical ability | 30% – 40% | Laboratory tasks, project defense, circuit debugging |
| Project outcomes | 10% – 20% | Evaluation of originality, functionality, and reliability |
| Teamwork | 10% – 20% | Peer ratings, meeting logs, contribution analysis |
The written examination now contains at least 30% application-oriented questions related to humanoid robot scenarios. For example: “Design a circuit that prevents a humanoid robot from overextending its elbow joint. Use a logic gate and one flip-flop to ensure that the motor is cut off after the joint reaches 180°.” Such questions force students to apply digital components in a functional context.
5.3.2 Process-Oriented Evaluation
Apart from the final exam, we continuously assess students throughout the semester. Class participation (10% – 20%), project milestone progress (30% – 40%), and laboratory reports (30% – 40%) are all included. Students submit biweekly progress reports with screenshots of their simulated waveforms or photos of their breadboard circuits. Timely feedback allows them to correct errors before they become repeated mistakes. The laboratory report format now requires a section titled “Engineering Significance,” where students must explain how their experimental circuit could be used in a humanoid robot.
6. Case Study of the Reform Implementation
6.1 Sample Selection and Implementation
To evaluate the effectiveness of our reform, we conducted a controlled experiment over a full semester. We selected two parallel classes in the electronic information engineering program. One class (the experimental group) used our reformed curriculum with humanoid robot integration, while the other class (the control group) continued with the traditional lecture-based method. Both classes had the same instructor and used the same textbook for the theoretical parts. The experimental group had weekly four-hour lab sessions focused on robot-related projects, whereas the control group had the same lab hours but following conventional experiment manuals.
The experimental group began with a special seminar on humanoid robot technology, highlighting the 2025 Spring Festival Gala performance by Unitree robots and other rescue scenarios. This opening inspired immediate interest. Then, the class was split into five groups of five to six students. Each group chose a project from the list in Table 3. They had access to lab benches equipped with digital trainer kits, breadboards, sensors, motor drivers, and simulation software. Weekly two-hour sessions were reserved for group work, with the instructor circulating to answer questions and challenge students with “what-if” scenarios.
In the control group, the instructor delivered lectures with PPT and demonstrated circuits on a breadboard, while students individually performed the prescribed experiments, such as verifying the truth table of a 74LS138. The final grade for the control group was based on the traditional formula: 70% final exam, 20% quizzes and homework, and 10% lab reports.
6.2 Evaluation of Teaching Effectiveness
At the end of the semester, we compared three metrics: final exam scores, project completion quality, and self-reported learning interest. We also analyzed the distribution of higher-order thinking skills evidenced in project reports. Table 5 presents a summary of the results.
| Metric | Experimental Group | Control Group | Difference |
|---|---|---|---|
| Average final exam score (/100) | 82.5 | 72.8 | +9.7 |
| Pass rate | 96% | 88% | +8% |
| Students reporting high interest | 82% | 57% | +25% |
| Projects fully functioning | 4 out of 5 | N/A | — |
| Average project score (/100) | 86.3 | N/A | — |
The experimental group outperformed the control group by nearly 10 points in the final exam, even though the final exam contained additional robot-related application questions. This is remarkable because the reform actually increased the cognitive difficulty of the exam. The project outputs exceeded our expectations; one group built a fully operational gesture-controlled robotic arm using multiplexing and shift registers, and another designed a music-playing robot with a 12-tone scale, all using basic digital chips. Surveys indicated that more than 80% of the experimental group found the course “interesting and useful,” compared to 57% in the control group. The qualitative feedback was equally positive: students appreciated that the course was “not just theory but real engineering.”
To quantify the improvement in conceptual understanding, we compared the performance on a common question about synchronous counters. The experimental group achieved an average of 85%, while the control group averaged 68%. The better performance can be attributed to the fact that the experimental group had designed a gait counter for the humanoid robot leg movement. The formula for the modulus \(M\) of a counter constructed with \(n\) flip-flops is:
$$ M = 2^n $$
But this alone is insufficient. In the context of a bipedal walking pattern, the counter must wrap around after 4 states (left, right, both, idle), requiring a modulus-4 counter. Students in the experimental group learned to modify the counter by adding combinational reset logic, which deepened their understanding of both counters and asynchronous reset.
6.3 Problems Encountered and Improvement Measures
Despite the overall success, we identified several difficulties. First, the number of humanoid robot kits was insufficient, causing bottlenecks and long waiting times during lab sessions. To mitigate this, we leveraged simulation tools more heavily and also partnered with a local robotics company to borrow prototypes for demonstration. Second, some students with weaker backgrounds struggled in the initial weeks because the project required simultaneous understanding of mechanical, electrical, and software concepts. We addressed this by implementing a blended learning model: short pre-recorded videos on prerequisite topics (e.g., binary arithmetic, Ohm’s law, basic programming) were provided online before each lab, and a teaching assistant held remote office hours twice a week. Third, group conflicts arose due to unequal participation. We introduced peer evaluation scores and required a weekly contribution log, which largely resolved the issue.
7. Conclusion and Outlook
Through this teaching reform, we have demonstrated that integrating humanoid robot technology into the digital electronics course can significantly improve student learning outcomes, boost engagement, and cultivate practical skills. The content, methods, and assessment policy were all redesigned to reflect real engineering practice. Students learned not only the fundamentals of digital logic but also how to design, simulate, test, and debug circuits that perform meaningful tasks in a humanoid robot.
The quantified results provide strong evidence: a 10-point improvement in exam scores, a 25% increase in interest, and several fully functional robot subsystems built by second-year students. More importantly, the students developed an engineering mindset — they began to ask “How can I make this circuit more reliable?” or “How would this logic behave if the sensor noise increases?” These are exactly the metacognitive skills necessary for lifelong learning.
Looking forward, we plan to deepen the integration by introducing more advanced topics such as FPGA-based vision acceleration for humanoid robot perception, as well as interdisciplinary content from biomechanics and psychology to inform robot design. We also aim to establish stronger international collaborations to share best practices and bring cutting-edge technology into the classroom. New open-ended projects, such as a collaborative humanoid robot dance orchestrated by multiple student teams, will be developed. We believe that the fusion of humanoid robot technology and digital electronics not only revitalizes a foundational course but also plants the seeds for the next generation of robotic innovators.
References
[1] Zhu Lin, Mao Lei. “Suggestions and Countermeasures for Humanoid Robot Sensor Development,” New Economy Guide, 2024(10): 74–79.
[2] Liu Yifan, Li Li, Wang Dianzheng, et al. “Workspace Analysis Method for Humanoid Robot Dual Arms,” Micro and Special Motors, 2024, 52(10): 61–67, 76.
[3] Xi Chongbin. “Application and Development of Humanoid Robots in Logistics,” Logistics Technology and Application, 2024, 29(10): 67–69.
[4] Cao Yafei. “How Can Humanoid Robots Break Through?” Software and Integrated Circuits, 2024(4): 31–35.
[5] Wang Yuancheng, Wen Jinghao, Zhang Qirui, et al. “Intelligent Biped Humanoid Robot Based on Jetson Nano,” Intelligent Computer and Applications, 2024, 14(4): 177–179.
[6] Bai Xuefeng, Yang Shuya, Sun Liuqing. “Teaching Reform and Practice of Humanoid Robot Training Course,” China Modern Educational Equipment, 2024(3): 152–153, 166.