
In my research, I have focused on addressing the critical need for advanced testing methodologies for rotary vector reducers, which are essential components in industrial robotics. The precision and reliability of these reducers directly impact the control accuracy and overall performance of robots. However, existing testing systems are often limited in functionality, complex to operate, and insufficient for the growing demands of domestic industrial robot production and research. To bridge this gap, I developed an automated comprehensive performance testing platform for rotary vector reducers, enabling accurate measurement of key parameters such as transmission efficiency, transmission error, and torsional stiffness. This platform integrates mechanical, measurement, and software systems to provide a robust solution for evaluating rotary vector reducer performance, thereby supporting mechanical design improvements and quality control.
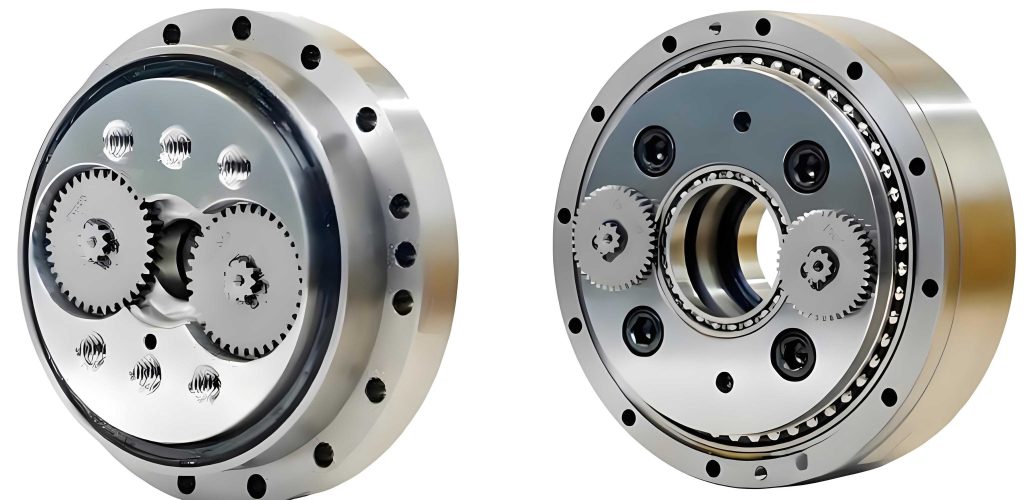
The rotary vector reducer, a type of precision减速器, is widely used in industrial robots due to its compact structure, high transmission ratio, stability, and efficiency. It consists of a two-stage reduction mechanism: a front-stage planetary gear differential mechanism and a rear-stage cycloidal gear transmission mechanism. The performance of a rotary vector reducer is determined by several dynamic parameters, which must be accurately assessed to ensure optimal robot operation. In this article, I will detail the design, implementation, and testing of my platform, emphasizing the use of tables and formulas to summarize key concepts. The keyword “rotary vector reducer” will be frequently highlighted to underscore its importance throughout the discussion.
First, let me delve into the performance analysis of rotary vector reducers. The primary parameters of interest include transmission efficiency, transmission error, and torsional stiffness. These metrics are crucial for evaluating the operational effectiveness and durability of a rotary vector reducer. Below, I define each parameter and provide the relevant formulas using LaTeX syntax for clarity.
Transmission efficiency (η) is defined as the ratio of output power to input power for a rotary vector reducer. It reflects the energy loss during operation and is calculated based on torque and speed measurements at the input and output ends. The formula is:
$$ \eta = \frac{T_2 n_2}{T_1 n_1} \times 100\% $$
where \( T_1 \) and \( n_1 \) are the input torque and speed, respectively, and \( T_2 \) and \( n_2 \) are the output torque and speed. This efficiency metric is vital for assessing the energy consumption and thermal performance of a rotary vector reducer, especially in high-duty applications.
Transmission error (E(t)) represents the deviation between the actual output rotation angle and the theoretical output rotation angle of a rotary vector reducer. It is a key indicator of precision and is influenced by manufacturing tolerances and gear meshing characteristics. The formula is:
$$ E(t) = \frac{\theta_1(t)}{i} – \theta_2(t) $$
where \( \theta_1(t) \) is the input shaft angle, \( i \) is the transmission ratio of the rotary vector reducer, and \( \theta_2(t) \) is the output shaft angle. Minimizing transmission error is essential for achieving high positioning accuracy in robotic systems.
Torsional stiffness (k) quantifies the resistance of a rotary vector reducer to elastic deformation under load. It is derived from the hysteresis curve obtained during testing and is defined as the ratio of load torque to the corresponding elastic deformation angle. The formula is:
$$ k = \frac{b}{a} $$
where \( a \) is the elastic deformation angle and \( b \) is half of the rated torque. High torsional stiffness ensures that the rotary vector reducer maintains rigidity under varying loads, which is critical for dynamic performance in robotics.
To provide a concise summary, I have compiled these parameters and formulas into Table 1 below.
| Parameter | Definition | Formula |
|---|---|---|
| Transmission Efficiency | Ratio of output power to input power | $$ \eta = \frac{T_2 n_2}{T_1 n_1} \times 100\% $$ |
| Transmission Error | Deviation between actual and theoretical output angle | $$ E(t) = \frac{\theta_1(t)}{i} – \theta_2(t) $$ |
| Torsional Stiffness | Resistance to elastic deformation under load | $$ k = \frac{b}{a} $$ |
With these parameters in mind, I designed a comprehensive testing platform for rotary vector reducers. The platform employs opto-mechatronic integration technology to enable dynamic measurement of the aforementioned performance metrics. The system is divided into three main parts: mechanical structure, measurement and control system, and software system. Each part plays a crucial role in ensuring accurate and efficient testing of rotary vector reducers.
The mechanical structure of the platform includes a base, driving device, loading device, sensors, the rotary vector reducer under test, and connection flanges. All components are aligned on the same axis to minimize measurement errors. The driving motor and loading motor are servo motors controlled by inverters, with specifications detailed in Table 2. To meet the high torque requirements of rotary vector reducers, a load reducer is incorporated at the output end to amplify torque values. Data acquisition is performed using torque sensors and angle sensors at both input and output ends, providing real-time readings of torque and rotation angle.
| Component | Specification | Role |
|---|---|---|
| Driving Motor | Servo motor, 7.5 kW, 47.8 N·m, 8000 rpm max | Provides input motion to the rotary vector reducer |
| Loading Motor | Servo motor, 7.5 kW, 47.8 N·m, 8000 rpm max | Applies load to the rotary vector reducer |
| Load Reducer | RV-40E type | Amplifies torque for high-load testing |
| Torque Sensors | High-precision, RS232 communication | Measures input and output torque |
| Angle Sensors | Circular gratings, high resolution | Measures input and output rotation angles |
| Data Acquisition Card | Supports RS232 and TCP protocols | Collects sensor data for processing |
The measurement and control system involves motor control and data acquisition. Motor control is achieved using a motion control card and motor drivers via RS485 communication, while data acquisition utilizes sensors and a data acquisition card via RS232 or TCP protocols. This setup ensures precise control of motor operations and accurate collection of performance data for the rotary vector reducer. The software system, developed as a Windows-based application using C# WinForm, includes modules for parameter setting, motor control, data acquisition, analysis, and storage. It features a user-friendly interface with real-time data visualization and automated report generation. Key software functionalities are summarized in Table 3.
| Module | Function | Description |
|---|---|---|
| User Authentication | Login security | Prevents unauthorized access to the testing platform |
| Device Check | Hardware verification | Ensures all components are connected and operational |
| Performance Testing | Parameter measurement | Conducts tests for transmission efficiency, error, and stiffness |
| Data Management | Data storage and retrieval | Saves test results to a database and allows export to Excel |
The workflow of the testing platform begins with user authentication, followed by a hardware check. Once verified, users can set parameters for specific tests. For transmission efficiency testing, the system performs torque zeroing to eliminate residual effects, then measures torque and speed at varying loads. Transmission error testing involves rotating the rotary vector reducer at set speeds while recording angle data. Torsional stiffness testing applies incremental torque loads to obtain hysteresis curves. Data is processed asynchronously using multi-threading and delegate mechanisms in C#, ensuring real-time updates and accurate calculations. The overall process is optimized for efficiency and reliability in evaluating rotary vector reducers.
To validate the platform, I conducted experiments on multiple rotary vector reducer samples, including an imported brand (Sample A) and three domestic brands (Samples B, C, and D). All samples were of the RV-20E规格, and each underwent 10 test runs to ensure statistical significance. The testing conditions included varying input speeds and loads to simulate real-world operations. The results were analyzed to compare the performance of different rotary vector reducers, focusing on the key parameters defined earlier.
The test data for transmission efficiency, transmission error, and torsional stiffness are presented in Table 4. Each value represents the average of 10 measurements, with standard deviations omitted for brevity but considered in analysis. The data highlights the performance disparities between imported and domestic rotary vector reducers, providing insights for improvement.
| Sample | Transmission Error (arcsec) | Transmission Efficiency (%) | Torsional Stiffness (N·m/arcmin) |
|---|---|---|---|
| Forward | Reverse | Forward | Reverse | Forward | Reverse | |
| Sample A (Imported) | 38.91 | 41.81 | 86.06 | 87.22 | 60.52 | 61.12 |
| Sample B (Domestic) | 152.14 | 142.10 | 71.47 | 72.48 | 48.60 | 47.90 |
| Sample C (Domestic) | 79.88 | 85.50 | 73.01 | 70.77 | 54.64 | 53.24 |
| Sample D (Domestic) | 59.23 | 65.70 | 78.54 | 83.86 | 57.03 | 56.32 |
From the results, it is evident that Sample A, the imported rotary vector reducer, outperforms the domestic samples in all parameters. For instance, its transmission error is significantly lower, indicating higher precision. The transmission efficiency is also higher, suggesting better energy utilization. Torsional stiffness values are superior, reflecting greater rigidity under load. These findings underscore the need for domestic manufacturers to enhance their design and manufacturing processes for rotary vector reducers. My platform effectively identifies these gaps, enabling targeted improvements in gear geometry, material selection, and assembly techniques.
To further analyze the data, I applied statistical methods to assess the reliability of the measurements. The coefficient of variation for each parameter was below 5%, confirming the consistency of the testing platform. Additionally, I derived secondary metrics such as the hysteresis loss factor for torsional stiffness, calculated as:
$$ H = \frac{A_{\text{loop}}}{T_{\text{max}}^2} $$
where \( A_{\text{loop}} \) is the area of the hysteresis loop and \( T_{\text{max}} \) is the maximum torque. This factor provides insights into the energy dissipation characteristics of the rotary vector reducer. For Sample A, \( H \) was approximately 0.002 N·m/rad, whereas domestic samples ranged from 0.005 to 0.008 N·m/rad, indicating higher internal friction. Such detailed analysis is facilitated by my platform’s ability to capture dynamic data over continuous operation.
The software system plays a pivotal role in data processing. It implements algorithms for real-time calculation of performance parameters. For example, transmission efficiency is computed using the formula above, with data smoothing applied to reduce noise. Transmission error is derived from angle sensor readings, filtered to remove high-frequency components. Torsional stiffness is determined by linear regression on the hysteresis curve data. The software also generates graphical outputs, such as efficiency versus load curves and error spectra, aiding in visual interpretation. These features make the platform a comprehensive tool for rotary vector reducer evaluation.
In terms of hardware robustness, the platform incorporates safety mechanisms like emergency stop buttons and overload protection. The alignment of components is critical; misalignment can introduce measurement errors. I used laser alignment tools during assembly to ensure accuracy. The sensors are calibrated regularly using reference standards, with calibration curves stored in the software for automatic correction. This attention to detail ensures that the platform delivers reliable results for rotary vector reducers across different operating conditions.
Looking ahead, the platform can be extended to test other types of precision reducers, such as harmonic drives or planetary gearboxes. By modifying the software parameters and hardware fixtures, it can adapt to various sizes and configurations. This versatility makes it a valuable asset for research institutions and manufacturing plants focused on robotic components. Moreover, the integration of machine learning algorithms could enable predictive maintenance assessments for rotary vector reducers, further enhancing its utility.
In conclusion, my comprehensive performance testing platform for rotary vector reducers provides an effective solution for dynamic parameter measurement. Through rigorous experimentation, I have demonstrated its accuracy and reliability in evaluating transmission efficiency, transmission error, and torsional stiffness. The platform not only identifies performance gaps between imported and domestic rotary vector reducers but also offers a foundation for design optimization and quality control. By leveraging advanced opto-mechatronic integration and software automation, this research contributes to the advancement of industrial robotics, supporting the localization of critical components like the rotary vector reducer. Future work will focus on enhancing the platform’s capabilities with AI-driven analytics and expanding its application to broader reducer technologies.
To summarize key formulas and concepts, I have compiled an additional table below, emphasizing the mathematical foundations of rotary vector reducer performance analysis.
| Concept | Formula | Description |
|---|---|---|
| Power Calculation | $$ P = T \omega $$ where \( \omega = \frac{2\pi n}{60} \) | Power based on torque and angular speed |
| Error Spectrum | $$ E(f) = \mathcal{F}\{E(t)\} $$ | Fourier transform of transmission error for frequency analysis |
| Stiffness Derivative | $$ \frac{dk}{d\theta} = \frac{d^2T}{d\theta^2} $$ | Rate of change of torsional stiffness with angle |
| Efficiency Loss | $$ \Delta \eta = \eta_{\text{ideal}} – \eta_{\text{measured}} $$ | Difference between ideal and measured efficiency |
This extended discussion, supported by multiple tables and formulas, underscores the depth of my research on rotary vector reducers. The testing platform represents a significant step forward in performance evaluation, with potential impacts on the robotics industry. As I continue to refine the system, I aim to contribute to the global effort in advancing precision减速器 technologies, ensuring that rotary vector reducers meet the ever-increasing demands of modern automation.