
The development and proliferation of industrial robots stand as a paramount indicator of a nation’s manufacturing and technological prowess. Within these sophisticated machines, the joint drive system acts as the critical foundation, directly dictating performance metrics such as precision, load capacity, and operational stability. Among various transmission solutions, the Rotary Vector (RV) reducer, characterized by its two-stage design combining a planetary gear train with a cycloidal pin-wheel mechanism, has become the de facto standard for precision joints due to its exceptional rigidity, high torque density, minimal backlash, and compact size. This transmission component is indispensable for high-performance robotic arms and precision machine tools.
Despite a booming domestic market for industrial robots, a staggering 75% of the market share for these core rotary vector reducer components is monopolized by a handful of Japanese manufacturers. This dominance creates significant bottlenecks for domestic robot builders, including exorbitant costs and unpredictable supply chains, severely undermining the global competitiveness of Chinese robotics. While two decades of national research initiatives have yielded considerable theoretical understanding and functional prototypes, the leap to reliable, cost-effective, and large-scale batch production remains elusive. A few domestic enterprises have achieved small-batch output, yet their products often suffer from inferior performance, shorter service life, and higher manufacturing costs compared to their imported counterparts. This article, from a first-person analytical perspective, delves into the multifaceted technical and systemic challenges hindering the domestic batch manufacturing of rotary vector reducers and explores potential pathways forward.
Structural Principles and Application Context
The superior performance of the rotary vector reducer stems from its unique kinematic structure and force distribution. It is essentially a closed, statically indeterminate differential gear system. The first stage typically consists of a standard involute planetary gear train, providing an initial speed reduction. The second, and more critical, stage is a cycloidal pin-wheel planetary mechanism with a small tooth difference (often one tooth). This stage provides the major speed reduction. The two stages are integrated within a shared pinwheel housing, and the force is transmitted and balanced through multiple crankshafts and cycloidal disks arranged in parallel. This parallel load-sharing design is the source of its high torsional rigidity and compactness. The precise meshing of the modified cycloidal profile with the cylindrical pins ensures smooth motion transfer with very little theoretical backlash.
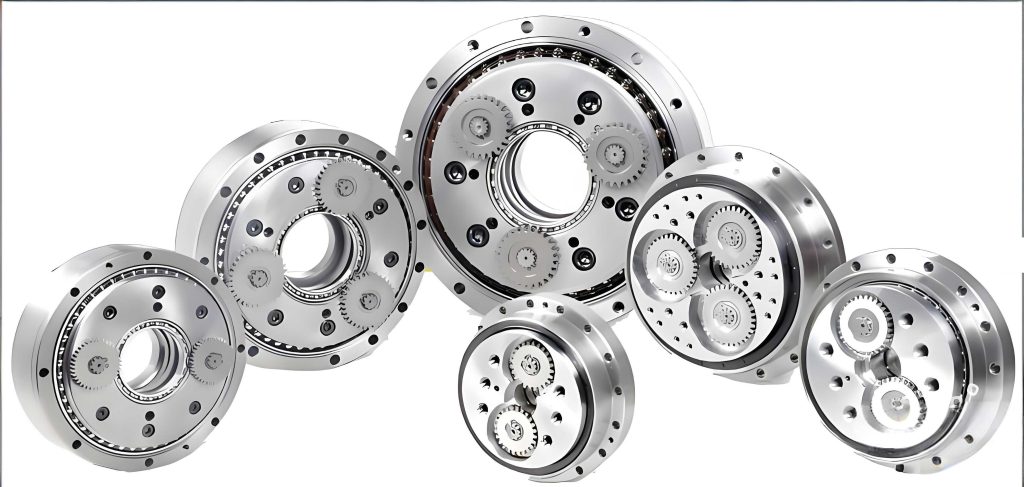
The demanding application in industrial robot joints, where repetitive high-precision positioning under varying loads is required, places extreme demands on the rotary vector reducer. Key performance indicators include:
- Positioning Accuracy and Repeatability: Dictated by the transmission error and hysteresis (backlash).
- Torsional Stiffness: Determines the system’s resistance to deflection under load, crucial for endpoint accuracy.
- Efficiency and Heat Generation: Affects power consumption and thermal stability during continuous operation.
- Service Life and Reliability: Directly impacts maintenance costs and machine uptime.
The inability to mass-produce rotary vector reducers that consistently meet these benchmarks is the central challenge for domestic industry.
Domestic Research Landscape: Theory vs. Practice
Extensive academic research in China has laid a solid theoretical foundation for understanding the rotary vector reducer. However, a significant gap persists between theoretical models and industrialized manufacturing. The following table summarizes the key research areas and their practical limitations.
| Research Domain | Key Theoretical Contributions | Gaps for Batch Manufacturing |
|---|---|---|
| Meshing Theory & Profile Design | Establishment of general meshing equations for cycloidal drives; derivation of universal profile equations incorporating modifications (offset, equidistant, rotational). Analysis of profile parameters (short width coefficient, etc.) on transmission characteristics. | Theory assumes ideal geometries. Practical manufacturing introduces form errors, surface roughness, and heat treatment distortions not accounted for in pure geometrical models. |
| Transmission Accuracy & Error Modeling | Development of probabilistic and deterministic error models; analysis of individual error sources (eccentricity, pin position, profile modification) on overall transmission error and backlash using methods like orthogonal experiments and virtual prototyping. | Models often isolate errors. The complex coupling and stacking of multiple micro-scale errors from all components in a statically indeterminate system during actual assembly is extremely difficult to predict and control in production. |
| Dynamics & Modal Analysis | Finite Element Analysis (FEA) for modal characteristics of individual parts (cycloidal disk, crankshaft); system-level dynamic modeling using lumped mass methods; investigation of parameter influences on natural frequencies. | Simulations rely on simplified boundary conditions and assumed material properties. Real-world damping, joint stiffnesses in bearings, and the impact of lubrication on dynamics are seldom fully integrated. |
| Load Distribution & Efficiency | Force analysis models considering elastic deformation and initial gaps due to profile modification; derivation of efficiency formulas using converted mechanism methods; analysis of load sharing among parallel paths. | Calculations often assume perfect load sharing. In reality, micro-geometrical differences between parallel crankshafts and cycloidal disks lead to uneven load distribution, affecting fatigue life and efficiency unpredictably. |
| Mesh Stiffness Calculation | Calculation of time-varying mesh stiffness based on Hertzian contact theory; incorporation of mesh stiffness into multi-degree-of-freedom dynamic models. | Stiffness models are highly sensitive to actual contact conditions (alignment, surface finish, lubrication), which are production-process dependent. |
While this research is invaluable for design and troubleshooting, it primarily addresses the “design” aspect. The core impediments to batch production lie in the realms of “manufacturing,” “metrology,” “materials processing,” and “systems integration.”
Core Challenges in Batch Manufacturing
Transitioning from prototype to batch production of rotary vector reducers exposes several critical, interconnected bottlenecks. These are not merely issues of scaling up but fundamental gaps in the industrial ecosystem.
1. Absence of Unified National Standards
The lack of comprehensive national standards for the design, manufacture, and testing of rotary vector reducers is a fundamental systemic hurdle. In the absence of such standards, each research institute and company operates in isolation, developing internal, often proprietary, specifications and process guidelines. This fragmentation leads to:
- Incompatibility and Non-Comparability: Products from different sources cannot be easily compared or substituted, hindering the development of a healthy supply chain.
- Reinvention of the Wheel: Significant resources are wasted solving the same basic problems (e.g., testing protocols) repeatedly.
- Quality Inconsistency: Without standardized tolerance grades, heat treatment specifications, and performance testing methods, consistent quality is nearly impossible to guarantee across batches or between manufacturers.
The initial work by the National Technical Committee for Reducers to draft a standard is a positive step, but progress is slow due to technical complexity and the lack of existing domestic benchmarks to reference.
2. The Specialized Manufacturing Equipment Dilemma
The ultra-high precision required for key components of the rotary vector reducer (micrometer-level tolerances) renders conventional, general-purpose machine tools inadequate for efficient and consistent batch production. The reliance on such tools is a major cost and capability constraint.
The Cycloidal Disk: A Case Study
The cycloidal disk is arguably the most critical and challenging component to manufacture. Its complex, precise profile dictates the meshing quality. Current domestic practices reveal the problem:
- Slow Wire-Cut EDM: A common but problematic method. While capable of achieving the profile, it is inherently slow. More critically, the cumulative pitch error from the machine’s lead screw and the lack of a finished surface (as-cut surfaces have a recast layer) result in poor transmission smoothness, noise, and accelerated wear. It is unsuitable for volume production.
- Form Grinding (Imported Machines): Some companies invest in expensive imported form-grinding machines. While providing a good surface finish, this method has drawbacks: the grinding wheel requires frequent and precise dressing, indexing errors affect tooth spacing (pitch error), and the process rate is low. It is better suited for small batches but not high-volume output.
The solution lies in developing dedicated gear generation equipment, specifically a cycloidal gear hobbing machine and a cycloidal gear grinding machine. The generation method (using a hob or grinding worm that mimics the pin-gear) would offer superior pitch accuracy and consistency, excellent surface finish, and significantly higher production rates. However, this necessitates the parallel development of the corresponding precision cutting tools—the cycloidal hob and the cycloidal grinding worm—which is a significant metallurgical and manufacturing challenge in itself.
The equation for the modified cycloidal profile is central to designing both the part and the tooling. The universal form, incorporating offset ($\Delta R_p$), equidistant ($\Delta r_{rp}$), and rotational ($\Delta \phi$) modifications, is given by:
$$ \begin{cases}
x = [R_p + \Delta R_p – (r_{rp} + \Delta r_{rp})] \sin(\phi – \phi_0) – a \sin(Z_p (\phi – \phi_0)) + \Delta r_{rp} \sin(\phi – \phi_0 – \zeta) \\
y = [R_p + \Delta R_p – (r_{rp} + \Delta r_{rp})] \cos(\phi – \phi_0) – a \cos(Z_p (\phi – \phi_0)) + \Delta r_{rp} \cos(\phi – \phi_0 – \zeta)
\end{cases} $$
where $R_p$ is the pin circle radius, $r_{rp}$ is the pin radius, $a$ is the eccentricity, $Z_p$ is the number of pins, $\phi$ is the input angle, $\phi_0$ is the initial phase, and $\zeta = \arctan\left(\frac{\sin((1-Z_p)(\phi – \phi_0))}{(R_p/(a Z_p)) – \cos((1-Z_p)(\phi – \phi_0))}\right)$. This complexity underscores the difficulty in accurately generating the conjugate tool profile.
3. Wear, Lubrication, and Service Life
Short service life and rapid degradation of precision are major criticisms of domestically produced rotary vector reducers. The root causes are multifaceted:
- Surface Integrity: Manufacturing processes that fail to produce optimal surface finish (low roughness, compressive residual stress) on contact surfaces (cycloid flank, pin surface, crankshaft bearing tracks) create nucleation sites for wear and fatigue.
- Material and Heat Treatment: The optimal material grades (e.g., specific bearing steels) and their precise heat treatment sequences (carburizing, nitriding, tempering) to achieve the required core toughness and surface hardness are often proprietary knowledge or not fully mastered domestically for this specific application.
- Lubrication Challenges: The sealed, compact structure of the rotary vector reducer mandates grease lubrication, not oil. This presents a thermal management nightmare. Key friction points, especially the needle rollers inside the crankshaft bearings, operate at very high relative speeds, generating substantial heat. Grease has poorer heat dissipation properties than oil, leading to operating temperature rise, grease degradation, loss of lubrication film, and ultimately, premature bearing failure—a common life-limiting factor.
Fundamental research into the wear mechanisms specific to the rotary vector reducer’s mixed rolling-sliding contacts, coupled with the development of high-performance, thermally stable greases, is urgently needed.
4. Intelligent Metrology and Selective Assembly
The rotary vector reducer’s statically indeterminate structure, with its many interconnected components, means that the cumulative effect of each part’s manufacturing variance (even within its individual tolerance band) can easily push the final assembled product outside the stringent performance specifications, particularly the required backlash of less than 1 arcminute.
Traditional random assembly is a recipe for low yield. The solution is a fully digitalized production management and selective assembly system. This system involves:
- 100% Component Metrology: Every critical component (cycloidal disk, pin housing, crankshaft, planetary gears) is measured post-manufacturing, and its actual dimensions are recorded and linked to a unique component ID.
- Digital Twin and Prediction Model: A mathematical model of the transmission error/backlash, based on the kinematic chain and elastic deformations, is established. This model can predict the final performance based on the actual measured dimensions of a set of candidate parts.
- Optimization-Driven Selection: For each assembly cycle, an optimization algorithm (e.g., Genetic Algorithm) processes the pool of available component IDs and their actual dimensions. It solves for the combination that minimizes the predicted backlash or transmission error, ensuring it falls within the acceptable range. This maximizes the assembly yield.
The backlash ($\Delta \phi_{output}$) can be modeled as a function of multiple error sources:
$$ \Delta \phi_{output} = f(\Delta R_p, \Delta r_{rp}, \Delta a, \Delta J_1, \Delta J_2, …, \Delta B_i) $$
where $\Delta R_p$ is pin circle radius error, $\Delta r_{rp}$ is pin radius error, $\Delta a$ is eccentricity error, $\Delta J_i$ are bearing clearances, and $\Delta B_i$ are other geometric errors. An optimization problem can be formulated as:
$$ \text{Minimize: } |\Delta \phi_{output}(X)| $$
$$ \text{Subject to: } |\Delta \phi_{output}(X)| \leq 1′ \text{ and } X \in S $$
where $X$ is a vector representing a specific set of selected component IDs, and $S$ is the set of all available components. Research indicates such a system can increase yield from ~55% (random assembly) to over 90%.
| Critical Bottleneck | Primary Causes | Required Solutions & Directions |
|---|---|---|
| Lack of Standards | Fragmented R&D, no common reference for design, manufacturing, or testing. | Accelerate development of comprehensive national standards covering tolerances, materials, heat treatment, and performance testing protocols. |
| Missing Specialized Equipment | Dependence on slow, inaccurate, or expensive generic/semi-specialized tools (EDM, form grinders). | R&D into dedicated generation machines (hobbing, grinding) and the corresponding precision cutting tools (hobs, grinding worms) for cycloidal gears. |
| Poor Service Life | Sub-optimal surface finish, material/heat treatment, and inadequate lubrication/thermal management. | Fundamental research on wear mechanisms; development of advanced material processes and high-performance, thermally stable specialty greases. |
| Low Assembly Yield | Random accumulation of component variances in a statically indeterminate system. | Implementation of digital twin-based selective assembly systems using 100% component metrology and optimization algorithms. |
Strategic Synthesis and Concluding Perspective
The journey towards successful domestic batch manufacturing of high-performance rotary vector reducers is a systemic engineering challenge that transcends theoretical design. It requires a concerted, strategic effort across academia, industry, and government to build a complete industrial ecosystem. The following matrix outlines the necessary transition from the current state to a future state capable of sustainable production.
| Aspect | Current State (Prototype/Small Batch) | Required Future State (Competitive Batch Production) |
|---|---|---|
| Foundation | Theoretical models, isolated prototypes, internal company specs. | Unified national standards for design, manufacture, and testing. |
| Core Capability | Manufacturing using adapted general-purpose or imported semi-specialized equipment. | Domestic mastery and supply of dedicated, high-productivity precision manufacturing equipment and tooling. |
| Quality Driver | Focus on achieving basic geometry and function. | Deep understanding and control of surface integrity, material science, and tribology for longevity. |
| Production System | Manual assembly based on trial-and-error or simple selection. | Fully digitalized, data-driven production line with intelligent predictive assembly. |
| Industry Structure | Vertically integrated, closed efforts by individual entities. | Open, collaborative ecosystem with specialized suppliers for components, equipment, tooling, and materials. |
In conclusion, while the theoretical groundwork for the rotary vector reducer is well-established domestically, the path to industrialization is obstructed by profound practical challenges. The absence of standards creates chaos, the lack of dedicated manufacturing equipment strangles productivity and quality, unresolved wear and lubrication issues limit life, and primitive assembly methods cripple yield. Addressing these four pillars—standardization, specialized equipment development, tribological science, and digitalized smart manufacturing—in a coordinated manner is not merely a technical necessity but a strategic imperative. The future of a robust, independent, and competitive domestic robotics industry hinges on solving these fundamental problems surrounding the core technology of the rotary vector reducer. The task is formidable, but a systematic, focused effort on these manufacturing-centric challenges is the only viable pathway forward.