
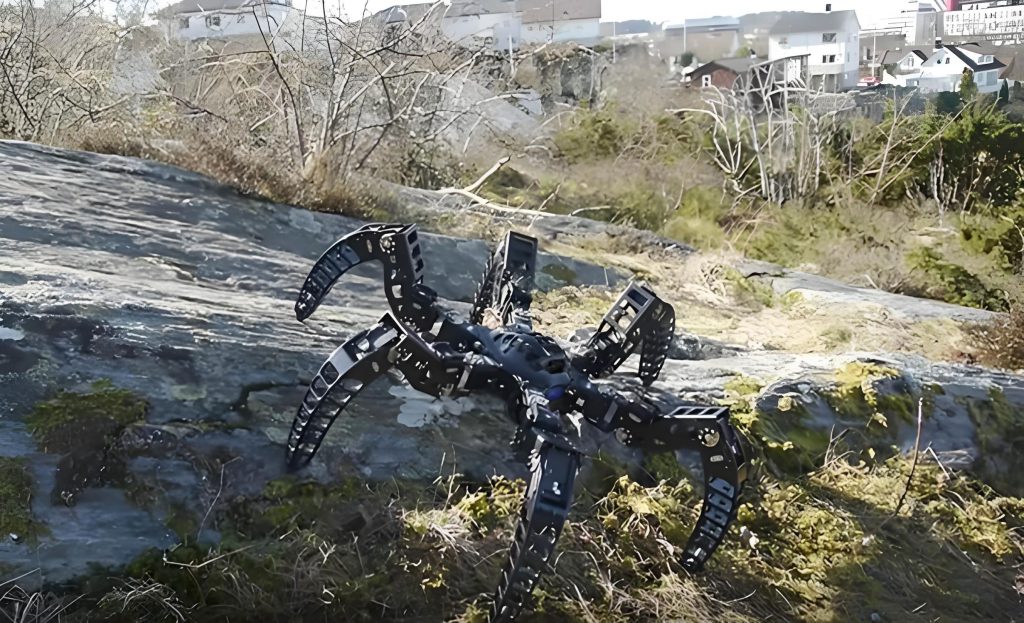
The quest to create agile, lifelike machines drives the field of bionics. A bionic robot, designed to mimic the movement and functionality of biological organisms, relies heavily on precise, coordinated joint actuation. This coordination is most often achieved using servo motors (servos), which convert electrical pulses into precise angular positions. Controlling a complex bionic robot with dozens of degrees of freedom presents a significant engineering challenge: generating numerous, independent, and highly accurate Pulse-Width Modulation (PWM) signals simultaneously. While microcontrollers (MCUs) and Digital Signal Processors (DSPs) are common choices, this paper argues for the superior efficacy of Field-Programmable Gate Arrays (FPGAs) in this domain. The inherent parallelism, deterministic timing, and reconfigurable hardware of an FPGA make it an ideal core for a multi-channel servo controller, enabling the smooth and complex motion sequences required by advanced bionic robot platforms.
The fundamental challenge in multi-servo control is the generation of multiple, concurrent PWM signals. The standard control signal for a hobbyist or robotic servo is a 50Hz PWM wave (20ms period) where the pulse width, typically between 0.5ms and 2.5ms, corresponds to an angular position from 0° to 180°. For a bionic robot with 12, 24, or more joints, a controller must manage an equal number of these PWM channels. A sequential processor like an MCU struggles with this task as the number of channels increases; servicing interrupts for each channel can lead to timing jitter, reduced bandwidth for other tasks, and complex, difficult-to-debug code. An FPGA, conversely, implements logic in hardware. A dedicated PWM generator can be instantiated for each servo channel, all running in perfect parallel from a common clock, guaranteeing absolutely jitter-free and simultaneous control. This hardware-centric approach is the cornerstone of a robust controller for a dynamic bionic robot.
System Architecture and Hardware Design
The proposed multi-channel servo control system is architected around an FPGA as the central, intelligent hub. The overall system block diagram encapsulates the flow from user command to physical actuator movement, tailored for the needs of a bionic robot. User input, perhaps from a higher-level planning system or a direct command interface, is received by the FPGA. Internally, the FPGA logic decodes this command, retrieves pre-programmed motion data from memory, and dispatches the corresponding PWM signals through dedicated output pins. These signals are then conditioned through protection circuitry before driving the servo motors that articulate the limbs or segments of the bionic robot. A dedicated, filtered power supply ensures stable operation for both the digital logic and the high-current servo motors.
| Component | Role in Bionic Robot Control | Key Specifications/Notes |
|---|---|---|
| FPGA (e.g., Cyclone IV EP4CE10) | Core controller; executes parallel logic for PWM generation, data fetching, and system coordination. | 10,320 LEs, 46 M9K memory blocks, 179 user I/Os. Enables true parallel control of all servos. |
| Digital Servo (e.g., LDX-218) | Actuator for robot joints; converts PWM signal to precise angular position. | Pulse: 0.5-2.5ms, Period: 20ms, Torque: 17kg-cm, Speed: 0.16s/60°. Ideal for robotic joints. |
| Opto-isolator (e.g., TLP280-4) | Protects FPGA I/O pins from back-EMF and current spikes generated by servos. | Critical for reliability; isolates the sensitive digital control domain from the noisy power domain of the actuators. |
| Voltage Regulator (e.g., AMS1117) | Provides clean, stable power to the FPGA core logic (3.3V). | Prevents logic errors or damage due to power noise, ensuring reliable operation of the bionic robot‘s brain. |
| Servo Power Supply | High-current supply (e.g., 7.4V Li-Po) for the servo motors. | Must be separate from logic supply to avoid brownouts during high-torque movements of the bionic robot. |
The choice of servo is critical for a bionic robot. Digital servos are preferred over their analog counterparts. A digital servo incorporates a microcontroller that receives the PWM command and employs higher-frequency internal control loops. This results in faster response, smaller deadband, higher holding torque, and better resistance to load changes. These characteristics directly translate to a more responsive, stable, and precise bionic robot, capable of holding poses firmly and moving quickly between them. The relationship between the command pulse width $PW$ and the resulting servo angle $\theta$ is linear:
$$\theta (in\ degrees) = \frac{(PW – PW_{min})}{(PW_{max} – PW_{min})} \times 180^\circ$$
where typically $PW_{min} = 500 \mu s$ and $PW_{max} = 2500 \mu s$.
The isolation circuit is a non-negotiable safety feature. Servo motors, especially when stalled or under high load, can generate significant back-electromotive force (back-EMF) and cause ground bounce. An opto-isolator like the TLP280 uses an LED and a phototransistor to transmit the PWM signal via light, creating a galvanic isolation barrier. This ensures that any electrical noise or voltage spikes from the servo power domain cannot propagate back to the fragile FPGA I/O pins, safeguarding the heart of the bionic robot controller.
FPGA Internal Logic Design and Core Modules
The true power of the FPGA-based controller lies in its internal architecture, implemented using a Hardware Description Language (HDL) like Verilog or VHDL. This design translates the system requirements into concurrent hardware modules operating on the FPGA fabric. The primary software/logic architecture for controlling the bionic robot consists of several key modules working in concert: a clock management unit, a command interpreter and address generator, a memory interface unit, and the core multi-channel PWM signal generators. The data flow begins with a command input, which triggers a read sequence from non-volatile memory (ROM) storing motion sequences, and culminates in the parallel update of all PWM generator modules.
The first essential module is the clock divider. The FPGA typically uses a high-frequency crystal oscillator (e.g., 50 MHz). To create the 20ms period (50Hz) base for the PWM signals, this clock must be divided down. A simple counter-based divider generates the precise timing backbone for the entire system. The time resolution for pulse width control is determined by the clock frequency used for the PWM counter. For a 100 kHz clock, the resolution is 10 µs, which for a 180° range yields an angular resolution of:
$$\text{Angular Resolution} = \frac{180^\circ \times 10 \mu s}{(2500 \mu s – 500 \mu s)} = 0.9^\circ$$
Higher clock frequencies yield finer control, crucial for smooth motion in a dexterous bionic robot.
| FPGA Logic Module | Primary Function | Key Implementation Details |
|---|---|---|
| Clock Manager / Divider | Generates all necessary clock domains from the master oscillator (e.g., 50 MHz -> 100 kHz, timing triggers). | Uses binary counters and state machines. Provides the fundamental timebase for PWM generation. |
| Command Decoder & Address Generator | Interprets input commands (e.g., “walk”, “turn”) and calculates the start address and length of the corresponding motion data in ROM. | Acts as a finite state machine (FSM). Maps high-level bionic robot actions to low-level memory pointers. |
| Memory Interface & FIFO Buffer | Reads sequential pulse-width data from ROM based on the address/length provided and buffers it for the PWM modules. | Utilizes FPGA block RAM configured as ROM and FIFO. Decouples memory read speed from PWM update rate, ensuring smooth data flow. |
| Multi-channel PWM Generator | The core module; a parallel array of identical sub-modules, each producing an independent PWM signal for one servo. | Each channel has a counter, a compare register, and control logic. Operates in perfect parallelism, enabling synchronized control of the entire bionic robot. |
The memory subsystem is vital for storing complex motion primitives for the bionic robot. A Read-Only Memory (ROM) IP core is initialized with data files containing the pulse-width values for every servo across all frames of an action sequence (e.g., a walking gait). The command decoder translates an action code into a starting address within this ROM and the number of data words to read (length). A First-In-First-Out (FIFO) buffer acts as a crucial intermediary. The memory interface unit fills the FIFO with data from the ROM. Each PWM generator channel then reads its specific data word from the FIFO at the appropriate time. This buffering architecture prevents timing bottlenecks and allows for the seamless streaming of motion data, which is essential for fluid, uninterrupted movement of the bionic robot.
The most significant module is the multi-channel PWM generator. Its design elegance lies in its scalability. A single PWM channel module is defined once in HDL. It consists of a free-running counter that resets every 20ms, a pulse-width register that holds the desired high-time value (loaded from the FIFO), and a comparator. The output signal is set high when the counter value is less than the pulse-width register value and low otherwise.
$$PWM_{output}(t) =
\begin{cases}
1, & \text{if } Counter(t) < PulseWidthRegister \\
0, & \text{otherwise}
\end{cases}$$
To control N servos, the FPGA design simply instantiates N of these channel modules. They all share the same global 20ms counter reset signal (or their own synchronized counters), ensuring all PWM periods start simultaneously. However, each channel’s pulse-width register is loaded with independent data. This results in N perfectly synchronized yet independently controlled PWM signals—exactly what is required to coordinate the multiple joints of a bionic robot. The number of channels is limited practically only by the number of I/O pins and logic elements on the FPGA, allowing a single chip to control a highly complex bionic robot with dozens of actuators.
Implementation, Verification, and Performance Analysis
The development process for the FPGA-based controller follows a standard digital design flow. The HDL code for all modules is written, synthesized, and then tested rigorously through simulation before being deployed to the physical hardware. Simulation is performed using tools like ModelSim. A testbench is written to provide stimuli (simulated command inputs) and to monitor the internal signals and outputs. The key verification steps include confirming that the address generator correctly interprets commands, that the memory interface reads the correct sequence of data from the ROM model, and that each PWM channel produces a signal with the exact pulse width corresponding to its assigned data. This simulation environment is indispensable for debugging the complex interactions within the bionic robot controller before hardware integration.
Following successful simulation, the design is compiled for the target FPGA. For real-world debugging and validation, in-system tools like SignalTap II Logic Analyzer are used. This tool allows the developer to specify internal signals (e.g., the address bus, data bus from the FIFO, PWM counter values) to be captured in real-time as the FPGA executes on the board. This provides a window into the actual hardware operation, confirming that the motion data is flowing correctly and that the PWM generators are being updated synchronously. It is the final step in verifying that the controller will reliably operate the physical bionic robot.
The performance advantages of this FPGA approach are substantial when applied to a bionic robot:
- Deterministic, Jitter-Free Timing: Because each PWM signal is generated by dedicated hardware logic, its timing is perfectly precise and unaffected by software loops or interrupt latencies. This leads to smoother servo movement and more accurate positioning.
- Massive Parallelism: Controlling 12, 24, or 50 servos requires no additional CPU overhead. The system complexity scales linearly with hardware resources, not with software complexity or processor load.
- High Flexibility and Reconfigurability: The motion repertoire of the bionic robot is defined by the data in the ROM. Changing actions requires only updating this data file, not re-engineering hardware. Furthermore, the FPGA logic itself can be reconfigured to add features like sensor feedback loops or communication interfaces.
- Compact and Integrated Solution: The entire multi-channel controller, potentially including memory and communication interfaces, fits into a single chip, reducing the size, weight, and power consumption of the control electronics—a critical factor for mobile or autonomous bionic robot platforms.
The system’s capability can be summarized by its fundamental channel update law. For a system with *C* channels, a PWM period of *T* (20ms), and a pulse-width resolution based on a clock period $t_{clk}$, the FPGA effortlessly manages the concurrent generation of all signals, a task that would strain a sequential processor.
Applications and Future Enhancements for Advanced Bionic Robots
The FPGA-based multi-channel servo controller finds its ideal application in sophisticated bionic robot projects. These include:
- Hexapod/Bipedal Walking Robots: Coordinating the 12, 18, or more servos required for stable, adaptive gait generation.
- Robotic Arms and Manipulators: Providing smooth, simultaneous control of shoulder, elbow, wrist, and gripper joints for precise trajectory following.
- Biomimetic Swimmer or Flyer Models: Controlling the complex, rhythmic actuation of fins or wings in real-time.
- Animatronic Figures: Driving the numerous facial and body actuators to create lifelike, expressive characters.
In each case, the FPGA’s ability to handle many channels with perfect timing ensures the bionic robot moves in a coordinated, natural, and reliable manner.
The presented design is a robust foundation that can be extended in several ways to create an even more intelligent and adaptive bionic robot controller:
- Integrated Closed-Loop Control: The FPGA can easily incorporate inputs from potentiometers (already inside servos) or external encoders to implement PID control loops directly in hardware for each joint, improving accuracy and disturbance rejection.
- Sensor Fusion and Real-Time Adaptation: Data from inertial measurement units (IMUs), force sensors, or vision systems can be processed in parallel within the FPGA to dynamically adjust motion sequences, enabling the bionic robot to balance on uneven terrain or grasp objects with variable weight.
- High-Level Communication Interfaces: Embedding a soft-core processor (like Nios II on Intel FPGAs) alongside the PWM control logic allows the FPGA to run a real-time operating system. This processor can handle high-level planning, network communication (ROS nodes), and complex sensor interpretation, sending simplified motion commands to the dedicated, low-level PWM hardware. This creates a powerful hybrid architecture perfect for advanced bionic robot research.
- Dynamic Motion Re-Loading: Replacing the static ROM with a volatile RAM block allows the bionic robot‘s motion sequences to be updated on-the-fly from a central computer or based on learned behavior, providing immense flexibility.
In conclusion, the utilization of an FPGA as the core of a multi-channel servo controller presents a paradigm shift from software-based sequential control to hardware-based parallel control. This approach directly addresses the fundamental requirements of a sophisticated bionic robot: precision, parallelism, determinism, and scalability. By implementing dedicated PWM generation channels, intelligent memory interfacing, and robust I/O protection, the FPGA-based system guarantees smooth, jitter-free, and coordinated control over a large array of actuators. The design is not only highly effective for current applications but also provides a flexible, reconfigurable platform for integrating feedback control and higher-level intelligence, paving the way for the next generation of autonomous, agile, and truly lifelike bionic robot systems. The inherent parallelism of hardware, as realized in the FPGA, is ultimately the most natural and powerful method to control the parallel actuation of a complex biological mimic.