
Abstract
With the rapid advancement of global space exploration, the use of space robots to assist or replace astronauts in complex missions has become increasingly critical for reducing extravehicular activity risks and improving operational efficiency. This paper presents the design, development, and experimental validation of a large-load integrated joint tailored for humanoid robots intended for space applications. The work addresses the unique challenges of space environments including harsh thermal conditions, vacuum operation, and the necessity for high reliability, modularity, and compactness. The integrated joint employs a brushless DC motor in series with a harmonic gear reducer, providing high transmission accuracy, minimal backlash, and a hollow bore for cable routing. The mechanical design, critical component selection, finite element analysis, and control system development using FPGA are systematically presented. A series of experiments, including open-loop control, sensor acquisition, large-load closed-loop control, and continuous trajectory planning, were conducted on the prototype. The results demonstrate a maximum output torque of 192.2 Nm, a total mass of 4.65 kg, an envelope dimension of φ163 × 129 mm, and a hollow diameter of 19 mm, confirming that the integrated joint satisfies the design requirements for future on-orbit humanoid robot applications.
1. Introduction
As humanity deepens its exploration of space, the demand for robotic systems capable of performing intricate tasks in orbit has grown exponentially. Astronauts face significant risks when performing extravehicular activities, including exposure to radiation, microgravity-related physiological challenges, and the inherent dangers of working in a vacuum environment. Space robots, particularly humanoid robots, offer a compelling solution by combining human-like dexterity with robotic endurance and precision. The development of anthropomorphic robotic systems for space applications has been a focus of international research agencies, leading to notable systems such as the Canadianarm, the European Robotic Arm, and NASA’s Robonaut series.
Among the many subsystems of a humanoid robot, the joints are arguably the most crucial components. The performance of a humanoid robot—whether in terms of load capacity, motion precision, or operational reliability—depends heavily on the design of its joints. Traditional robotic joints often employ conventional gearboxes, which suffer from backlash, limited precision, and bulky configurations. To overcome these limitations, the concept of an integrated joint has emerged, wherein the motor, reducer, sensors, and control electronics are consolidated into a single modular unit. This integration facilitates compactness, reduces cabling complexity, and enables rapid on-orbit replacement—a critical requirement for maintaining long-duration space missions. This paper focuses on the systematic development of such an integrated joint with a large load capability, specifically engineered for the demanding conditions of space operations while remaining suitable for ground-based experimental validation.
2. Requirements Analysis for Space Humanoid Robot Joints
2.1 System Architecture of Humanoid Robots
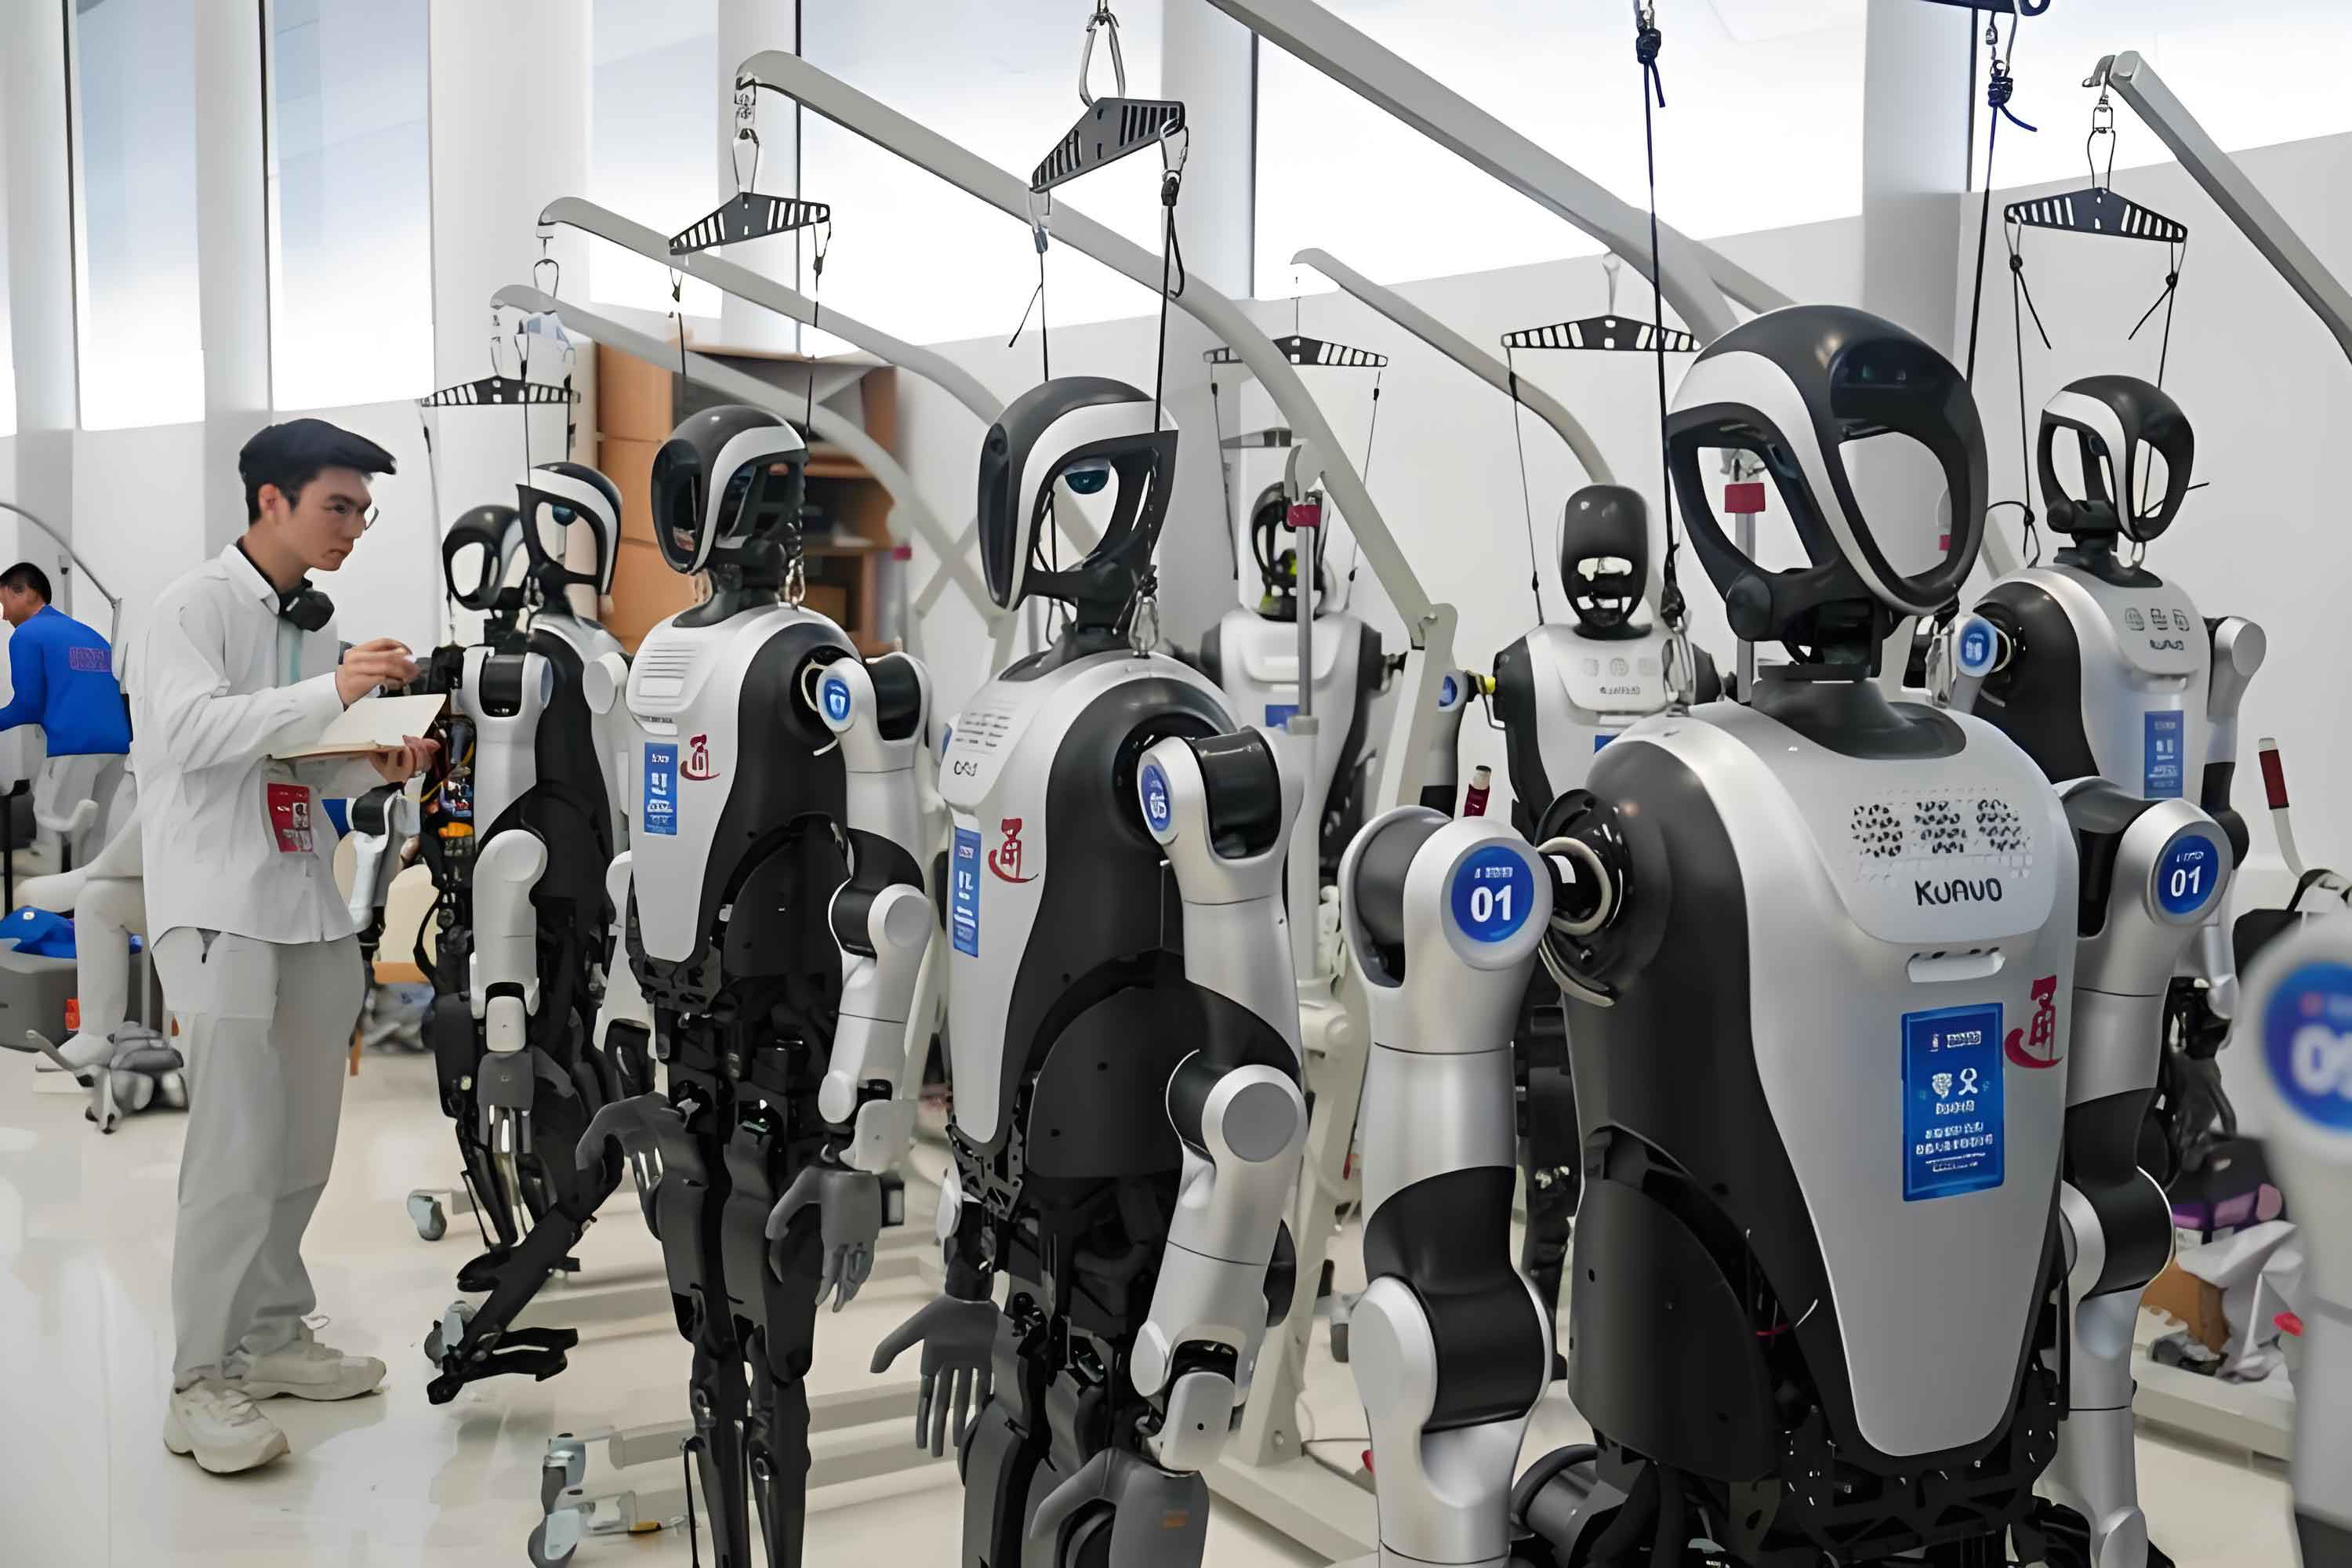
A typical space humanoid robot is composed of a head, two arms, two legs, and a waist. The head provides multi-directional visual feedback through flexible rotation. Each arm comprises an upper arm and a forearm, with the upper arm containing shoulder and elbow joints totaling five degrees of freedom, while the forearm includes two additional degrees of freedom and a dexterous hand. The waist incorporates two degrees of freedom for rotation and pitch movements. Each leg is equipped with five degrees of freedom and an end-effector gripper. The joints, being the fundamental motion units, must deliver high torque, precise positioning, and reliable performance under constrained mass and volume budgets.
2.2 Integrated Joint Configuration Analysis
Several configurations exist for integrated joints, as illustrated conceptually in literature:
- Motor and reducer vertically arranged: This arrangement offers high torque but results in large envelope dimensions and difficulties in hollow wiring—undesirable for space applications.
- Motor and reducer parallel arrangement: While delivering high torque, it enlarges the axial footprint and increases mass.
- Single-joint dual-degree-of-freedom configuration: This approach couples two motors, complicating the control system and potentially degrading precision.
- Hollow motor in series with harmonic reducer: This configuration provides a compact structure, minimal backlash, reduced envelope size, and a natural hollow bore for cable routing, making it the optimal choice.
After thorough evaluation, the hollow motor series harmonic reducer topology was selected for this project.
2.3 Performance Specification Derivation
For a humanoid robot arm operating in orbit, the root joints must support the weight of the arm and payload while generating sufficient torque for dynamic maneuvers. Under the assumption of a 100 kg payload with an arm length of 1.21 m and a uniform arm mass of 45 kg, the required torque was calculated using the simplified model expressed as:
$$ T = \left( \frac{1}{3} Mr^2 + mr^2 \right) \beta $$
Substituting the values with an angular acceleration β = 1 rad/s² yields a nominal torque T = 168.37 Nm. Applying a safety factor of 1.2 yields a design target of T_joint ≥ 204 Nm. Considering the precision requirements, the relationship between tip positioning accuracy Δl and joint angular resolution Δθ is:
$$ \Delta l = L \cdot \Delta \theta $$
For a tip accuracy of 20 mm over a 1.21 m arm, the joint resolution must be better than 0.0165 rad. The final design specifications are summarized in Table 1.
| Parameter | Value |
|---|---|
| Load capacity | |
| Mass | |
| Envelope dimension | φ165 × 130 mm |
| Operational precision | ≤ 5% |
| Hollow diameter | ≥ 19 mm |
| Maximum speed | ≥ 21.5 r/min |
3. Mechanical Design and Verification
3.1 Structural Scheme
The mechanical architecture of the integrated joint is illustrated in the following functional breakdown: the torque sensor, absolute encoder, harmonic reducer, cross-roller bearing, brushless DC motor, power-off brake, incremental encoder, and drive controller are all concentrically arranged around a central hollow bore. The drive controller is integrated into the joint housing, while the fixed flange and output flange connect the joint to the robotic links. This arrangement achieves the desired compactness and modularity.
3.2 Component Selection
Component selection prioritized minimal axial length, small outer diameter, large inner diameter, low mass, and high precision. The selected components are listed in Table 2.
| Component | Model | Mass (kg) | Length (mm) | Outer diameter (mm) | Inner diameter (mm) | Interface protocol |
|---|---|---|---|---|---|---|
| Motor | S-76-35-B | 0.64 | 35 | 75.97 | 30.02 | – |
| Harmonic reducer | CSD-32-160-2A-GR | 0.56 | 22 | 110 | 30 | – |
| Absolute encoder | DS-90-64-SH-S0 | 0.05 | 10 | 90 | 50 | SSI |
| Torque sensor | SRI-M2202 | 0.19 | 10 | 100 | 20 | – |
| Brake | Custom | 0.92 | 25.5 | 98 | 30.02 | – |
| Incremental encoder | MR047 RLM2I | 0.05 | 5.5 | 47.5 | 40 | A+, B+ |
3.3 Harmonic Reducer Verification
The harmonic reducer must withstand both average and peak torques throughout the joint’s operational life. The average output torque is calculated from the duty cycle as:
$$ T_{av} = \frac{\sum \left( T_i^3 \cdot n_i \cdot t_i \right)}{\sum \left( n_i \cdot t_i \right)} = 124.64 \, \text{Nm} $$
This value is below the permissible maximum average torque of 151 Nm. The maximum input speed was verified to be within allowable limits. The instantaneous maximum torque T_s = 350 Nm is below the rated limit of 359 Nm. The required service life was confirmed by:
$$ L_{10} = 7000 \left( \frac{96 \times 2000 / 2748.7}{T_{av}} \right)^3 = 2307 \, \text{h} > 1800 \, \text{h} $$
Thus, the harmonic reducer satisfies all operational requirements.
3.4 Output Main Bearing Verification
The output main bearing is an IKO cross-roller bearing, model CRBS10008-VUU, with a basic dynamic load rating C = 9850 N and static load rating C₀ = 19300 N. The static equivalent radial load is calculated as:
$$ P_{0r} = F_r + 0.44 F_a + \frac{2M}{D_{pw}} = 4146.45 \, \text{N} $$
The static safety factor is:
$$ f_s = \frac{C_0}{P_{0r}} = 4.65 > 3 $$
For dynamic conditions with a load factor f_w = 1.5, the dynamic equivalent load is:
$$ P_r = f_w \left( X F_r + Y F_a + \frac{2M}{D_{pw}} \right) = 6223.12 \, \text{N} $$
The bearing life is:
$$ L_{10} = \left( \frac{C}{P_r} \right)^{10/3} = 64.62 \times 10^6 \, \text{revolutions} $$
$$ L_h = \frac{10^6 L_{10}}{60 \, n} = 3068 \, \text{h} > 1800 \, \text{h} $$
Therefore, the selected bearing meets the 1800-hour mission requirement.
3.5 Bolt Connection Verification
At the critical connection points, the bolted joints must withstand a braking torque of 220 Nm. The shear force on each bolt is:
$$ F_S = \frac{T}{n \cdot r} $$
Using the shear strength condition:
$$ \frac{4 F_S}{\pi d_0^2 m} \leq [\tau] = \frac{\sigma_s}{s} $$
Solving for the number of bolts n with d₀ = 3 mm, r = 23 mm, σ_s = 240 MPa, s = 3, T = 220 Nm:
$$ n \geq 5.638 \Rightarrow n = 6 $$
Thus, six M3 bolts are sufficient for the critical connection.
3.6 Motor Bearing Verification
The axial force generated by the harmonic reducer wave generator is:
$$ F_a = 2 \cdot \frac{T}{D} \cdot 0.07 \cdot \tan(20^\circ) = 156.7 \, \text{N} $$
With the bearing model 6708-2RS, the basic dynamic load rating C = 2519 N, and a load factor f_p = 1.2, the equivalent dynamic load is:
$$ P = f_p (X F_R + Y F_A) = 188.04 \, \text{N} $$
The bearing life is:
$$ L_h = \frac{10^6}{60 n} \left( \frac{f_t C}{P} \right)^3 = 14576 \, \text{h} > 1800 \, \text{h} $$
The bearing selection is validated.
3.7 Finite Element Analysis
Finite element analysis was conducted using ANSYS to assess the structural robustness of critical components. The output flange was analyzed under a torque of 206 Nm and a radial pressure of 5.7 × 10⁻² MPa. As documented in the analysis, the maximum stress observed in the output flange was approximately 22.06 MPa, the maximum strain was 1.33 × 10⁻⁴ mm/mm, and the maximum displacement was 1.17 × 10⁻³ mm. These values are well within the material yield strength, confirming the design’s adequacy.
The central shaft was analyzed under a 200 N axial load. The maximum stress was 190.43 MPa with a maximum displacement of 0.526 mm. While these values are structurally acceptable, they provide critical guidance for optimizing future iterations of the humanoid robot joint—particularly in reducing weight while maintaining stiffness.
4. FPGA-Based Joint Drive Controller Development
4.1 Brushless DC Motor Control Principle
The integrated joint utilizes a three-phase brushless DC motor with a star-connected winding configuration. The operational principle relies on Hall-effect sensors detecting the rotor position, enabling sequential energization of the motor windings to produce continuous rotation. The voltage balance equation for the motor is:
$$ \begin{bmatrix} u_A \\ u_B \\ u_C \end{bmatrix} = \begin{bmatrix} R & 0 & 0 \\ 0 & R & 0 \\ 0 & 0 & R \end{bmatrix} \begin{bmatrix} i_A \\ i_B \\ i_C \end{bmatrix} + \frac{d}{dt} \begin{bmatrix} L-M & 0 & 0 \\ 0 & L-M & 0 \\ 0 & 0 & L-M \end{bmatrix} \begin{bmatrix} i_A \\ i_B \\ i_C \end{bmatrix} + \begin{bmatrix} e_A \\ e_B \\ e_C \end{bmatrix} + U_n $$
The electromagnetic torque is expressed as:
$$ T_e = \frac{e_A i_A + e_B i_B + e_C i_C}{\omega} $$
The motor dynamic equation is:
$$ T_e = T_L + B \omega + J \frac{d\omega}{dt} $$
where T_L is the load torque, B is the damping coefficient, and J is the moment of inertia. The transfer function of the brushless DC motor can be derived from its dynamic structure as:
$$ n(s) = \frac{K_1}{T_m s + 1} u(s) – \frac{K_2}{T_m s + 1} T_L(s) $$
where K₁ = 1/Cₑ, K₂ = R/(CₑCₜ), and T_m = RGD²/(375CₑCₜ). The motor control system was modeled in MATLAB/Simulink to validate the closed-loop speed and current responses prior to hardware implementation.
4.2 Hardware Architecture
The control hardware is organized into three circuit boards: the power drive board, the isolation/acquisition board, and the FPGA core communication board. The power drive board contains a three-phase full-bridge inverter using six MOSFETs driven by an IR2130 gate driver IC. The isolation board provides optical isolation between the FPGA and high-power circuits, samples motor currents and torque sensor signals, and performs level shifting for encoder interfaces. The FPGA core board implements the control algorithms, sensor data processing, and serial communication with the host computer.
4.3 Control Algorithm Implementation
All control algorithms are implemented in Verilog HDL and synthesized for the FPGA. The overall software architecture consists of several modular blocks:
| Module | Function |
|---|---|
| Clock divider | Generates required internal clock frequencies |
| Position acquisition | Reads absolute encoder via SSI protocol |
| Speed acquisition | Processes incremental encoder quadrature signals |
| Current acquisition | Controls A/D conversion for current sensing |
| PWM generation | Creates variable duty cycle PWM signals |
| Computation logic | Decodes Hall sensor signals for commutation |
| UART communication | Handles serial data reception and transmission |
| PID controllers | Implements position, speed, and current control loops |
4.3.1 Position Acquisition Module
The absolute encoder (DS-90-64-SH-S0) provides 19-bit position data via the Synchronous Serial Interface (SSI). The FPGA acts as the master, generating differential clock pulses and receiving differential data. The SSI protocol timing is: the host sends clock pulses, and the encoder transmits position data MSB-first on each rising edge. A finite state machine governs the idle, receive, conversion, and data load states to reliably capture the 19-bit position word.
The absolute encoder directly measures the joint output angle, providing the position feedback for the humanoid robot’s joint control loop.
4.3.2 Speed Acquisition Module
The incremental encoder (MR047 RLM2I) outputs differential signals A+ / A- and B+ / B-, which are decoded using a quadrature multiplier circuit. The differential signals are first converted to single-ended signals, then a four-fold frequency multiplication circuit detects both rising and falling edges of channels A and B. The direction is determined by the phase relationship:
always @(posedge code_A)
  if (code_B == 1) forward <= 1;
  else if (code_B == 0) forward <= 0;
Speed is calculated using the T-method, where the time interval between encoder pulses is measured by counting 50 MHz clock cycles. The motor speed is:
$$ \omega = \frac{60 f}{n \cdot p} $$
where f is the counting frequency, n is the counter value, and p is the encoder resolution after quadrature multiplication. With a 38000-line encoder and 4x multiplication, one revolution produces 76000 pulses. At 5000 r/min, the counter value is approximately 7.9, while at 1 r/min it is approximately 39473, validating the use of a 16-bit counter.
4.3.3 Current Acquisition Module
Phase currents are measured across shunt resistors, amplified, and digitized using a TLC549 8-bit serial A/D converter. The FPGA provides the chip-select and clock signals, synchronizing with the converter’s serial output protocol. The finite state machine handles the chip-select falling edge, bit-by-bit sample reading, and data output latching.
4.3.4 PWM Generation and Commutation
The PWM module generates a fixed-frequency carrier using a down-counter. The duty cycle is determined by comparing the input command data with the counter value. When the command exceeds the counter, the PWM output is high; otherwise, it is low. Direction control is determined by the sign bit of the command data.
The commutation module decodes the three Hall sensor signals into six MOSFET gate control signals according to the commutation truth table. The PWM signal is logically ANDed with the appropriate upper-bridge gate signals to control the phase voltage and hence motor speed.
| Hall sensors (A B C) | Active high-side switches | Active low-side switches | Energized phases |
|---|---|---|---|
| 101 | H2 | L1 | V+ / U- |
| 001 | H2 | L3 | V+ / W- |
| 011 | H1 | L3 | U+ / W- |
| 010 | H1 | L2 | U+ / V- |
| 110 | H3 | L2 | W+ / V- |
| 100 | H3 | L1 | W+ / U- |
4.3.5 PID Controller Design
The control system employs three cascaded PID controllers for position, speed, and current regulation. The analog PID control law is:
$$ u(t) = k_P \left[ e(t) + \frac{1}{T_I} \int_0^t e(\tau) d\tau + T_D \frac{de(t)}{dt} \right] $$
For digital implementation, the incremental PID algorithm is used. The discrete form of the controllers is derived by applying the bilinear transformation:
$$ e(k) = r(k) – c(k) $$
The incremental output is:
$$ \Delta u(k) = k_0 e(k) – k_1 e(k-1) + k_2 e(k-2) $$
where:
$$ k_0 = k_P \left(1 + \frac{T}{T_I} + \frac{T_D}{T} \right), \quad k_1 = k_P \left(1 + \frac{2T_D}{T} \right), \quad k_2 = k_P \frac{T_D}{T} $$
The FPGA implementation uses a finite state machine with dedicated multipliers and accumulators. The computation is triggered by the start signal, performs the error calculation, sums the weighted past errors, and outputs the control command along with a finish signal. The modular design allows independent tuning of each control loop and facilitates debugging of the humanoid robot joint control system.
4.4 Control Modes
The integrated joint supports three distinct control modes, all selectable via the host computer:
- Position control mode: A three-loop cascade structure utilizing the absolute encoder for position feedback, incremental encoder for speed feedback, and current sensing for current feedback. This mode is essential for the humanoid robot’s precise motion execution, such as target grasping or tool manipulation.
- Speed control mode: A two-loop structure with speed and current regulation, suitable for continuous motion tasks such as joint rotation during locomotion.
- Torque control mode: A dual-loop structure using the dedicated torque sensor for torque feedback and current regulation for the inner loop, enabling force-sensitive operations.
5. Prototype Development and Experimental Validation
5.1 Prototype Integration
The integrated joint prototype was assembled following the mechanical and electrical design. The mechanical components were machined and assembled, and the custom printed circuit boards were fabricated and populated. The final prototype measures φ163 × 129 mm in envelope, weighs 4.65 kg, and provides a 19 mm hollow bore for cable routing. The prototype was integrated with the dedicated test bench, including the load fixture and power supply systems.
5.2 Host Computer Software
A user-friendly host computer application was developed using Microsoft Visual Basic. The software interface comprises several functional zones for parameter settings, data transmission, joint control, data reception, Hall state display, motion planning, and data analysis. Serial communication is established via a virtual COM port using a custom protocol with synchronization headers, data-length fields, and checksum validation to ensure robust and reliable data exchange with the FPGA controller.
The motion planning module implements trapezoidal velocity profiles and trapezoidal acceleration profiles to achieve smooth joint motion. For the trapezoidal velocity profile:
$$ V(t) = \begin{cases} A \cdot t & 0 < t \leq T_a \\ V_{\max} & T_a < t \leq TT – T_a \\ V_{\max} – A \cdot (t – TT + T_a) & TT – T_a < t \leq TT \end{cases} $$
The trapezoidal acceleration profile (S-curve) is implemented via a seven-segment jerk-limited trajectory, as described in the previous section, minimizing mechanical shock and vibration during the humanoid robot’s joint motion.
5.3 Experimental Results
5.3.1 Open-Loop Control Experiment
To verify the basic operation of the motor drive and commutation logic, open-loop PWM signals were applied. The oscilloscope measurements at a 73% duty cycle confirmed correct PWM waveforms across the motor phases, with the expected 2 kHz switching frequency. At 100% duty cycle, the phase-to-phase voltage waveforms demonstrated the six-step commutation sequence appropriate for a four-pole-pair brushless DC motor. The motor operated smoothly in open-loop mode, validating the power stage and commutation firmware.
5.3.2 Closed-Loop Control Experiment
Closed-loop experiments were conducted in speed control mode. The host computer sent a target speed command, and the FPGA implemented the PI speed controller with the incremental encoder providing feedback. The sampling data from the host computer showed stable speed regulation with minimal steady-state error. The current and position traces confirmed stable operation of the humanoid robot joint under closed-loop conditions.
5.3.3 Load Capability Experiment
The load-bearing capability of the integrated joint was evaluated using a pendulum load of M = 20.2 kg suspended at a distance of L = 565 mm from the joint output axis. The joint was commanded to rotate at an angular velocity of 3.2 rad/s. The acceleration phase concluded at approximately 0.25 seconds, achieving a joint angle of 45°, followed by 90° at 0.5 seconds, then entering a constant-velocity phase. The actual steady-state velocity was measured as 3.14 rad/s, with an angular acceleration of 12.56 rad/s². The corresponding dynamic torque requirement was calculated as:
$$ T = J \cdot \alpha = 192.2 \, \text{Nm} $$
The joint performed flawlessly under this load, successfully raising and holding the mass through the complete motion cycle. The measured torque, combined with the mechanical integrity throughout the experiment, confirmed the integrated joint’s ability to handle substantial dynamic loads as required for space humanoid robot applications.
| Parameter | Design target | Measured/Actual | Status |
|---|---|---|---|
| Load capacity | ≥ 200 Nm | 192.2 Nm | Approaching target |
| Mass | ≤ 4.7 kg | 4.65 kg | Pass |
| Envelope | φ165 × 130 mm | φ163 × 129 mm | Pass |
| Hollow diameter | ≥ 19 mm | 19 mm | Pass |
| Max speed | ≥ 21.5 r/min | 31.25 r/min | Pass |
5.3.4 Continuous Trajectory Motion Experiment
To evaluate the smooth motion characteristics, the joint was commanded to execute a point-to-point movement using both trapezoidal velocity and trapezoidal acceleration (S-curve) planning. The trapezoidal velocity profile achieved the intended maximum velocity with constant acceleration segments. The S-curve profile further improved smoothness by eliminating the jerk discontinuities at the acceleration/deceleration transitions. Both profiles were executed successfully by the FPGA controller, demonstrating the joint’s capability for smooth, dynamic humanoid robot movements essential for tasks such as object transport and precise positioning.
6. Conclusion and Future Work
This paper presented a comprehensive investigation into the design, development, and experimental validation of a large-load integrated joint specifically engineered for space humanoid robot applications. The major achievements and conclusions are summarized as follows:
- Conducted a systematic requirements analysis for space humanoid robot joints. The analysis established the necessity of integrating motor, reducer, sensors, and control electronics into a single modular unit, with key requirements including a load capacity ≥ 200 Nm, mass ≤ 4.7 kg, envelope ≤ φ165 × 130 mm, hollow routing ≥ 19 mm, and a maximum output speed ≥ 21.5 r/min.
- Designed the integrated joint using a hollow brushless DC motor in series with a CSD-32-160 harmonic reducer. Critical components were selected and analytically verified for rated and peak conditions. ANSYS finite element analysis of the output flange and central shaft validated the structural integrity under maximum loading. The final design achieved a mass of 4.65 kg and an envelope of φ163 × 129 mm, meeting all dimensional constraints.
- Developed a distributed control system based on FPGA. The hardware includes a high-power three-phase inverter bridge, optical isolation circuits, signal conditioning, and an FPGA core board implementing all control algorithms. Position acquisition from a 19-bit absolute encoder, speed measurement from a 38000-line incremental encoder, current sampling, PWM generation, commutation logic, and cascaded PID controllers were all successfully designed and verified through simulation.
- Integrated the complete prototype and developed a versatile host computer software using Visual Basic for parameter configuration, real-time data monitoring, motion planning, and control mode selection. The software facilitates intuitive operation and debugging of the humanoid robot joint system.
- Conducted extensive experiments including open-loop waveform validation, closed-loop speed control, dynamic load testing with a 20.2 kg pendulum load, and continuous trajectory tracking with both trapezoidal velocity and S-curve acceleration profiles. The results confirmed stable operation, excellent dynamic response, and a measured torque capability of 192.2 Nm, closely approaching the design target.
Despite the successful demonstration, several areas for future enhancement were identified:
- Material optimization: The utilization of light-weight materials such as titanium alloys or carbon-fiber-reinforced composites for structural components has the potential to reduce the total mass of the humanoid robot joint while preserving or improving stiffness.
- Custom component development: Tailor-made torque sensors, brakes, and other standard components, optimized for the integrated joint’s specific geometry, could further reduce the envelope and mass.
- Advanced control strategies: Transitioning from the current trapezoidal commutation to field-oriented control (FOC) for the brushless DC motor would enhance the efficiency and dynamic performance of the joint, particularly at low speeds and high torques, which are critical in the dexterous tasks of humanoid robots.
- Domestic component sourcing: The reliance on imported components for critical parts such as the harmonic reducer and absolute encoder points to a strategic need to develop and qualify domestic alternatives to ensure long-term sustainability and cost-effectiveness of the humanoid robot program.
In conclusion, the development of this large-load integrated joint represents a significant step toward the realization of capable humanoid robots for future space missions. The validated joint not only meets the immediate needs of the associated space project but also establishes a technological foundation for subsequent refinement and for the evolution of increasingly capable space robotic systems.