
At the opening ceremony of the Second World Humanoid Robot Games, fifty Tiangong humanoid robots moved around the National Speed Skating Oval in a steady, orderly formation. They relied on precise autonomous navigation, holding their positions and rhythms as if they were athletes taking part in a coordinated parade. The scene looked simple: a group of humanoid robots walking together. Behind it, however, was a much more demanding engineering test. Zhang Xiangyu, a young navigation algorithm engineer at the Beijing Humanoid Robot Innovation Center, was responsible for the formation entry of these Tiangong humanoid robots. For him, the formation was not merely a display. It was a high-intensity test of swarm intelligence for humanoid robots.
“A formation entry may look like humanoid robots walking forward in an orderly way, but in reality it is a high-intensity test of swarm intelligence,” Zhang said. “For example, when fifty humanoid robots start at the same time, they cannot rely on a single simple command. Every humanoid robot must have its own position, its own path, and its own rhythm, while remaining consistent with the entire formation. They must understand collective instructions and also make local adjustments based on what is happening in front of them.”
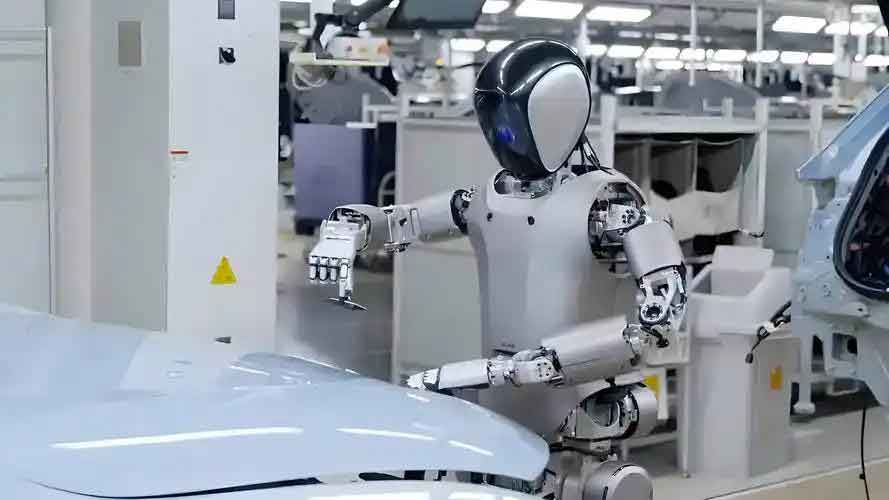
For a humanoid robot to walk steadily, task planning in the “brain” is not enough. Motion ability is equally important. In the industry, this ability is compared to the humanoid robot’s “little brain”: it continuously senses posture and position, corrects gait and speed in real time, and maintains balance and safe operation when the ground rises or falls, when localization jitters, or when sudden interference occurs. The navigation and collaboration work done by Zhang is precisely what helps a humanoid robot develop a powerful little brain.
-
A Formation of Humanoid Robots Is a Test of Swarm Intelligence
The formation entry at the National Speed Skating Oval was not designed as a simple procession. It was designed as a coordinated task for many humanoid robots at once. A humanoid robot that walks alone can focus on its own balance, its own path, and its own safety. A humanoid robot that walks with forty-nine others must do all of that while also respecting a shared formation. The difficulty is not only technical. It is also conceptual. The humanoid robot must understand that it belongs to a larger body of machines, even as it remains responsible for its own immediate surroundings.
Zhang explained that when fifty humanoid robots begin moving together, a single command is not enough. Each humanoid robot needs its own position, its own route, and its own timing. At the same time, each humanoid robot must stay aligned with the group. That means every humanoid robot must listen to the collective instruction and also respond to local conditions. If the ground changes under one humanoid robot, or if another humanoid robot nearby shifts slightly, the individual humanoid robot cannot simply ignore the difference. It must adjust without breaking the whole formation.
This is why the demonstration was described as a high-intensity test of swarm intelligence. In a laboratory, a humanoid robot may perform well under controlled conditions. In a real venue, however, conditions are never perfectly controlled. Localization may fluctuate. A humanoid robot may react a little more slowly during a turn. Another humanoid robot may deliberately reduce speed because of ground conditions, gait state, or safety strategy. These differences are small when considered one by one. When fifty humanoid robots are moving together, those small differences can be amplified across the entire formation.
The real challenge is therefore not to make fifty humanoid robots succeed once in a single demonstration. The real challenge is to make them safe, stable, and repeatable under real-site fluctuations and interference. A formation that works only when everything is perfect is not a reliable formation. A formation that works when one humanoid robot drifts slightly, when another turns late, and when a third slows down for safety is a formation that demonstrates true swarm intelligence.
In such a system, fifty humanoid robots correspond to fifty “little brains” thinking at the same time. If one humanoid robot experiences a localization fluctuation, a delay in turning, or a voluntary reduction in speed because of its safety strategy, its little brain must complete a correction in a very short time. It may need to adjust its path slightly, constrain its speed, and re-engage with the formation. It cannot allow the error to travel with it all the way to the endpoint. In other words, the quality of the formation depends on whether the little brain of each humanoid robot is stable enough to absorb disturbance quickly.
This is a shift in how engineers think about humanoid robot motion. A humanoid robot is no longer only a single machine that must complete a task. It is also a member of a coordinated group. The little brain of each humanoid robot must be capable of both independence and alignment. It must be able to act locally while respecting a shared mission. That combination is what makes a formation of humanoid robots more than a visual spectacle. It becomes a practical test of how humanoid robots can work together in the real world.
-
Unified Rules and Flexible Local Decisions for Every Humanoid Robot
To meet this challenge, Zhang and his colleagues did not ask fifty humanoid robots to follow a rigid, mechanical rhythm. They did not force every humanoid robot to synchronize every step in an inflexible way. Instead, they gave each humanoid robot’s little brain a set of collaboration rules that were both unified and flexible. The rules were unified because the humanoid robots needed to share the same task. The rules were flexible because each humanoid robot needed room to make local decisions.
The unified part included the task time, the formation target, and the safety boundary. These elements gave the group a common direction. Every humanoid robot needed to know when the task should be completed, what the overall formation should look like, and what safety limits could not be crossed. Without these shared rules, the formation would fragment. A humanoid robot might optimize only for its own path and create danger for another humanoid robot. A humanoid robot might move too quickly and break the group’s timing. A humanoid robot might focus so much on the formation that it ignored an immediate obstacle.
The flexible part was the local decision authority given to each humanoid robot. Within the shared rules, each humanoid robot could make fine adjustments based on its actual position, its motion state, and the situation immediately in front of it. This allowed the humanoid robot to absorb the small fluctuations and disturbances that are unavoidable on a real site. If a humanoid robot detected a slight localization drift, it could correct its path. If it noticed that it was approaching a turn too quickly, it could adjust its speed. If it sensed that the space around it was becoming less safe, it could take action according to its safety strategy.
In this way, the humanoid robots shared the same general direction while also taking care of the small conditions under their own feet. The formation did not depend on every humanoid robot being exactly the same. It depended on every humanoid robot being able to manage its own local error within a common framework. The neatness of the formation came from fifty little brains digesting their own errors inside the same set of rules.
Zhang described this as a process from single-machine intelligence to swarm intelligence. Single-machine intelligence means that one little brain can continuously perceive, continuously correct, and continuously judge in a complex environment. Swarm intelligence means that many little brains can align with one another under the same task and tolerate one another’s errors. The first is about individual capability. The second is about collective reliability. A humanoid robot that is intelligent alone may still fail in a group if it cannot align with others. A group of humanoid robots that can align and tolerate variation can accomplish tasks that no single humanoid robot could complete alone.
Dimension Single Humanoid Robot Intelligence Swarm Intelligence for Humanoid Robots Primary focus One humanoid robot perceiving, moving, and staying safe Many humanoid robots aligning under one task while tolerating individual variation Perception The humanoid robot senses its own posture, position, and surroundings Each humanoid robot senses locally while also respecting the shared formation Decision-making The humanoid robot chooses a local path and speed The humanoid robot follows common rules but keeps local decision authority Correction The humanoid robot corrects its own gait, path, and balance The humanoid robot corrects local errors so they do not spread through the group Safety The humanoid robot protects itself and nearby people or objects The humanoid robot respects a shared safety boundary while managing immediate risk Formation Formation is not the main concern Formation remains stable even when individual humanoid robots fluctuate Main challenge Complex environments and continuous correction Alignment, tolerance, and repeatable performance under disturbance -
Why Humanoid Robots Are Not Identical Copies
The biggest difficulty, according to Zhang, is that humanoid robots are not completely identical copies of one another. Even when they come from the same development effort, each humanoid robot may behave slightly differently. One humanoid robot may show a small fluctuation in localization. Another humanoid robot may react a little more slowly when turning. A third humanoid robot may voluntarily reduce speed because of ground conditions, gait state, or safety strategy. These differences are not necessarily defects. They are part of operating real humanoid robots in real environments.
For a single humanoid robot, a small error may be easy to manage. The little brain can correct the path, adjust the speed, and continue. For fifty humanoid robots moving together, however, even a small error can be amplified. If one humanoid robot drifts slightly to the side, the humanoid robot next to it may need to adjust. That adjustment may affect another humanoid robot. Soon, a local variation can become a formation-level problem. This is why the challenge is not simply about making each humanoid robot walk well. It is about making many humanoid robots walk well together.
The challenge is also about repeatability. A formation of humanoid robots may succeed once when conditions are favorable. But a successful demonstration is not enough for real deployment. The humanoid robots must be able to perform safely and stably again and again, even when the site has fluctuations and interference. They must be able to recover from small disturbances without human intervention. They must be able to keep the formation without turning every small error into a large failure.
This is where the little brain becomes essential. When a humanoid robot detects that its position is slightly wrong, its little brain must decide how to correct the error without creating a new problem. When a humanoid robot turns late, its little brain must adjust the path and speed to rejoin the formation smoothly. When a humanoid robot slows down for safety, its little brain must communicate that change through behavior and allow nearby humanoid robots to adapt. The goal is not to eliminate all variation. The goal is to keep variation within safe limits and prevent it from being carried all the way to the endpoint.
In this sense, the formation is a continuous negotiation among humanoid robots. Each humanoid robot is responsible for its own local situation, but each is also responsible for the shared result. The little brain is the mechanism that makes this negotiation possible. It allows the humanoid robot to sense, judge, and adjust in real time. It allows the humanoid robot to remain an individual while also acting as part of a group.
-
From One Humanoid Robot to Fifty: The Work of a Navigation Algorithm Engineer
Zhang graduated last year from Beihang University with a master’s degree in Transportation Engineering. He then joined the Beijing Humanoid Robot Innovation Center. In his view, the humanoid robot industry has broad prospects. Soon after joining, he and his colleagues formed a team and won the 2026 Robot Warriors Challenge. At that time, he was responsible for debugging only one humanoid robot. Now he is responsible for the formation debugging of fifty humanoid robots. The change in scale reflects both the rapid development of the humanoid robot field and the growing complexity of the work.
At the Beijing Humanoid Robot Innovation Center, there are many young engineers like Zhang. Their daily research is full of energy, and the laboratory is filled with young people. Team members were born in the 1990s and 2000s, and they cooperate with a natural sense of understanding. Some work on models and perception. Some work on control. Some work on navigation software. Together, they support the humanoid robot as if it were a new colleague who needs many people to take care of it. One person helps it see clearly. Another helps it think clearly. Another helps it stand steadily and walk well.
For Zhang, the work has a strong sense of contrast. Sometimes he sits in front of a computer, studying maps, trajectories, and data. At other times, he runs after a humanoid robot on site, trying to understand why it slowed down in one place, drifted in another, or suddenly stopped. Many people imagine that navigation means drawing a line on a map. In real research and development, it is more like teaching a humanoid robot to understand the world. The code must not only produce a result on a screen. It must produce a result in the physical environment.
The effectiveness of a piece of code is measured by whether the humanoid robot can complete its task in the real world. If the path planning is improved, the humanoid robot may avoid one unnecessary turn. If the speed and safety distance are tuned well, the humanoid robot may move more naturally beside people. If exception handling is done well, the humanoid robot will not panic and spin in place when something unexpected happens. These are practical improvements, but they require continuous iteration. Each adjustment must be tested on a real humanoid robot in a real environment.
This is why Zhang finds the feedback of “code becoming real action” especially attractive. In many software fields, code changes are observed through screens, logs, or metrics. In humanoid robot research, a change in code can be seen in the way a humanoid robot moves. A humanoid robot may turn more smoothly. It may keep a safer distance. It may recover from a disturbance more gracefully. The physical behavior of the humanoid robot gives immediate meaning to the abstract work of algorithm development.
Role Area in Humanoid Robot Development Contribution Result for the Humanoid Robot Models and perception Helps the humanoid robot understand its environment and its own state The humanoid robot can see more clearly and sense changes more reliably Control Helps the humanoid robot regulate motion, balance, and gait The humanoid robot can stand steadily and walk well Navigation software Helps the humanoid robot plan paths, localize itself, and collaborate The humanoid robot can move safely toward a destination System integration Brings perception, control, navigation, and safety together The humanoid robot operates as a complete system rather than separate parts Scenario deployment Tests the humanoid robot in real environments The humanoid robot becomes more practical and more reliable -
The Feedback of Code Becoming Real Action
Navigation for a humanoid robot is often misunderstood. It is not simply about drawing a line between two points on a map. It is about giving the humanoid robot a sense of where it is, where it should go, and how to get there safely. This requires continuous perception and continuous correction. The humanoid robot cannot assume that the world will remain unchanged. People move. Obstacles appear. Floors vary. Localization may drift. The little brain must process these changes and respond in real time.
In Zhang’s work, a successful navigation system allows the humanoid robot to complete a task in a real environment. If the path planning is optimized, the humanoid robot may reduce unnecessary turns. If speed and safety distance are properly tuned, the humanoid robot may move more naturally near people. If exception handling is well designed, the humanoid robot may avoid panicked behavior when something unexpected occurs. These outcomes are not abstract. They are visible in the motion of the humanoid robot.
This is the attraction of humanoid robot research. A line of code can change how a humanoid robot behaves in the physical world. A small improvement in perception can help the humanoid robot see an obstacle earlier. A small improvement in control can help the humanoid robot maintain balance on uneven ground. A small improvement in navigation can help the humanoid robot choose a better route. When these improvements combine, the humanoid robot becomes more capable, more stable, and more useful.
For Zhang, the most rewarding moment is when the code stops being only code. It becomes action. The humanoid robot moves differently because of a change made in the software. It responds differently because of a new rule. It completes a task that it could not complete before. This feedback loop between software and physical behavior is what makes humanoid robot development especially engaging. It also explains why the field demands both careful analysis and hands-on experimentation.
-
Continuous Perception, Continuous Correction, Continuous Judgment
In the past, robots were more likely to execute actions along fixed routes. They followed pre-planned paths and repeated predetermined motions. Today, the focus is shifting. Engineers are paying more attention to how a humanoid robot continuously perceives, continuously corrects, and continuously judges during a task. The humanoid robot is not expected to wait until it has gone wrong before turning back. It is expected to keep confirming its state as it moves.
Zhang often puts himself in the role of the humanoid robot during development. He imagines the humanoid robot asking itself: Is my current position correct? Is my speed appropriate? Is my surroundings safe? These questions are not answered once at the beginning. They are answered continuously throughout the task. The humanoid robot must keep checking its position against the plan. It must keep checking its speed against safety limits. It must keep checking the environment for people, obstacles, and changes.
This continuous process is the core of the little brain. The little brain does not simply command the humanoid robot to move. It helps the humanoid robot understand whether the movement is going well. It helps the humanoid robot detect small deviations before they become large errors. It helps the humanoid robot maintain balance when the ground is not perfect. It helps the humanoid robot adapt when another humanoid robot nearby changes speed or position.
As continuous perception and correction technologies improve, they will accelerate the movement of humanoid robots from the laboratory to more application scenarios. A humanoid robot that can only follow a fixed route has limited use. A humanoid robot that can perceive, correct, and judge continuously can work in more open and dynamic environments. It can move around people. It can handle unexpected obstacles. It can adjust its behavior when conditions change. This is a necessary step for the humanoid robot to become a practical tool in everyday life.
-
Building the Talent and Ecosystem for Humanoid Robots
At the Beijing Humanoid Robot Innovation Center, the presence of young engineers is striking. Many of them are working on core algorithms, core components, system integration, and scenario deployment. Tao Yong, an associate professor at Beihang University’s School of Mechanical Engineering and Automation and the Institute of Embodied Intelligence Robotics, said that the humanoid robot is a multidisciplinary innovation field. Young researchers have contributed their energy and talent to many aspects of humanoid robot development.
Universities such as Beihang University have already opened programs in embodied intelligence. However, the demand for talent remains urgent. The cultivation and recruitment of the talent needed for humanoid robot development still require further strengthening. In Tao’s view, the young talent team is a core element in the development of embodied intelligence and the humanoid robot field. The humanoid robot is not built by one discipline alone. It requires mechanical engineering, control, computer science, artificial intelligence, perception, navigation, and many other areas. It also requires people who can integrate these areas into a working system.
Beijing has already taken a leading position in the humanoid robot and embodied intelligence industry. According to Tao, Beijing has a complete ecosystem from basic research to innovation and entrepreneurship. This ecosystem has not appeared overnight. It is the result of long-term effort. The humanoid robot field needs sustained investment in research, education, and application. It also needs opportunities for young engineers to work on real systems and real tasks.
The formation of fifty Tiangong humanoid robots at the National Speed Skating Oval is one example of this ecosystem in action. It brought together navigation, perception, control, safety, and collaboration. It required young engineers to solve problems that cannot be solved by theory alone. It also showed how a humanoid robot can move from a single-machine demonstration toward a coordinated group task. The experience gained from such a project can feed back into future humanoid robot development.
-
The Road Ahead for Humanoid Robot Navigation
Zhang and his colleagues are now aiming their navigation work at industrial, commercial service, and family scenarios. In the future, a humanoid robot will not only need to complete a single action. It will need to understand a task and complete it from beginning to end. For example, if a humanoid robot is instructed to deliver an item to a designated location, it must understand where the destination is. It must decide how to get there. It must avoid people and obstacles along the way. It must also complete the handover or operation after arrival.
Navigation in this context is like the humanoid robot’s spatial intuition. It allows the humanoid robot to know where it is, where it should go, and how to travel safely. This is more than path planning. It is a continuous process of understanding space and motion. The humanoid robot must maintain a mental model of its position. It must update that model as it moves. It must connect its current state to its goal. It must also anticipate what may happen next.
In the future, a humanoid robot will need to move autonomously through complex spaces. It will also need to gradually acquire navigation capabilities for more open environments. A factory floor, a shopping mall, an office, and a home all have different layouts, rules, and patterns of human activity. A humanoid robot cannot rely on a single solution for all of them. It must be able to adapt its navigation strategy to the environment. It must be able to learn from experience and improve over time.
The goal, as Zhang puts it, is to make humanoid robot navigation more intelligent. This goal is not only about moving from one point to another. It is about enabling the humanoid robot to understand a task, interact with the environment, and complete the task safely. It is about making the humanoid robot useful in real settings. It is also about making the humanoid robot reliable enough that people can trust it in their daily lives.
Application Direction for Humanoid Robot Navigation What the Humanoid Robot Must Understand What the Humanoid Robot Must Do Industrial environments Workspace layout, safety zones, movement rules Move materials or tools safely and repeatably Commercial service Public space flow, customer safety, service points Guide, deliver, assist, or interact with people Family settings Home layout, household objects, personal space Support daily tasks while respecting safety and privacy Open environments Unpredictable obstacles, changing conditions, social rules Adapt navigation continuously and avoid dangerous behavior -
Why the Little Brain Matters for the Future of Humanoid Robots
The formation at the National Speed Skating Oval showed more than coordinated movement. It showed how much depends on the little brain of each humanoid robot. A humanoid robot may have strong task planning in its brain, but without a capable little brain, it cannot move safely or steadily. It cannot adjust to uneven ground. It cannot recover from localization errors. It cannot coordinate with other humanoid robots. The little brain is what connects intention to action.
In the formation, fifty humanoid robots had to move as one while remaining individually responsible for their own local conditions. Each humanoid robot had to sense its own position and speed. Each humanoid robot had to correct its own path. Each humanoid robot had to respect the shared formation and safety boundary. The result was a demonstration of swarm intelligence, but it was built on the continuous work of individual little brains.
This principle applies beyond the formation. As humanoid robots move into factories, service spaces, and homes, they will face environments that are far more complex than a controlled demonstration. They will encounter people, obstacles, changing layouts, and unexpected events. They will need to keep their balance, plan their paths, and avoid danger. They will need to understand tasks and complete them. In all of these situations, the little brain will be essential.
The work of young engineers such as Zhang Xiangyu reflects the broader development of the humanoid robot field. It is a field that combines software and hardware, perception and action, individual intelligence and collective behavior. It requires patience, experimentation, and continuous correction. It also requires a long-term view. The humanoid robot of the future will not become capable overnight. It will be shaped by many small improvements in navigation, control, perception, and collaboration.
What the formation demonstrated is that a humanoid robot can be more than a single machine following a fixed path. A humanoid robot can be part of a coordinated group. It can share a task with other humanoid robots. It can adapt to local conditions. It can absorb error and continue. This is the direction of humanoid robot development: from single-machine intelligence to swarm intelligence, from fixed routes to continuous perception and correction, and from laboratory demonstrations to real-world applications.
The goal is not only to make humanoid robots walk in a straight line. The goal is to make humanoid robots understand space, complete tasks, and work safely among people. The little brain is the foundation of that goal. As navigation becomes more intelligent, the humanoid robot will become more useful. As collaboration becomes more robust, groups of humanoid robots will be able to perform tasks that a single humanoid robot cannot. The future of the humanoid robot will be built by many little brains, each sensing, correcting, and judging, while aligning with a shared mission.