
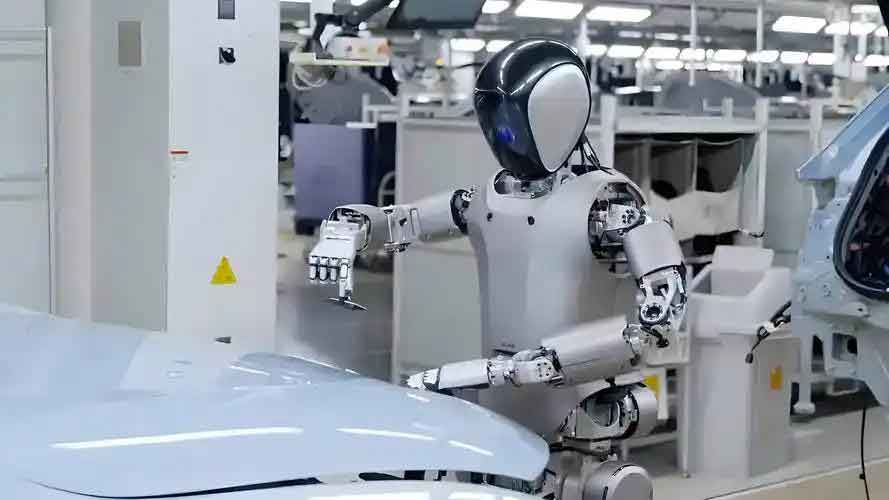
Policy signals, industrial ambition, and rapid technological convergence are placing the humanoid robot at the center of a new phase in robotics engineering education. In November 2023, the Ministry of Industry and Information Technology issued the Guiding Opinions on the Innovative Development of Humanoid Robots. That document set a clear trajectory: by 2025, an initial innovation system for the humanoid robot should be established, with breakthroughs in key technologies such as the brain, cerebellum, and limbs, and with safe and effective supply of core components. By 2027, the innovation capacity of the humanoid robot sector should be significantly improved, a safe and reliable humanoid robot industrial chain and supply chain system should be formed, an industrial ecosystem with international competitiveness should be built, and comprehensive strength should reach an advanced world level.
In January 2024, the Ministry of Industry and Information Technology and six other departments issued the Implementation Opinions on Promoting the Innovative Development of Future Industries. Within the effort to create landmark products, the document explicitly called for breakthroughs in core technologies for the humanoid robot, including high-torque motors, high-dynamic motion planning and control, imitation perception and cognition, intelligent dexterous hands, and electronic skin. It also emphasized advancing product development and application in intelligent manufacturing, home services, and special-environment operations. Against this backdrop, Elon Musk, founder of Tesla, predicted that the future humanoid robot industry market will be larger than the automobile industry and will have a market scale exceeding one hundred billion. Such expectations have intensified the demand for engineers who understand not only robotics as a whole but also the mechanical foundations that make a humanoid robot reliable, efficient, and manufacturable.
1. Policy Momentum and the Expanding Humanoid Robot Talent Challenge
The humanoid robot is no longer a laboratory curiosity. It is increasingly treated as a strategic product platform that combines mechanical design, electronics, control, perception, artificial intelligence, and human-machine interaction. The policy framework described above makes the direction clear: the humanoid robot must move from prototype demonstrations toward safe, reliable, and scalable products. That shift requires a workforce capable of designing joints, reducers, bearings, transmissions, structures, control systems, and integrated mechatronic modules. It also requires universities to reconsider how foundational courses prepare students for the humanoid robot era.
China has responded to the broader robotics talent challenge by expanding robotics engineering programs. By 2024, a total of 367 undergraduate institutions in China had established robotics engineering majors. This expansion reflects national strategy and industrial demand. However, the growth in program numbers does not automatically guarantee that course content, teaching methods, practical training, and evaluation systems are aligned with the real needs of the humanoid robot industry. In many cases, traditional mechanical design courses remain organized around conventional machines and generalized components rather than around modern robotics products. The result is a gap between what students learn in the classroom and what engineers must do when they design a humanoid robot.
The humanoid robot is especially demanding because it integrates many subsystems into a single product. A humanoid robot must stand, balance, walk, manipulate objects, perceive its environment, and interact safely with humans. Each of these capabilities depends on mechanical design choices made at the system level and at the joint level. The design of a humanoid robot therefore requires top-down thinking. Application scenarios define requirements. Whole-body configuration defines the architecture. Dynamic simulation defines joint performance needs. Detailed joint design then determines motors, reducers, encoders, controllers, bearings, couplings, and structural interfaces. This is precisely the kind of systems thinking that a reformed course in mechanical design fundamentals should cultivate.
2. Why Mechanical Design Fundamentals Must Be Rebuilt Around the Humanoid Robot
Mechanical Design Fundamentals is a core professional course for robotics engineering. It introduces students to mechanisms, transmissions, connections, bearings, shafts, gears, and other essential elements of mechanical systems. In the traditional curriculum, however, the course is often built from separate technical modules. Students study planar mechanism structure analysis, planar linkage mechanisms, cam mechanisms, intermittent motion mechanisms, threaded connections and screw drives, belt drives, chain drives, gear drives, worm drives, gear trains, shaft-hub connections, bearings, couplings, clutches, brakes, rotor balancing, and machine speed regulation. Each topic may be mathematically useful, but the chapters are frequently independent. The content lacks a strong logical thread that connects component knowledge to product-level design.
This structure is poorly matched to humanoid robot development. A humanoid robot is not a collection of isolated components. It is a system in which the head, arms, legs, joints, sensors, controllers, and power systems must work together. If students learn mechanical design as a set of disconnected chapters, they may be able to solve textbook problems but may struggle to decompose a humanoid robot design task from the top down. They may not understand why a particular reducer, bearing, or transmission layout is selected for a humanoid robot joint. They may not see how dynamic simulation, lightweight optimization, motion-space optimization, and detailed component design interact.
The traditional course also misses components and methods that are common in modern humanoid robot design. Harmonic reducers, cycloidal pinwheel reducers, crossed roller bearings, synchronous belt drives, and parallel mechanisms are either absent or insufficiently covered. Modern design tools receive limited attention. Many exercises rely on analytical methods and graphical methods rather than on contemporary engineering workflows. For a humanoid robot engineer, this is a serious limitation. The course needs a new architecture that follows the humanoid robot design process, builds logical relationships among knowledge points, introduces modern design tools, and adds the components and methods required by current and future humanoid robot products.
3. Current Teaching Problems in the Humanoid Robot Context
The reform exploration identifies four major problems in the traditional Mechanical Design Fundamentals course. These problems are not abstract. They directly affect the ability of graduates to contribute to humanoid robot research, development, and production.
- Outdated and Incomplete Course Content. Traditional textbooks are organized around dispersed technical modules. The chapters include planar mechanism structure analysis, planar linkage mechanisms, cam mechanisms, intermittent motion mechanisms, threaded connections and screw drives, belt drives, chain drives, gear drives, worm drives, gear trains, shaft-hub connections, bearings, couplings, clutches, brakes, rotor balancing, and machine speed regulation. The topics are relatively independent and lack logical connection. In contrast, humanoid robot design is a systems engineering activity that requires holistic thinking and top-down decomposition of design tasks. The course also lacks content on harmonic reducers, cycloidal pinwheel reducers, crossed roller bearings, synchronous belt drives, and parallel mechanisms, all of which are relevant to modern humanoid robot design. Modern design methods and tools are introduced only briefly, while many design exercises still rely on analytical and graphical methods that are disconnected from modern engineering practice. A top-down theoretical course system is needed so that knowledge points gain logical relationships through the humanoid robot product design process, modern design methods and tools are integrated, and missing knowledge required by modern humanoid robot design is added.
- Disconnection Between Theory, Laboratory Courses, and Course Design. The current laboratory courses associated with the theory course include four main experiments: cognition of common mechanisms and general components, mapping and analysis of mechanism kinematic diagrams, involute gear tooth profile generation, and reducer structure analysis and disassembly. The cognition experiment mainly uses teaching aids in the laboratory. These aids demonstrate the principles of various mechanisms through motion, but students do not participate in design. The kinematic diagram mapping and analysis experiment requires manual drawing of planar mechanism kinematic diagrams and calculation of degrees of freedom. The method is traditional and does not apply modern design tools. The involute gear tooth profile generation experiment observes the process by which a rack-type cutter generates an involute gear tooth profile. It helps students understand the causes of undercutting and how modification can avoid it, but students mainly watch a demonstration. The reducer structure analysis and disassembly experiment asks students to disassemble and assemble an industrial gearbox so that they can recognize gearbox structure, gear arrangement, and fastening methods. Overall, the laboratory content is limited, students do not perform enough hands-on operations, modern design tools are not used, and the connection to course design is weak. The theory course, laboratory courses, and course design must be considered together to achieve systematic and coordinated education.
- Insufficient Cultivation of Student Innovation Ability. The traditional teaching model does not sufficiently develop student innovation. Only the first chapter briefly discusses the long history of mechanical creation, development, and use. It notes that simple textile machines appeared three thousand years ago, rope wheels, cams, and linkage mechanisms were used in production two thousand years ago, and after the Han dynasty, the south-pointing chariot and distance-recording drum cart used gears and gear trains. Other chapters rarely mention mechanical innovation design. They mainly explain the principles and applications of traditional mechanisms. The course design task is to design a single-stage or two-stage parallel-shaft reducer. This is a practice of basic course content, but it does not involve innovation ability cultivation. For engineers who work on humanoid robot product design, innovation is a critical skill module. Teaching methods and approaches therefore need reform to build student innovation capacity.
- Incomplete Evaluation System. The traditional evaluation method generally consists of three parts: final theoretical examination, regular learning performance, and regular homework. Their proportions are 60 percent, 20 percent, and 20 percent respectively. Regular learning performance includes attendance and classroom participation. Homework scores are usually averaged across multiple assignments and included in the total score. This traditional evaluation system does not consider innovation ability or practical ability. Both are extremely important for humanoid robot design and must be supplemented in a reformed assessment system.
4. Rebuilding the Theoretical Curriculum Around Humanoid Robot Products
The reform exploration proposes a theoretical curriculum rebuilt around the humanoid robot. The curriculum is designed systematically and top-down. It begins with application scenario requirements, then conceives the overall humanoid robot design, establishes an initial three-dimensional model, designs the head, arm, and leg configurations, performs dynamics simulation, determines the performance requirements of all joints, and finally proceeds to detailed joint design. This sequence gives the course a coherent product-oriented logic instead of a loose collection of chapters.
Using the design process of large and small humanoid robots as the basis, the relationship between humanoid robot design, course content, and design tools can be explained in detail. The initial design of the humanoid robot system model includes preliminary joint design, head configuration design, arm configuration design, and leg configuration design. At this stage, preliminary information about joint dimensions, mass, and performance is provided for whole-body dynamics simulation. According to the motion requirements of the humanoid robot in its usage scenarios, whole-body dynamics simulation is performed to confirm the performance requirements and motion-space requirements of each joint. This stage requires lightweight optimization design of structural parts and motion-space optimization design of configurations.
The system design of the humanoid robot involves course content such as planar linkage mechanisms, planar mechanism analysis, belt drives, chain drives, threaded drives, and cam drives. The related modern design tools include Solidworks, ADAMS, Ansys, Webots, and Matlab. Solidworks is used for three-dimensional modeling. ADAMS and Webots are used for dynamics analysis. Ansys is used for structural lightweight optimization design. Matlab is used for configuration optimization design. These tools allow students to connect mechanical design theory with simulation, optimization, and validation in a humanoid robot context.
After the system design is completed, the performance requirements of large joints are determined, and detailed design can proceed. This includes motors, reducers, controllers, encoders, and control software. The reducer design portion includes three transmission forms: harmonic gears, cycloidal pinwheel gears, and planetary gears. The related course content includes gear drives, gear trains, shaft-hub connections, bearings, threaded connections, couplings, brakes, rotor balancing, and machine speed regulation. In the bearing section, knowledge of crossed roller bearings is added. In the gear train section, knowledge of harmonic gears and cycloidal pinwheel gears is added. The modern design tools related to joint design include Solidworks, Maxwell, Kisssoft, Ansys, and Python. Maxwell is used for motor electromagnetic simulation. Kisssoft is used for gear design. Ansys is used for gear strength verification. Python is used for control software programming.
The design of a small humanoid robot follows a similar relationship with the course system and design tools, but the joint transmission scheme is different. It mainly uses parallel-shaft gear trains, face gears, and planetary gears. This variation allows the course to compare different humanoid robot design approaches and helps students understand how product scale and performance requirements influence transmission selection.
| Humanoid Robot Design Stage | Related Course Content | Modern Design Tools | Modern Components and Topics Added |
|---|---|---|---|
| System design of a large humanoid robot: preliminary joint design, head configuration, arm configuration, leg configuration, dynamics simulation, lightweight optimization, and motion-space optimization | Planar linkage mechanisms, planar mechanism structure analysis, belt drives, chain drives, threaded drives, cam mechanisms | Solidworks, ADAMS, Ansys, Webots, Matlab | Synchronous belt drives, parallel mechanisms, integrated system thinking for humanoid robot design |
| Detailed design of large humanoid robot joints: motors, reducers, controllers, encoders, and control software | Gear drives, gear trains, shaft-hub connections, bearings, threaded connections, couplings, brakes, rotor balancing, and speed regulation | Solidworks, Maxwell, Kisssoft, Ansys, Python | Harmonic gears, cycloidal pinwheel gears, planetary gears, crossed roller bearings |
| Design of small humanoid robot joints: motors, reducers, controllers, encoders, and control software | Gear drives, gear trains, shaft-hub connections, bearings, threaded connections, couplings, brakes, rotor balancing, and speed regulation | Solidworks, Kisssoft, Ansys, Python | Parallel-shaft gear trains, face gears, planetary gears |
5. Integrated Design of Theory, Laboratory Courses, Course Design, and Discipline Competitions
To solve the disconnection between theory teaching, laboratory courses, and course design, the reform exploration proposes an integrated design that links theory teaching, laboratory courses, course design, and discipline competitions. The humanoid robot product becomes the common thread that runs through all four components.
- Theory Teaching. The theoretical course content is developed according to the top-down logic of humanoid robot design. Each part of the content is explained in connection with humanoid robot design. Modern or future-oriented components are added, such as synchronous belts, crossed roller bearings, and harmonic reducers. The modern design tools used to design these components are also introduced, including ADAMS, Matlab, Ansys, and Kisssoft. This approach helps students see that mechanical design fundamentals are not isolated knowledge points but tools for solving real humanoid robot engineering problems.
- Laboratory Courses. Laboratory courses are arranged in correspondence with the theoretical course. Because class hours are limited, laboratory courses cannot cover every topic. Teachers should use modern design tools in laboratory teaching and allow students to participate in hands-on work as much as possible. This is a shift from passive observation toward active experimentation. In a humanoid robot context, laboratory work can help students connect mechanism principles, component selection, simulation, and design validation.
- Course Design. The traditional course design asks students to design a single-stage or two-stage transmission gearbox. Under the humanoid robot-based reform, the design task is changed to the design of a large humanoid robot joint. The joint includes a motor, reducer, encoder, controller, and control software. It is a complex mechatronic product. This task comes directly from modern humanoid robot products, so it has greater value for student training. It also corresponds to the theoretical teaching content, creating a strong link between classroom knowledge and product design practice.
- Discipline Competitions. Student participation in discipline competitions is a comprehensive practice and application of classroom knowledge. It stimulates interest in learning. The humanoid robot products taught in the theoretical course have corresponding competitions. Therefore, the theoretical course and discipline competitions are designed as an integrated whole. Competitions allow students to move from course exercises to team-based problem solving, prototyping, and presentation.
Through the humanoid robot product, theory courses, course experiments, course design, and discipline competitions are connected as a whole. This integrated approach lays a strong theoretical and practical foundation for cultivating excellent engineers who can meet the development needs of China’s humanoid robot industry.
6. Building Student Innovation Capacity for Humanoid Robot Engineering
Building student innovation capacity is essential for humanoid robot engineering. The reform exploration proposes four main measures. These measures aim to move students beyond memorization and routine calculation toward creative problem solving, technology forecasting, and product-oriented design thinking.
- Teaching the History of Science and Technology and Innovation Tools. Teaching the history of science and technology can increase student interest in learning. It also helps students grasp the trends of technological development, predict future prospects, and improve the foresight of their designs. The development history of humanoid robot joints illustrates a shift from rigid joints to elastic joints and quasi-direct-drive joints. Understanding this evolution helps students see that humanoid robot design is not static. Innovation also follows patterns. TRIZ is an effective innovation tool. The TRIZ innovation method was created by Genrich S. Altshuler, a former Soviet inventor. It reveals the internal laws and principles of creative invention and is a mature and practical innovation methodology. The course introduces five TRIZ innovation thinking methods: the Nine Windows method, the Ideal Final Result method, the STC Operator method, the Little People method, and the Goldfish method.
- Introducing Scientific Research into the Classroom. Integrating faculty research into teaching is an important feature that distinguishes university education from primary and secondary education. The Mechanical Design Fundamentals course team has two teachers who lead General Program projects of the National Natural Science Foundation of China. The research topics involve line gears and quasi-direct-drive humanoid robot joints. Both topics are at the frontier of technological development. By introducing the content of these research projects, teachers can inspire student innovation and show how humanoid robot design problems connect to advanced research.
- Assigning Innovative Design Tasks. After teaching the history of science and technology, introducing TRIZ innovation thinking methods, and presenting research content, the course assigns innovative design tasks to students. The design task can be chosen by students or assigned by the teacher. Through these innovative design assignments, students practice innovation ability. This is important because humanoid robot development requires engineers who can propose new mechanisms, new joint layouts, new transmission solutions, and new integration methods.
- Organizing Students to Participate in Discipline Competitions. Another very effective way to develop student innovation ability is to organize students to participate in discipline competitions. Relevant competitions include the China International College Students’ Innovation Competition, the Challenge Cup Chinese College Students’ Entrepreneurship Plan Competition, the National College Students Mechanical Innovation Design Competition, the National College Students Structural Design Competition, and the RAICOM Robot Developer Competition. Other relevant events include the China University Robot Competition, the China Robot Competition and RoboCup China, and the China Robot and Artificial Intelligence Competition. The RAICOM competition includes the CAIA Digital Cultural Creativity Track, the CAIP Information Technology Innovation Track, the CAIR Engineering Competition Track, and the CAIM Engineering Maker Track. Within the CAIR Engineering Competition Track, there are humanoid robot-related categories such as Youzhi Future, Humanoid Safety, Humanoid Comparison, and Humanoid Virtual Simulation. By participating in discipline competitions, students connect theory with practice, gain further exposure to real humanoid robot product design, and develop teamwork ability.
7. A Multidimensional Evaluation System for Humanoid Robot Talent Development
The traditional evaluation method includes only final theoretical examination, regular learning performance, and regular homework. The reform exploration replaces this narrow approach with a multidimensional evaluation system that adds innovation ability and practical ability as assessment indicators. This system is more consistent with the humanoid robot industry’s demand for talent. Innovation ability is evaluated through two innovative design tasks assigned during teaching. Students form innovation groups to complete the design tasks. They may choose their own topics or select teacher-assigned topics. For example, students may take the actual needs of the offshore wind power industry in Yangjiang as a subject for innovative design. Practical ability is evaluated through student participation in discipline competitions and related awards. Relevant competitions include the China International College Students’ Innovation Competition, the Challenge Cup Chinese College Students’ Entrepreneurship Plan Competition, the National College Students Mechanical Innovation Design Competition, the National College Students Structural Design Competition, the China University Robot Competition, the China Robot Competition and RoboCup China, the RAICOM Robot Developer Competition, and the China Robot and Artificial Intelligence Competition. Through competition participation, students link theory with practice, encounter real humanoid robot product design issues, and exercise team collaboration.
| Evaluation Dimension | Traditional Weighting | Reformed Weighting | Purpose in a Humanoid Robot Context |
|---|---|---|---|
| Final theoretical examination | 60 percent | 60 percent | Assesses understanding of mechanical design fundamentals that support humanoid robot development |
| Regular learning performance or classroom performance | 20 percent | 10 percent | Encourages participation and engagement with humanoid robot design discussions |
| Regular homework | 20 percent | 10 percent | Strengthens component analysis and design calculation skills |
| Innovation ability | Not included | 10 percent | Evaluates creative design tasks relevant to humanoid robot mechanisms and joints |
| Practical ability | Not included | 10 percent | Recognizes competition performance and hands-on humanoid robot design practice |
The reformed evaluation system does not reduce the importance of theoretical knowledge. Instead, it places theoretical knowledge within a broader set of capabilities. A humanoid robot engineer must be able to calculate, model, simulate, design, build, test, and communicate. The multidimensional system recognizes that mechanical design fundamentals are the foundation, while innovation and practice are the pathways through which that foundation becomes engineering capability.
8. The Humanoid Robot as an Integrator of Mechanical Design and Mechatronics
The humanoid robot is a powerful teaching platform because it integrates mechanical design with mechatronics. A large humanoid robot joint is not merely a gearbox. It includes a motor, reducer, encoder, controller, and control software. Designing such a joint requires knowledge of gear transmission, bearing selection, shaft-hub connection, threaded connection, coupling, brake, rotor balancing, and speed regulation. It also requires understanding of motor characteristics, electromagnetic simulation, control algorithms, and software programming. When the course is organized around the humanoid robot, students encounter these elements in a connected way rather than as separate subjects.
This integration is especially important for robotics engineering. In traditional mechanical design courses, students may learn how to design a reducer without fully understanding how the reducer interacts with a motor, sensor, controller, and whole-body motion planning. In a humanoid robot-based course, the reducer is not an isolated component. It is part of a joint that must meet torque, speed, precision, backlash, stiffness, weight, and packaging requirements. The joint is part of a limb that must satisfy workspace and dynamic requirements. The limb is part of a whole-body system that must maintain balance and perform tasks. This chain of relationships gives mechanical design a clear purpose and a systems context.
Modern design tools support this integration. Solidworks enables three-dimensional modeling of the humanoid robot and its joints. ADAMS and Webots support dynamics simulation. Ansys supports structural lightweight optimization and strength verification. Matlab supports configuration optimization. Maxwell supports motor electromagnetic simulation. Kisssoft supports gear design. Python supports control software programming. When these tools are taught alongside mechanical design fundamentals, students learn a workflow that resembles modern humanoid robot engineering practice. They do not simply solve textbook problems. They model, simulate, optimize, and validate design choices.
The humanoid robot also introduces students to modern components that are often missing from traditional courses. Harmonic reducers are widely relevant to humanoid robot joints because of their compactness and high reduction ratios. Cycloidal pinwheel reducers offer high stiffness and shock resistance. Crossed roller bearings support compact and rigid joint structures. Synchronous belt drives provide flexible transmission options. Parallel mechanisms expand the design space for limbs and other structures. By including these topics, the reform connects the course to current humanoid robot technology rather than to a past generation of machines.
9. Implications for Robotics Engineering Curriculum Reform
The reform exploration has implications beyond a single course. It suggests that robotics engineering curricula should be designed around real products, especially complex products such as the humanoid robot. When a course is anchored in a product, knowledge points are no longer isolated. They become tools for solving design problems. Students can see why a particular mechanism, transmission, bearing, or material is selected. They can see how system-level requirements flow down to component-level specifications. They can see how simulation and optimization inform design decisions.
The reform also suggests that theory, laboratory work, course design, and discipline competitions should be planned together. In many programs, these elements are treated as separate activities. Theory is taught in lectures. Laboratory work demonstrates principles. Course design applies a few calculations. Competitions are extracurricular. The humanoid robot-based reform connects them. The theoretical course introduces the design logic. Laboratory courses provide hands-on experience with mechanisms and tools. Course design requires the integration of motor, reducer, encoder, controller, and software into a humanoid robot joint. Discipline competitions provide open-ended challenges that require teamwork and innovation. Together, these elements create a more coherent learning experience.
The reform further suggests that evaluation should recognize innovation and practice. If a curriculum claims to develop innovative engineers for the humanoid robot industry, assessment must reflect that goal. A final examination alone cannot measure a student’s ability to propose a new mechanism, optimize a joint, or complete a complex design project. The multidimensional evaluation system gives weight to innovation tasks and competition performance while retaining a strong theoretical examination component. This balanced approach can encourage students to take creative work seriously without neglecting fundamental knowledge.
The humanoid robot industry is moving quickly. Policy documents set ambitious goals for 2025 and 2027. Industry leaders predict a market larger than the automobile industry. Universities cannot afford to remain disconnected from this development. As one university leader observed, research and teaching in many universities have already become disconnected from industry, especially in fast-developing emerging sectors such as offshore wind power and robotics. The humanoid robot is one of those sectors. Curriculum reform is therefore urgent. Courses must be updated, teaching methods must become more product-oriented, practical training must use modern tools, and evaluation must reward the abilities that industry needs.
10. Conclusion
The reform exploration of Mechanical Design Fundamentals based on humanoid robot products offers a concrete response to the talent challenge facing the humanoid robot industry. It begins with national policy and industry momentum. It identifies the limitations of traditional course content, the disconnection between theory and practice, the insufficient cultivation of innovation, and the incompleteness of evaluation. It then proposes a top-down theoretical curriculum built around the design process of large and small humanoid robots. It adds modern components such as harmonic reducers, cycloidal pinwheel reducers, crossed roller bearings, synchronous belts, and parallel mechanisms. It introduces modern design tools such as Solidworks, ADAMS, Ansys, Webots, Matlab, Maxwell, Kisssoft, and Python. It integrates theory teaching, laboratory courses, course design, and discipline competitions through the humanoid robot product. It builds student innovation capacity through the history of science and technology, TRIZ innovation methods, research introduction, innovative design tasks, and competitions. It establishes a multidimensional evaluation system that includes final theoretical examination, classroom performance, homework, innovation ability, and practical ability.
For robotics engineering education, the humanoid robot is more than a new product category. It is a curriculum integrator. It connects mechanical design fundamentals with mechatronics, control, simulation, optimization, and product development. It gives students a visible and demanding target for their learning. It also gives universities a way to align teaching with national strategy and industrial demand. The reform and exploration of the humanoid robot-based Mechanical Design Fundamentals course therefore have reference significance for curriculum reform in robotics engineering and for the cultivation of talent for China’s humanoid robot industry. As the humanoid robot moves from policy vision to industrial reality, the classroom must move with it. The mechanical design fundamentals course can become a starting point for that transformation, preparing students to design the joints, mechanisms, and systems that will make future humanoid robots safe, capable, and useful in intelligent manufacturing, home services, special-environment operations, and beyond.