
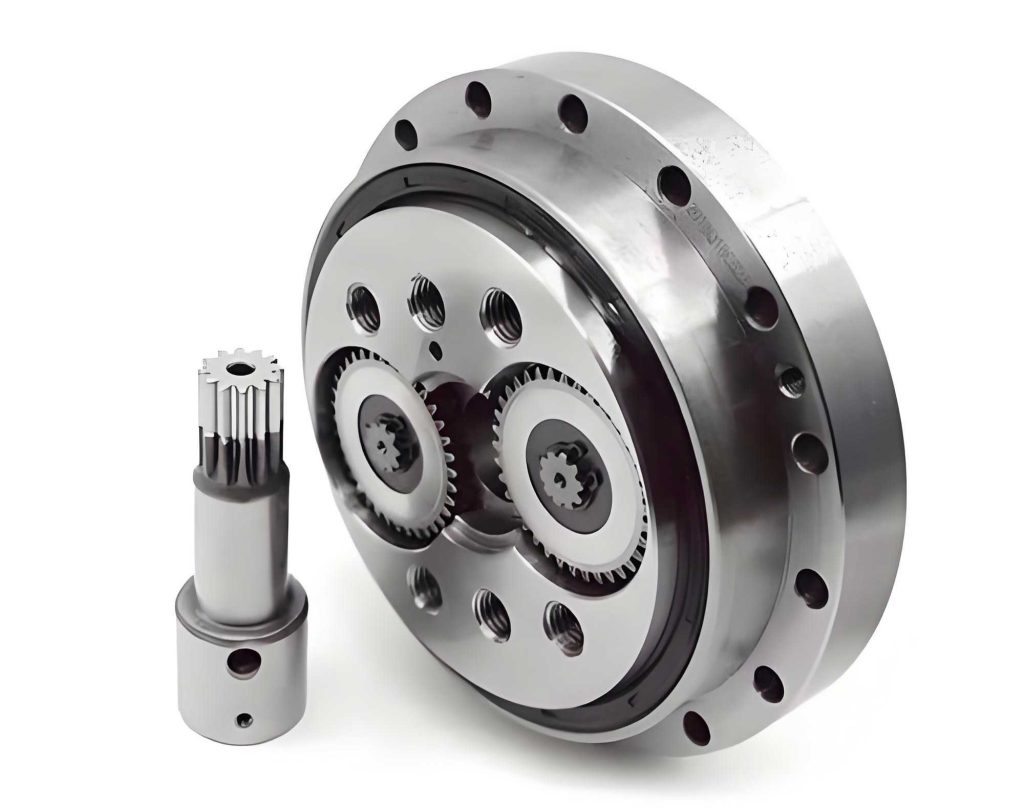
The relentless pursuit of higher precision, compactness, and reliability in motion control has positioned the Rotate Vector (RV) reducer as a cornerstone technology in advanced robotics, aerospace, and high-precision manufacturing. At the heart of an RV reducer’s exceptional performance—characterized by high torsional stiffness, substantial reduction ratio, and compact design—lies its two-stage transmission system. The critical second stage, the cycloid-pin gear drive, directly governs the mechanism’s ultimate positioning accuracy and load-bearing capacity. To ensure smooth assembly, adequate lubrication, and compensation for manufacturing imperfections, the profile of the cycloidal gear must be meticulously modified. Traditional modification methods, while theoretically sound, often fall short in practical, high-volume manufacturing environments where part-to-part variations are inevitable. This article, from our perspective in precision transmission research, delves into a novel two-stage conjugate modification methodology specifically designed for the RV reducer. This approach proactively compensates for key machining errors during the design phase, ensuring robust performance even in the presence of dimensional deviations, thereby offering significant practical value for the design and assembly of RV reducers.
Conventional cycloidal gear modification strategies, such as equidistant (Δrrp), radial shifting (Δrp), and rotational (Δφ) modifications, are typically calculated based on nominal design parameters to create necessary backlash and avoid interference. However, these “theoretical” modifications do not account for the actual deviations present in manufactured components like the pin housing center circle, the pin radius, or the pin hole positions. In batch production, different combinations of these errors can lead to two problematic extremes: assembly interference or excessive backlash, both detrimental to the RV reducer’s performance and longevity. This gap between theory and practice necessitates a more adaptive modification strategy—one that treats part errors not as anomalies but as inputs to the design process itself.
Our proposed methodology addresses this need through a systematic two-step process: Primary Error-Compensation Modification and Secondary Conjugate Optimization. The core innovation lies in establishing a direct equivalence between machining errors and classical modification parameters, allowing us to “absorb” variations into the cycloid profile itself.
Primary Stage: Error Compensation Modeling and Theoretical Zero-Backlash Profile
The first stage aims to synthesize a theoretical cycloid profile that would mate perfectly with a pin gear possessing specific dimensional errors, resulting in zero theoretical backlash. We focus on compensating the three most sensitivity-influencing errors identified for the RV reducer: pin radius error (δrrp), pin housing center circle radius error (δrp), and pin hole circumferential position error (δt).
The principle is to equate the circumferential clearance (or interference) generated by an error on the cycloid’s pitch circle to the clearance generated by a specific equidistant or radial shift modification. The fundamental equations relating errors to circumferential backlash (j) are:
$$
j_{rp} = \delta r_{rp}, \quad j_t = k \delta t, \quad j_p = \delta r_p \sqrt{1 – k^{2}}
$$
where \(k = a z_p / (r_p + \Delta r_p)\) is the shortened coefficient, \(a\) is the eccentricity, \(z_p\) is the number of pins, and \(r_p\) is the nominal pin center circle radius. Similarly, the backlash from modifications is:
$$
j_{\Delta} = \Delta r_{rp}, \quad j_s = \Delta r_p \sqrt{1 – k^{2}}
$$
By setting the backlash from an error equal to the backlash from a modification (\(j_{error} = j_{modification}\)), we can solve for the equivalent compensatory modification amount. The compensation strategy for single errors is summarized below:
| Error Source | Deviation Sign | Compensation Method | Compensation Amount |
|---|---|---|---|
| Pin Radius (δrrp) | Positive (+) | Positive Equidistant | Δrrp1 = +|δrrp| |
| Pin Radius (δrrp) | Negative (-) | Negative Equidistant | Δrrp1 = -|δrrp| |
| Pin Hole Position (δt) | Positive (+) | Positive Equidistant | Δrrp2 = +|kδt| |
| Pin Hole Position (δt) | Negative (-) | Negative Equidistant | Δrrp2 = -|kδt| |
| Center Circle Radius (δrp) | Positive (+) | Positive Radial Shift | Δrp1 = +|δrp| |
| Center Circle Radius (δrp) | Negative (-) | Negative Radial Shift | Δrp1 = -|δrp| |
In a real RV reducer, multiple errors coexist. The total primary compensatory modification is the algebraic sum of the individual compensations:
$$
\Delta r’_{rp} = \Delta r_{rp1} + \Delta r_{rp2}, \quad \Delta r’_p = \Delta r_{p1}
$$
Furthermore, to account for elastic deformation under load, which affects the meshing condition, we introduce a deformation compensation function δ(φ) based on the deflection of the most loaded tooth (δmax):
$$
\delta(\phi) = \frac{\sin \phi}{\sqrt{1 + k^{2} – 2k \cos \phi}} \delta_{max}
$$
Integrating the total compensatory modifications and the elastic deformation into the standard equidistant and radial shift modification equation yields the primary, theoretical zero-backlash cycloid profile, denoted as (x’z, y’z):
$$
\begin{aligned}
x’_z & = \left[ (r_p + \Delta r’_p) – (r_{rp} + \Delta r’_{rp} + \delta) s^{-\frac{1}{2}} \right] \cos\left[(1-i_H)\phi\right] – \\
& \quad \frac{a}{r_p + \Delta r’_p} \left[ (r_p + \Delta r’_p) – z_p (r_{rp} + \Delta r’_{rp} + \delta) s^{-\frac{1}{2}} \right] \cos(i_H \phi) \\
y’_z & = \left[ (r_p + \Delta r’_p) – (r_{rp} + \Delta r’_{rp} + \delta) s^{-\frac{1}{2}} \right] \sin\left[(1-i_H)\phi\right] + \\
& \quad \frac{a}{r_p + \Delta r’_p} \left[ (r_p + \Delta r’_p) – z_p (r_{rp} + \Delta r’_{rp} + \delta) s^{-\frac{1}{2}} \right] \sin(i_H \phi)
\end{aligned}
$$
where \(s = 1 + k^{2} – 2k \cos \phi\), \(i_H = z_p / z_c\) is the transmission ratio, and \(z_c\) is the number of cycloid gear teeth. This profile represents an ideal, interference-free fit for the specific set of part errors but provides no clearance for assembly or lubrication.
Secondary Stage: Conjugate Optimization for Practical Assembly and Performance
The primary profile is not suitable for actual use, as it lacks essential radial clearance (Δr) at the tooth root and tip. The goal of the secondary stage is to determine a new, conjugate cycloid profile—via a second set of equidistant (Δr*rp) and radial shift (Δr*p) modifications—that closely approximates the working segment of the primary profile while satisfying practical constraints of clearance and backlash (which translates to transmission error).
We define the working segment of the primary profile between two limit points B’ and C’, corresponding to angles φb and φc, which are chosen to minimize the average pressure angle within the segment, optimizing force transmission. This segment is discretized into m points: (x’zi, y’zi). For a given trial secondary modification pair (Δr*rp, Δr*p), we can calculate a corresponding point set (x*zi, y*zi) on the new profile. The objective is to minimize the average vertical deviation between these two profiles over the working segment:
$$
f(\Delta r^{*}_{rp}, \Delta r^{*}_{p}) = \frac{1}{m} \sum_{i=1}^{m} | y^{*}_{zi} – y’_{zi} |
$$
A smaller \(f\) indicates a closer approximation, meaning the secondary profile will behave more like the conjugate, zero-backlash primary profile during the meshing action.
This optimization is subject to critical engineering constraints for the RV reducer:
- Transmission Error (Backlash Constraint):The circumferential clearance j between the primary and secondary profiles must result in a transmission error (γ) within acceptable limits (e.g., ≤ 1 arc-minute).
$$
j = \Delta r^{*}_{rp} – \Delta r’_{rp} – \Delta r^{*}_{p} \sqrt{1 – k_2^{2}} + \Delta r’_{p} \sqrt{1 – k_1^{2}}
$$$$
\gamma(\Delta r^{*}_{rp}, \Delta r^{*}_{p}) = 2 \times \frac{j}{a z_c} \times \frac{180 \times 60}{\pi} \quad (\text{in arc-minutes})
$$ - Radial Clearance Constraint:The physical gap between the pin and the cycloid tooth at the root/tip must be positive and typically small (e.g., 0 < Δr ≤ 0.03 mm).
$$
\Delta r = (\Delta r^{*}_{rp} + \Delta r’_{rp}) – (\Delta r^{*}_{p} + \Delta r’_{p})
$$ - Manufacturability Constraint:The secondary equidistant modification should be within a practical machining range (e.g., |Δr*rp| ≤ 0.20 mm).
The complete optimization model for determining the final, practical conjugate modification amounts is therefore:
$$
\begin{aligned}
& \underset{\Delta r^{*}_{rp}, \Delta r^{*}_{p}}{\text{minimize}}
& & f(\Delta r^{*}_{rp}, \Delta r^{*}_{p}) \\
& \text{subject to}
& & \gamma(\Delta r^{*}_{rp}, \Delta r^{*}_{p}) \leq 1′ \\
& & & |\Delta r^{*}_{rp}| \leq 0.20 \text{ mm} \\
& & & 0 < \Delta r \leq 0.03 \text{ mm}
\end{aligned}
$$
Solving this model using an iterative least-squares method yields the optimal secondary modification pair (Δr*rp, Δr*p). The final, manufacturable cycloid gear profile is then generated using these values in the standard modification equations, resulting in a gear that is both conjugate in the working zone and possesses the necessary clearances.
Validation and Analysis: A Case Study on an RV-80E Reducer
To validate our methodology, we applied it to an RV-80E type RV reducer. Key nominal parameters and theoretical modifications are listed below:
| Parameter | Symbol | Value |
|---|---|---|
| Pin Center Circle Radius | rp | 58 ±0.02 mm |
| Pin Radius | rrp | 2.5 ±0.004 mm |
| Eccentricity | a | 1 ±0.004 mm |
| Cycloid Gear Teeth | zc | 39 |
| Pin Teeth | zp | 40 |
| Theoretical Equidistant Mod. | Δrrp | -0.026 mm |
| Theoretical Radial Shift Mod. | Δrp | -0.036 mm |
A detailed finite element model of the cycloid-pin transmission stage was developed and verified by comparing contact stress distributions and load-dependent transmission error trends against established analytical and published results, confirming model accuracy.
We designed an orthogonal experiment (L9 array) to test our method under various single and combined error conditions, using the defined tolerance ranges. The table below outlines the experimental scheme and the secondary modification amounts calculated by our model for each case, compared to the baseline nominal (error-free) model.
| Model | δrrp (mm) | δrp (mm) | δt (mm) | Secondary Modifications (Δr*rp, Δr*p) (mm) |
|---|---|---|---|---|
| 1 | -0.004 | -0.02 | -0.01 | (-0.037, -0.056) |
| 2 | -0.004 | 0 | 0 | (-0.030, -0.036) |
| 3 | -0.004 | 0.02 | 0.01 | (-0.023, -0.016) |
| 4 | 0 | -0.02 | 0 | (-0.026, -0.056) |
| 5 | 0 | 0 | 0.01 | (-0.019, -0.036) |
| 6 | 0 | 0.02 | -0.01 | (-0.033, -0.016) |
| 7 | 0.004 | -0.02 | 0.01 | (-0.015, -0.056) |
| 8 | 0.004 | 0 | -0.01 | (-0.029, -0.036) |
| 9 | 0.004 | 0.02 | 0 | (-0.022, -0.016) |
| 10 (Baseline) | 0 | 0 | 0 | (-0.026, -0.036) |
Key Findings from the Analysis:
- Single Error Compensation: For models with only one significant error (e.g., Model 2: δrrp=-0.004mm), our method successfully generated a conjugate profile, whereas the traditional theoretical modification led to excessive clearance. In cases where theoretical modification caused interference (e.g., specific error signs in pin hole position), our compensatory method provided a viable, interference-free solution.
- Combined Error Compensation: Under all combined error conditions, our method determined a viable modification set. For instance, Model 3’s profile showed the required radial clearance at the root/tip while closely matching the theoretical conjugate profile in the working zone, demonstrating the core principle of our two-stage approach.
- Performance Enhancement: A comparative analysis of key performance metrics revealed the superiority of the compensatory method. The following summary highlights the average improvements observed across all non-interfering test cases when compared to applying only the theoretical modification to the erroneous parts.
| Performance Metric | Average Improvement with Compensatory Method |
|---|---|
| Peak Transmission Error | Reduction of ~32% |
| Peak-to-Peak Transmission Error | Reduction of ~26% |
| Maximum Contact Stress on Cycloid Gear | Reduction of ~11% |
| Number of Teeth in Simultaneous Contact | Increased or maintained at optimal level |
The reduction in contact stress is particularly significant for the durability and reliability of the RV reducer, as it indicates a more favorable load distribution across the cycloid teeth. The method effectively redistributes the load, mitigating stress concentrations that arise from misfit due to uncompensated errors.
Conclusion and Engineering Application
The proposed two-stage conjugate modification method based on error compensation presents a significant advancement in the design logic for cycloidal gears in RV reducers. By explicitly modeling and compensating for critical machining errors during the profile generation process, this method bridges the gap between theoretical design and manufacturing reality.
The primary stage translates part errors into a coherent set of initial modifications, creating a “theoretical perfect match” profile. The secondary stage then optimizes for a practical, manufacturable profile that retains near-conjugate meshing characteristics while satisfying essential assembly and precision constraints. Finite element validation confirms that this approach not only prevents interference but also enhances transmission accuracy and improves load distribution, leading to lower contact stresses compared to traditional methods applied to parts with errors.
The practical implications for RV reducer production are substantial:
- Design Stage: Tolerances on hard-to-machine components (e.g., pin housing) can be relaxed to economic levels. The permissible error ranges then directly feed into the model to define a corresponding range of suitable cycloid gear modifications, lowering overall manufacturing cost without sacrificing performance.
- Assembly Stage: For selective assembly in high-volume production, measured part errors can be grouped. Our model can compute the precise cycloid modification required for each group combination, providing a scientific basis for matching gears to housings to achieve consistent, high-quality output.
- Repair/Service: The method can be used to determine a replacement cycloid gear’s optimal modification based on the measured wear or errors in an existing, used pin housing assembly.
In conclusion, this compensatory and conjugate approach to cycloid profile design enhances the robustness, performance, and manufacturability of the critical cycloid-pin transmission within the RV reducer, offering a powerful tool to meet the ever-increasing demands for precision and reliability in advanced mechanical systems.