
The rotary vector reducer is a pivotal component within the joint actuators of industrial robots, lauded for its compact structure, high load capacity, and exceptional transmission precision. Its operational health is directly linked to the reliability and positioning accuracy of the entire robotic system. Among its potential failure modes, localized faults in gears, such as pitting, spalling, or chipping, are prevalent. Detecting these incipient faults is crucial for predictive maintenance. Traditional vibration-based diagnostic methods, while useful, often grapple with challenges in rotary vector reducers due to complex signal modulation from time-varying transmission paths and the simultaneous meshing of multiple components. This analysis explores an alternative pathway: utilizing the Instantaneous Angular Speed (IAS) signal derived from the servo motor’s built-in encoder. This signal offers a direct reflection of the torsional dynamics of the drivetrain and is immune to the aforementioned transfer path effects. We delve into the dynamic response of the rotary vector reducer under localized gear faults by first modeling the time-varying meshing stiffness, incorporating it into a torsional dynamic model, and subsequently analyzing the characteristic signatures present in the IAS signal.
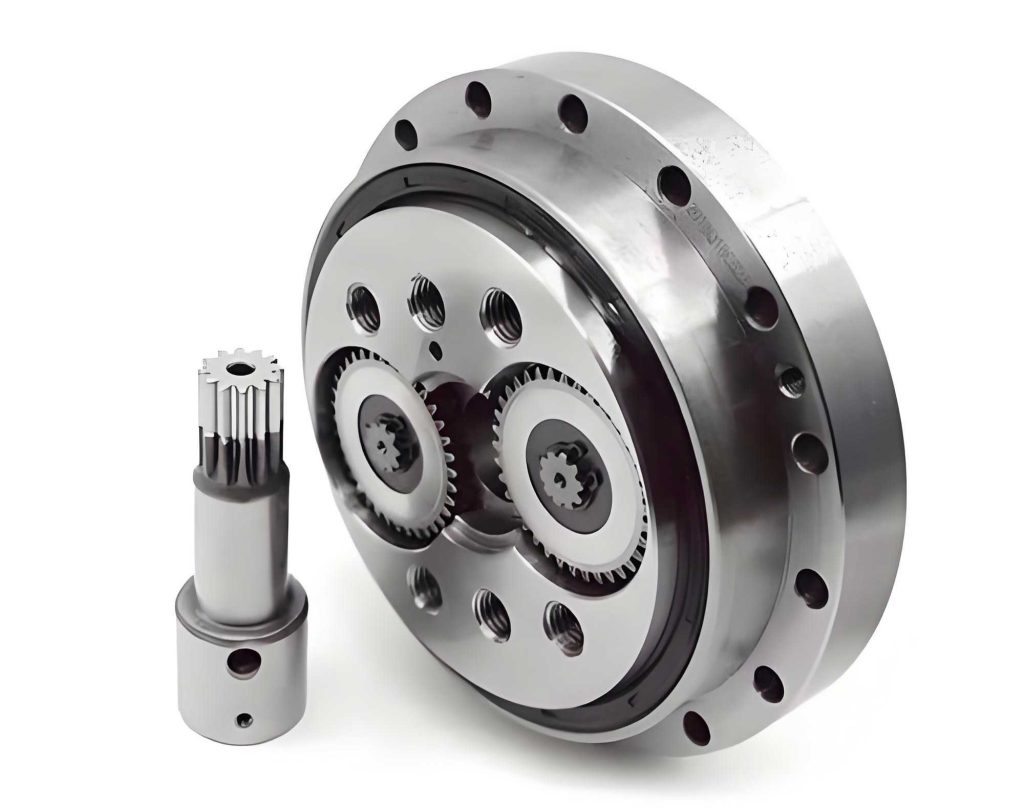
1. Transmission Stages and Characteristic Frequencies of the Rotary Vector Reducer
The rotary vector reducer achieves high reduction ratios through a two-stage design. The first stage is a planetary gear train, and the second is a cycloidal-pin gear mechanism. The planetary stage provides an initial speed reduction, while the cycloidal stage offers the primary, high-ratio reduction with high torque capacity and compactness.
The total reduction ratio \( n \) of the rotary vector reducer is given by:
$$ n = \frac{N_s}{N_c} = 1 + \frac{Z_p \cdot Z_w}{Z_s \cdot (Z_w – Z_c)} $$
where \( N_s \) is the sun gear speed, \( N_c \) is the output crank speed, \( Z_s \) is the sun gear tooth number, \( Z_p \) is the planet gear tooth number, \( Z_c \) is the cycloidal gear tooth number, and \( Z_w \) is the number of pin teeth (or pins).
Using the input shaft (sun gear) rotational frequency as the reference (1st order), the characteristic orders for key components are derived as shown in Table 1. These orders are fundamental for analyzing fault-related frequency components in the angular domain.
| Component | Characteristic Order (Relative to Input Shaft) | Symbol |
|---|---|---|
| Sun Gear (Input) | 1 | \(O_s\) |
| Output Crank/Plate | \(1/n\) | \(O_c\) |
| Planet Gear / Cycloidal Gear (Revolution) | \(\frac{Z_s \cdot Z_w}{Z_s \cdot Z_w + Z_p \cdot (Z_w – Z_c)}\) | \(O_p = O_{cyc}\) |
| Planetary Stage Meshing | \(Z_s \cdot (O_s – O_c)\) | \(O_{mp}\) |
| Cycloidal-Pin Stage Meshing | \(Z_w \cdot (O_p – O_c)\) | \(O_{mc}\) |
Table 1: Characteristic orders of a typical rotary vector reducer.
2. Time-Varying Meshing Stiffness (TVMS) of the Transmission Stages
The dynamic response of a gear system is profoundly influenced by its Time-Varying Meshing Stiffness (TVMS), which acts as a primary internal excitation. Faults on gear teeth directly alter the local contact conditions and, consequently, the TVMS.
2.1 TVMS of the Planetary Stage
The planetary stage typically uses involute spur gears. The TVMS for a single tooth pair can be calculated using the potential energy method, considering Hertzian contact stiffness \(k_h\), bending stiffness \(k_b\), shear stiffness \(k_s\), and axial compressive stiffness \(k_a\).
The Hertzian contact stiffness for a tooth pair is:
$$ k_h = \frac{\pi E L}{4(1-\nu^2)} $$
where \(E\) is Young’s modulus, \(L\) is the tooth face width, and \(\nu\) is Poisson’s ratio.
The bending, shear, and axial stiffness for a single gear tooth (modeled as a cantilever beam) are given by integrals over the tooth profile:
$$ \frac{1}{k_b} = \int_{-\alpha_1}^{\alpha_2} \frac{ \{1 – \cos\alpha_m [\alpha_2 – \alpha]\}^2 \cos\alpha }{E L [\sin\alpha + (\alpha_2 – \alpha) \cos\alpha]^3} \, d\alpha $$
$$ \frac{1}{k_s} = \int_{-\alpha_1}^{\alpha_2} \frac{1.2 (1+\nu) \cos^2\alpha }{E L [\sin\alpha + (\alpha_2 – \alpha) \cos\alpha]} \, d\alpha $$
$$ \frac{1}{k_a} = \int_{-\alpha_1}^{\alpha_2} \frac{\sin^2\alpha }{E L [\sin\alpha + (\alpha_2 – \alpha) \cos\alpha]} \, d\alpha $$
where \(\alpha_1\) and \(\alpha_2\) are angles defining the active profile.
The single-tooth-pair mesh stiffness \(k_t\) is:
$$ \frac{1}{k_t} = \frac{1}{k_h} + \sum_{i=1}^{2} \left( \frac{1}{k_{b,i}} + \frac{1}{k_{s,i}} + \frac{1}{k_{a,i}} \right) $$
The total TVMS \(K_p(t)\) for the sun-planet mesh, considering the contact ratio \(\epsilon\), is the sum of the stiffnesses of all tooth pairs in contact at any instant:
$$ K_p(t) = \sum_{i=1}^{N_c(t)} k_{t,i}(t) $$
where \(N_c(t)\) is the number of tooth pairs in contact (typically 1 or 2 for spur gears).
2.2 TVMS of the Cycloidal-Pin Stage
The TVMS of the cycloidal-pin stage is more complex due to the multi-tooth contact and profile modifications. The force transmission relies on several cycloid teeth contacting the pins simultaneously. The stiffness at a single cycloid-pin contact point \(j\) can be derived from Hertzian contact theory and the geometry of the modified cycloid profile.
The normal force \(F_{n,j}\) at contact point \(j\) relates to the tangential force \(F_{t,j}\) and the pressure angle \(\alpha_{c,j}\):
$$ F_{n,j} = \frac{F_{t,j}}{\sin\alpha_{c,j}} $$
The half-width of the contact area \(b_j\) is:
$$ b_j = \sqrt{ \frac{8 F_{n,j} \rho_j r}{\pi L E^*} } \quad \text{where} \quad \frac{1}{E^*} = \frac{1-\nu_1^2}{E_1} + \frac{1-\nu_2^2}{E_2} $$
Here, \(\rho_j\) is the radius of curvature of the cycloid tooth at the contact point, \(r\) is the pin radius, and subscripts 1 and 2 refer to the cycloid gear and pin materials, respectively.
The approximate radial compression \(\delta_j\) at the contact is:
$$ \delta_j \approx \frac{b_j^2}{2\rho_j} = \frac{4 F_{n,j} r}{\pi L E^* \rho_j} $$
The local contact stiffness \(k_{c,j}\) is then:
$$ k_{c,j} = \frac{F_{t,j}}{\delta_j} = \frac{\pi L E^* \rho_j \sin\alpha_{c,j}}{4 r} $$
The total TVMS \(K_c(t)\) for the cycloidal stage is the sum of the stiffnesses of all contact points in the load zone, which typically involves \(Z_c/3\) to \(Z_c/2\) teeth:
$$ K_c(t) = \sum_{j \in \text{Load Zone}} k_{c,j}(t) $$
2.3 Effect of Localized Faults on TVMS
A localized fault, such as a spall or chip on a tooth, locally reduces the effective contact area and material integrity. This manifests as a sudden drop in the TVMS contribution of that specific tooth during its engagement.
- Planet Gear Fault: When a faulty planet gear tooth enters the mesh with the sun gear, the single-tooth-pair stiffness \(k_t\) for that pair drops significantly for the duration of that tooth’s contact. This creates a periodic impulse in the planetary stage TVMS \(K_p(t)\) with a period corresponding to the planet gear’s rotation relative to the carrier \(O_p\).
- Cycloidal Gear Fault: A fault on a cycloid tooth causes a reduction in its local contact stiffness \(k_{c,j}\) throughout its passage through the load zone. Given the high contact ratio (multiple teeth in contact), the fault affects the total stiffness \(K_c(t)\) over a longer angular duration (roughly corresponding to the angular extent of the load zone, e.g., ~120°) compared to the brief, sharp drop caused by a spur gear fault.
These fault-induced modulations in \(K_p(t)\) and \(K_c(t)\) serve as the internal excitations that generate distinctive torsional vibrations, which are captured in the IAS signal.
3. Torsional Dynamic Model and IAS Simulation
To understand the IAS response, a lumped-parameter, pure torsional dynamic model of the rotary vector reducer is established. The model considers the inertias of the sun gear \(J_s\), planet gears \(J_p\), cycloid gears \(J_{cyc}\), and output plate \(J_c\), connected by shafts with stiffness \(k\) and damping \(c\). The key internal forces are the meshing forces in both stages, which are functions of the TVMS and the relative displacement between components.
The equations of motion for the sun gear and a planet gear, for example, can be written as:
$$ J_s \ddot{\theta}_s + c_s \dot{\theta}_s + \sum_{i=1}^{N_p} r_s \left[ K_{p,i}(t) \cdot (r_s \theta_s – r_p \theta_{p,i}) + C_{p,i} \cdot (r_s \dot{\theta}_s – r_p \dot{\theta}_{p,i}) \right] = T_{in} $$
$$ J_p \ddot{\theta}_{p,i} + r_p \left[ K_{p,i}(t) \cdot (r_p \theta_{p,i} – r_s \theta_s) + C_{p,i} \cdot (r_p \dot{\theta}_{p,i} – r_s \dot{\theta}_s) \right] = 0 $$
where \(r\) denotes base radii, \(\theta\) angular displacement, \(N_p\) the number of planets, and \(T_{in}\) the input torque. Similar equations govern the cycloid-pin interaction and output.
By numerically integrating this system of equations with the fault-modulated TVMS \(K_{p}(t)\) or \(K_{c}(t)\) as input, the dynamic angular displacements \(\theta(t)\) are obtained. The IAS of the input shaft (sun gear) is then derived as \(\omega_s(t) = \dot{\theta}_s(t)\). Simulated IAS signals for healthy, planet gear fault, and cycloid gear fault conditions are generated. A comparison of key characteristics is summarized in Table 2.
| Condition | IAS Waveform Signature | Order Spectrum Signature |
|---|---|---|
| Healthy | Regular, small-amplitude fluctuations at meshing frequencies (\(O_{mp}\), \(O_{mc}\)). | Dominant peaks at \(O_{mp}\) and \(O_{mc}\). Possibly low-level sidebands at \(O_p\) due to manufacturing imperfections. |
| Planet Gear Local Fault | Periodic, sharp impulsive dips superimposed on the waveform. Period = \(1/O_p\). Dip duration is short (corresponding to low contact ratio of spur gears). | Strong sideband families around the planetary meshing order \(O_{mp}\). The sidebands are spaced by the fault order \(O_p\). The amplitude of sidebands around \(O_{mc}\) is relatively weaker. |
| Cycloidal Gear Local Fault | Periodic, broader ‘soft’ dips or modulations. Period = \(1/O_p\). Dip duration is longer (corresponding to the high contact ratio and load zone extent of the cycloidal stage). | Strong sideband families around the cycloidal meshing order \(O_{mc}\), spaced by \(O_p\). The sidebands around \(O_{mp}\) are less pronounced. |
Table 2: Characteristic IAS signatures for different fault conditions in a rotary vector reducer.
The core insight is that while both planet and cycloid gear faults manifest at the same fundamental frequency (the revolution order \(O_p\)), their modulation effects on the system stiffness, and hence on the IAS, have distinct temporal and spectral signatures due to the fundamental differences in gear geometry and meshing mechanics. The planet gear fault creates a localized, high-impact event, while the cycloid gear fault causes a more distributed, lower-impact but longer-duration disturbance.
4. Experimental Validation and Signal Analysis
Experimental validation was conducted on a test rig comprising a servo motor, an RV-80E-81 type rotary vector reducer, and a magnetic powder brake. The built-in 2500 PPR incremental encoder of the servo motor provided the raw pulse train. Localized faults (spalling) were artificially introduced on a single planet gear tooth and on a single cycloid gear tooth separately. IAS signals were computed from the encoder pulse arrival times \(t_i\):
$$ \omega(i) = \frac{\Delta \phi}{\Delta t} = \frac{2\pi / PPR}{t_i – t_{i-1}} $$
where \(PPR\) is the encoder resolution.
Under constant input speed (e.g., 200 RPM), the raw IAS signals for the three conditions were obtained. After removing the mean speed, the fluctuating IAS components were analyzed. The experimental results corroborated the simulation findings:
- The IAS waveform for the healthy rotary vector reducer showed only regular, low-level undulations.
- For the faulty planet gear, clear, sharp periodic impulses appeared in the IAS waveform at the planet rotation period. The order spectrum exhibited prominent \(O_p\)-spaced sidebands around \(O_{mp}\).
- For the faulty cycloid gear, periodic, wider modulations appeared in the IAS waveform at the same period. The order spectrum showed dominant \(O_p\)-spaced sidebands around \(O_{mc}\).
These experimental signatures align with the theoretical predictions in Table 2, confirming the efficacy of IAS analysis for differentiating between planet and cycloid gear localized faults in a rotary vector reducer, despite their identical characteristic fault frequency. This method leverages the inherent mechanical response differences between the involute planetary stage and the cycloidal-pin stage.
5. Conclusion
This analysis demonstrates that instantaneous angular speed (IAS) monitoring, facilitated by the ubiquitous servo motor encoder, provides a powerful and direct means for diagnosing localized gear faults in rotary vector reducers. The core of the method lies in understanding how different fault types modulate the system’s time-varying meshing stiffness, which in turn creates distinct torsional vibrations. Planet gear faults generate short-duration, high-impact impulses due to the low contact ratio of spur gears, leading to strong fault-related sidebands around the planetary meshing order in the spectrum. Conversely, cycloidal gear faults cause longer-duration, lower-impact modulations due to the high contact ratio and multi-tooth engagement of the cycloidal stage, resulting in prominent fault sidebands around the cycloidal meshing order. These identifiable signatures in both the time-domain waveform and the order spectrum enable effective fault detection and isolation. This approach offers a non-intrusive, cost-effective diagnostic solution for the critical rotary vector reducer components in industrial robots, contributing significantly to condition-based maintenance strategies.