
Precision power transmission is the cornerstone of advanced manufacturing, and the rotary vector reducer stands as a critical component in this domain, particularly within the joints of industrial robots. Its superior attributes—high torque capacity, compact design, excellent torsional stiffness, and minimal backlash—make it indispensable for applications demanding high precision and reliability. However, the long-term operational stability and accuracy of these reducers are intrinsically linked to the wear performance of their core transmission elements, primarily the cycloid drive assembly. Tooth profile wear, a progressive surface degradation mechanism, acts as a precursor to more severe failures, gradually degrading transmission efficiency, increasing vibration and noise, and ultimately leading to a loss in positional accuracy. Therefore, developing a comprehensive model to predict and analyze the dynamic wear characteristics of the tooth profiles in a rotary vector reducer is of paramount engineering significance for lifecycle prediction, preventive maintenance, and performance optimization.
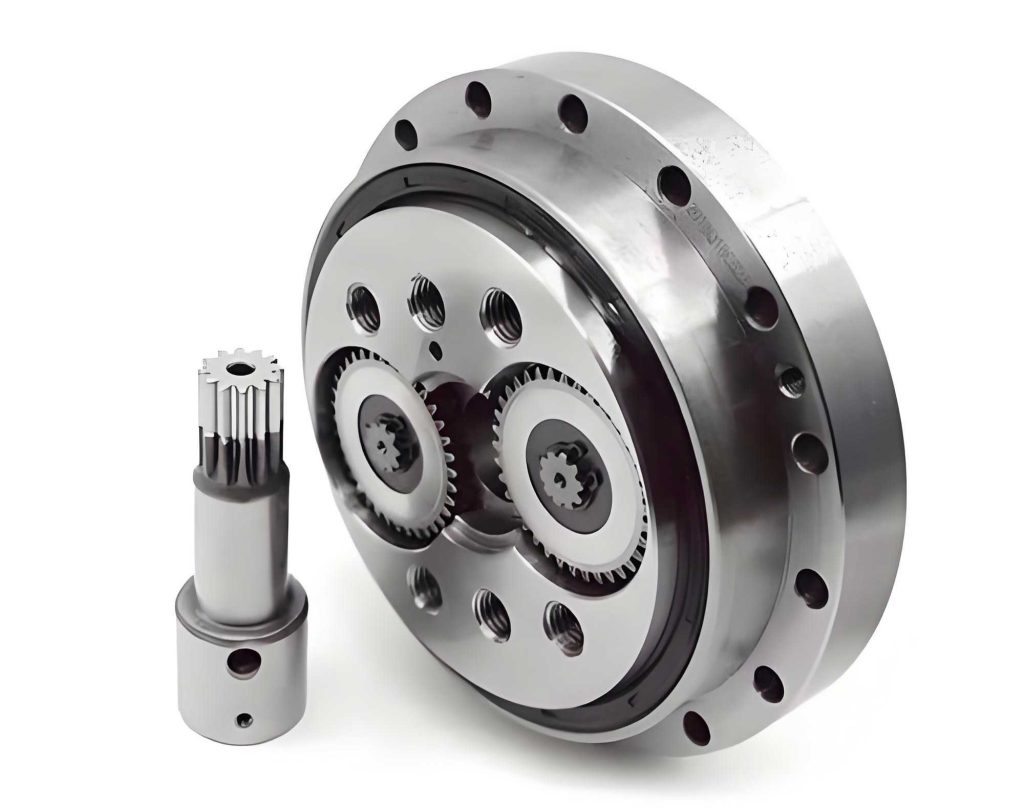
This study focuses on establishing a high-fidelity numerical simulation framework to quantify the dynamic wear evolution on the tooth flanks of a cycloid pinwheel system within a rotary vector reducer. The model integrates multi-body system dynamics, non-linear contact mechanics, and a physics-based wear law. A distinctive feature of our approach is the treatment of the wear coefficient not as a constant empirical value but as a variable parameter dependent on localized contact conditions, which evolve with the wear process itself. We validate key aspects of this relationship through equivalent experimental data. Using a representative rotary vector reducer model (based on the BX-40E specifications), we analyze the interplay between dynamic meshing forces, contact pressure distribution, relative sliding, and the resulting wear depth over multiple operational cycles.
System Modeling of the Rotary Vector Reducer
The rotary vector reducer is a compound gear system typically combining a first-stage planetary gear train with a second-stage cycloid drive. Our analysis centers on the cycloid pinwheel mechanism, which is primarily responsible for the high reduction ratio and compactness. The system’s kinematic and dynamic behavior forms the foundation for calculating the time-varying loads on each tooth pair.
Geometry of the Worn Cycloid Profile
The instantaneous meshing geometry between the cycloid disk and the stationary pinwheel is fundamental. The standard cycloid profile is derived from the rolling of a circle of radius $$r_{rp}$$ (generating circle radius) around a base circle of radius $$R_p$$ (pin circle radius). When wear occurs, material is removed normal to the tooth surface, effectively modifying the local profile. Considering the wear depth $$\Delta R_{rp}$$ on the pin and $$\Delta R_p$$ on the cycloid disk at a specific meshing point *i*, the modified profile equation for the cycloid disk in its coordinate system becomes:
$$
\begin{align*}
x_i &= (R_p + \Delta R_p \cos\alpha_i)\cos(\phi – \phi_{iH}) – a\cos\phi_{iH} + (r_{rp} + \Delta R_{rp})S^{-1/2}\left[K_1\cos\phi_{iH} – \cos(\phi – \phi_{iH})\right] \\
y_i &= (R_p + \Delta R_p \cos\alpha_i)\sin(\phi – \phi_{iH}) + a\sin\phi_{iH} – (r_{rp} + \Delta R_{rp})S^{-1/2}\left[K_1\sin\phi_{iH} – \sin(\phi – \phi_{iH})\right]
\end{align*}
$$
where:
$$S = 1 + K_1^2 – 2K_1\cos\phi, \quad K_1 = \frac{a Z_p}{R_p + \Delta R_p}, \quad \phi_{iH} = \frac{2\pi(i-1)}{Z_c}$$.
Here, $$a$$ is the eccentricity, $$Z_p$$ is the number of pins, $$Z_c$$ is the number of cycloid disk lobes, $$\phi$$ is the input crank angle, and $$\alpha_i$$ is the pressure angle at contact point *i*. The curvature radius of the cycloid profile, crucial for contact stress calculation, is also altered by wear and is given by:
$$\rho_i = \frac{R_p S^{3/2}}{|K_1(Z_p+1)\cos\phi – (1+Z_pK_1^2)|} + r_{rp} + \Delta R_{rp}$$
The geometric parameters for the analyzed rotary vector reducer system are summarized in the table below:
| Parameter | Symbol | Value/Unit |
|---|---|---|
| Number of Cycloid Lobes | $$Z_c$$ | 39 |
| Number of Pins | $$Z_p$$ | 40 |
| Pin Radius | $$r_{rp}$$ | 3.0 mm |
| Pin Circle Radius | $$R_p$$ | 69.5 mm |
| Eccentricity | $$a$$ | 1.3 mm |
| Short Coefficient | $$K_1$$ | 0.7482 |
| Tooth Width | $$b$$ | 15 mm |
| Input Torque | $$T_{in}$$ | 412 Nm |
| Output Speed | $$n_{out}$$ | 300 rpm |
Dynamic Model and Contact Force Analysis
A multi-degree-of-freedom translational-rotational dynamic model of the rotary vector reducer is established. This model includes the sun gear, planets, crankshafts, cycloid disks, and the output frame. The equations of motion account for time-varying mesh stiffness, damping, and most importantly, the geometric transmission error induced by progressive tooth wear on both the cycloid disk and pins.
The contact between a cycloid lobe and a pin is modeled as an elastic-impact between two cylinders. The non-linear Langkali-Nikravesh contact force model is employed, which includes both elastic and hysteretic damping components:
$$
F_{N_i}(t) = k_c \delta_i^{n} \left[ 1 + \frac{3(1-c_e^2)}{4} \frac{\dot{\delta}_i}{\dot{\delta}_i^{(-)}} \right]
$$
where $$k_c$$ is the contact stiffness derived from Hertzian theory, $$\delta_i(t)$$ is the dynamic penetration at the *i*-th tooth pair, $$\dot{\delta}_i$$ is its velocity, $$\dot{\delta}_i^{(-)}$$ is the initial impact velocity, $$n$$ is a force exponent (typically 1.5 for elastic contact), and $$c_e$$ is the coefficient of restitution.
The penetration $$\delta_i(t)$$ is critically dependent on the wear-induced profile error $$e_{cp_i}(t) = \Delta R_{p_i} – \Delta R_{rp_i}$$:
$$\delta_i(t) = \theta_c r_i – e_{cp_i}(t)$$
If $$\delta_i(t) \ge 0$$, contact is maintained; otherwise, the tooth pair separates. The load distribution among all simultaneously contacting tooth pairs is solved using the deformation compatibility condition, ensuring the sum of moments from all contact forces balances the input torque on the cycloid disk. The contact pressure $$p_i(t)$$ is then calculated from the Hertzian formula:
$$p_i(t) = \frac{F_{N_i}(t)}{2b a_{H_i}}, \quad a_{H_i} = \sqrt{\frac{4 F_{N_i}(t) \rho_{eq_i}}{\pi b E_{eq}}}$$
where $$a_{H_i}$$ is the half-width of the contact zone, $$\rho_{eq_i}$$ is the equivalent radius of curvature, and $$E_{eq}$$ is the equivalent elastic modulus.
Dynamic Wear Prediction Model for the Rotary Vector Reducer
The core of the prediction methodology is the Archard wear equation, which is generalized for dynamic, non-conformal contacts like those in a rotary vector reducer. The incremental wear depth $$\Delta h$$ at a discrete point on the tooth flank over a small time step $$\Delta t$$ is:
$$
\Delta h(t) = \kappa(t) \cdot p(t) \cdot s_{rel}(t)
$$
where $$\kappa(t)$$ is the dimensionless wear coefficient, $$p(t)$$ is the instantaneous contact pressure, and $$s_{rel}(t)$$ is the relative sliding distance accumulated over $$\Delta t$$. The total wear depth after $$N$$ cycles is the cumulative sum:
$$h_N(t) = \sum_{j=1}^{N} \Delta h_j(t)$$
Determination of the Wear Coefficient $$\kappa(t)$$
A key advancement in this model is recognizing that $$\kappa$$ is not a constant. It depends on local tribological conditions such as contact pressure, sliding velocity, and surface state, all of which evolve with wear. To capture this, we conducted equivalent disk-on-pin wear tests under controlled conditions representative of the rotary vector reducer’s operating envelope. The test parameters are listed below:
| Test Piece Parameter | Upper Piece (Pin) | Lower Piece (Disk) |
|---|---|---|
| Material | GCr15 Bearing Steel | GCr15 Bearing Steel |
| Hardness (HRC) | 60-62 | 60-62 |
| Radius | 2.5 mm | 25 mm |
| Normal Load (FN) | 20, 40, 60, 80 N | – |
| Rotational Speed | – | 30 rpm |
The instantaneous wear coefficient was calculated from measured mass loss $$Q(t)$$:
$$\kappa(t) = \frac{Q(t) \cdot H}{ \rho \cdot F_N \cdot (2\pi R_d n_d t) }$$
where $$H$$ is material hardness, $$\rho$$ is density, $$R_d$$ and $$n_d$$ are the disk radius and speed. The results showed $$\kappa$$ decreases with time (from a run-in to a steady-state value) and increases with applied load. This relationship $$\kappa(p, \dot{s}, state)$$ was fitted to a function and integrated into the dynamic simulation, where the local pressure $$p_i(t)$$ and sliding speed at each mesh point determine its instantaneous wear coefficient.
Calculation of Relative Sliding Distance
In the cycloid drive, pure rolling occurs only at the pitch point. At all other contact positions, relative sliding exists. The instantaneous sliding velocity $$v_{s_i}(t)$$ at the *i*-th contact point is the difference between the tangential velocities of the two surfaces. For a crank rotation angle $$\phi$$, it can be expressed as:
$$v_{s_i}(t) = a \omega \left[ \frac{Z_p}{Z_p – 1} – \frac{\sin(\alpha_i)}{\sin(\alpha_i + \beta_i)} \right]$$
where $$\omega$$ is the input angular speed, and $$\beta_i$$ is the angle of the contact normal. The incremental sliding distance $$s_{rel,i}(\Delta t)$$ is then $$v_{s_i}(t) \cdot \Delta t$$. This sliding distance, combined with the contact pressure, drives the wear process at that specific location on the rotary vector reducer’s tooth flank.
Results and Discussion
The integrated model was simulated for a significant number of operating cycles to observe the evolution of system dynamics and wear.
Dynamic Meshing Forces and Pressure Angle Correlation
The dynamic meshing force on individual tooth pairs varies significantly throughout a single revolution of the cycloid disk. The force distribution shifts among the approximately half of the teeth that are in contact simultaneously. A clear linear relationship was observed between the meshing force $$F_{N_i}$$ at a given point and its corresponding pressure angle $$\alpha_i$$:
$$F_{N_i} \propto C \cdot \sin(\alpha_i)$$
This relationship stems from the moment equilibrium condition of the cycloid disk. As wear progresses and the profile deviates from the ideal geometry, the load-sharing among teeth changes. With increasing wear cycles, the number of teeth sharing the load slightly decreases, leading to a gradual increase in the average force on the remaining contacting teeth.
Contact Pressure Distribution
The contact pressure distribution along the tooth profile is highly non-uniform. It reaches maximum values near the regions corresponding to the highest pressure angles. Notably, a distinct pressure valley was observed at the profile inflection point (where the cycloid curve transitions from convex to concave). At this point, the equivalent radius of curvature approaches infinity (flat contact), leading to a larger contact area and lower pressure for the same load. The evolution of contact pressure with wear is summarized below for key profile zones:
| Tooth Profile Zone | Initial Max Pressure | Trend with Wear | Primary Reason |
|---|---|---|---|
| Root Region (High $$\alpha$$) | Highest | Increase Rate Slows | Load concentration & work hardening |
| Inflection Point | Lowest (Valley) | Minimal Change | Conformal contact maintained |
| Tip Region (High $$\alpha$$) | High | Increase Rate Accelerates | Pronounced profile loss leading to edge contact |
Evolution of Relative Sliding and Wear Sensitivity
The relative sliding distance $$s_{rel}$$ along the profile forms an asymmetric “M” shape. Sliding is minimal at the inflection point (near pure rolling) and increases towards both the root and tip regions. As wear modifies the profile, the kinematic conditions change, altering the sliding distribution. We define a wear sensitivity $$\zeta$$ as the derivative of sliding distance with respect to wear depth: $$\zeta = \partial s_{rel} / \partial h$$. Analysis shows that the regions flanking the inflection point exhibit the highest sensitivity, meaning small amounts of wear there cause significant changes in subsequent sliding behavior, creating a feedback loop.
Tooth Profile Wear Depth Evolution
The cumulative wear depth on both the cycloid disk and the pins after multiple cycles reveals the characteristic wear pattern of the rotary vector reducer. The wear depth profile is an irregular, asymmetric inverted “W” shape. Key observations include:
- Dual Wear Peaks: Two primary wear peaks appear on the flanks of the cycloid lobe, located in the high-sensitivity zones before and after the inflection point. These correspond to regions of high combined pressure and sliding.
- Inflection Point Valley: The wear depth is minimal at the inflection point due to the low contact pressure and near-zero sliding, acting as a natural wear-resistant zone.
- Root and Tip Micro-Peaks: Small, sharp wear peaks are observed very close to the root and tip of the cycloid lobe. These are caused by “edge-loading” or “tip/root contact” events that occur due to accumulated profile wear and dynamic deflections, leading to brief, high-impact contact.
The progression of wear with the number of cycles $$N$$ is non-linear. The wear rate (depth per cycle) is highest initially and gradually decreases, approaching a steady state as the contact conforms and work-hardens, aligning with the experimental $$\kappa(t)$$ trend. A comparison with a model using a constant wear coefficient showed substantial quantitative and qualitative differences. The constant-$$\kappa$$ model underestimated wear in the peak regions and failed to predict the formation of root/tip micro-peaks, underscoring the necessity of using a condition-dependent wear coefficient for accurate life prediction of the rotary vector reducer.
The wear depth $$h$$ on the pin follows a similar but mirrored pattern. The maximum wear depth on the cycloid disk after a simulated 5000 cycles was approximately an order of magnitude larger than that on the harder, stationary pins, indicating the cycloid disk is the more vulnerable component in this pair.
Conclusion
This study developed a comprehensive dynamic wear prediction model for the critical cycloid-pin interface within a rotary vector reducer. By integrating a multi-body dynamic model, a non-linear contact formulation, and a generalized Archard wear law with an experimentally-derived variable wear coefficient, the framework successfully captures the complex interplay between system dynamics, contact mechanics, and progressive surface degradation. The key findings for the rotary vector reducer are:
- The wear coefficient is a dynamic parameter dependent on local contact conditions. Using a condition-variable coefficient, as opposed to a constant value, is essential for accurate wear quantification and prediction of characteristic wear patterns like root/tip micro-peaks.
- The wear depth profile on the cycloid tooth is non-uniform, forming an inverted “W” shape with dual main peaks in high-pressure, high-slip zones and a pronounced valley at the profile inflection point where contact conditions are favorable.
- Wear evolution alters the load distribution and meshing kinematics, creating a feedback mechanism. The wear rate generally decreases non-linearly with cycles due to work hardening and increased conformity, but localized phenomena like edge contact can create micro-peaks.
- The meshing force on a tooth pair is linearly correlated with its instantaneous pressure angle, a fundamental relationship governing the load-sharing behavior in the rotary vector reducer.
The proposed model provides a powerful virtual tool for engineers to assess the long-term wear performance of a rotary vector reducer during the design phase. It enables optimization of gear parameters, material selection, and lubrication strategies to minimize wear, thereby enhancing the reliability, maintaining precision, and extending the service life of industrial robots and other precision machinery utilizing this vital component. Future work will incorporate the effects of lubrication and wear debris into the model for an even more realistic simulation.