
The rotary vector reducer, commonly known as the RV reducer, is a high-precision, high-rigidity, and high-load-capacity transmission mechanism integral to industrial robots and precision machinery. Its performance directly influences the positional accuracy and dynamic response of the entire system. Within this sophisticated over-constrained structure, the connecting bolts that secure the planet carrier (comprising the support shaft and output flange) are critical components. Their mechanical behavior under operational loads is not merely a matter of static connection but a dynamic factor affecting load distribution, structural integrity, and ultimately, the transmission error of the reducer. Traditional analysis often relies on empirical formulas or simplified static models, which fail to capture the complex, time-varying forces induced by the unique cycloidal-pin gear meshing and the multi-path load sharing inherent to the rotary vector reducer design. This article presents a comprehensive investigation into the force characteristics of these connecting bolts, combining theoretical derivation based on deformation coordination principles with multi-body dynamic simulation to elucidate their behavior under various operational conditions.
Introduction and Theoretical Foundation
The rotary vector reducer operates on a two-stage principle: a primary involute planetary gear stage and a secondary cycloidal-pin gear stage, connected via crankshafts. This configuration results in multiple load paths and redundant constraints. Analyzing forces in such a system requires more than static equilibrium; it necessitates the application of deformation coordination conditions. These conditions ensure the compatibility of displacements and deformations among all interconnected elastic elements, guaranteeing the structure’s continuity after loading.
The general three-dimensional strain compatibility equations are given by:
$$
\begin{aligned}
&\frac{\partial^2 \varepsilon_{x}}{\partial y^{2}}+\frac{\partial^2 \varepsilon_{y}}{\partial x^{2}}=\frac{\partial^{2} \gamma_{x y}}{\partial x \partial y}, \\
&\frac{\partial^{2} \varepsilon_{y}}{\partial z^{2}}+\frac{\partial^{2} \varepsilon_{z}}{\partial y^{2}}=\frac{\partial^{2} \gamma_{y z}}{\partial y \partial z}, \\
&\frac{\partial^{2} \varepsilon_{x}}{\partial z^{2}}+\frac{\partial^{2} \varepsilon_{z}}{\partial x^{2}}=\frac{\partial^{2} \gamma_{x z}}{\partial x \partial z}, \\
&2 \frac{\partial^{2} \varepsilon_{x}}{\partial y \partial z}=\frac{\partial}{\partial x}\left(-\frac{\partial \gamma_{y z}}{\partial x}+\frac{\partial \gamma_{x z}}{\partial y}+\frac{\partial \gamma_{x y}}{\partial z}\right), \\
&2 \frac{\partial^{2} \varepsilon_{y}}{\partial x \partial z}=\frac{\partial}{\partial y}\left(-\frac{\partial \gamma_{y z}}{\partial x}+\frac{\partial \gamma_{x z}}{\partial y}+\frac{\partial \gamma_{x y}}{\partial z}\right), \\
&2 \frac{\partial^{2} \varepsilon_{z}}{\partial x \partial y}=\frac{\partial}{\partial z}\left(-\frac{\partial \gamma_{y z}}{\partial x}+\frac{\partial \gamma_{x z}}{\partial y}+\frac{\partial \gamma_{x y}}{\partial z}\right).
\end{aligned}
$$
For the specific case of the rotary vector reducer, these principles are applied to key components. Assuming rigid-body motion for high-stiffness parts and elastic deformation for bearings and gears, the following coordination conditions are established:
- Output Flange/Planet Carrier: Due to its high rigidity, the tangential elastic deformations of all support bearings on the crankshafts are equal. Similarly, the tangential elastic displacements of all connecting bolts are equal.
$$\delta_{ot1} = \delta_{ot2} = \ldots = \delta_{otM}, \quad \delta_{L1} = \delta_{L2} = \ldots = \delta_{L6}.$$ - Planet Gears and Cycloid Gears: The elastic deformations along the line of action for each planet gear meshing with the sun gear are equal. Likewise, the deformations for each cycloid gear meshing with the pin gear are equal.
$$\delta_{sp1} = \delta_{sp2} = \delta_{spM}, \quad \delta_{cr1} = \delta_{cr2} = \ldots = \delta_{crN}.$$
Applying static equilibrium equations for each component (sun gear, planet gear, crankshaft, cycloid gear, and output flange) in conjunction with these deformation coordination conditions allows for the theoretical calculation of the force in each load path, including the forces on the crankshaft support bearings and the connecting bolts. The force \(F\) contributed by a bolt pair on the output flange, accounting for friction, is given by:
$$F = (F_{Li} – F_{fi}) \cos(\beta/2), \quad \text{where } F_{fi} = F_{pre} f.$$
Here, \(F_{Li}\) is the shear force on bolt \(i\), \(F_{fi}\) is the frictional force on the contact surface, \(F_{pre}\) is the bolt preload, \(f\) is the coefficient of friction, and \(\beta\) is the angular separation between bolts.
Parametric Modeling of the Rotary Vector Reducer
Accurate geometric modeling is paramount, especially for the cycloid disk. The standard cycloidal profile is modified to ensure proper backlash for assembly, lubrication, and error compensation. Using the principle of generating a cycloid via a rolling circle and employing vector methods, the equation for the modified cycloid profile is established. The primary modifications are the equidistant modification (\(\Delta R_p\)) and the shift modification (\(\Delta R_b\)).
The parametric equations for the modified cycloid gear profile are:
$$
\begin{bmatrix} x(\theta) \\ y(\theta) \end{bmatrix} = \begin{bmatrix} R^*_b \cos\theta + (R_g S – R^*_p) \cos(\theta + \beta) \\ R^*_b \sin\theta + (R_g S – R^*_p) \sin(\theta + \beta) \end{bmatrix}
$$
Where:
$$
\begin{aligned}
& R^*_b = R_b + \Delta R_b, \quad R^*_p = R_p + \Delta R_p, \quad i_0 = \frac{R_b}{R_g}, \quad \gamma_0 = i_0 \theta, \\
& \tan \beta = \frac{a \sin \gamma_0}{R_g + a \cos \gamma_0}, \quad S = \sqrt{1 + K_1^2 + 2 K_1 \cos \gamma_0}, \quad K_1 = \frac{a}{R_g}.
\end{aligned}
$$
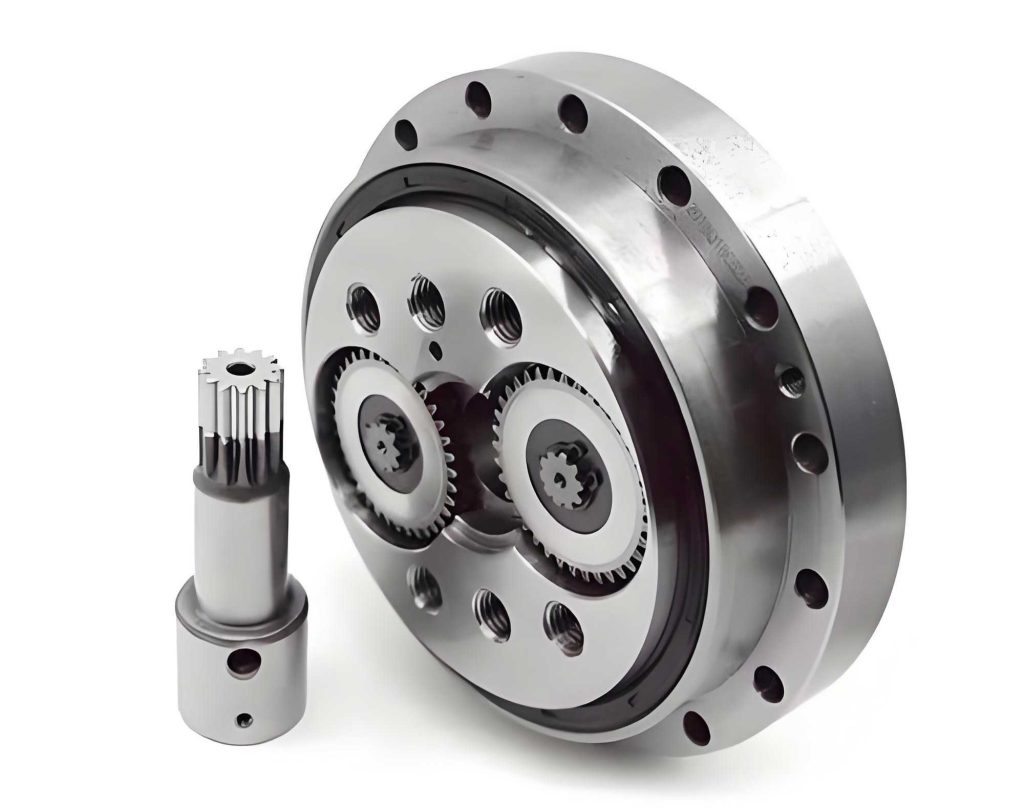
Based on the parameters of an RV-20E-81 type reducer, a full three-dimensional parametric model is created. This model includes all key components: the input sun gear, planet gears, crankshafts, cycloid gears, pin gear housing, needle pins, output flange, support shaft, and the connecting bolts. The basic parameters used for modeling are summarized in the table below.
| Primary Parameter | Symbol | Value | Primary Parameter | Symbol | Value |
|---|---|---|---|---|---|
| Sun Gear Teeth | \(Z_s\) | 12 | Cycloid Gear Teeth | \(Z_c\) | 39 |
| Planet Gear Teeth | \(Z_p\) | 24 | Pin Gear Teeth | \(Z_b\) | 40 |
| Pressure Angle | \(\alpha\) | 20° | Eccentricity | \(a\) | 0.9 mm |
| Planet Gear Width | \(B_1\) | 5 mm | Cycloid Gear Width | \(B_2\) | 8.9 mm |
| Pin Center Circle Radius | \(R_z\) | 52 mm | Pin Radius | \(r_z\) | 2 mm |
| Equidistant Modification | \(\Delta R_z\) | -0.01 mm | Shift Modification | \(\Delta r_z\) | -0.012 mm |
| Bolt Diameter | \(D\) | 8 mm | Bolt Circle Radius | \(r_L\) | 35 mm |
Multi-Body Dynamic Simulation Methodology
To analyze the dynamic force variations in the bolts under realistic operating conditions, a multi-body dynamics (MBD) model is developed in Adams. The complex 3D geometry is imported, and the simulation environment is configured as follows:
- Material Properties: All components are assigned appropriate material properties (e.g., density, Young’s modulus) but are treated as rigid bodies since the focus is on gross motion and force transmission, not component flexibility.
- Kinematic Joints: Revolute joints are defined between the input shaft and ground, the support shaft and ground, the output flange and ground, the crankshafts and the support shaft (at the support bearing hole center), and the crankshafts and cycloid gears (at the cycloid gear bearing hole center). Fixed joints connect the pin gear housing to ground, the bolts to the support shaft, and the needle pins to the pin housing.
- Contact Forces: The critical meshing action between the cycloid gear and the needle pins is modeled using an impact-based contact force. The contact stiffness is set to \(1.2 \times 10^7 \, \text{N·m/rad}\) and the damping to \(3.8 \times 10^{-4} \, \text{N·s·m}^{-1}\). The primary planetary stage is modeled using Adams’ built-in gear constraints.
- Driving and Loading Conditions: A smooth step function is applied to the input shaft to avoid instantaneous acceleration: $$\text{Input Motion: } 7290 \times \text{time} \times \text{step}(\text{time}, 0, 0, 0.1, 1) \, \text{deg/s}.$$
An output torque is applied to the output flange, also using a step function to apply load after startup: $$\text{Output Torque: } \text{step}(\text{time}, 0.1, 0, 0.2, -1.67 \times 10^5) \, \text{N·mm}.$$
The simulation is run for 3 seconds with 3000 steps using the GSTIFF integrator. The model validation shows the output speed stabilizes at 89.9964 deg/s, matching the theoretical reduction ratio with an error of only 0.004%, confirming the model’s kinematic accuracy.
Analysis of Bolt Force Characteristics Under Various Conditions
To investigate the influence of different operational parameters on the six connecting bolts (numbered 1 to 6), a series of dynamic simulations are performed. The bolts experience shear forces due to the transmitted torque, and their magnitudes vary with the kinematic state of the rotary vector reducer.
Influence of Cycloid Gear Rotation Angle
The position of the cycloid gear relative to the pin gear significantly alters the contact force distribution. Simulations are run for different cycloid gear rotation angles (from an initial reference position) under a constant load. The force on each bolt is measured. The general trend of total bolt force initially increases with the rotation angle, peaks, and then decreases. The individual bolt forces show distinct and non-linear patterns:
| Rotation Angle | Bolt 1 Force Trend | Bolt 2 Force Trend | Bolt 3 Force Trend | Bolt 4 Force Trend | Bolt 5 Force Trend | Bolt 6 Force Trend |
|---|---|---|---|---|---|---|
| 45° | High | Medium | Medium | Low | Medium | Medium |
| 90° | Minimum | High | Medium-High | Low-Medium | Minimum | Maximum |
| 135° | Medium | Medium | Minimum | Medium | High | Low |
| 180° | High | Low | High | Low-Medium | Medium-High | Low |
The key observation is that the load-sharing order among the six bolts changes with the rotation angle. At any given angle, typically four bolts carry relatively similar loads, while the remaining two experience significantly higher or lower forces. For instance, at 90°, Bolt 6 carries the highest load, whereas at 180°, Bolts 1 and 3 become more heavily loaded. This demonstrates the dynamic and periodic nature of load distribution in the rotary vector reducer.
Influence of Initial Mounting Angle of the Cycloid Gear
The initial angular orientation (or phase) of the cycloid gear assembly when the reducer starts operation also affects the bolt force history. Simulations are conducted for different initial mounting angles, with the cycloid gear rotating through a fixed 90° arc. The results indicate a complex dependency:
| Initial Angle | Most Loaded Bolt(s) | Least Loaded Bolt(s) | Remarks on Force Variation |
|---|---|---|---|
| 16° | Bolt 5, Bolt 6 | Bolt 1, Bolt 4 | Moderate variation among bolts. |
| 32° | Bolt 1, Bolt 5 | Bolt 6 | Bolt 6 force shows a sharp drop. |
| 48° | Bolt 5 | Bolt 2, Bolt 4 | Bolt 5 force peaks; others are moderate. |
| 64° | Bolt 4, Bolt 1 | Bolt 2 | Significant shift in load pattern. |
This sensitivity to initial phase means that two identical rotary vector reducers, assembled with their cycloid gears in different orientations, could exhibit different bolt load patterns and potentially different fatigue lives for the bolted connection.
Influence of Output Load Torque
The magnitude of the output load torque is a primary factor determining the absolute force levels in the bolts. Simulations are run with increasing torque values. As expected, the forces in most bolts increase monotonically with the applied torque. However, the rate of increase is not linear, and the sensitivity varies per bolt.
| Output Torque (N·mm) | Bolt 1 Force | Bolt 2 Force | Bolt 3 Force | Bolt 4 Force | Bolt 5 Force | Bolt 6 Force | Total Force Sum |
|---|---|---|---|---|---|---|---|
| 20,000 | Low | Low | Low | Low | Low | Medium | Low |
| 60,000 | Medium-Low | Medium-Low | Medium-Low | Medium-Low | Medium-Low | High | Medium |
| 100,000 | Medium | Medium | Medium | Medium | Medium | Very High | High |
| 140,000 | Medium-High | Medium-High | Medium-High | Medium-High | Medium-High | Very High | Very High |
| 180,000 | High | High | High | High | High | High (slight drop from 140k) | Highest |
The trend shows that as torque rises, the force carried by the “primary” load-bearing bolts (which change with angle) increases significantly. At very high torque, the system seems to redistribute load more evenly, as seen by Bolt 6’s force stabilizing or slightly decreasing while others catch up. The overall sum of bolt forces increases non-linearly, with a steeper slope at higher torques, indicating the growing contribution of the bolt circle to resisting the output moment.
Discussion and Synthesis of Findings
The dynamic analysis of the rotary vector reducer reveals that the connecting bolts are subject to a complex, periodically varying load state that is far from a simple, evenly distributed shear. The forces are highly dependent on the instantaneous kinematic configuration (cycloid gear angle), the initial assembly phase, and the load level. This behavior stems directly from the epicyclic motion of the cycloid gear and the changing pattern of simultaneous tooth engagements with the needle pins.
The deformation coordination principle provides the theoretical backbone for understanding force distribution in this statically indeterminate system. It explains why forces equalize among similar load paths (like planet gears) but also why, in the bolt circle, forces can differ because the compatibility condition applies to tangential displacement, not directly to force. The local stiffness of the flange structure and the friction in the joint determine how the total tangential force is apportioned among the individual bolts.
The following table summarizes the force characteristics for each bolt across the studied conditions:
| Bolt Number | General Load Trend with Increasing RV Angle | Sensitivity to Initial Mounting Angle | Sensitivity to Load Torque |
|---|---|---|---|
| Bolt 1 | Decreases then increases | Moderate | High |
| Bolt 2 | Increases then decreases | High | High |
| Bolt 3 | Increases, decreases, then increases | Moderate-High | High |
| Bolt 4 | Relatively stable, small fluctuations | Low-Moderate | High |
| Bolt 5 | Decreases then increases | Very High | High |
| Bolt 6 | Increases sharply then decreases | Very High | Very High, non-linear |
For design and reliability assessment, this implies that:
- Bolt selection and preload must account for the dynamic amplification factor, not just the average shear. The most critical bolt (e.g., Bolt 6 at 90° rotation) experiences a force significantly higher than the simple total torque divided by the number of bolts.
- Fatigue analysis for the bolted connection must consider the complete stress cycle as the cycloid gear rotates through one period. The variable-amplitude loading can accelerate fatigue crack initiation.
- Assembly consistency might be important for predictable performance. Controlling the initial mounting angle of the cycloid gear could help minimize the worst-case bolt load in a specific application.
- Condition monitoring could potentially use bolt strain patterns as an indicator of internal wear or misalignment within the rotary vector reducer.
Conclusion
This study has systematically investigated the force characteristics of the connecting bolts in a rotary vector reducer through an integrated approach of theoretical mechanics and multi-body dynamic simulation. The application of deformation coordination principles provides the foundational framework for analyzing the over-constrained system, while dynamic simulation in Adams captures the intricate, time-varying forces resulting from the cycloidal-pinion meshing action.
The key findings are that bolt forces are not static or uniformly distributed. They vary significantly with the rotation angle of the cycloid gear, with the order of the most-to-least loaded bolts changing throughout the cycle. The initial assembly phase of the cycloid gear introduces another layer of variability, influencing the specific load history. As expected, all bolt forces scale with the output load torque, but in a non-linear and non-uniform manner. The total force transmitted through the bolt circle exhibits a non-linear increase with torque and a parabolic trend with rotation angle, initially rising before falling.
These insights move beyond simplistic empirical calculations and highlight the dynamic complexity of load sharing in precision gearboxes like the rotary vector reducer. Understanding this behavior is crucial for optimizing the design of the planet carrier connection, ensuring adequate fatigue life, and improving the overall reliability and precision of this critical robotic component. Future work could incorporate the finite element method to model joint flexibility and contact deformations more precisely, and experimental strain gauge validation would further solidify these findings.