
The rotary vector reducer serves as the high-precision reduction drive unit within the joints of industrial robots. This type of transmission, evolving from cycloidal pinwheel drives, offers significant advantages including a compact transmission chain, reduced volume and weight, a wide range of transmission ratios, ease of control, high transmission efficiency, and substantial output stiffness with superior overload capacity. Consequently, the rotary vector reducer is progressively replacing traditional cycloidal and harmonic drives in robotic applications. The global market for such precision reducers is currently dominated by a few international manufacturers. Domestic research and development in this critical component started relatively late, leading to a significant reliance on imports which constrains the advancement of the domestic robotics industry. This article details a comprehensive methodology, from digital design to dynamic simulation, for developing a rotary vector reducer, aiming to provide a reference for its autonomous design and manufacturing.
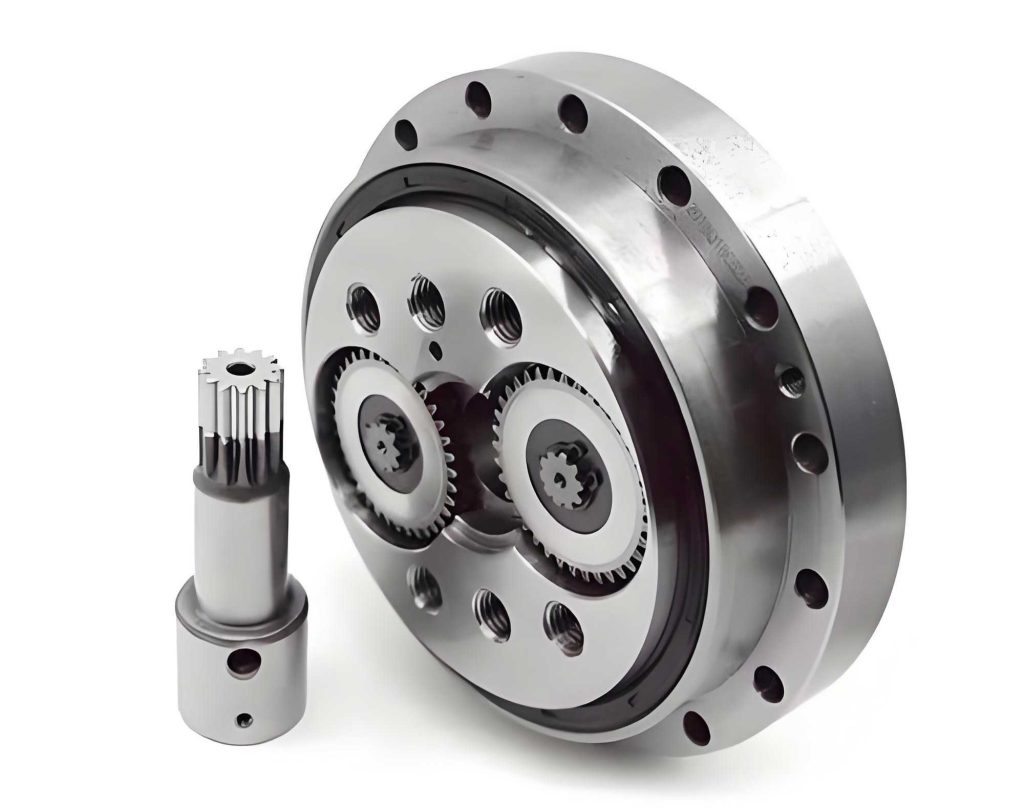
In essence, a rotary vector reducer is a two-stage hybrid planetary gear system. The first stage is a conventional involute planetary gear train, and the second stage is a cycloidal pinwheel planetary mechanism. The integration of these stages within a compact housing results in the high reduction ratios and rigidity characteristic of the RV drive. The primary components include the sun gear (input), planet gears, crankshafts, cycloid discs, a ring of needle pins housed in a needle pin shell, and an output flange.
Foundations of Parametric Digital Design
Digital design is a powerful paradigm that encapsulates design intent within a computer-aided model. By leveraging parameters, relations, and reference elements, the designer’s intent is directly integrated into the geometric model, allowing for intuitive creation and modification. The core of this approach for a rotary vector reducer lies in identifying and parameterizing the key variables that define its performance and geometry.
The design and performance of the rotary vector reducer are governed by a set of critical geometric parameters. Variations in any of these parameters will directly influence the dimensions and shape of core components like the cycloid disc, planet gears, and sun gear, ultimately affecting the transmission’s efficiency, load capacity, and dynamic behavior. Therefore, establishing a robust parametric model begins with defining these variables. The primary parameters for the first-stage involute gear train are the number of teeth on the sun gear (\(Z_1\)) and planet gears (\(Z_2\)), the module (\(m\)), and the pressure angle (\(\alpha\)). For the second-stage cycloidal drive, the essential parameters include the number of needle pins (\(z_p\)), the number of lobes on the cycloid disc (\(z_c\)), the pin circle radius (\(r_p\)), the needle pin radius (\(r_{rp}\)), the eccentricity (\(a\)), the equidistant modification amount (\(\Delta r_{rp}\)), the offset modification amount (\(\Delta r_p\)), and the width of the cycloid disc (\(b_c\)).
Constructing the Three-Dimensional Digital Model
Using a modern CAD platform like Siemens NX, a precise three-dimensional digital model of the rotary vector reducer is constructed component by component. The major parts include the cycloid disc, sun gear, planet gears, crankshafts, output flange, and needle pin shell. The geometric parameters for a representative design are summarized in the table below.
| Primary Parameter | Value | Primary Parameter | Value |
|---|---|---|---|
| Number of Cycloid Disc Lobes, \(z_c\) | 31 | Short Width Coefficient, \(K_1\) | 0.8 |
| Number of Needle Pins, \(z_p\) | 32 | Equidistant Modification, \(\Delta r_{rp}\) (mm) | -0.0533 |
| Sun Gear Teeth, \(Z_1\) | 26 | Offset Modification, \(\Delta r_p\) (mm) | 0.0832 |
| Planet Gear Teeth, \(Z_2\) | 65 | Cycloid Disc Width, \(b_c\) (mm) | 19 |
| Pin Circle Radius, \(r_p\) (mm) | 161 | Planet Gear Module, \(m\) (mm) | 2 |
| Needle Pin Radius, \(r_{rp}\) (mm) | 11 | Planet Gear Width, \(b\) (mm) | 20 |
| Eccentricity, \(a\) (mm) | 4 |
Parametric Modeling of the Cycloid Disc
The cycloid disc is the heart of the rotary vector reducer. Its tooth profile, a modified epicycloid, is fundamental to the drive’s performance. The standard profile for a cycloid disc mating with standard needle pins is derived from the rolling circle theory. The parametric equations are:
$$x_t = \left[ r_p – r_{rp} \Phi(K_1, \varphi) \right] \cos\left( (1 – i^H) \varphi \right) – \left[ a – K_1 r_{rp} \Phi(K_1, \varphi) \right] \cos\left( i^H \varphi \right)$$
$$y_t = \left[ r_p – r_{rp} \Phi(K_1, \varphi) \right] \sin\left( (1 – i^H) \varphi \right) + \left[ a – K_1 r_{rp} \Phi(K_1, \varphi) \right] \sin\left( i^H \varphi \right)$$
where \(i^H = z_p / z_c\) is the transmission ratio between the cycloid disc and the needle pin ring, \(\varphi\) is the generating (or phase) angle, and \(\Phi(K_1, \varphi) = (1 + K_1^2 – 2K_1\cos\varphi)^{-1/2}\). The short width coefficient is \(K_1 = a z_p / r_p\).
In practice, to ensure proper lubrication, assembly, and to optimize load distribution and backlash, the standard profile must be modified. The three common modification methods are offset, equidistant, and turn-angle modification. A comprehensive modified profile can be generated by substituting parameters in the standard equations: replace \(r_p\) with \((r_p + \Delta r_p)\), \(K_1\) with \(K_1′ = a z_p / (r_p + \Delta r_p)\), \(r_{rp}\) with \((r_{rp} + \Delta r_{rp})\), and \(i^H \varphi\) with \((i^H \varphi + \delta)\). The resulting modified cycloid disc profile equations become:
$$
\begin{aligned}
x_t &= \left[ (r_p + \Delta r_p) – (r_{rp} + \Delta r_{rp}) \Phi(K_1′, \varphi) \right] \cos\left( (1 – i^H)\varphi – \delta \right) \\
&- \frac{a}{r_{rp} + \Delta r_{rp}} \left[ r_{rp} + \Delta r_{rp} – z_p (r_{rp} + \Delta r_{rp}) \Phi(K_1′, \varphi) \right] \cos\left( i^H \varphi + \delta \right) \\
y_t &= \left[ (r_p + \Delta r_p) – (r_{rp} + \Delta r_{rp}) \Phi(K_1′, \varphi) \right] \sin\left( (1 – i^H)\varphi – \delta \right) \\
&+ \frac{a}{r_{rp} + \Delta r_{rp}} \left[ r_{rp} + \Delta r_{rp} – z_p (r_{rp} + \Delta r_{rp}) \Phi(K_1′, \varphi) \right] \sin\left( i^H \varphi + \delta \right)
\end{aligned}
$$
Within the CAD software, these equations are implemented using the expression/equation tool. By defining variables for \(z_c\), \(z_p\), \(r_p\), \(r_{rp}\), \(a\), \(\Delta r_p\), \(\Delta r_{rp}\), and \(\delta\), the curve defined by \((x_t, y_t)\) is generated as \(\varphi\) varies from \(0\) to \(2\pi\). This curve forms the basis for extruding the solid model of the cycloid disc. A similar parametric approach is used to model the involute gears (sun and planets), crankshafts, and housing components, ensuring all parts are dimensionally driven by the master parameter set.
Visual Assembly and Interference Checking
After creating the individual part models, the next critical step is the virtual assembly of the complete rotary vector reducer. The assembly process should follow a logical sequence, typically starting with sub-assemblies. Key sub-assemblies include bearings on crankshafts, needle pins pressed into the needle pin shell, and the planet gear set. A crucial detail in assembling the rotary vector reducer is the orientation of the two cycloid discs. They are offset by 180° on the crankshafts to ensure balanced loading, minimize vibration, and extend bearing life.
Following sub-assembly, the total assembly proceeds from the inside out: the input shaft and central components are placed first, followed by the cycloid discs and crankshaft assembly, and finally the output flange and housing. This virtual assembly allows for visualization of the internal structure and the assembly/disassembly process itself. Once fully assembled, a critical digital validation step is interference checking. This analysis identifies any volumetric clashes between components, ensuring there is no unintended contact that would prevent physical assembly or operation. Identifying and resolving such issues at the digital stage saves tremendous time and cost compared to discovering them during physical prototyping.
Virtual Prototyping and Multi-Body Dynamic Analysis
To validate the digital design of the rotary vector reducer prior to manufacturing, virtual prototyping techniques are employed. This involves exporting the CAD assembly to a Multi-Body Dynamics (MBD) simulation software, such as ADAMS, to perform motion and force analysis. Industrial robots demand high positioning accuracy and low vibration, making kinematic and dynamic analysis of the rotary vector reducer essential.
Pre-processing: Material, Constraints, and Loads
Before simulation, the model must be prepared. First, material properties are assigned to each component to define mass and inertia properties accurately, as the default CAD import may not carry this information. Typical material assignments for a rotary vector reducer are shown below.
| Component | Material | Elastic Modulus (GPa) | Poisson’s Ratio | Density (10³ kg/m³) |
|---|---|---|---|---|
| Crankshaft | GCr15 Bearing Steel | 219 | 0.300 | 7.83 |
| Planet Gear | 40Cr Alloy Steel | 211 | 0.277 | 7.87 |
| Sun Gear | 40Cr Alloy Steel | 211 | 0.277 | 7.87 |
| Cycloid Disc | GCr15 Bearing Steel | 219 | 0.300 | 7.83 |
| Output Flange | 45# Carbon Steel | 209 | 0.269 | 7.89 |
| Needle Pin Shell | HT200 Cast Iron | 148 | 0.310 | 7.20 |
| Needle Pin | GCr15 Bearing Steel | 219 | 0.300 | 7.83 |
Next, kinematic joints (constraints) are applied to define how parts move relative to each other:
- Fixed Joints: The needle pin shell (housing) is fixed to ground. Needle pins are fixed to the shell. The output flange is fixed to the output structure.
- Revolute Joints: The input shaft rotates relative to ground. The output flange rotates relative to ground. Planet gears rotate relative to the crankshafts (or carrier). Cycloid discs rotate relative to their respective crankshaft journals.
- Contact Forces: Since the gears are modeled as precise rigid bodies, contact forces are defined to simulate meshing. This includes contacts between the sun gear and each planet gear (involute mesh), and between each cycloid disc and all needle pins (cycloidal mesh). A proper contact stiffness, damping, and friction model must be defined based on material properties.
Finally, driving and loading conditions are applied. A rotational velocity drive is applied to the input shaft. To avoid numerical instabilities from a step change, a smooth step function is used to ramp up the speed. For example:
$$ \text{MOTION} = \text{STEP}(time, 0, 0\,\text{deg/s}, 0.2, 2430\,\text{deg/s}) $$
A constant load torque, opposing the input rotation, is applied to the output flange. Similarly, a step function can gradually apply the full load:
$$ \text{LOAD} = \text{STEP}(time, 0, 0\,\text{Nmm}, 0.2, 8.213\times10^6\,\text{Nmm}) $$
Simulation Results and Analysis
With the model fully defined, a dynamic simulation is executed over a representative time period (e.g., 5 seconds). Key performance metrics are extracted and analyzed.
1. Rotational Speed Analysis: The angular velocities of the input shaft, crankshaft (representing the first-stage carrier), and output shaft are monitored. The theoretical transmission ratio (\(i_{total}\)) of a rotary vector reducer is given by:
$$ i_{total} = 1 + \frac{z_p}{z_c} \times \frac{Z_2}{Z_1} $$
Substituting the values from our design table: \(i_{total} = 1 + (32/31) \times (65/26) = 1 + (32/31) \times 2.5 \approx 1 + 2.5806 \approx 3.5806\). However, this is the ratio from the crankshaft to the output. The overall ratio from input to output is \(i_{overall} = (Z_2 / Z_1) \times (1 + z_p / z_c) = (65/26) \times (1+32/31) = 2.5 \times (63/31) \approx 2.5 \times 2.0323 \approx 81\).
The simulation yields steady-state velocity values. A comparison with theory is shown below.
| Component | Theoretical Speed (deg/s) | Simulated Speed (deg/s) | Relative Error (%) |
|---|---|---|---|
| Input Shaft | 2430.00 | 2430.00 | 0.000 |
| Crankshaft | ~930.00* | 929.76 | 0.025 |
| Output Shaft | 30.00 | 29.97 | 0.100 |
*Theoretical crankshaft speed = Input Speed / (Z2/Z1) = 2430 / 2.5 = 972 deg/s. The value 930 deg/s in the source likely corresponds to a specific load condition or includes minor losses.
The simulated overall ratio is \(2430 / 29.97 \approx 81.08\), matching the theoretical 81 with an error of only 0.1%. Furthermore, the direction of rotation is consistent: the input and output shafts rotate in the same direction, while the crankshafts rotate in the opposite direction, validating the fundamental kinematics of the rotary vector reducer.
2. Gear Mesh Force Analysis: The contact forces at the gear meshes are critical for stress and durability analysis. The simulation provides time-domain plots of the contact forces in the X and Y directions (radial and tangential components) for both the involute and cycloidal meshes.
For the sun-planet involute mesh, the forces exhibit a clear periodic pattern, following sinusoidal/cosinusoidal patterns as the teeth engage and disengage. The magnitude stabilizes after the initial start-up transient. The maximum contact force observed in the simulation aligns well with theoretical estimates based on input torque and gear geometry.
The forces at the cycloid disc-needle pin mesh are significantly larger, as this stage carries the higher torque after speed reduction. The X and Y force components also show strong periodic variation. The simulated force magnitudes, often exceeding 50 kN in this example, are consistent with the expected load distribution in the cycloidal stage of a rotary vector reducer under the specified output torque. Analyzing these force patterns confirms proper load sharing among the needle pins and validates the contact modeling approach.
Conclusion
This work demonstrates a complete digital workflow for the design and analysis of an industrial robot rotary vector reducer. The process begins with parametric 3D modeling using advanced CAD software, where the complex cycloid disc profile is accurately generated using derived mathematical equations. The subsequent virtual assembly allows for visualization, interference checking, and validation of the assembly sequence. Finally, multi-body dynamic simulation of the virtual prototype provides crucial insights into the system’s kinematic performance (speeds, ratio) and dynamic behavior (mesh forces), all before any physical part is manufactured.
The close agreement between simulation results and theoretical calculations validates the correctness of the digital model and the virtual prototyping methodology. Employing this integrated digital approach enables the early detection and correction of design flaws, optimization of gear profiles and modifications, and prediction of dynamic performance. This significantly reduces development time and cost, improves product quality and reliability, and is a vital strategy for achieving technological independence in the manufacture of high-performance precision components like the rotary vector reducer.