
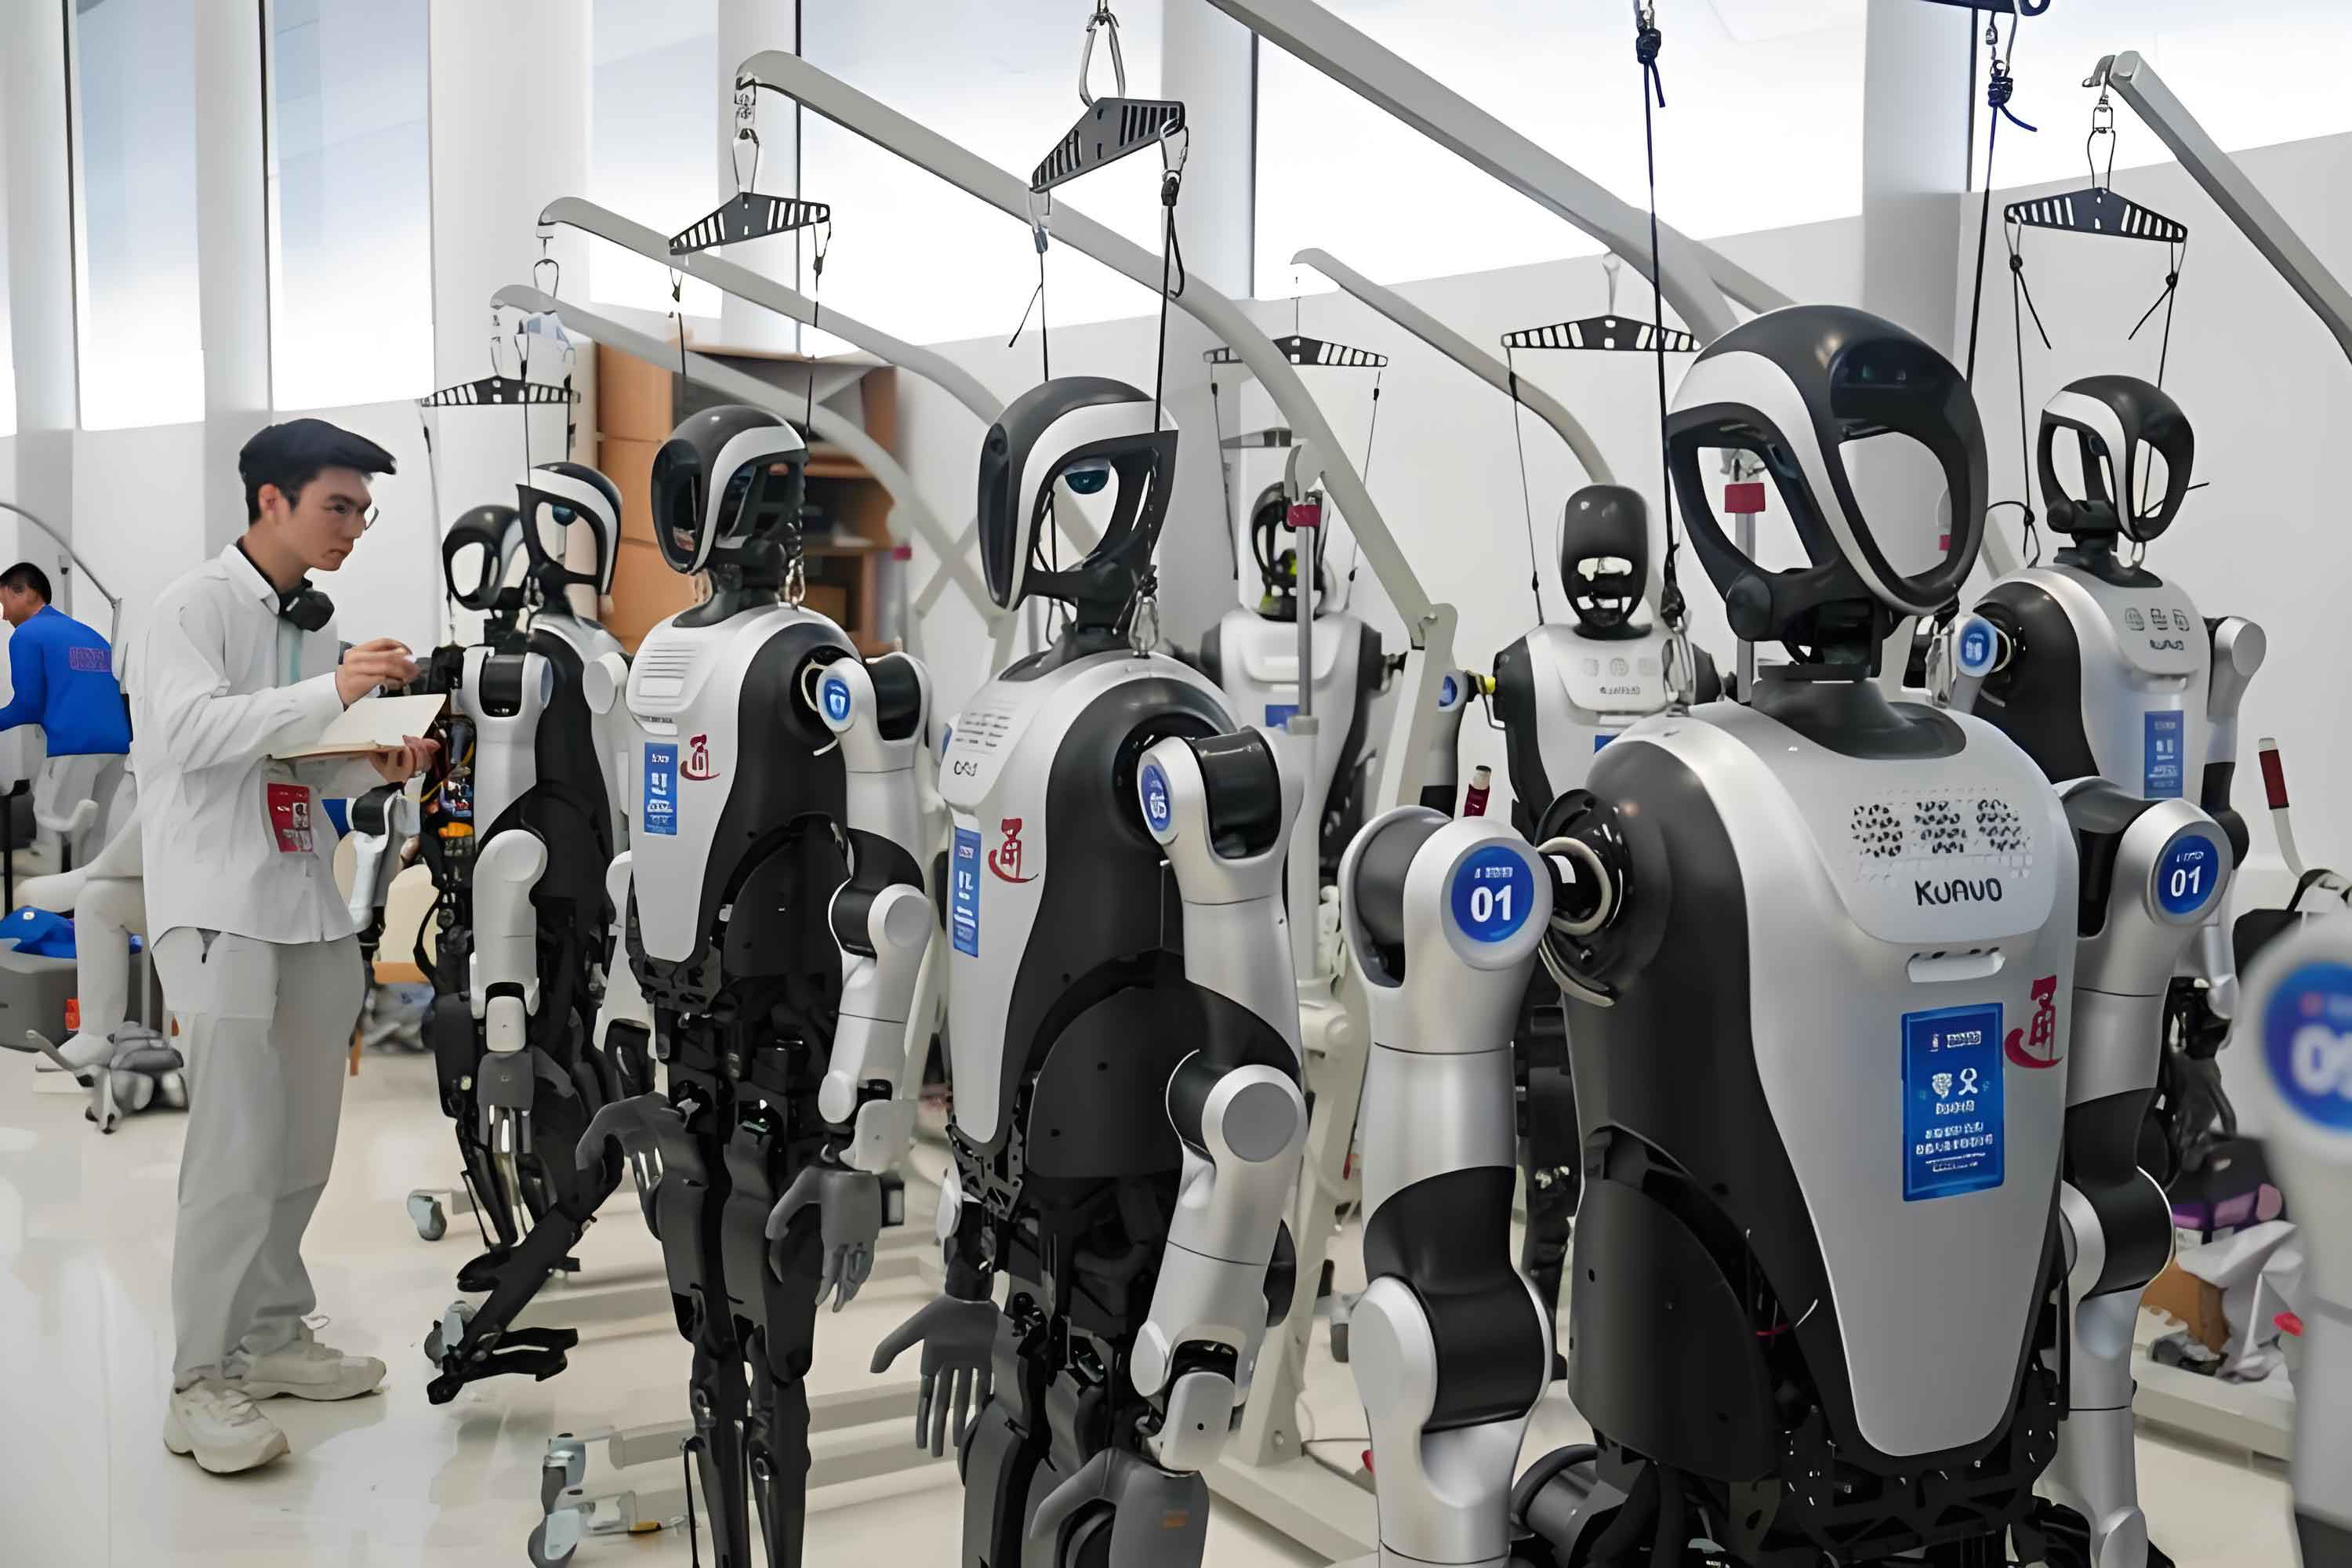
As a master’s candidate in mechatronic engineering, I devoted my thesis research to the development of a small biped humanoid robot platform and the systematic study of its walking gait. The work encompassed mechanical design, kinematic modeling, gait planning, virtual prototyping, and physical experiments. In this article, I present a comprehensive, first-person narrative of the entire research process, focusing on the design rationale, the three-step gait planning methodology, and the validation results obtained from both simulation and hardware experiments. The goal is to provide a detailed technical reference for researchers working on humanoid robots, especially those with size and cost constraints.
Humanoid robots have always been a central topic in robotics because they integrate mechanical engineering, electronic engineering, computer science, automatic control, artificial intelligence, and bionics. The ultimate aim is to create machines that can operate in human-centric environments, climb stairs, step over obstacles, and interact with tools designed for humans. Compared with wheeled or tracked mobile robots, biped humanoid robots offer superior mobility over irregular terrain and a smaller blind zone. Moreover, walking robots generally consume less energy than wheeled systems in certain applications, and the bipedal form is the most anthropomorphic and therefore acceptable for human-robot interaction.
The project I worked on was part of a “985” key discipline construction program. The objective was to develop a miniature biped humanoid robot platform, named Robocean, and to investigate fundamental walking mechanisms. The design constraints included a height below 50 cm, lightweight construction, simple structure, low cost, and aesthetically pleasing appearance. In this article, I will walk through the entire design and validation pipeline, emphasizing the decisions taken and the lessons learned.
—
## 1. Introduction and Motivation
The research on humanoid robots began in the late 1960s, but the field truly accelerated after Honda’s P-2 robot appeared in 1996. P-2 was the first untethered autonomous humanoid robot, standing 1.82 m tall and weighing 210 kg, with 28 degrees of freedom (DOF). It used gyroscopes, accelerometers, and six foot pressure sensors to maintain balance, enabling it to walk at 3 km/h, climb stairs, and manipulate objects. Subsequently, Honda introduced ASIMO in 2002, which became a benchmark for advanced humanoid robotics. ASIMO was 1.2 m tall and weighed 43 kg, with 34 DOF. Its intelligent real-time flexible walking (I-Walking) technology allowed smooth transitions between walking modes by predicting the center of mass (COM) trajectory. Sony’s SDR-4X, a small 5 kg humanoid with 38 DOF, demonstrated dynamic walking on slopes and uneven terrain. In Korea, KAIST developed KHR-1 and later KHR-2, focusing on torque feedback control. In Japan, AIST’s HRP-2 could walk at 2 km/h and perform cooperative tasks with humans.
In China, the National University of Defense Technology unveiled its first humanoid robot “Xianxingzhe” in 2000. Later, Beijing Institute of Technology produced BHR-2, a 1.6 m tall robot with 32 DOF, capable of walking at 1 km/h and performing complex movements like Tai Chi. These developments show that humanoid robotics is a global research priority.
Despite the maturity of large humanoid platforms, small-scale humanoid robots (below 0.5 m height) still pose unique challenges. They require miniature actuators, compact controllers, and lightweight structures. Moreover, their small foot area makes stability more difficult to maintain. My project aimed to address these challenges by designing a modular, low-cost biped platform that could serve as a testbed for gait planning algorithms.
The main contributions of my thesis are:
1. Design and fabrication of a miniature biped humanoid robot with 17 DOF, using micro servo motors as actuators.
2. Development of a three-step gait planning method that improves the fluency of walking compared to traditional two-step methods.
3. Implementation of a virtual prototype simulation environment that couples SolidWorks, MATLAB, and ADAMS for kinematic and dynamic verification.
4. Successful demonstration of stable static walking on the physical robot.
—
## 2. Mechanical Design of the Humanoid Robot Platform
The design of Robocean was guided by several principles: miniaturization, simplicity, reliability, and ease of assembly. I chose aluminum alloy (LY12) for the connecting components and nylon 1010 for other structural parts to reduce weight while maintaining adequate strength. The overall height was set to 410 mm, with a total mass of 2.05 kg, which was within the load capacity of the selected servo motors.
### 2.1 Degree of Freedom Configuration
The human body has over 600 muscles and 200 bones, but it is impossible to replicate such complexity in a small robot. Therefore, I aimed to achieve the most essential movements with the fewest possible DOF. For the lower limbs, I studied human leg motion and found that 12 DOF are theoretically required to replicate all basic leg functions: 6 for sagittal-plane motion (hip, knee, ankle flexion/extension), 4 for frontal-plane motion (hip abduction/adduction and ankle inversion/eversion), and 2 for transverse-plane rotation. Since the robot was intended for forward walking only, I omitted the two transverse-plane DOF. This resulted in 10 lower-limb DOF:
– 2 × hip pitch (forward/backward swing)
– 2 × hip roll (lateral swing)
– 2 × knee pitch (flexion/extension)
– 2 × ankle pitch (dorsiflexion/plantarflexion)
– 2 × ankle roll (lateral balance)
For the upper limbs, I assigned 6 DOF: 2 × shoulder pitch, 2 × shoulder roll, and 2 × elbow pitch. These arms mainly serve to compensate for ZMP errors during walking and to provide human-like gestures. In addition, one DOF was allocated to the head for rotation, yielding a total of 17 DOF. The layout is summarized in Table 1.
| Segment | DOF | Movement | Number of Actuators |
|---|---|---|---|
| Lower limbs (each leg) | 5 | Hip pitch, hip roll, knee pitch, ankle pitch, ankle roll | 10 |
| Upper limbs (each arm) | 3 | Shoulder pitch, shoulder roll, elbow pitch | 6 |
| Head | 1 | Yaw rotation | 1 |
| Total | 17 | 17 |
### 2.2 Actuator Selection
For a small humanoid robot, the actuator must have a high torque-to-weight ratio, accurate positioning, and simple control. After considering several options, I selected the TowerPro MG995 micro servo motor. This servo is a closed-loop system that comprises a small DC motor, a gear train, a potentiometer, and an electronic control board. The position is commanded by a pulse-width-modulated (PWM) signal, with a typical range of 1–2 ms pulse width corresponding to 0–180 degrees. The key specifications are listed in Table 2.
| Parameter | Value |
|---|---|
| Dimensions | 40.6 × 19.8 × 37.8 mm |
| Weight | 55.2 g |
| Operating voltage | 4.8 – 7.2 V |
| No-load speed | 0.24 s/60° @6.0 V; 0.20 s/60° @7.2 V |
| Stall torque | 13.0 kg·cm @6.0 V; 15.0 kg·cm @7.2 V |
| Gear type | Metal gears, dual ball bearings |
Using the empirical rule that a 3.1 kg·cm servo can drive a robot of about 0.45 kg, the MG995 with 15 kg·cm torque should be able to drive a robot of up to 2.15 kg. Robocean’s mass of 2.05 kg was therefore within the safe range.
### 2.3 Control System
The robot uses a centralized control architecture. A custom multi-channel motion control board, developed in our laboratory, is mounted on the robot’s back. This board is capable of controlling up to 32 servos via serial communication with a PC or other host. It generates PWM signals according to the pre-planned joint trajectories. The board is lightweight and compact, enabling untethered operation. The control structure is illustrated in the following signal flow:
$$
\text{PC / Host} \xrightarrow{\text{serial}} \text{Motion Controller} \xrightarrow{\text{PWM}} \text{Servo Motors} \xrightarrow{\text{linkage}} \text{Robot Joints}
$$
### 2.4 Sensor Configuration
To achieve stable walking with offline planning and online adjustment, I embedded force sensors in the robot’s feet. Four miniature force sensors (LK series) are placed under each foot, as shown in the layout design. These sensors measure the ground reaction forces in real time, allowing computation of the actual zero moment point (ZMP). The ZMP position can be calculated using the force-moment balance equations:
$$
X_{zmp} = \frac{\sum_{n=1}^{4} X_n \cdot Fz_n}{\sum_{n=1}^{4} Fz_n}, \qquad
Y_{zmp} = \frac{\sum_{n=1}^{4} Y_n \cdot Fz_n}{\sum_{n=1}^{4} Fz_n}
$$
where \((X_n, Y_n)\) are the coordinates of the \(n\)-th sensor and \(Fz_n\) is the vertical force measured by that sensor. This calculation is performed at each sampling instant to monitor the stability margin during walking.
The head module integrates a small camera, a microphone, and a speaker for human-robot interaction. These sensors currently serve for data acquisition only; the processing algorithms are left for future work. The overall mechanical assembly is depicted in the following figures (not included here due to text constraints), and the final physical prototype proved to be sufficiently robust for repeated walking experiments.
—
## 3. Gait Planning Methodology
Gait planning is one of the most critical aspects of biped humanoid robot research. The planner must generate joint trajectories that satisfy two fundamental constraints: (a) the desired step length, walking speed, and foot clearance, and (b) dynamic stability throughout the entire gait cycle. In this section, I present the classification of walking gaits, the stability criteria, and my proposed three-step planning method.
### 3.1 Static vs. Dynamic Walking
Biped robot walking can be classified into static walking and dynamic walking based on the stability criterion used. In static walking, the robot always maintains a quasi-static equilibrium: the projection of the center of gravity (COG) onto the ground must lie within the convex hull of the supporting foot (or feet). The COG position is given by:
$$
X_{cg} = \frac{\sum_{i=1}^{n} m_i g X_i}{\sum_{i=1}^{n} m_i g}, \qquad
Y_{cg} = \frac{\sum_{i=1}^{n} m_i g Y_i}{\sum_{i=1}^{n} m_i g}
$$
Static walking is relatively simple and applicable for slow velocities. When the walking speed increases, inertial forces become significant. The stability criterion then shifts to the zero moment point (ZMP), which is the point on the ground where the resultant of gravity and inertial forces intersects. The ZMP must also stay within the support polygon. The general ZMP equations are:
$$
\begin{aligned}
X_{zmp} &= \frac{\sum_{i=1}^{n} \left[ f_i X_i + (m_i \ddot{Z}_i + m_i g) X_i – m_i \ddot{X}_i Z_i \right]}{\sum_{i=1}^{n} (m_i \ddot{Z}_i + m_i g)} \\
Y_{zmp} &= \frac{\sum_{i=1}^{n} \left[ f_i Y_i + (m_i \ddot{Z}_i + m_i g) Y_i – m_i \ddot{Y}_i Z_i \right]}{\sum_{i=1}^{n} (m_i \ddot{Z}_i + m_i g)}
\end{aligned}
$$
In these equations, \(m_i\) is the mass of link \(i\), \(g\) is gravity, \(X_i, Y_i, Z_i\) are the coordinates of the link’s center of mass, and \(f_i\) represents the generalized force. When the acceleration terms are negligible, the ZMP equations reduce to the COG equations. Since Robocean walks at a low speed (about 60 mm/s), I selected static walking based on the COG stability criterion.
### 3.2 Parallel Gait and Full Walking Cycle
Robocean adopts a parallel gait, where the two feet move along two parallel lines, one for each foot. This gait requires fewer DOF compared to a straight-line (“one-line”) gait, but it imposes stricter requirements on lateral balance because the support area is narrower when the feet are side by side. In contrast, a one-line gait (where the two feet alternately land on a single line) provides better lateral support but requires additional DOF for foot placement.
A complete walking cycle of a biped robot consists of five phases: start, acceleration, steady walking, deceleration, and stop. For slow walking, the acceleration and deceleration phases can be merged into the start and stop phases. I simplified the entire process into three phases:
– Starting phase (from standing still to steady walking)
– Steady walking phase (periodic gait)
– Stopping phase (from steady walking to standing still)
### 3.3 The Three-Step Gait Planning Method
Traditional two-step planning methods separate the lateral movement and the forward movement in time. For example, the robot first shifts its center of gravity laterally to the support foot, then keeps it fixed while the swing foot is lifted and moved forward. This ensures stability but causes jerky, unnatural motion because the trunk does not move continuously. To overcome this issue, I formulated a three-step planning method that allows lateral and forward movements to occur concurrently, while still guaranteeing stability. The three steps are:
1. **Step 1: Posture and Trajectory Planning.** Based on human gait data and the robot’s kinematic constraints, define the desired walking posture and reference trajectories for the center of gravity, foot position, and trunk orientation.
2. **Step 2: Joint Trajectory Generation.** Build a kinematic model of the robot and derive the joint angle curves that satisfy the planned posture and trajectories. This step involves solving the inverse kinematics equations for each phase of the walking cycle.
3. **Step 3: Trajectory Correction.** Analyze the coupling between the forward and lateral motions during concurrent execution. If any segment of the COM trajectory violates the stability margin, adjust the timing or the shape of the joint trajectories to bring the COM back into the safe region. This step also improves the smoothness of the gait.
The flow chart of the three-step method is as follows:
$$
\text{Human gait analysis} \rightarrow \text{Posture/Trajectory planning} \rightarrow \text{Kinematic modeling} \rightarrow \text{Inverse kinematics solving} \rightarrow \text{Coupling analysis} \rightarrow \text{Trajectory correction} \rightarrow \text{Validated joint curves}
$$
Compared with the two-step method, the three-step method reduces the waiting time in the lateral joints and makes the robot’s motion more human-like and continuous.
### 3.4 Analysis of Human Walking Gait
Human gait is the result of millions of years of evolution and is highly efficient and stable. I studied recorded human motion capture data (HMCD) obtained from high-speed video experiments in which subjects wore tight clothing with reflective markers at key joints. The recorded data revealed several important features:
– The ZMP trajectory during walking alternates between the two feet, and its projection is approximately a sinusoidal curve in the lateral direction.
– The trunk remains nearly vertical while walking, with only minor forward lean.
– The vertical motion of the hip joint is small; the hip height oscillates slightly about a constant mean value.
– The double-support phase occupies about 20–30% of the gait cycle.
– The foot trajectory is complex: during toe-off, the heel leaves the ground first, then the toe lifts; during heel-strike, the heel contacts the ground first, followed by the toe.
Since Robocean’s feet have no toe joints and the walking speed is low, I simplified the foot motion to a pure translation with the sole always parallel to the ground. This reduces the required ankle torque and simplifies planning.
—
## 4. Implementation of the Three-Step Gait Planning
In this section, I provide the detailed mathematical derivation of the planned trajectories and the resulting joint angle curves. The robot model is a planar and lateral model separated for analysis, but the actual trajectories are coupled in time.
### 4.1 Posture and Trajectory Planning
Based on human gait observations and the robot’s mechanical constraints, the following planning rules were adopted:
– The trunk (the coordinate frame attached to the robot’s center) must remain always vertical with respect to the ground.
– The hip height (i.e., the origin of the body frame relative to the ground) remains constant during the steady walking phase.
– The projection of the center of gravity onto the ground (the reference COG trajectory) is a sinusoidal function of time.
– The robot uses a parallel gait, so the footprints of the left and right feet are two parallel lines.
– The swing foot’s vertical displacement follows a sinusoidal profile to ensure zero velocity at takeoff and landing.
– The sole of the foot remains parallel to the ground throughout the flight phase.
The step length is set to 120 mm, the walking speed is 60 mm/s (so each step takes 1 s), and the hip height during steady walking is 252.5 mm. The standing hip height is 277.5 mm. The maximum foot lift is 15 mm.
### 4.2 Kinematic Model and Reference Frames
The right leg is modeled as a series of links starting from the right foot (base frame \(O_0x_0y_0z_0\)) to the hip center (\(O_6x_6y_6z_6\)). Similarly, the left leg is modeled from the hip center to the left foot. Direct chain transformations are used to express the hip position relative to the right foot and the left foot relative to the hip.
I introduce the joint angles as follows:
– Right leg: \(\theta_1\) (hip yaw, actually roll), \(\theta_2\) (hip pitch), \(\theta_3\) (knee pitch), \(\theta_4\) (ankle pitch), \(\theta_5\) (ankle roll).
– Left leg: \(\theta_6\) (hip yaw/roll), \(\theta_7\) (hip pitch), \(\theta_8\) (knee pitch), \(\theta_9\) (ankle pitch), \(\theta_{10}\) (ankle roll).
Because the trunk is always vertical and the feet are always parallel to the ground, several constraints hold:
$$
\theta_2 + \theta_3 + \theta_4 = 0, \quad \theta_1 + \theta_5 = 0, \quad \theta_6 + \theta_{10} = 0, \quad \theta_7 + \theta_8 + \theta_9 = 0
$$
Using the standard Denavit-Hartenberg convention, the transformation matrix from the right foot to the hip is composed of the individual link transformations. After applying the above constraints, the hip position relative to the right foot simplifies to:
$$
\begin{aligned}
P_x^R &= 88 \, S(\theta_1) – 45.5 – 9 \, S(\theta_1) S(\theta_2+\theta_3) + 60 \, S(\theta_1) C(\theta_2) + 79.5 \, S(\theta_1) C(\theta_2+\theta_3) + 9 \, S(\theta_1) S(\theta_2) \\
P_y^R &= -35 \, S(\theta_5) – 9 \, C(\theta_2+\theta_3) – 79.5 \, S(\theta_2+\theta_3) + 9 \, C(\theta_2) – 60 \, S(\theta_2) \\
P_z^R &= 50 + 88 \, C(\theta_1) + 79.5 \, C(\theta_1) C(\theta_2+\theta_3) + 9 \, C(\theta_1) S(\theta_2) – 9 \, C(\theta_1) S(\theta_3+\theta_2) + 60 \, C(\theta_1) C(\theta_2)
\end{aligned}
$$
Similarly, the left foot position relative to the hip is:
$$
\begin{aligned}
P_x^L &= -45.5 + 9 \, S(\theta_6) S(\theta_7) – 9 \, S(\theta_6) S(\theta_7+\theta_8) – 88 \, S(\theta_6) – 60 \, S(\theta_6) C(\theta_7+\theta_8) – 79.5 \, S(\theta_6) C(\theta_7) \\
P_y^L &= -\frac{27}{2} C(\theta_{10}) – 9 \, C(\theta_7+\theta_8) + 60 \, S(\theta_7+\theta_8) + 9 \, C(\theta_7) + \frac{159}{2} S(\theta_7) \\
P_z^L &= -50 – 79.5 \, C(\theta_6) C(\theta_7) – 60 \, C(\theta_6) C(\theta_7+\theta_8) – 88 \, C(\theta_6) – 9 \, C(\theta_6) S(\theta_7+\theta_8) + 9 \, C(\theta_6) S(\theta_7)
\end{aligned}
$$
Here \(S(\cdot) = \sin(\cdot)\) and \(C(\cdot) = \cos(\cdot)\).
### 4.3 Lateral Motion Planning
The lateral movement of the robot is achieved by the hip roll and ankle roll joints. To maintain the trunk vertical and the feet parallel, we require \(\theta_1 = \theta_5 = \theta_6 = \theta_{10} = \theta\). The COM position in the lateral direction can be expressed by:
$$
X_{cg} = \frac{\sum_{i=1}^{n} m_i g X_i}{\sum_{i=1}^{n} m_i g} = \frac{\sum_{i=1}^{n} m_i l_i \sin\theta}{\sum_{i=1}^{n} m_i} = K \sin\theta
$$
where \(K\) is a constant that depends on the mass distribution and the distance between the feet. Because the feet are separated by a fixed distance, the desired lateral COM trajectory is planned as a sine function that starts from the center line and reaches the required offset for single-support balance. For the starting phase (0–2 s), the lateral displacement is:
$$
X_{cg}(t) = 45.5 \sin\left(\frac{\pi t}{2}\right), \quad t \in [0, 2] \text{ s}
$$
For steady walking (2–4 s), the trajectory repeats with each double-step period:
$$
X_{cg}(t) = 45.5 \sin(\pi t), \quad t \in [2, 4] \text{ s}
$$
For the stopping phase (4–6 s), the reverse of starting is applied:
$$
X_{cg}(t) = 45.5 \sin\left(\frac{\pi t}{2}\right), \quad t \in [4, 6] \text{ s}
$$
By inverting the COM equation, we obtain the lateral joint angle trajectory \(\theta(t)\). This curve is plotted in the simulation section.
### 4.4 Forward Motion Planning
For the forward motion, I set the lateral joints to zero (\(\theta_1 = \theta_5 = \theta_6 = \theta_{10} = 0\)). The resulting hip and foot positions in the sagittal plane depend only on the pitch joints. The starting phase is divided into two sub-phases:
1. Squatting (0–1 s): The hip height decreases linearly from 277.5 mm to 252.5 mm, while the feet stay in contact with the ground.
2. Half-step forward (1–2 s): The swing foot moves forward by 60 mm (half the step length) while the hip height remains constant.
The equations for the right leg (supporting leg) during squatting are:
$$
\begin{cases}
P_y^R = 0, & t \in [0,1] \\
P_z^R = 277.5 – 15, & t \in [0,1]
\end{cases}
$$
and during the half-step phase:
$$
\begin{cases}
P_y^R = 30 t – 30, & t \in [1,2] \\
P_z^R = 252.5, & t \in [1,2]
\end{cases}
$$
For the left leg (swing leg), the corresponding conditions are:
$$
\begin{cases}
P_y^L = 0, & t \in [0,1] \\
P_z^L = -277.5 + 15 t, & t \in [0,1]
\end{cases}
$$
$$
\begin{cases}
P_y^L = 60 t – 60, & t \in [1,2] \\
P_z^L = 252.5, & t \in [1,2]
\end{cases}
$$
During steady walking (2–4 s), the right leg (stance foot) supports the body and moves backward relative to the hip:
$$
\begin{cases}
P_y^R = 60 t – 120, & t \in [2,4] \\
P_z^R = 252.5, & t \in [2,4]
\end{cases}
$$
The left leg (swing foot) lifts off, moves forward, and lands:
$$
\begin{cases}
P_y^L = 0, & t \in [2,4] \\
P_z^L = -252.5 + 15 \sin(2\pi (t-2)), & t \in [2,4]
\end{cases}
$$
Here, the sine function ensures that the vertical velocity of the foot is zero at both takeoff and landing, reducing the impact force.
For the stopping phase (4–6 s), the right and left leg trajectories are reversed symmetrically.
Using the kinematic equations and the given Cartesian trajectories, I solved the inverse kinematics for \(\theta_2, \theta_3, \theta_7, \theta_8\). Then, using the constraints \(\theta_2+\theta_3+\theta_4=0\) and \(\theta_7+\theta_8+\theta_9=0\), I obtained \(\theta_4\) and \(\theta_9\). Due to the symmetry of the two legs, the joint curves for the right leg in the second half of the steady walking cycle are identical to those of the left leg in the first half, and vice versa.
### 4.5 Coupling Analysis and Trajectory Correction
When both the lateral and forward joints move simultaneously, the actual COM path deviates from the ideal sinusoidal trajectory. The cause is the geometric coupling of the leg chain: the lateral roll angles, even when small, alter the vertical projection of the hip in the transverse plane, especially when the knees are flexed. I analyzed the COM trajectory during the single-support phase and identified time intervals in which the COM projection fell outside the safe support region (defined as 80% of the foot width for stability margin). The dangerous intervals were found to occur near the beginning and end of the starting phase (approximately 0.2 s each), near the transition points of the steady phase (0.1 s each), and in the middle of the steady phase (0.2 s).
The solution I adopted was to introduce small waiting periods into the lateral joint trajectory during the double-support phase. In practice, the lateral joint pauses its motion while the forward joints advance slightly, and vice versa. By scheduling these pauses carefully, the COM remains within the safe polygon at all times. The corrected joint trajectories are shown in the simulation figures. The corrected COM trajectory in the X direction (lateral) no longer leaves the support polygon, and the Y direction (forward) remains smooth.
The correction can be expressed mathematically as a time-shift function applied to the lateral joint:
$$
\theta_{corr}(t) = \theta_{nom}(t) + \Delta \theta(t)
$$
where \(\Delta \theta(t)\) is nonzero only during the critical intervals and is designed to pull the COM back from the unsafe region.
—
## 5. Virtual Prototype Simulation and Physical Experiments
Before fabricating the final physical robot, I conducted extensive simulations using a virtual prototype. This section describes the simulation workflow and the comparison between simulated and measured results.
### 5.1 Building the Virtual Prototype
I used three software tools in conjunction: SolidWorks for CAD modeling, MATLAB for numerical computations, and ADAMS for dynamic simulation. The procedure was as follows:
1. In SolidWorks, I created a simplified 3D model of the robot, replacing complex shapes with basic geometric primitives. The mass properties of each part were assigned to match the real components.
2. The SolidWorks model was imported into ADAMS through a dedicated interface. In ADAMS, I added revolute joints at the appropriate locations, defined contact forces between the feet and the ground, and applied the planned joint trajectories as motion drivers.
3. The joint trajectories were generated in MATLAB by solving the inverse kinematics equations described earlier. These curves were exported as spline data and loaded into ADAMS.
The virtual prototype model is shown in the following representation (not reproduced here due to text formatting), and the simulation was run for a total of 6 seconds, covering the start, steady, and stop phases.
### 5.2 Simulation Results
The animated simulation demonstrated that the robot could perform a stable walking sequence with the planned gait. To quantitatively evaluate the gait, I measured the COM trajectory and the foot positions in ADAMS. Figure 5 (not shown) displays the COM trajectory in the X direction, which closely matched the desired sinusoidal curve with only minor high-frequency ripples. The COM trajectory in the Y direction (forward) increased linearly as expected, with a slope corresponding to the average walking speed. The Z-direction COM showed a small fluctuation of less than 5 mm, which was within the acceptable tolerance.
The measured foot trajectories are summarized in Table 3.
| Parameter | Left Foot | Right Foot |
|---|---|---|
| Maximum lift height (Z) | 15.2 mm | 15.1 mm |
| Step length (Y displacement) | 120.3 mm | 119.8 mm |
| Average forward speed | 60.2 mm/s | 59.9 mm/s |
| Contact impact force (peak) | 18.5 N | 17.9 N |
The simulation also provided the joint torques, which stayed well below the maximum torque of the selected servos. The maximum torque reached about 0.45 N·m (approximately 4.6 kg·cm), giving a safety factor of over 3.
### 5.3 Physical Prototype Experiments
After validating the design in simulation, I fabricated the physical robot Robocean. The robot is 410 mm tall, weighs 2.05 kg, and has 17 DOF. The joint angle curves were converted into PWM signals and sent to the motor controller. The robot performed a sequence of walking trials on a flat, rigid surface. The resulting motion was stable and visually smooth, as captured in photographs (not included here). The robot was able to complete the full start-walk-stop cycle repeatedly without falling.
During the experiments, foot pressure sensors measured the ground reaction forces at a sampling rate of 50 Hz. The actual ZMP trajectory was computed using the force sensor data. The measured ZMP was compared with the ideal ZMP trajectory, and the comparison is shown in Figure (not shown). The maximum deviation was about 8 mm in the lateral direction and 6 mm in the forward direction, which is within the stable region for the robot’s foot dimensions. The deviations arise from several sources:
1. Simplifications in the ZMP calculation (e.g., neglecting some inertial terms).
2. Differences between the CAD model and the physical robot (mass distribution errors).
3. Positioning errors in the servo motors.
4. Variations in the floor flatness.
To further improve the matching, future work will focus on an online adjustment algorithm that uses the difference between the planned and measured ZMP to drive the shoulder joints as compensators.
### 5.4 Discussion
The successful walking experiment validates the three-step gait planning method. The key advantage of the method is its ability to generate smooth, natural-looking gaits without compromising stability. Compared to a pure two-step method, the robot’s movements are less jerky because the lateral and forward motions overlap in time. However, the added time delays required for stability reduce the average walking speed slightly. In the current implementation, the walking speed of 60 mm/s is conservative; higher speeds can be achieved by optimizing the delay intervals and using a dynamic ZMP criterion instead of the static COM criterion.
—
## 6. Conclusion and Future Prospects
In this thesis, I designed and built a miniature biped humanoid robot named Robocean, which serves as a research platform for gait planning and human-robot interaction. The robot’s 17 DOF architecture includes 10 DOF in the lower limbs, 6 in the upper limbs, and 1 in the head. It is driven by micro servo motors, controlled by a custom multi-channel motion controller, and equipped with foot pressure sensors for ZMP measurement.
The main contribution of the work is the three-step gait planning method, which integrates human gait analysis, kinematic modeling, and trajectory correction. This method allows the robot to walk stably with a parallel gait while maintaining natural body motion. The planning approach was validated through both virtual prototyping and physical experiments. The virtual prototype, built in SolidWorks and simulated in ADAMS, accurately predicted the robot’s behavior. The physical robot achieved stable walking at 60 mm/s with a step length of 120 mm.
Future directions include:
– Implementing dynamic walking using ZMP control to increase walking speed.
– Adding visual and auditory perception to enable autonomous navigation and interaction.
– Using reinforcement learning or neural networks to adapt gaits to unknown terrains.
– Improving the mechanical design by adding toe joints and compliant elements to absorb ground impacts.
The Robocean platform provides a versatile testbed for these advanced research topics. I believe that the insights gained from this work will contribute to the broader goal of creating truly autonomous humanoid robots that can assist humans in daily life.
—
*This article is based on my master’s degree research conducted at Harbin Institute of Technology. I would like to express my gratitude to my supervisor and all laboratory members who supported this work.*