
In my exploration of robotics, I have focused on developing a hexapod bionic robot that mimics the locomotion of insects, particularly cockroaches. This bionic robot leverages the Arduino platform for control, integrating servo motors and sensor systems to achieve stable and adaptive movement. The design emphasizes mechanical symmetry, efficient gait patterns, and robust sensing capabilities, all aimed at enhancing the autonomy and versatility of such bionic robots in various applications. Throughout this project, I have delved into the principles of biomechanics, control theory, and sensor fusion to create a functional prototype that demonstrates the potential of bionic robots in real-world scenarios.
The core inspiration for this bionic robot comes from biological systems, where hexapod organisms exhibit remarkable stability and agility. By studying their anatomy and movement, I have designed a mechanical structure that replicates key features, enabling the robot to navigate complex environments. This bionic robot is not just a mechanical replica; it embodies the integration of electronics and software to mimic intelligent behavior. The use of Arduino as the main controller allows for flexibility in programming and real-time adjustments, making it an ideal platform for experimenting with bionic robot designs. In this article, I will detail the design process, from mechanical assembly to control algorithms, highlighting how each component contributes to the overall functionality of the bionic robot.
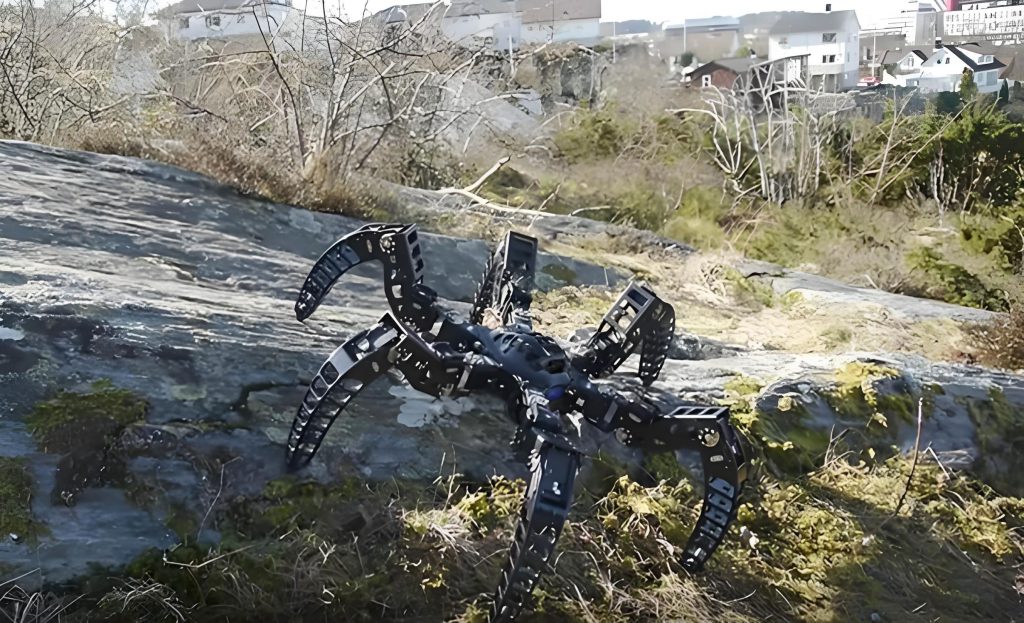
Mechanical design is fundamental to the performance of any bionic robot. For my hexapod bionic robot, I adopted a symmetric structure consisting of a central carrier plate, servo mounting plates, and six legs. Each leg is modeled after insect limbs, with three joints: the coxa (thigh), femur (mid-leg), and tibia (shin). Servo motors are attached at these joints to provide actuation. Specifically, the coxa servo enables forward and backward swinging, the femur servo controls vertical lifting of the leg, and the tibia servo allows for inward and outward flexion. This configuration grants the bionic robot a wide range of motion, essential for adapting to uneven terrain. The mechanical parameters are summarized in the table below, which outlines key dimensions and servo specifications.
| Component | Parameter | Value | Unit |
|---|---|---|---|
| Leg Joint | Coxa Length | 50 | mm |
| Femur Length | 60 | mm | |
| Tibia Length | 40 | mm | |
| Servo Motor | Torque (Stall) | 2.5 | kg·cm |
| Operating Voltage | 4.8 – 6.0 | V | |
| Carrier Plate | Dimensions | 150 x 100 | mm |
To analyze the kinematics of this bionic robot, I derived equations for leg movement. The position of the foot tip relative to the body can be expressed using forward kinematics. Let $\theta_c$, $\theta_f$, and $\theta_t$ represent the angles of the coxa, femur, and tibia servos, respectively. The coordinates $(x, y, z)$ of the foot tip in a leg-fixed frame are given by:
$$ x = L_c \cos(\theta_c) + L_f \cos(\theta_c + \theta_f) + L_t \cos(\theta_c + \theta_f + \theta_t) $$
$$ y = L_c \sin(\theta_c) + L_f \sin(\theta_c + \theta_f) + L_t \sin(\theta_c + \theta_f + \theta_t) $$
$$ z = 0 \text{ (for planar motion, but vertical adjustment comes from femur servo)} $$
Here, $L_c$, $L_f$, and $L_t$ are the lengths of the coxa, femur, and tibia segments. For vertical movement, the z-coordinate is modified by the femur servo’s angle, typically involving a separate offset. This kinematic model is crucial for gait planning in the bionic robot, ensuring precise foot placement during locomotion.
Gait pattern is a critical aspect of bionic robot mobility. I implemented a tripod gait, which is common among hexapod insects. In this gait, the legs are grouped into two sets of three: one set includes the front and rear legs on one side and the middle leg on the opposite side, forming a stable triangular support. While one tripod is on the ground pushing backward, the other tripod is lifted and swung forward. This alternation creates continuous motion. The gait cycle can be described mathematically. Let $T$ be the gait period, and $\phi_i$ be the phase offset for leg $i$ (where $i = 1$ to $6$). For a tripod gait, the phases are:
$$ \phi_1 = 0, \phi_2 = 0.5, \phi_3 = 0, \phi_4 = 0.5, \phi_5 = 0, \phi_6 = 0.5 $$
expressed in fractions of $T$. The duty factor $\beta$, defined as the fraction of time a leg is in the stance phase, is typically 0.5 for a tripod gait. The foot trajectory during the swing phase can be modeled using polynomial equations to ensure smooth movement. For instance, the vertical displacement $z(t)$ during swing might follow a parabolic path:
$$ z(t) = h \left(1 – \left(\frac{2t}{T_s} – 1\right)^2\right) $$
where $h$ is the maximum lift height and $T_s$ is the swing phase duration. This approach minimizes jerks in the bionic robot’s motion, enhancing stability.
The control system for this bionic robot is centered on an Arduino Nano board, chosen for its compact size and sufficient I/O capabilities. The Arduino Nano features an ATmega328 microcontroller with 14 digital I/O pins, 8 analog inputs, and a 16 MHz crystal oscillator. It serves as the main processor, handling sensor data and sending commands to a 24-channel servo control board, which drives the 18 servo motors (3 per leg). The servo control board uses PWM signals to adjust servo angles. The relationship between PWM duty cycle and angle is linear for standard servos. If the PWM period is $P$ and the pulse width for a given angle $\theta$ is $w$, then:
$$ w = w_{\text{min}} + \frac{\theta – \theta_{\text{min}}}{\theta_{\text{max}} – \theta_{\text{min}}} (w_{\text{max}} – w_{\text{min}}) $$
where $w_{\text{min}}$ and $w_{\text{max}}$ correspond to the pulse widths at minimum and maximum angles, typically 1 ms and 2 ms for a 180° servo. This precise control allows the bionic robot to execute complex movements reliably.
Sensing is integral to the autonomy of this bionic robot. I integrated a combination of ultrasonic and infrared sensors to enable obstacle avoidance and line following. The ultrasonic sensors, HC-SR04 modules, measure distances from 2 cm to 400 cm with an accuracy of 2 mm. They operate by emitting a sound wave and calculating the time delay of the echo. The distance $d$ to an obstacle is given by:
$$ d = \frac{v \cdot \Delta t}{2} $$
where $v$ is the speed of sound (approximately 340 m/s at room temperature) and $\Delta t$ is the time delay. For the infrared sensors, I used GP2D12 modules for line tracking. They detect reflected infrared light, outputting a voltage inversely proportional to distance. The sensor circuit includes components like amplifiers and regulators to ensure stable readings. To minimize blind spots, I mounted three ultrasonic sensors symmetrically on the robot’s front, with infrared sensors placed between them. This multi-sensor fusion enhances the bionic robot’s environmental perception, as summarized in the table below.
| Sensor Type | Model | Range | Accuracy | Purpose |
|---|---|---|---|---|
| Ultrasonic | HC-SR04 | 2 – 400 cm | 2 mm | Obstacle avoidance |
| Infrared | GP2D12 | 10 – 80 cm | 5% | Line following |
| Infrared (Line) | Custom | 0 – 5 cm | N/A | Black/white line detection |
Data from these sensors are processed by the Arduino Nano through analog-to-digital conversion. For instance, the infrared sensor output voltage $V_{\text{out}}$ relates to distance $d$ via an empirical equation: $V_{\text{out}} = \frac{k}{d}$, where $k$ is a constant. By combining readings from multiple sensors, the bionic robot can make informed decisions, such as adjusting its gait to avoid obstacles or follow a path. This sensor integration is a key feature that elevates the bionic robot beyond simple mechanical motion, adding a layer of intelligence.
Software development for this bionic robot was done using the Arduino IDE, an open-source environment that simplifies coding for microcontrollers. The program structure involves initializing pins, setting up servo positions, and implementing loops for gait cycles and sensor reading. A crucial part is calibrating the servos to find the initial neutral positions, which ensures synchronized movement. Due to assembly tolerances, I incorporated software offsets to adjust PWM values dynamically. The main control algorithm follows a state machine pattern: in each loop iteration, the robot checks sensor inputs, updates its state (e.g., moving forward, turning), and computes corresponding servo angles. For example, if an obstacle is detected within a threshold distance $d_{\text{thresh}}$, the bionic robot triggers a turning routine by varying the stride lengths on each side.
To illustrate the gait sequence, consider a table mapping leg states over time. Let “1” indicate stance phase and “0” swing phase. For a tripod gait with period $T$ divided into 10 time steps, the pattern for one complete cycle is:
| Time Step | Leg 1 | Leg 2 | Leg 3 | Leg 4 | Leg 5 | Leg 6 |
|---|---|---|---|---|---|---|
| t1 | 1 | 0 | 1 | 0 | 1 | 0 |
| t2 | 1 | 0 | 1 | 0 | 1 | 0 |
| t3 | 0 | 1 | 0 | 1 | 0 | 1 |
| t4 | 0 | 1 | 0 | 1 | 0 | 1 |
| t5 | 1 | 0 | 1 | 0 | 1 | 0 |
| t6 | 1 | 0 | 1 | 0 | 1 | 0 |
| t7 | 0 | 1 | 0 | 1 | 0 | 1 |
| t8 | 0 | 1 | 0 | 1 | 0 | 1 |
| t9 | 1 | 0 | 1 | 0 | 1 | 0 |
| t10 | 1 | 0 | 1 | 0 | 1 | 0 |
This table shows the alternating pattern that keeps the bionic robot balanced. In practice, I implemented this using arrays of angle values for each servo, interpolating between keyframes to create smooth motion. The code also includes error handling for sensor failures, ensuring the bionic robot can default to a safe mode if needed.
Debugging and optimization were essential steps in developing this bionic robot. Initially, I encountered issues like leg tremor and inaccurate positioning, often due to power supply fluctuations or servo calibration errors. To address this, I improved the battery system, using a lithium-polymer pack with higher current delivery, and fine-tuned the PWM signals in software. The torque requirements for the bionic robot can be estimated using static analysis. For a leg supporting a fraction of the robot’s weight $W$, the torque $\tau$ at the coxa joint is approximately:
$$ \tau = r \cdot F = L_c \cdot \frac{W}{6} \cdot \sin(\theta_c) $$
where $r$ is the moment arm. Ensuring servos operate within their torque limits prevented stalling. Additionally, I added software limits to prevent joints from exceeding mechanical bounds, enhancing the longevity of the bionic robot.
Experiments conducted with the bionic robot validated its performance. I tested it on flat surfaces, inclined planes, and obstacle-laden paths. The sensor system successfully enabled line following with an accuracy of ±2 cm, and obstacle avoidance triggered at distances of 20 cm. The table below summarizes key performance metrics, demonstrating the effectiveness of this bionic robot design.
| Metric | Value | Conditions |
|---|---|---|
| Maximum Speed | 0.1 m/s | On flat ground, tripod gait |
| Obstacle Detection Range | 20 – 400 cm | Using ultrasonic sensors |
| Line Following Accuracy | ±2 cm | On a 3 cm wide black line |
| Power Consumption | 0.5 A (idle), 2.5 A (peak) | At 6 V supply |
| Weight | 500 g | Including all components |
These results highlight the bionic robot’s capability to perform autonomous tasks. The integration of mechanical design, control algorithms, and sensor feedback creates a cohesive system that mimics biological locomotion. Future improvements could involve adding more sensors, such as inertial measurement units for balance, or implementing machine learning for adaptive gait control. The modular nature of this bionic robot allows for easy upgrades, making it a platform for ongoing research in bionic robotics.
In conclusion, the design and research of this hexapod bionic robot based on Arduino have yielded a robust and functional prototype. By analyzing biological principles, I developed a mechanical structure with three-jointed legs and implemented a tripod gait for stable movement. The control system, centered on Arduino Nano and servo boards, allows precise actuation, while ultrasonic and infrared sensors enable environmental interaction. Through software development and debugging, I optimized performance, ensuring smooth operation. This project underscores the potential of bionic robots to bridge the gap between biological inspiration and engineering application, paving the way for more advanced autonomous systems. The lessons learned from this bionic robot will inform future designs, contributing to the evolving field of bionic robotics.